
- Posts: 133
- Thank you received: 15

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Have you tried to set.....
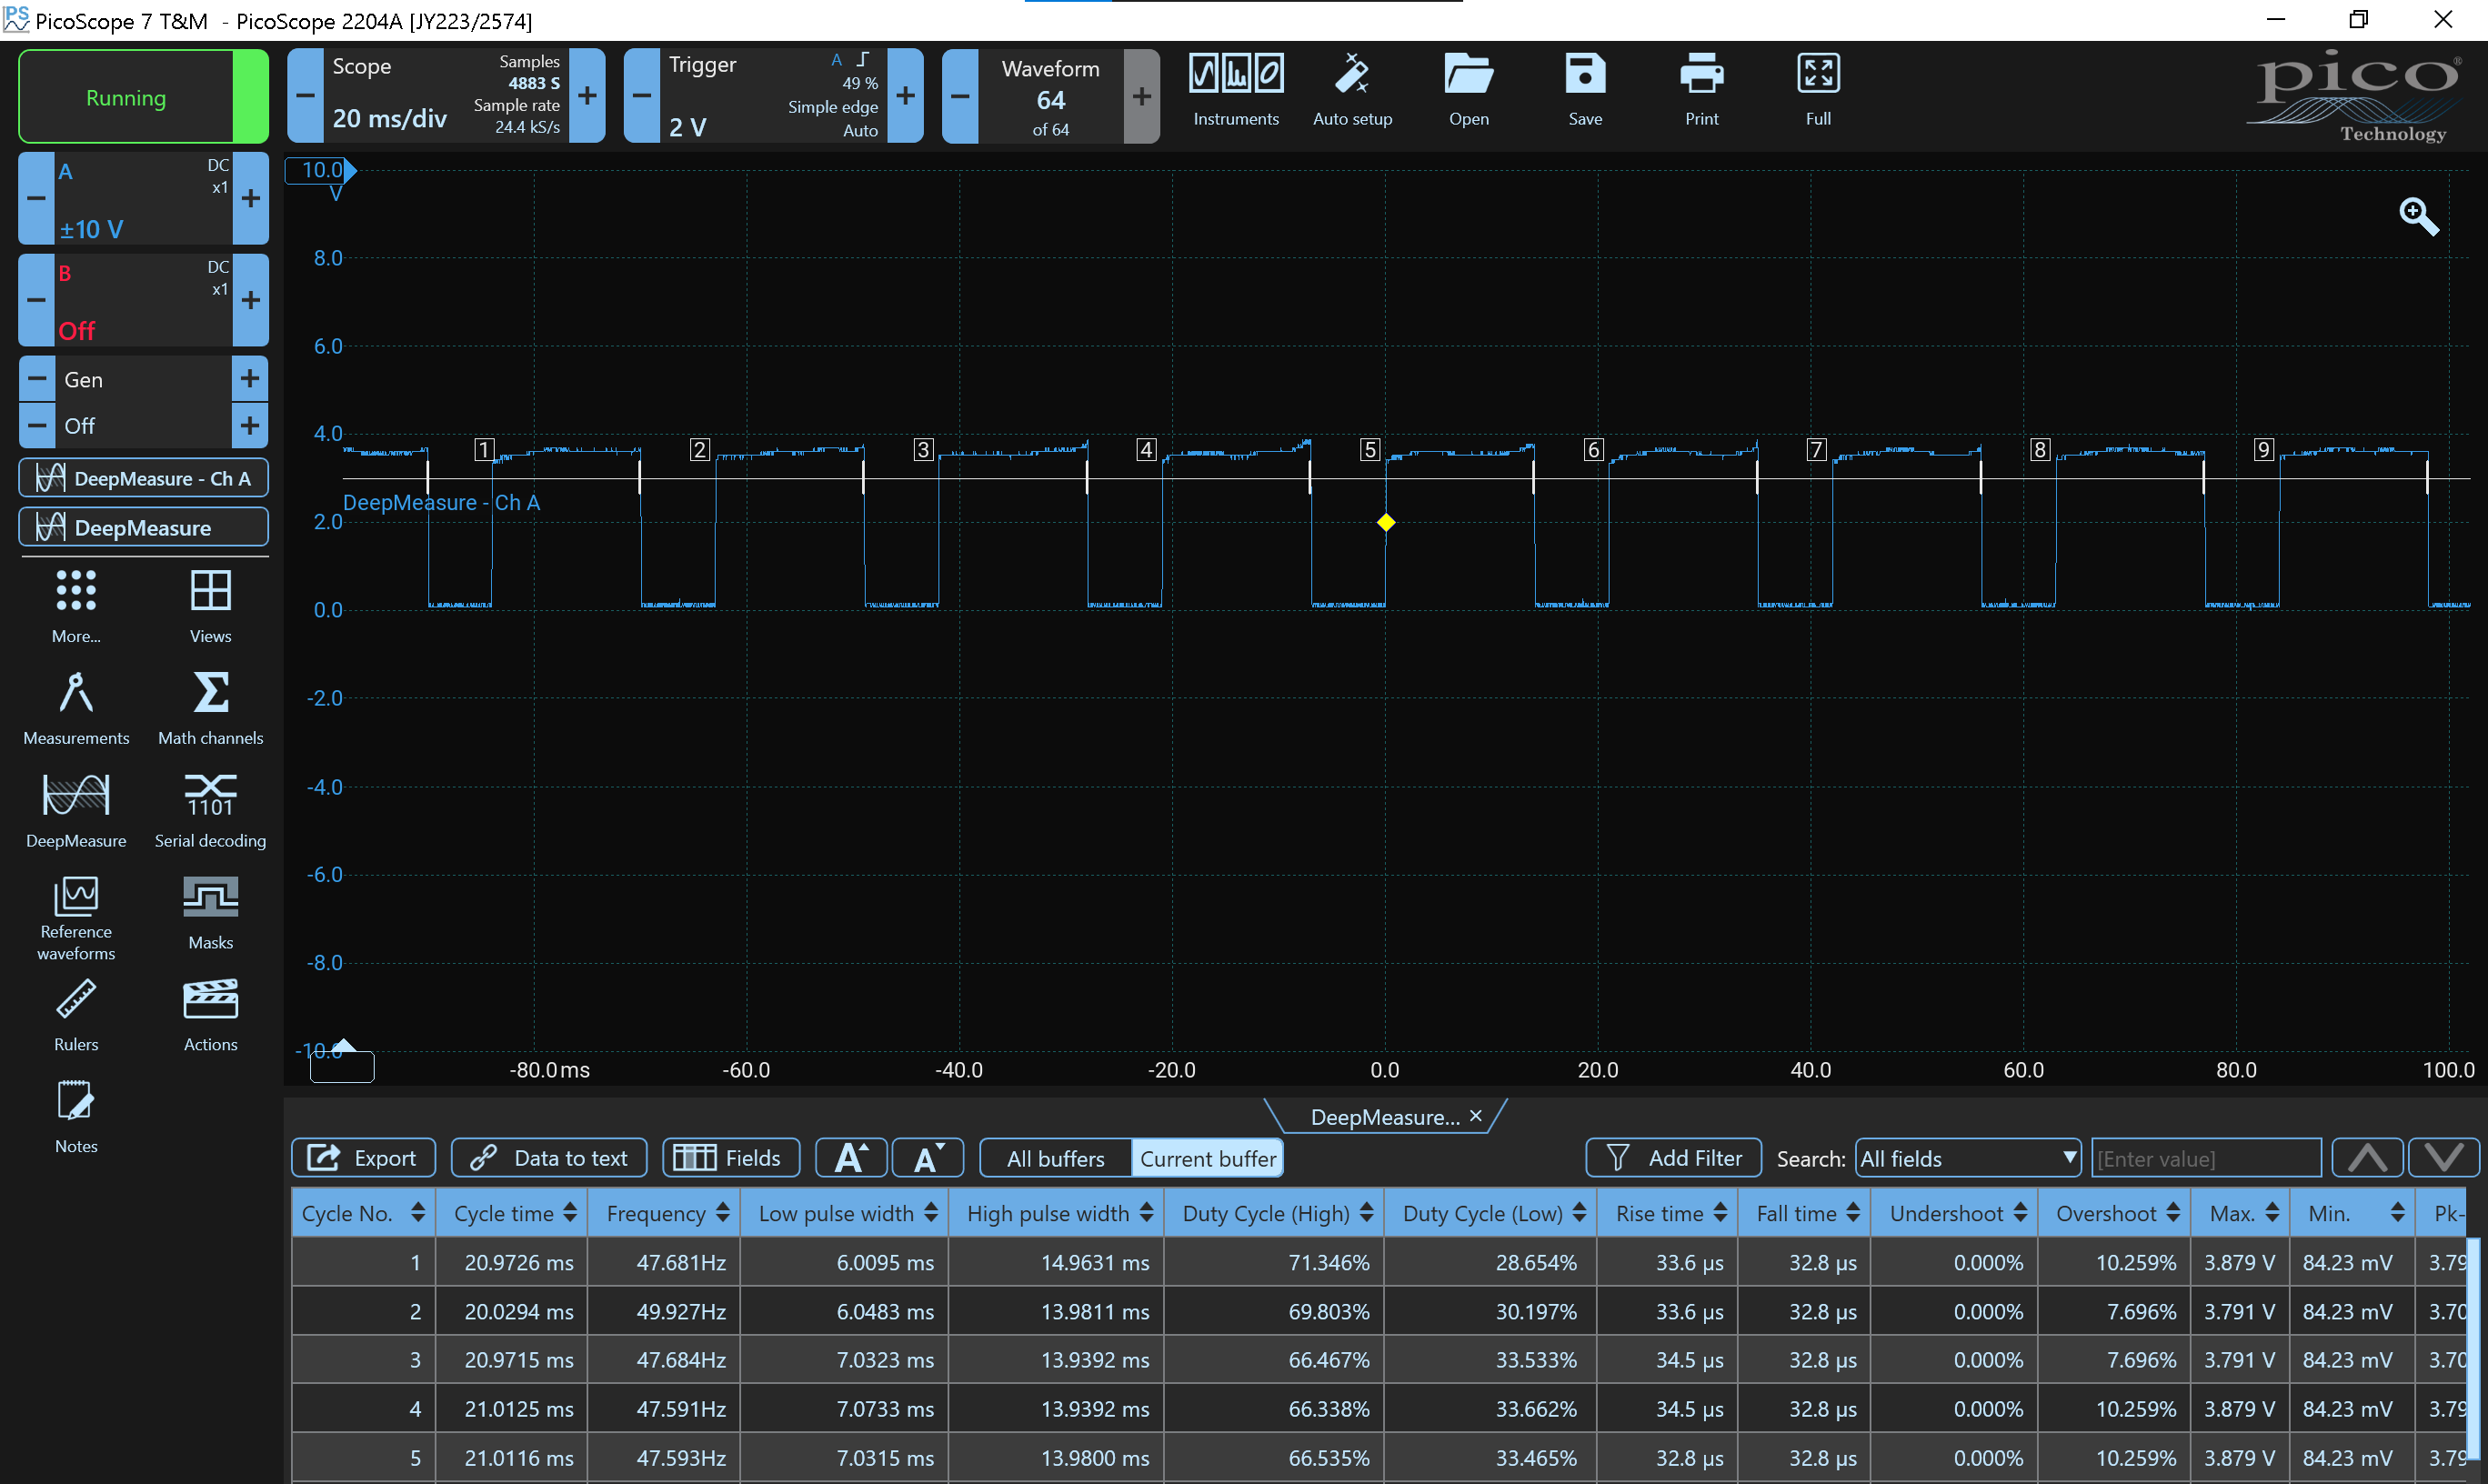
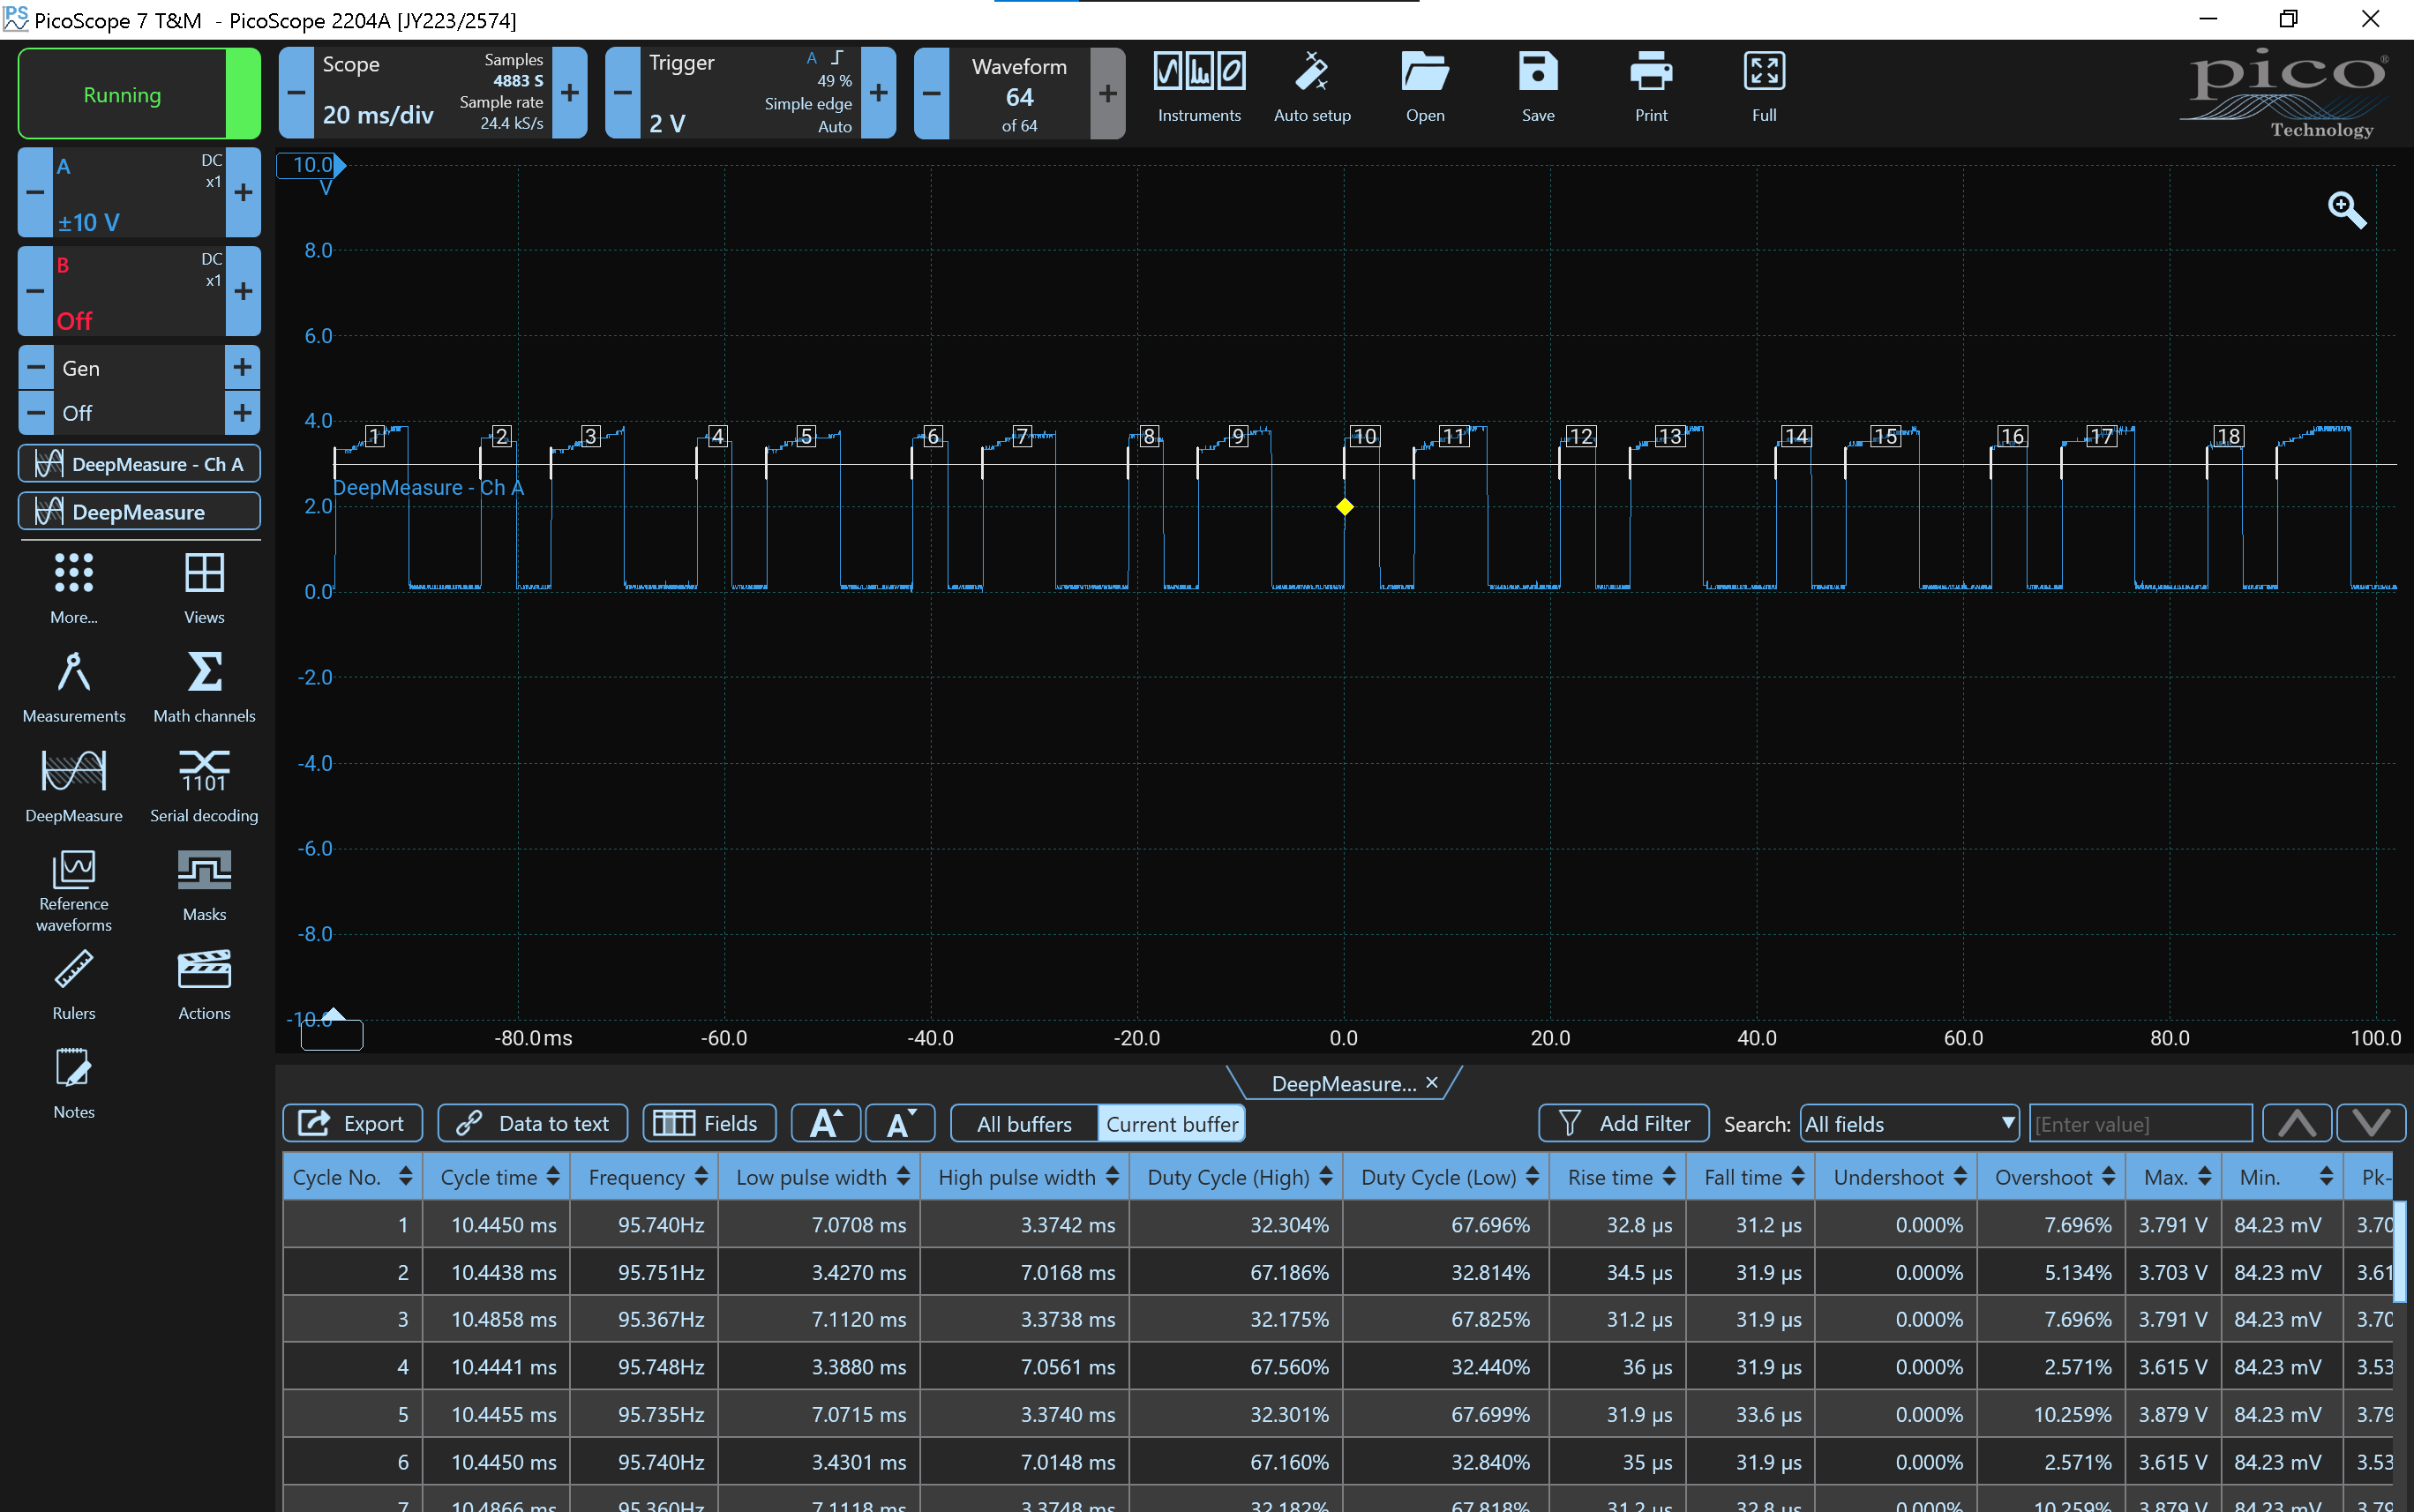
Thinking about it more with your comment, I think maybe the machine is moving the correct amount, but the position reported back to LinuxCNC isn't correct or isn't stable, for some reason. How can I look into this further? If it were just floating point rounding error, once the iceshield had arrived at the correct position, shouldn't the reported position then be stable at the rounded value, instead of flicker? My X axis is very coarse, so I am comfortable with it not having high precision, but the flickering reported value (shown in the DRO) is very odd given that it's a stepper.
Do I need to re-flash with each change of scale, or is modifying it in the .ini sufficient?
For reference,
config: github.com/digiexchris/6x11-sg-grinder-l...reconfig/config.json
generated ini: github.com/digiexchris/6x11-sg-grinder-l...eld/LinuxCNC/rio.ini
but I have changed the scale to 11.64 (yes, very coarse) for the X axis but that's what was required to get 10mm of movement from G1 X10 with a surface grinder table driven off of the normal handwheel (it's quite a large movement per handwheel turn)
I think I'll change the microstepping up to 32k so I can get the scale number higher and see what effect that has on the stability of the reported position.
if i set the deadband to :
DEADBAND = 0.0001
my DRO shows the exact position like 10.000 or 0.000
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
