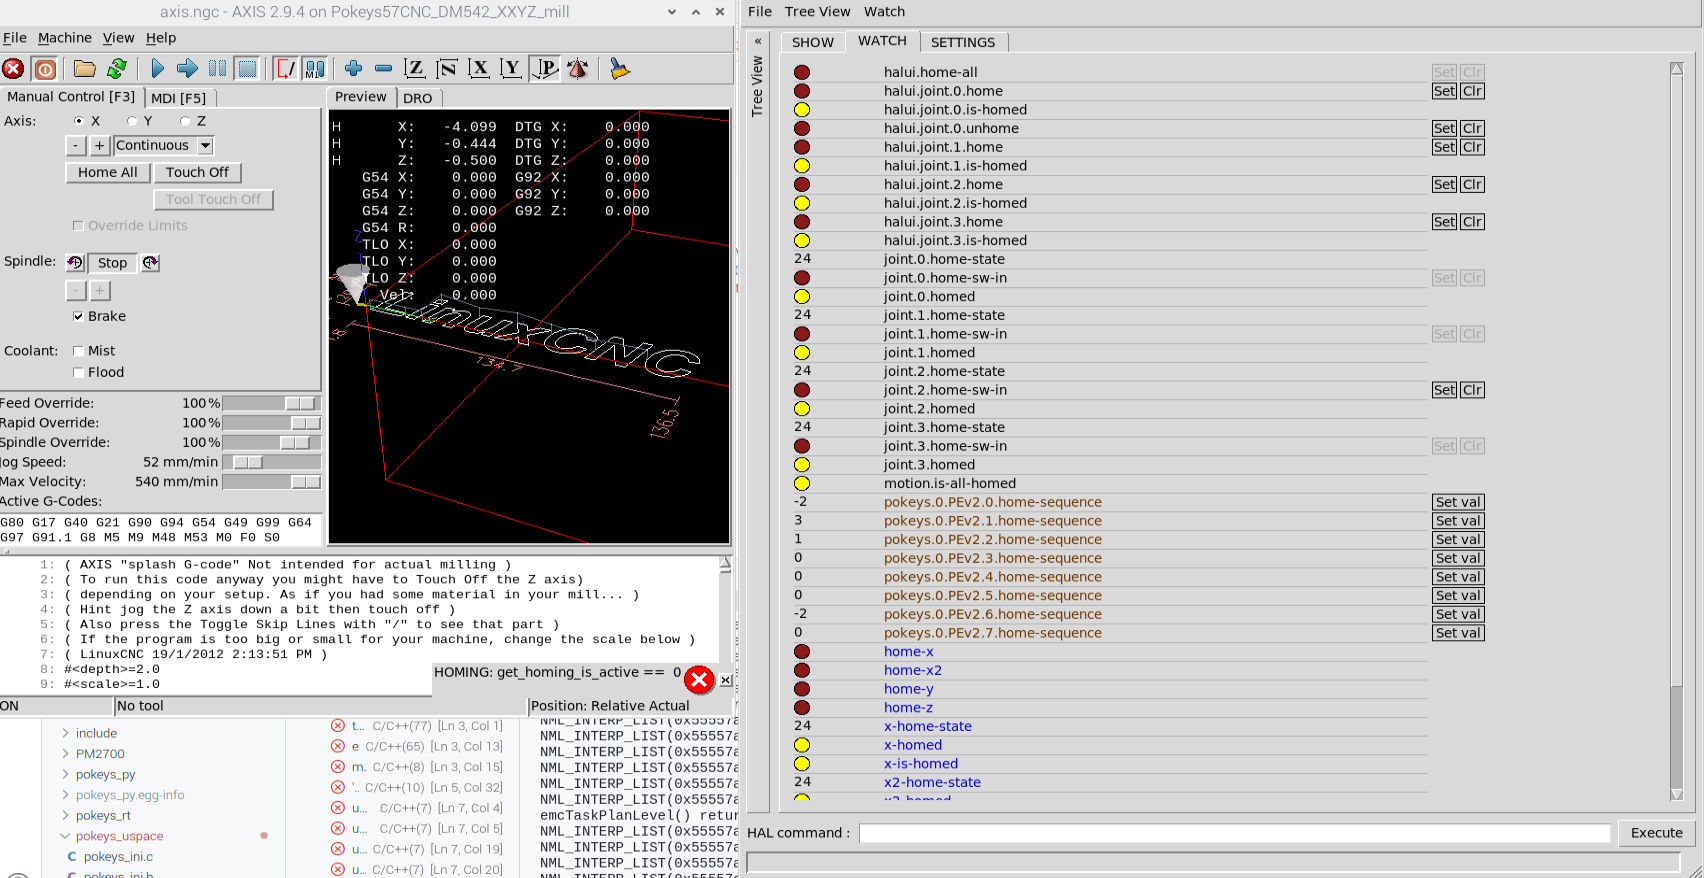
Pokeys_homecomp EncoderSearch / Encoder Arm Topic: Pos_Fb Following errors

More
1 year 7 months ago #323425 by zarfld
Replied by zarfld on topic Pokeys
Hi All,

it seems that i found the issue by accident image missing /media/kunena/emoticons/w00t.png : it seemed that some part of motion still checks the home-switch-in even if they don't have a direct influence on my homing-procedure. (that is completely outsourced to pokeys, i just await the home status, the home-switch information is there but more or less for informative purposses. i didn't use these switches at all, but it seems theres some part of motion which checks that in background)

Please Log in or Create an account to join the conversation.

More
1 year 7 months ago #325111 by zarfld
i now tried to extend the homing workflow to better align to the Linuxcnc usual homing.

my home states are :

PK_PEAxisState_axREADY   -> before homing
when Homing is triggered the pokeys internal Homingprocedure does the following states
 - PK_PEAxisState_axHOMINGSTART 
 - PK_PEAxisState_axHOMINGSEARCH 
 - PK_PEAxisState_axHOMINGBACK 
- PK_PEAxisState_axHOMING_RESETTING
- PK_PEAxisState_axHOMING_BACKING_OFF
 - (  PK_PEAxisState_axHOME ) that status of pulse engine is suppresed and 

after that i have to finalize the pokeys homing procedure by a "PK_PEv2_HomingFinish" command in order to operate that joint again for tho upcoming steps there fore i added two additional steps: 
    PEAxisState_axReadyToFinalizeHoming  -  used as a indicator from pokeys.comp to pokeys_homecomp that the homing finalize command can be triggered

    PK_PEAxisState_axReadyToArmEncoder  in this step that index search part should take place, in that step my intention was to reset the position feedback to ZERO_POSITION, to prevent problems on pokeys due to the (softlimits on the device side).

on the Joint for Z i have the problem that the difference to zero position is quite high as the position change might be 100 mm

so here i'm at a point  where i don't figure out what to do, and either where to find out or whom to ask for help.

what i currently try to do is 
Joint_num].index_enable = index_search_active;  at the PK_PEAxisState_axReadyToArmEncoder status


and at the follwoing status
PK_PEAxisState_axHOMINGARMENCODER  i basically reuse the actions as were done in homing.c at "HOME_INDEX_SEARCH_WAIT"

                if (H[joint_num].index_enable == index_search_armed) {
                    /* yes, stop motion */
                    joint->free_tp.enable = 0;

                    // joint->free_tp.pos_cmd = joint->free_tp.curr_pos; // set to zero
                    joint->free_tp.pos_cmd = 0; // set to zero

                    /* Pokeys resets encoder position to zeros */
                    H[joint_num].index_enable = index_search_armed;

                    H[joint_num].homing = 1;
                    H[joint_num].home_state = HOME_SET_INDEX_POSITION;
                }


but it always stops at about that step and some part triggers "do_cancel_homing"
the only message that i could see on my last version was 
"emc/task/taskintf.cc 976: Error on joint 3, command number 139"

(until now a similar message was together with a FOLLOWING_ERROR for that joint)

Is there someone who could tell me where to check, or whom to ask. I'm not sure if this thread is the right place to ask about that topic.

BR
Dominik

Please Log in or Create an account to join the conversation.

More
1 year 6 months ago #325552 by andypugh
Looking at the code around taskintf.cc:976 that error indicates that EMCMOT_JOINT_ERROR_BIT is being set. Have you tried tracking down what might be causing that?

Please Log in or Create an account to join the conversation.

More
1 year 6 months ago - 1 year 6 months ago #325903 by zarfld
thanks for the answer!

the "errors" seem to be the limitswitches. (i need to check the simulation).i disconnected the HAL signals from joints and now that works.

an minor issue which i can workaraound by just providing pos_fb=0.0 during homing procedure on pokeys is that i don't know how to "Pause" Linuxcnc from checkeing pos_fb versus pos_cmd for following errors during homing procedure.
(in homing.c i have seen some "free_tp.enable=0" and applying ofstes to pos_fb and pos_cmd - i think i have to check that more in detail)

BR
Dominik 
Last edit: 1 year 6 months ago by zarfld.

Please Log in or Create an account to join the conversation.

More
1 year 6 months ago #325905 by rodw

an minor issue which i can workaraound by just providing pos_fb=0.0 during homing procedure on pokeys is that i don't know how to "Pause" Linuxcnc from checkeing pos_fb versus pos_cmd for following errors during homing procedure.
You use a component that sets pos_cmd == pos_fb while homing.
An example of this is the cia402.comp used with Ethercat drives.
The following user(s) said Thank You: zarfld

Please Log in or Create an account to join the conversation.

More
1 year 6 months ago #325907 by rodw

Please Log in or Create an account to join the conversation.

Time to create page: 0.070 seconds
Powered by Kunena Forum