Servo Spindle motor encoder Mesa 7i76e

More
6 years 7 months ago #160920 by andypugh

blazini36 wrote: [


If you provide a sort-of tunnel round the back of the ball-nut mount you can have a sheet metal cover for the ballscrew slot.
"tunnel" piece
photos.app.goo.gl/o18GwVWe4rti654Q9
Then cover strip in place:
photos.app.goo.gl/3irQBj1pRtioLbor9
And in-situ on the column.
photos.app.goo.gl/ctRiwQ5ArB8ZugM16

(Not my idea, I stole it from the compound of my dad's Smart and Brown Model M)

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago - 6 years 7 months ago #161102 by Erikcnc
Im thinking of using this encoder and connect it through a small timing belt to the spindle and not using the encoder of the motor anymore.
any thoughts?

Yumo COM-11102 Encoder 1024 P/R
Last edit: 6 years 7 months ago by Erikcnc.

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago #161105 by andypugh

Erikcnc wrote: Im thinking of using this encoder and connect it through a small timing belt to the spindle and not using the encoder of the motor anymore.


Should work. It has an index (not all do)

Though as Blazini showed, motor encoder + separate index can work well.

Please Log in or Create an account to join the conversation.
More
6 years 7 months ago #161113 by Erikcnc

andypugh wrote:

Erikcnc wrote: Im thinking of using this encoder and connect it through a small timing belt to the spindle and not using the encoder of the motor anymore.


Should work. It has an index (not all do)

Though as Blazini showed, motor encoder + separate index can work well.


How do i realize this? I got a bunch o NPN NO sensors to test it.
I have to make sure that the spindle rotates the right rpm.

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago #161160 by JohnnyCNC
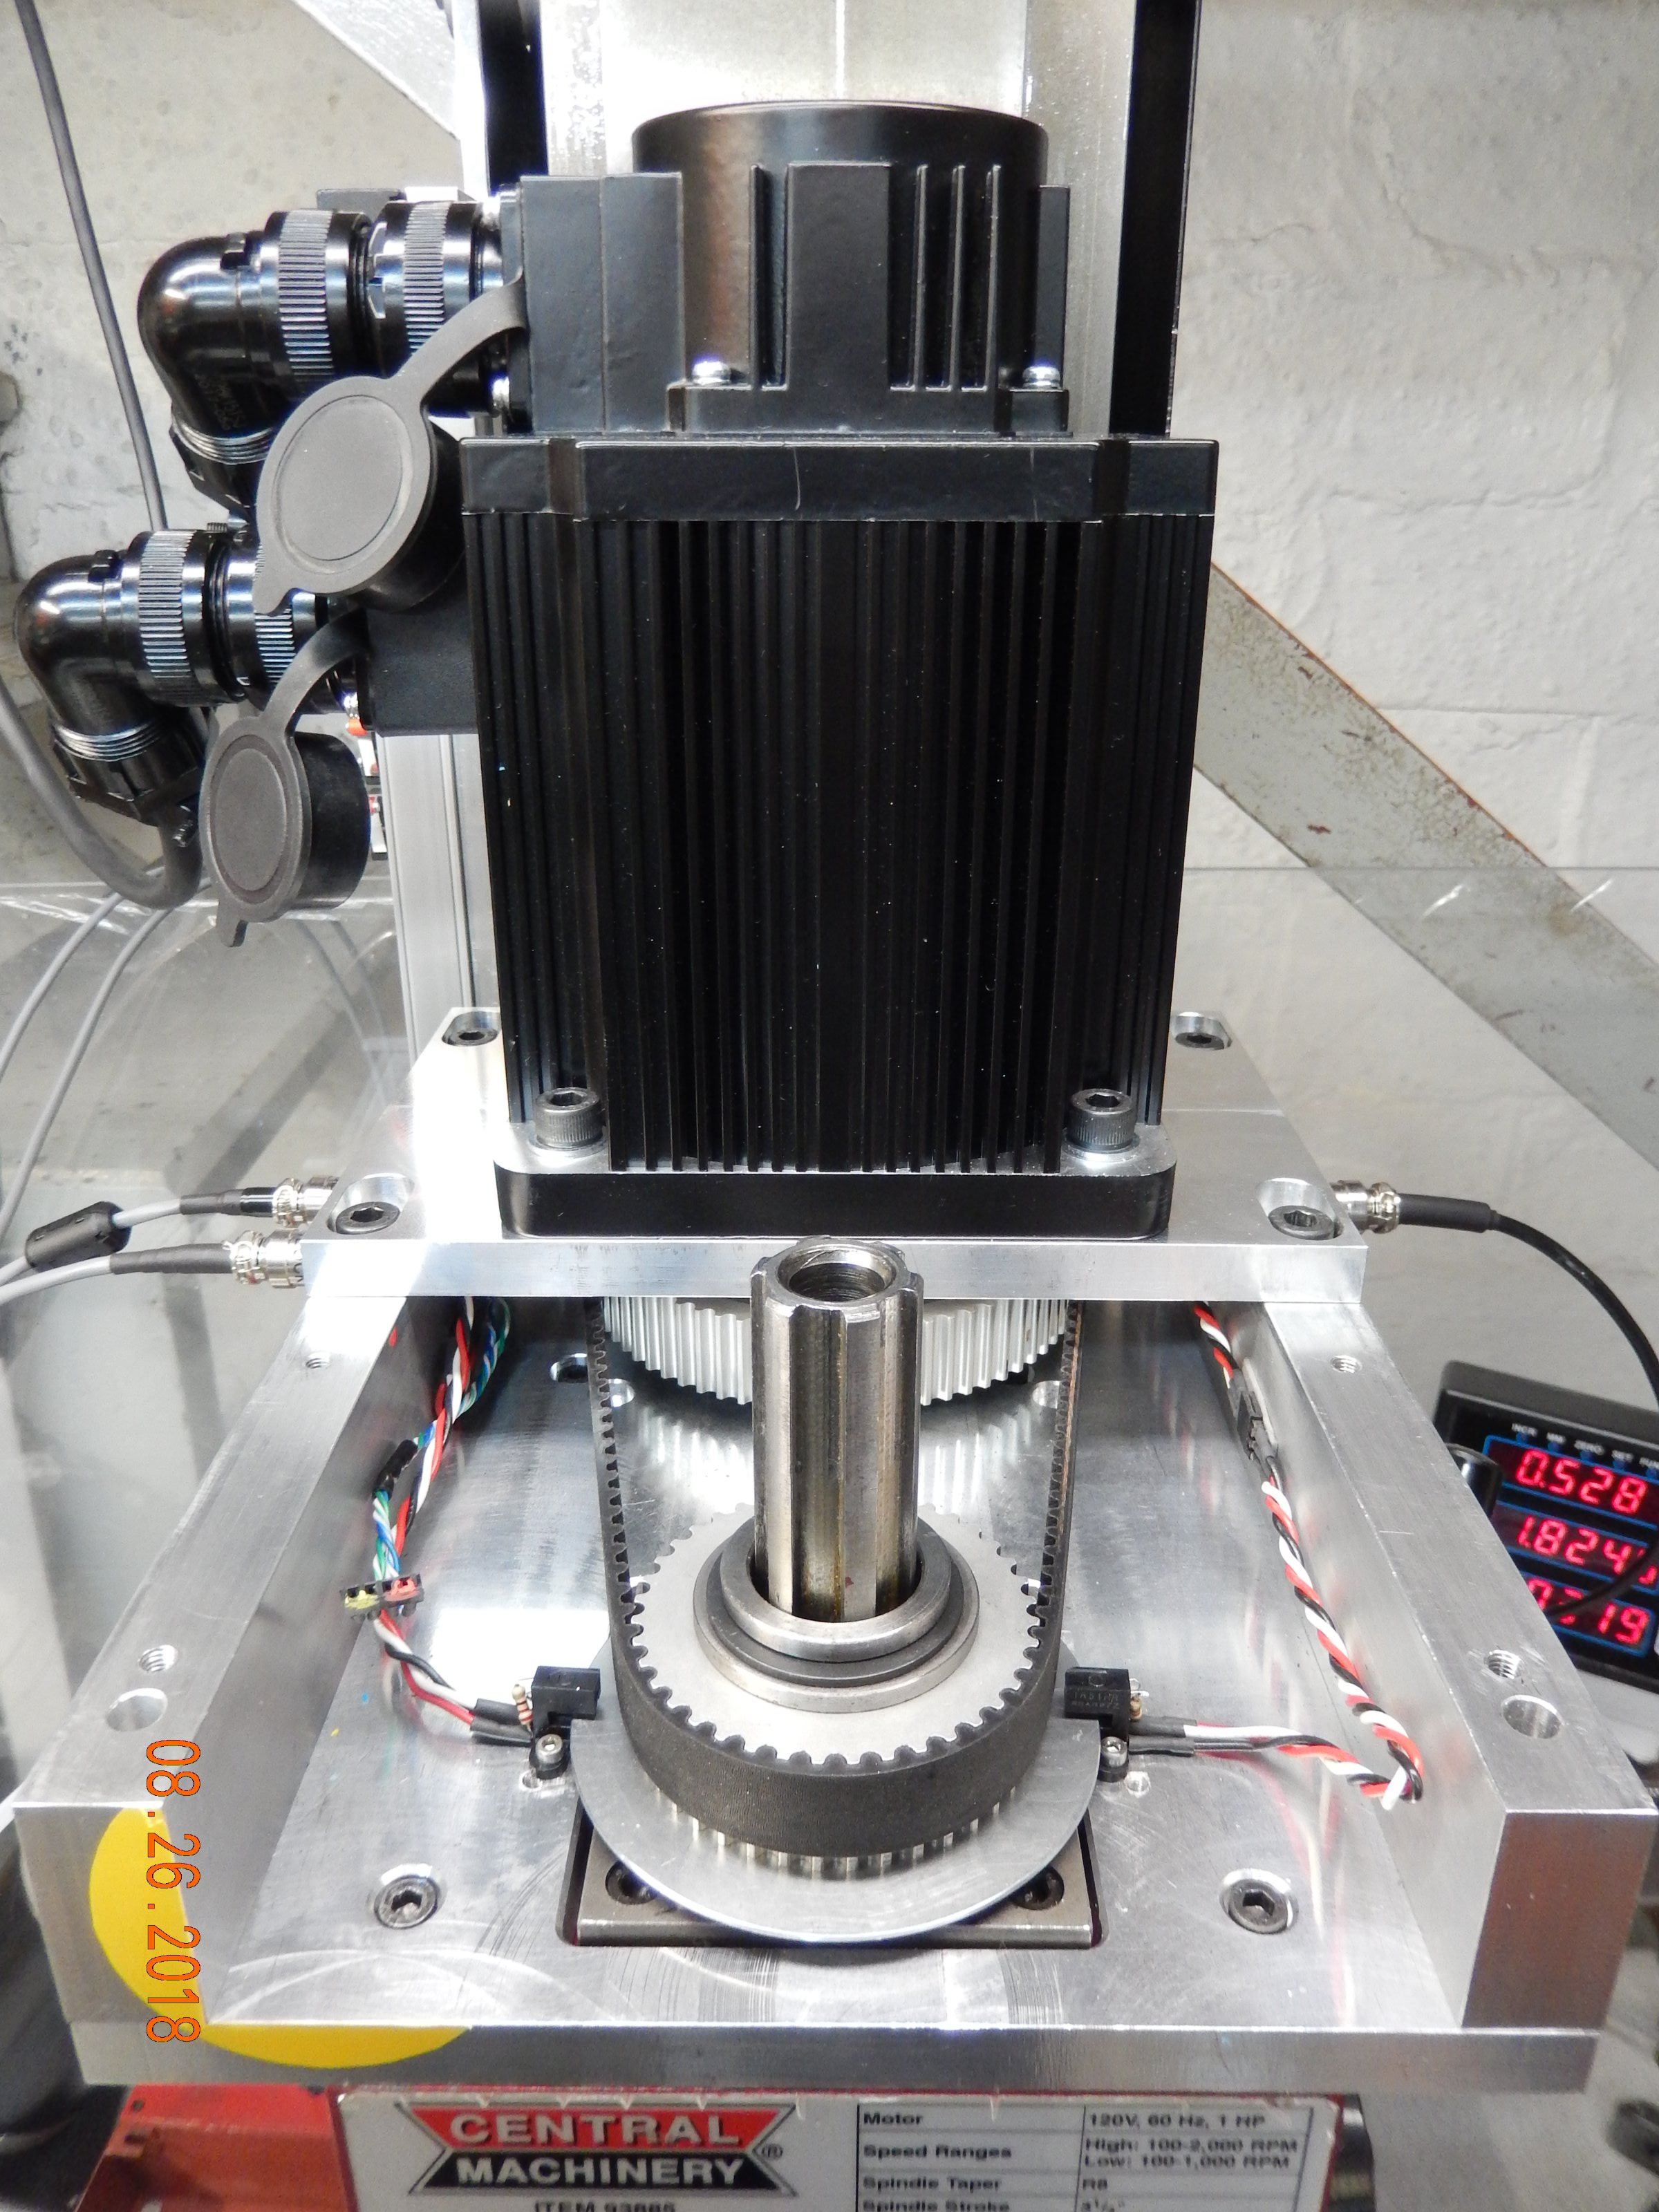
You could make that work. If it is geared 1:1 you can use the A/B/Z signals right from the encoder. On my mill I used the A/B signals that my spindle servo motor drive outputs and added a separate index signal to the spindle. This is because the spindle motor is geared 1:1.8. You will actually see two pickups for the index signal/ This is because the second one drives the a DRO that I also have on the mill.

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago - 6 years 7 months ago #161292 by blazini36

Erikcnc wrote:

andypugh wrote:

Erikcnc wrote: Im thinking of using this encoder and connect it through a small timing belt to the spindle and not using the encoder of the motor anymore.


Should work. It has an index (not all do)

Though as Blazini showed, motor encoder + separate index can work well.


How do i realize this? I got a bunch o NPN NO sensors to test it.
I have to make sure that the spindle rotates the right rpm.

For that you'll have to use a known good device to either calculate the spindle speed or measure it. Assuming you have no optical tach or anything to measure the spindle directly......If you spin your motor exactly 1 rotation (just the motor), the number of counts from the encoder count pin should match it x4, so a 1000ppr encoder should show 4000 counts, in that case your "scale" in the .ini is 4000, and your velocity feedpack pin will represent rotations per second exactly at the motor, but this is not what you want unless your belt ratio is exactly 1:1.

Excuse any math mistakes, I'm writing this off the top of my head, I'll use the 1000ppr as an example....
Since you are not using a timing belt you should spin your spindle by hand and let it drive your motor then you can estimate the difference, how accurate you get is all in how thorough you are. Spin the spindle exactly 1 time and look at how many counts feed back from the motor, if you get 2500 counts, then divide 2500 into 4000 and you get 0.625. Now if LinuxCNC is driving your motor based on the encoder feedback then you want to leave your hm2.7i76e.......encoder.scale pin at 4000. Use the scale hal component with the gain pin set at 0.625 to feed back into motion.spindle−speed−in pin. You also need to use another scale component to scale the position pin the exact same amount into the motion.spindle−revs pin. Now your spindle speed/position requirements are satisfied for LinuxCNC.

To make the index work when your motor is not 1:1 with the spindle exactly, disconnect the index pin in hal and physically, you don't need it. Use the NPN prox switch with the signal wire tied into the 7i76e's encoder index input. then connect the motion.spindle−index−enable pin to the 7i76e......encoder.index-enable hal pin. This works because the spindle index prox is still resetting the position pin on the 7i76e at a rate that will roughly equal "1" to motion since it is scaled to do so. in order to use a Prox in the 7i76e's encoder index it has to either be NPN or 5v PNP, do not use a higher voltage prox with the encoder index unless it is NPN and shares common with the 7i76e's logic side..
Last edit: 6 years 7 months ago by blazini36.

Please Log in or Create an account to join the conversation.

Time to create page: 0.267 seconds
Powered by Kunena Forum
