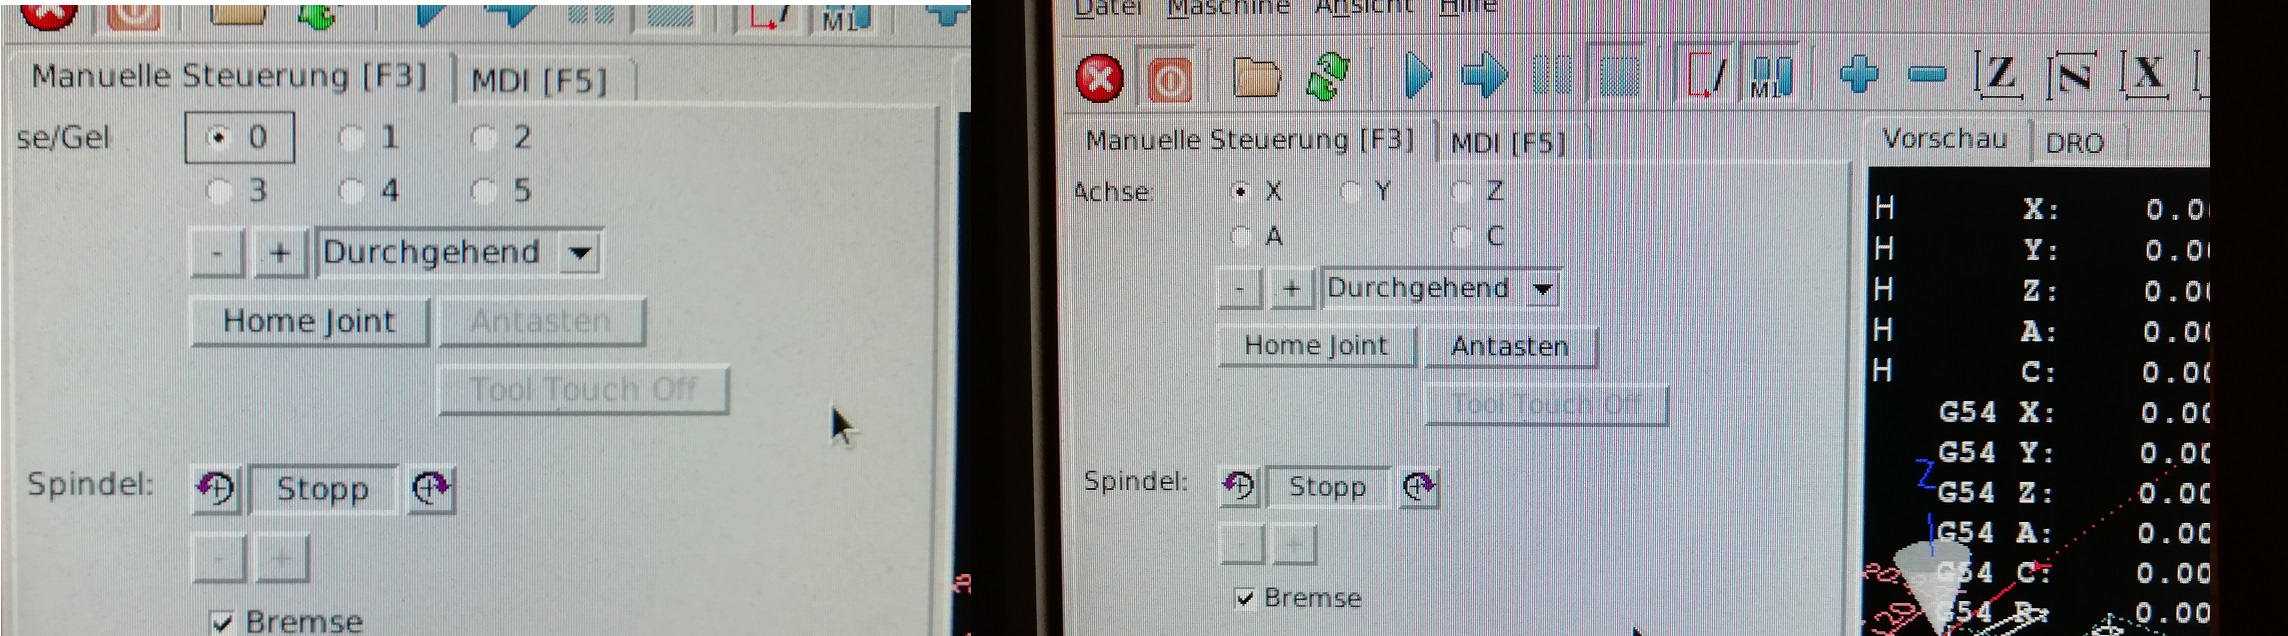
Why do I have to home every single joint before being able to jog and home full axes? Isn´t that dangerous for a gantry type machine, only homing y2 for example?
As Peter says, you need HOME_SEQUENCE=N for each joint in your ini.
Joints 1 & 2 (your Y axis) need to be HOME_SEQUENCE=-1
Joint 3 (your Z) is usually HOME_SEQUENCE=0 so it lifts up out of the way at the beginning
All of the rest could be HOME_SEQUENCE=1 so they all home simulteneously or you could continue the sequence to do them in sequence eg use 1,2,3 to set the order you want.