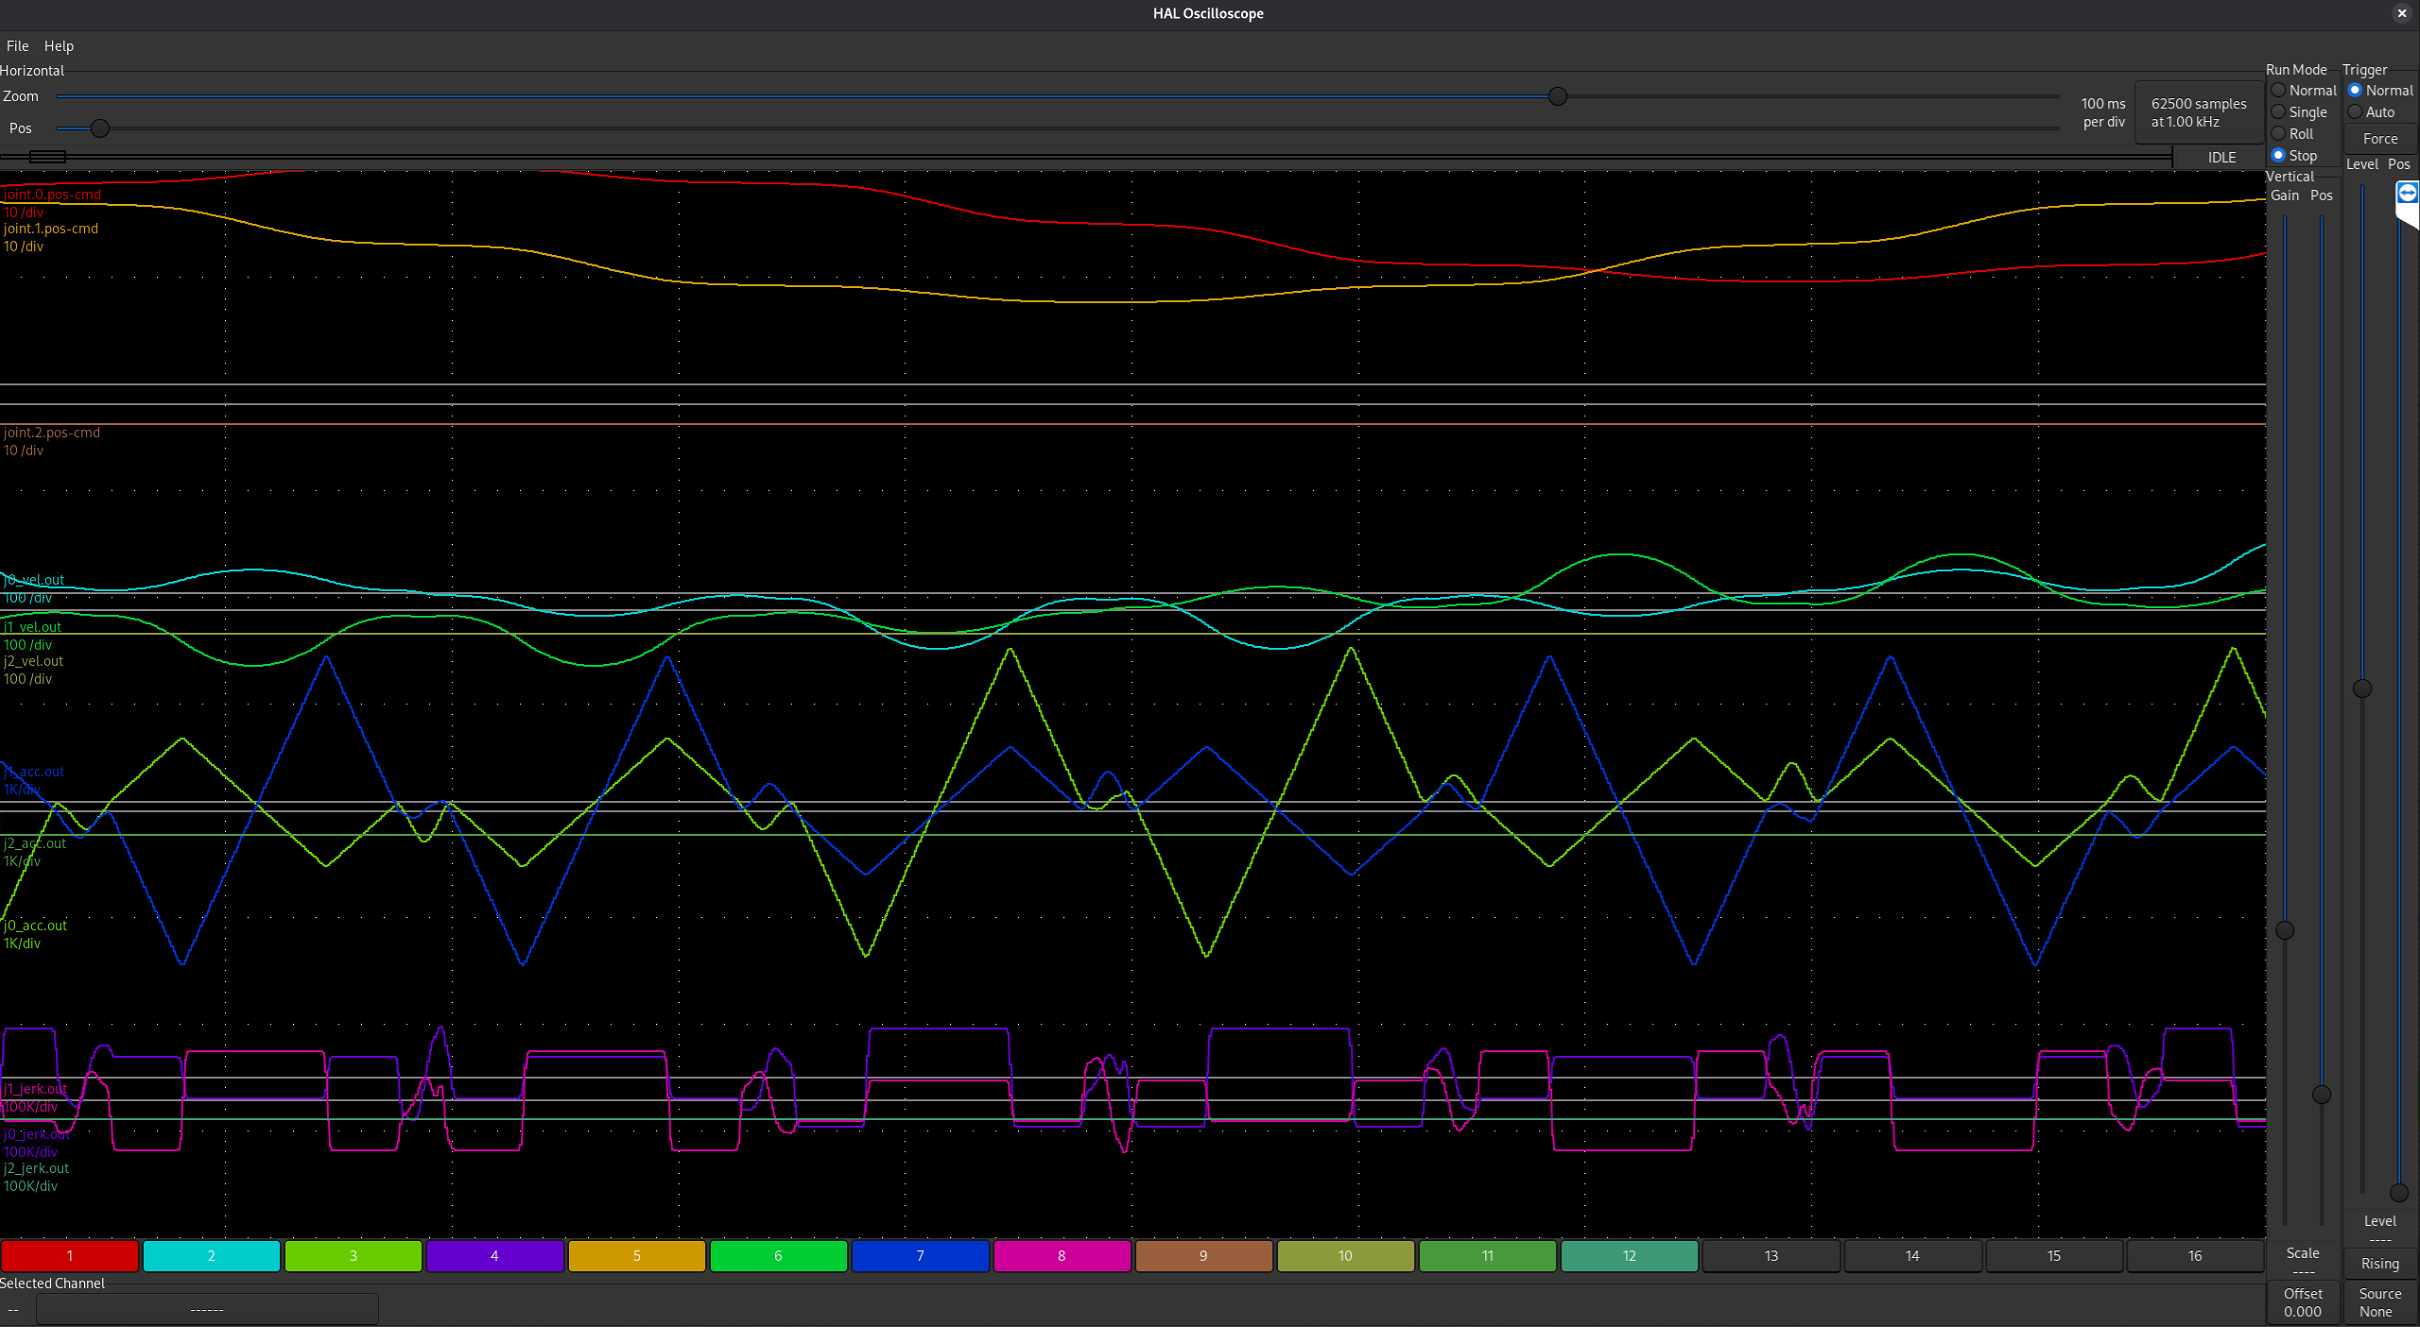
I was wrong, on closer inspection the planner can stay within the jerk limit without falling back to a full stop.
It was a bug in the jerk budget split during Bezier blends. Tangential jerk (Ruckig along the path) and centripetal jerk (curvature change through the blend) were budgeted independently, 50% and 100% of the per-joint limit respectively, assuming they're orthogonal. They are in Cartesian space, but not per joint axis, where they add as scalars. For @ruediger123's octagon: 25k + 50k = 75k on a 50k limit, matching the ~47% overshoot in the HALscope trace.
Fix: subtract the tangential share before allocating centripetal. 25k + 25k = 50k, exactly at the limit, no overshoot, no wasted headroom. Corner velocity drops ~20% vs the buggy code, but it's the true physical maximum.
@PCW was right, the TP should always obey constraints. Fix is in the 9d branch.
Edit:
the artifacts at the end of the page.
I'm also looking at what Automata had reported, I think I can improve merging of small segments, I'll put some effort into that
Edit:
I think the previous build maybe have some issue because I merged master without being careful
New build, still working on speed, not ready yet
delete link, this had issues too