

Orientation position problem after run Gcode

More
3 years 1 month ago #282027 by tommylight
Try this:
Machine powered and enabled
Spindle off
watch the spindle encoder count in hal show
make a line on the spindle to have a 0 reference point where the encoder shows 0
turn spindle by hand 10 times
see the encoder count, it is 10 times bigger?
-
Check the spindle encoder scaling, if you have a 1024 PPR encoder, probably scale should be 4096.
In this case after 10 turns you should see 40960
If not, there are two possibilities, scaling is wrong or encoder is faulty/miss wired/not counting properly/does not have quadrature outputs/voltage to low/ outputs not able to swing high enough to register/
The following user(s) said Thank You: abdulasis12

Please Log in or Create an account to join the conversation.

More
3 years 1 month ago #282029 by tommylight

Yesterday I try install  EMI Filter on Servo Drive X,Y,Z 
There is no need for more that one of those for the whole machine if they are rated for more current than the machine can use.
Those are "line filters" so will not help with EMI created inside the machine, they do prevent interference going into or out of the machine through mains power lines.
For you case, ferrite beads or doughnuts on motor wires near the drives should help.
But as noted above by Aciera, shielded cables and proper grounding is essential.
The following user(s) said Thank You: abdulasis12

Please Log in or Create an account to join the conversation.

More
3 years 4 weeks ago #282116 by abdulasis12

Try this:
Machine powered and enabled
Spindle off
watch the spindle encoder count in hal show
make a line on the spindle to have a 0 reference point where the encoder shows 0
turn spindle by hand 10 times
see the encoder count, it is 10 times bigger?
-
Check the spindle encoder scaling, if you have a 1024 PPR encoder, probably scale should be 4096.
In this case after 10 turns you should see 40960
If not, there are two possibilities, scaling is wrong or encoder is faulty/miss wired/not counting properly/does not have quadrature outputs/voltage to low/ outputs not able to swing high enough to register/
I try done 
10 rev move with hand  and check in hallshow ,The number about 4096*10=  40,960   +- little (with hand stop position)

I try more..
50 rev with hand yes it's 4096*50 = 204,800 +- little (with hand stop position)

I pretty sure my encoder correct on 1024ppr and 4096 per 1revolution.

If not, there are two possibilities, scaling is wrong or encoder is faulty/miss wired/not counting properly/does not have quadrature outputs/voltage to low/ outputs not able to swing high enough to register/

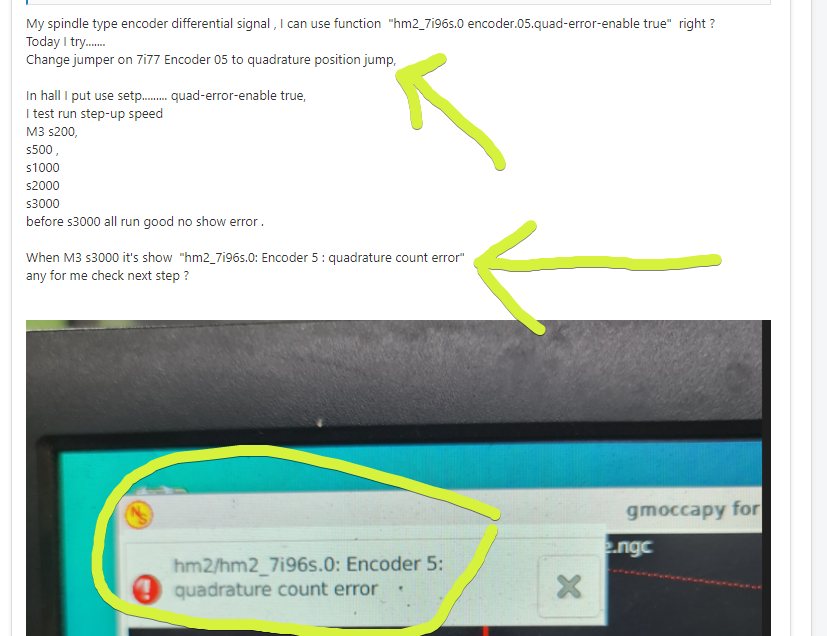
I ever try change jumper from differential to quadrature and use this solution from MR.PCW
Result is 

When M3 s3000 it's show  "hm2_7i96s.0: Encoder 5 : quadrature count error"


Please Log in or Create an account to join the conversation.

More
3 years 4 weeks ago #282130 by Aciera
Also note that spindle orientation uses an index signal that recurs once per revolution. I don't know if you are getting that from the sensor as well but if that signal looks like the A and B count signals on your scope then I don't think there is not much hope for proper spindle orientation.

Please Log in or Create an account to join the conversation.

More
3 years 4 weeks ago #282133 by 0x2102
@abdulasis12

I noticed a similar problem with my setup. High speed spindle with encoder (36K rpm). Position would be accurate until I reach a certain rpm - 18000rpm in my case.

In your situation, you might be able to fix it (EMI?). In my case I wrote a simple COMP to reset the spindle Index = 1 or high after I issue an M3 command. 

The COMP is waiting for an M3 (the spindle to reach an RPM range where the encoder signal is stable but above your tapping speed. 

Hope this makes sense and it might be food for thought. 

sets spindle-sync          1          
net  spindle-sync            enable-spindle-index.out => spindle.0.index-enable => hm2_7i95.0.encoder.04.index-enable    
net spindle-brake-on      spindle.0.brake                  => enable-spindle-index.brake-on


The following user(s) said Thank You: Aciera, abdulasis12

Please Log in or Create an account to join the conversation.

More
3 years 4 weeks ago - 3 years 4 weeks ago #282230 by abdulasis12

@abdulasis12

I noticed a similar problem with my setup. High speed spindle with encoder (36K rpm). Position would be accurate until I reach a certain rpm - 18000rpm in my case.

In your situation, you might be able to fix it (EMI?). In my case I wrote a simple COMP to reset the spindle Index = 1 or high after I issue an M3 command. 

The COMP is waiting for an M3 (the spindle to reach an RPM range where the encoder signal is stable but above your tapping speed. 

Hope this makes sense and it might be food for thought. 

sets spindle-sync          1          
net  spindle-sync            enable-spindle-index.out => spindle.0.index-enable => hm2_7i95.0.encoder.04.index-enable    
net spindle-brake-on      spindle.0.brake                  => enable-spindle-index.brake-on


Hi MR.  0x2102
I think I will try your solution, Now I have a problem .

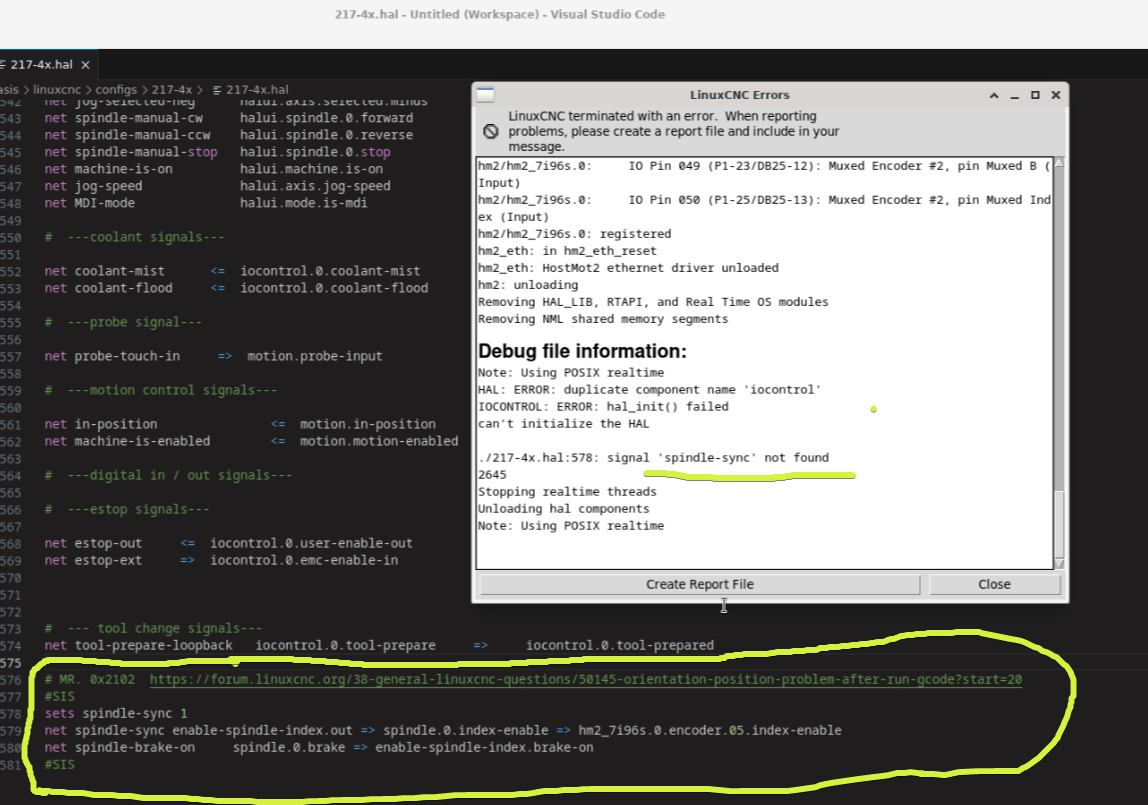
I put your hall  and change to my hm2

sets spindle-sync 1          
net  spindle-sync enable-spindle-index.out => spindle.0.index-enable => hm2_7i96s.0.encoder.05.index-enable    
net spindle-brake-on spindle.0.brake => enable-spindle-index.brake-on

Save and run linuxcnc, Show error   signal 'spindle-syn not found '

Please give me some advice.

 
Last edit: 3 years 4 weeks ago by abdulasis12.

Please Log in or Create an account to join the conversation.

Time to create page: 0.398 seconds
Powered by Kunena Forum