
- Posts: 4819
- Thank you received: 2177

Please Log in or Create an account to join the conversation.

Hi MR.AcieraAh ok, it's actually an or2 component not a mux2 so that is fine then. I haven't gone over your hal in great detail and debugging spindle orientation can be a difficult task. Doing it remotely is very difficult indeed.
So the first thing I would suggest is to thoroughly test the spindle orient functionality by running the spindle and then do an M19 R0 then run the spindle again and do another M19 R0. You want this to work at least a hundred times using different spindle speeds and directions before moving on to other things.Today
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Hi MR.PCWI would set the hm2_7i96s.0 encoder.05.quad-error-enable bit,
do your gcode test and see if hm2_7i96s.encoder.05.quad-error gets set true
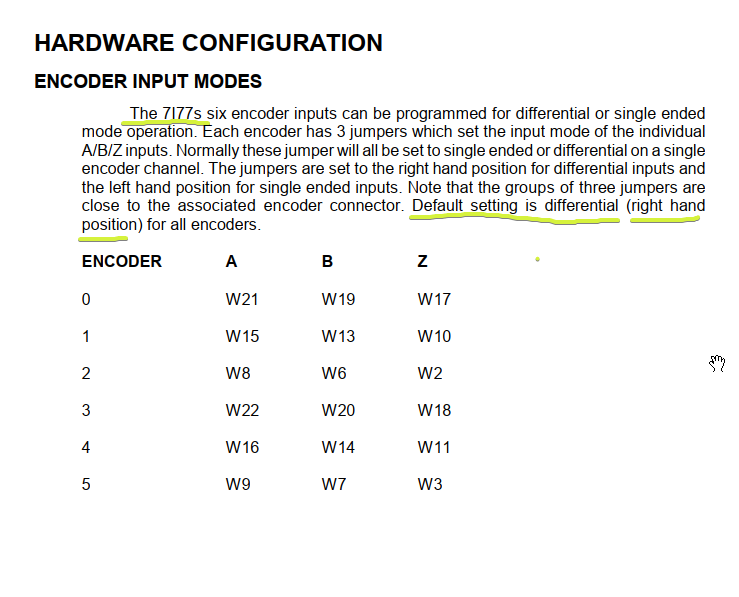
Is the spindle encoder differential?
If so, is the 7I77 set for differential inputs?
Please Log in or Create an account to join the conversation.
Ahh I just got you meaning set jumper.
I would set the hm2_7i96s.0 encoder.05.quad-error-enable bit,
do your gcode test and see if hm2_7i96s.encoder.05.quad-error gets set true
Is the spindle encoder differential?
If so, is the 7I77 set for differential inputs?
Hi MR.PCW
Yes, My spindle Encoder is Differential.
---- If so, is the 7I77 set for differential inputs?
Hmmm, I not sure , How to recheck ?
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
