
- Posts: 532
- Thank you received: 327
Trajectory Planner using Ruckig Lib
- Joco
- Offline
- Platinum Member
-

Less
More
2 years 11 months ago - 2 years 11 months ago #285674
by Joco

Unless there is some more to do before that h/w test is viable.
Replied by Joco on topic Trajectory Planner using Ruckig Lib
Don't forget to book it in else I can't run up a test on real h/w.Skynet presents : tpmod_T800
Scurve, using velocity ends, look ahead.
This is fun.
Unless there is some more to do before that h/w test is viable.
Last edit: 2 years 11 months ago by Joco.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- rodw
- Offline
- Platinum Member
-
Less
More
- Posts: 12170
- Thank you received: 4153
2 years 11 months ago #285678
by rodw
Replied by rodw on topic Debian 12 - 2.9.1 image for the Raspberry Pi 4b/400
Yes push it please Grotius. We all want to see it on real hardware.

MAybe you will have to place an embargo on JoCo until you get it on your table

MAybe you will have to place an embargo on JoCo until you get it on your table
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 11 months ago #285723
by Grotius
Replied by Grotius on topic Debian 12 - 2.9.1 image for the Raspberry Pi 4b/400
Hi,
Github is updates.
Joco, enable ve by setting the hal pin.
I thought to blend the rapids. I think this makes some sence.
Github is updates.
Joco, enable ve by setting the hal pin.
I thought to blend the rapids. I think this makes some sence.
The following user(s) said Thank You: Joco
Please Log in or Create an account to join the conversation.
- dm17ry
- Offline
- Elite Member
-

Less
More
- Posts: 212
- Thank you received: 91
2 years 11 months ago #285733
by dm17ry
Replied by dm17ry on topic Debian 12 - 2.9.1 image for the Raspberry Pi 4b/400
doesn't non-zero end velocity lead to infinite jerks?

The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 11 months ago #285746
by Grotius
Replied by Grotius on topic Debian 12 - 2.9.1 image for the Raspberry Pi 4b/400
This is indeed a problem, i think if Joco test this on his machine he can get a following error.
velocity end=0
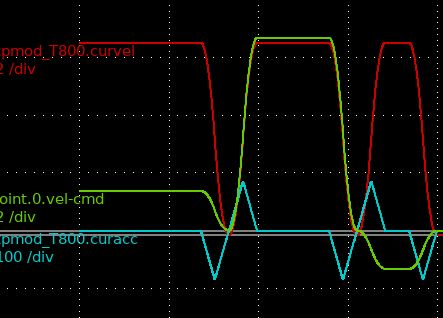
velocity end=1, here you see a vel-cmd jump.
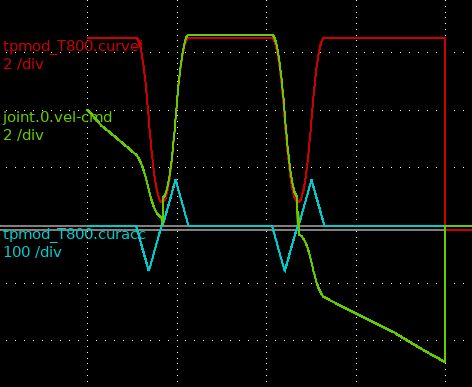
velocity end=0
velocity end=1, here you see a vel-cmd jump.
The following user(s) said Thank You: akb1212
Please Log in or Create an account to join the conversation.
- Joco
- Offline
- Platinum Member
-
Less
More
- Posts: 532
- Thank you received: 327
2 years 11 months ago #285758
by Joco
Replied by Joco on topic Debian 12 - 2.9.1 image for the Raspberry Pi 4b/400
Interesting graphs with the velocity commands diverging. Do we know why that is happening?
Please Log in or Create an account to join the conversation.
Time to create page: 7.707 seconds