
- Posts: 2419
- Thank you received: 2349
Trajectory Planner using Ruckig Lib
- Grotius
- Offline
- Platinum Member
-

Less
More
2 years 5 months ago #301773
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
@RDA,
Volunteers can choose what they like. If you build one you like, you can use it with c++ under the hood.
I think you won't regret your effort. It's quite responsive.
@Grijalvap,
I have no idea what gui we should build. It's up to the designer, the one with the initiave to create something.
The c++ axis gui i build, is like a ugly copy of the axis gui.
For my personnaly i like to see a copycat gui of a excisting machine brand.
I have to be going on with the planner work. So designing and design's for gui's, windows, etc
has to be outsourced to volunteers.
Take some inspiration and build what you like. I will take care that c++ will work under the hood.
This c++ work is quite straighforward as we have nml command interface where almost all things can be done
to run the cnc.
Please use qt designer. A empty c++ project and start building the gui, sub windows etc.
For the opencascade gremlin viewer, add a frame.
For the gcode, also add a frame. So everything that is special will need a frame.
A offline fillet test, while program is running. Haha.
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 5 months ago - 2 years 5 months ago #301777
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
@Andrew,
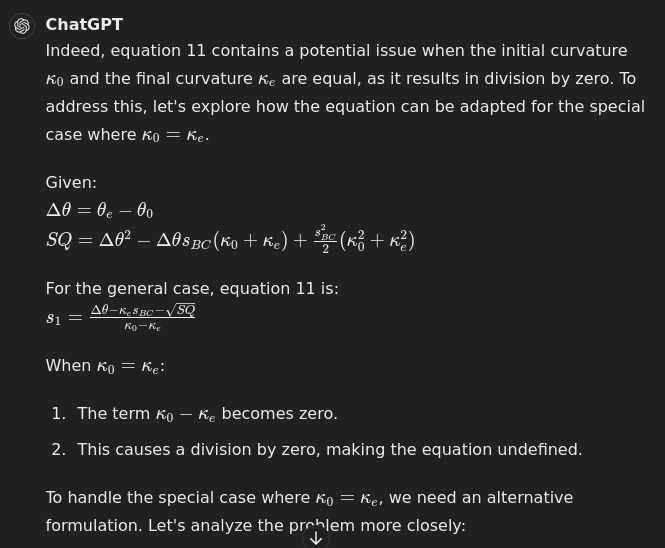
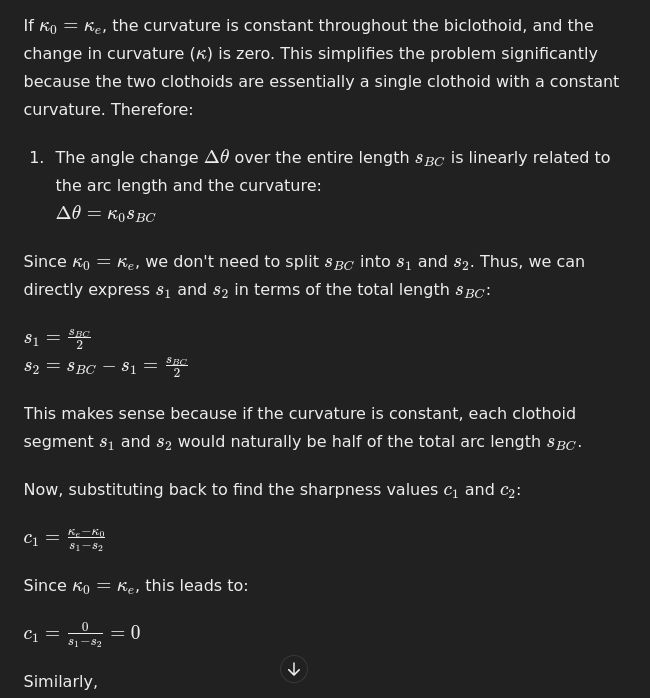
Equation 11 has k0 - ke as the denominator, so when the curvature of the shapes you're trying to join are equal, the equation breaks down
if Ke-Ko=0 then result s1=0. But you know that yourself too.
I really have to dive in that to say something usefull.
Deep respect you are doing and have achieved so far.
I see equatation 9 is interesting related to Ko & Ke.
I was planning to test your scurve algo tomorrow.
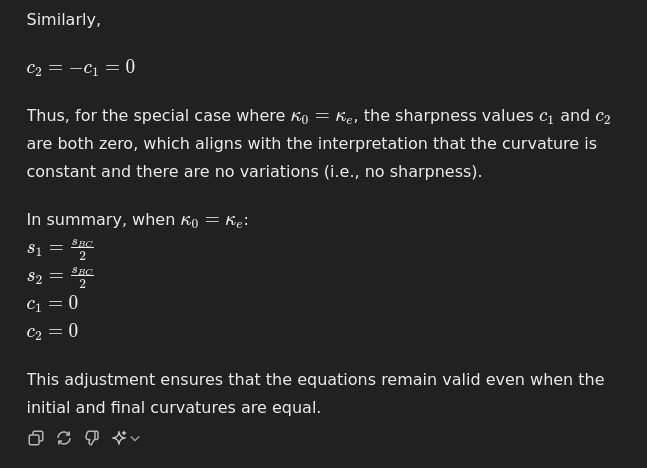
Here is some chatgpt info about your issue, i just copy paste a piece of the science paper into chatgpt.
Equation 11 has k0 - ke as the denominator, so when the curvature of the shapes you're trying to join are equal, the equation breaks down
if Ke-Ko=0 then result s1=0. But you know that yourself too.
I really have to dive in that to say something usefull.
Deep respect you are doing and have achieved so far.
I see equatation 9 is interesting related to Ko & Ke.
I was planning to test your scurve algo tomorrow.
Here is some chatgpt info about your issue, i just copy paste a piece of the science paper into chatgpt.
Last edit: 2 years 5 months ago by Grotius.
The following user(s) said Thank You: akb1212
Please Log in or Create an account to join the conversation.
- andrew2085
- Offline
- Junior Member
-

Less
More
- Posts: 28
- Thank you received: 42
2 years 5 months ago #301780
by andrew2085
Replied by andrew2085 on topic Trajectory Planner using Ruckig Lib
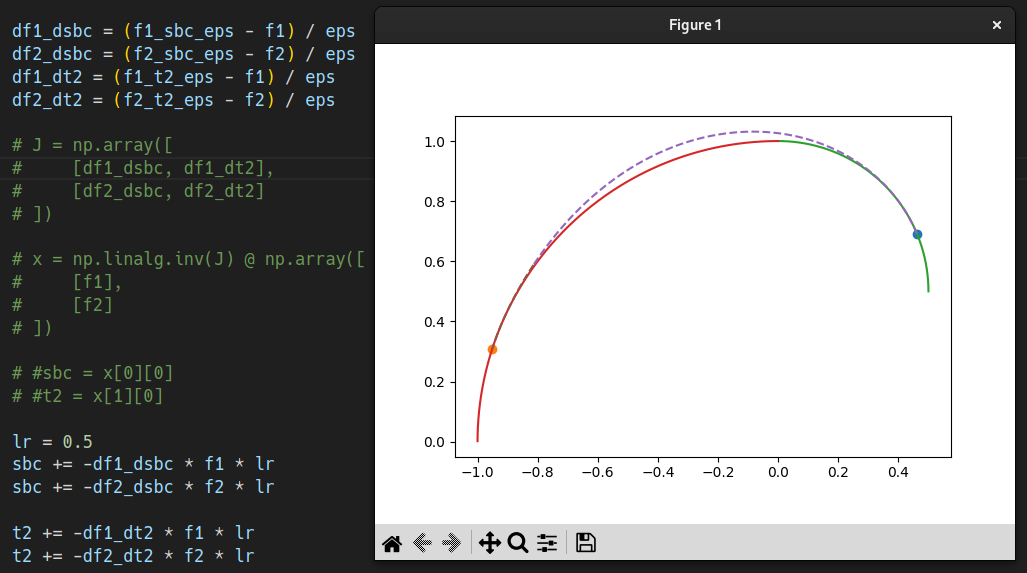
When I replace the Jacobian matrix stuff with this, it converges very slowly. I have no idea why yet.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- andrew2085
- Offline
- Junior Member
-
Less
More
- Posts: 28
- Thank you received: 42
2 years 5 months ago - 2 years 5 months ago #301783
by andrew2085
Replied by andrew2085 on topic Trajectory Planner using Ruckig Lib
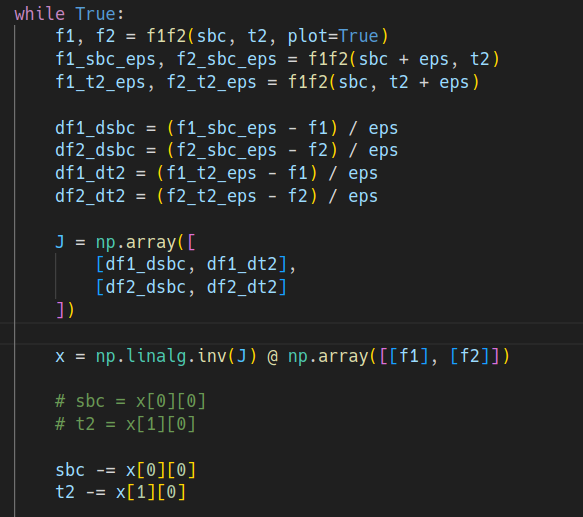
Well I figured it out. It now converges in about 6 iterations. Maybe I just don't understand the notation from the paper, but that sure as hell doesn't look like its decrementing sBC and t2, it looks like its assigning. It was just a wild ass guess, but it was correct.
Changing from assignment to decrement:
From the paper:
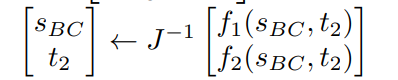
Edit:
I asked ChatGPT: mathb.in/78746
I guess subtracting from the existing values is implied because that's whats normally done when doing this kind of operation with an inverse Jacobian.
Changing from assignment to decrement:
From the paper:
Edit:
I asked ChatGPT: mathb.in/78746
I guess subtracting from the existing values is implied because that's whats normally done when doing this kind of operation with an inverse Jacobian.
Last edit: 2 years 5 months ago by andrew2085.
The following user(s) said Thank You: tommylight, Grotius, spumco
Please Log in or Create an account to join the conversation.
- automata
- Offline
- Premium Member
-

Less
More
- Posts: 105
- Thank you received: 93
2 years 5 months ago #301848
by automata
Replied by automata on topic Trajectory Planner using Ruckig Lib
@Grotius and @Andrew2085
Awesome work.
Some of the parameters used by Delta controllers for high speed machining can be found in the NC300 manual.
deltronics.ru/images/manual/CNC_Milling-...M_MM_EN_20210630.pdf
Parameters for path modification / blending Page 12-5, 12-6 (pg 306): Param 329, 330, 331, 332, 333
Parameters for feedrate modification Page 12-4 (pg 305): Param 309, 311, 319, 320, 321, 322
This may point the way.
Regards,
automata
The following user(s) said Thank You: tivoi, Grotius
Please Log in or Create an account to join the conversation.
- andrew2085
- Offline
- Junior Member
-
Less
More
- Posts: 28
- Thank you received: 42
2 years 5 months ago - 2 years 5 months ago #301850
by andrew2085
Replied by andrew2085 on topic Trajectory Planner using Ruckig Lib
I'm going to convert the bi-clothoid stuff I've tested so far into C++. I tested using Gaussian quadrature in Python to numerically integrate the clothoid. It's seems unreasonably fast and unreasonably accurate to the point that it seems like magic. Evaluating the derivative at only 5 points is giving an integral with an error of around 1e-11 to 1e-17.
Edit:
Here is the start of it: github.com/a-downing/clothoid
Edit:
Here is the start of it: github.com/a-downing/clothoid
Last edit: 2 years 5 months ago by andrew2085.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
Time to create page: 1.925 seconds