
- Posts: 224
- Thank you received: 115
Trajectory Planner using Ruckig Lib
- Becksvill
- Offline
- Elite Member
-

Less
More
2 years 4 months ago #303514
by Becksvill
Replied by Becksvill on topic Trajectory Planner using Ruckig Lib
We Are about to do a big aluminium 4axis carving and the current trajectory generator swaps to no look ahead when it combines 4axis motion with 3axis motion I think. Which is a problem
I think tormach has fixed that.
Does anyone know what the current limit is and can it be fixed easy?
Just been looking at the wonderful work Grotius is doing and wondering if this is possible to fix atb the same time..
Regards
Andrew
I think tormach has fixed that.
Does anyone know what the current limit is and can it be fixed easy?
Just been looking at the wonderful work Grotius is doing and wondering if this is possible to fix atb the same time..
Regards
Andrew
The following user(s) said Thank You: Lcvette, Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-

Less
More
- Posts: 2419
- Thank you received: 2349
2 years 4 months ago #303547
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
Hi Becksvill,
I know someone else who hass the same problem with a huge 3d printer in Italy. He was asking me the same thing.
So in the current tp from Rob Ellenberg we have to change logic to enable this 4 axis look ahead?
I know someone else who hass the same problem with a huge 3d printer in Italy. He was asking me the same thing.
So in the current tp from Rob Ellenberg we have to change logic to enable this 4 axis look ahead?
The following user(s) said Thank You: Lcvette
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
2 years 4 months ago - 2 years 4 months ago #303548
by Aciera
Replied by Aciera on topic Trajectory Planner using Ruckig Lib
Yes the current trajectory planner in LinuxCNC only does multiline look ahead for Gcode using XYZ words as soon as the interpreter encounters more then those (eg an A word for a rotary axis) it falls back to one line look ahead.
So basically it's missing the ability to blend more then XYZ axes.
[edit]
also applies to 3D printers as a fourth axis is needed for the extruder.
So basically it's missing the ability to blend more then XYZ axes.
[edit]
also applies to 3D printers as a fourth axis is needed for the extruder.
Last edit: 2 years 4 months ago by Aciera.
The following user(s) said Thank You: Lcvette, Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 4 months ago #303551
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
Will have a look at that next week in the original trajectory planner.
Yesterday i did some work at the gui interface.
Today i made a MILLTASK component for halcore that i named "state_machine.so"
This component will do the program logic like start, stop, pause etc. and also handles the jogging & trajectory stuff.
The state_machine.so component is using shared memory to load the gcode data from userspace.
All is done in c++ code.
So for uploading gcode to the hal side, no hal pins are required. It just's sends the data_structure containing the gcode
information to the kernel module. It's using a mutex.
This is showing the cnc app, after loading the gcode drawing, it sends the gcode_data to hal side.
Then in the component itself it prints the ammount of gcode lines as a test : testing if component has gcode lines recieved.
Ok now this framework works and is quite compact.
At the left it prints the ammount of recieved gcode lines. This print is done by the hal component : state_machine.so
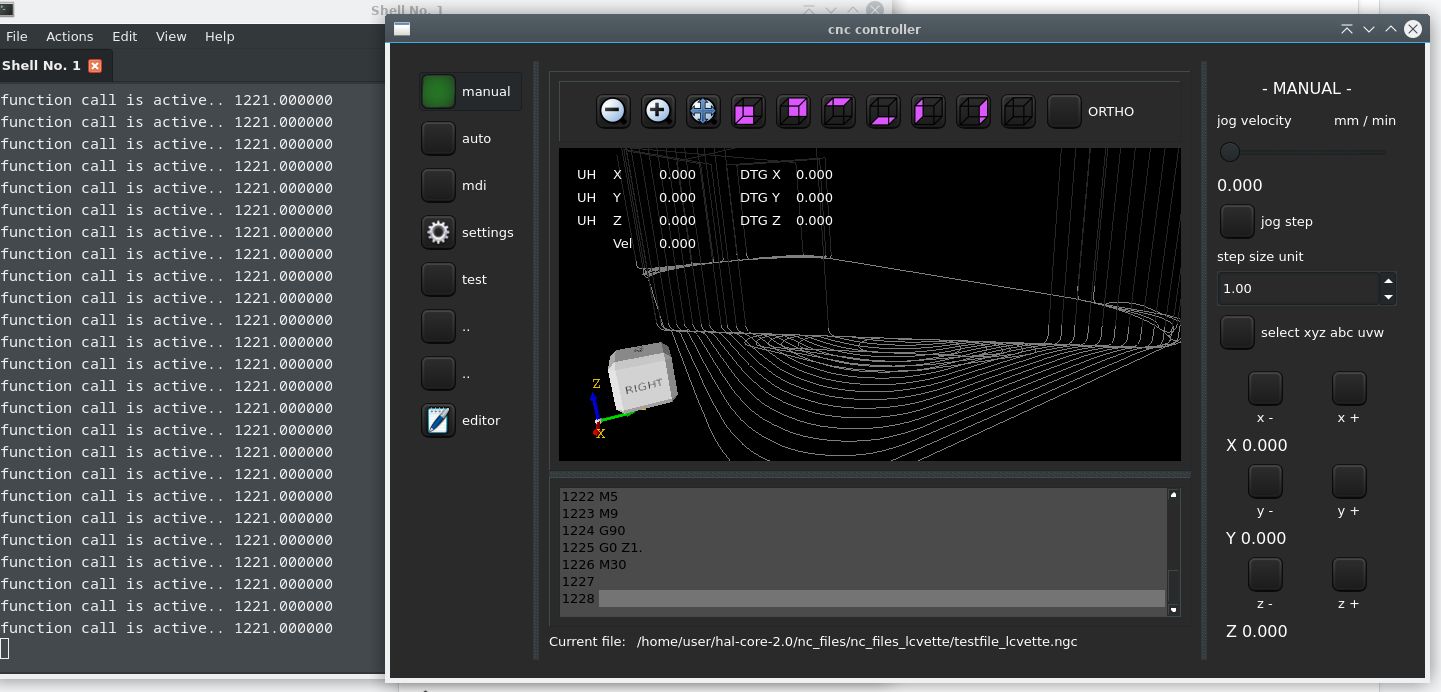
Yesterday i did some work at the gui interface.
Today i made a MILLTASK component for halcore that i named "state_machine.so"
This component will do the program logic like start, stop, pause etc. and also handles the jogging & trajectory stuff.
The state_machine.so component is using shared memory to load the gcode data from userspace.
All is done in c++ code.
So for uploading gcode to the hal side, no hal pins are required. It just's sends the data_structure containing the gcode
information to the kernel module. It's using a mutex.
This is showing the cnc app, after loading the gcode drawing, it sends the gcode_data to hal side.
Then in the component itself it prints the ammount of gcode lines as a test : testing if component has gcode lines recieved.
Ok now this framework works and is quite compact.
At the left it prints the ammount of recieved gcode lines. This print is done by the hal component : state_machine.so
The following user(s) said Thank You: tommylight, Clive S, Lcvette, Aciera, Darium, Unlogic
Please Log in or Create an account to join the conversation.
- Becksvill
- Offline
- Elite Member
-
Less
More
- Posts: 224
- Thank you received: 115
2 years 4 months ago #303606
by Becksvill
Replied by Becksvill on topic Trajectory Planner using Ruckig Lib
Thanks Grotius
Yes the multi axis stuff is where it would be great to have a decent lookahead
And we would really appreciate it
Yes the multi axis stuff is where it would be great to have a decent lookahead
And we would really appreciate it
The following user(s) said Thank You: Lcvette
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 4 months ago #303741
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
Hi,
If i run this in a 9 axis config, it blends the corner, and therm condition=2. Wich means TC_TERM_COND_PARABOLIC.
It has a 4th axis a.
Maybe i need a sample file where the motion stops each segment.
If i run this in a 9 axis config, it blends the corner, and therm condition=2. Wich means TC_TERM_COND_PARABOLIC.
It has a 4th axis a.
Warning: Spoiler!
Code:
G21 G90 G40
G64 P10.0
G17
S1 F12000
M3
G0 x0 y0 z0 a0
G1 x100 y0 z1 a100
G1 x100 y100 z0 a110
G1 x100 y0 z1 a120
G1 x0 a0
M5
m30
Maybe i need a sample file where the motion stops each segment.
The following user(s) said Thank You: Lcvette, wellingtoncsouza
Please Log in or Create an account to join the conversation.
Time to create page: 1.705 seconds