
- Posts: 4
- Thank you received: 3
scurve trajectory planner
- Evgen
- Offline
- New Member
-

Less
More
1 year 7 months ago - 1 year 7 months ago #324947
by Evgen
Replied by Evgen on topic scurve trajectory planner
I tested it. The problem is solved. I'll corect my post for automatical addition right P value, but it's interesting task, how calculate it.
And another question. How can I make deb package with new planner?
And another question. How can I make deb package with new planner?
Last edit: 1 year 7 months ago by Evgen.
The following user(s) said Thank You: Aciera
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-

Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago - 1 year 7 months ago #325000
by Grotius
Replied by Grotius on topic scurve trajectory planner
@HalaszAttila,
Mabye just give it a try on a LinuxCNC v2.8.4 version.
The repository has info how to install, patch.
Maybe others can help to setup a vm and test it for you, as my vm is broken at the moment.
@Evgen,
That is not possible unless you edit the source in the ~/debian dir.
For shipping software, you can considering using ~/opt/linuxcnc as the installation dir for a .deb package.
Creating a .deb package from linuxcnc that installs in ~/opt/linuxcnc dir is clean way to go.
Last edit: 1 year 7 months ago by Grotius.
The following user(s) said Thank You: HalaszAttila
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago #325064
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi all,
Today a new feature is added to the planner.
Jog in pause state.
It captures keyboard buttons for xyz axis in pause state.
This feature should work for every used linuxcnc gui, axis, gmocappy, qtvcp, etc. The whole mickmack.
When resuming the motion, the xy is running back to pause-pos, then the z is running back to pause-pos.
Next feature is tangential knife.
Will do that next time.
The following user(s) said Thank You: akb1212, tommylight, Clive S, HalaszAttila, pommen, yrsiddhapura, FabianB
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
1 year 7 months ago #325069
by Aciera
This is a cool feature but IMO the use of keyboard keys for jogging is rather unfortunate. There have been several calls to move away from keyboard jogging. Why not use one of the existing hal pins like 'halui.axis.L.minus', 'halui.axis.L.plus' or better yet create dedicated hal pins for jogging while paused.
Replied by Aciera on topic scurve trajectory planner
It captures keyboard buttons for xyz axis in pause state.
This is a cool feature but IMO the use of keyboard keys for jogging is rather unfortunate. There have been several calls to move away from keyboard jogging. Why not use one of the existing hal pins like 'halui.axis.L.minus', 'halui.axis.L.plus' or better yet create dedicated hal pins for jogging while paused.
The following user(s) said Thank You: skunkworks, HalaszAttila, Grotius
Please Log in or Create an account to join the conversation.
- skunkworks
- Offline
- Moderator
-

Less
More
- Posts: 351
- Thank you received: 153
1 year 7 months ago #325076
by skunkworks
Replied by skunkworks on topic scurve trajectory planner
This is awesome!! Great work to everyone involved.
I agree with Aciera - keyboard jogging is way at the bottom of the list. I have many large machines that are never jogged by the keyboard.
sam
I agree with Aciera - keyboard jogging is way at the bottom of the list. I have many large machines that are never jogged by the keyboard.
sam
The following user(s) said Thank You: HalaszAttila, Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago #325089
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi Guys,
Thanks for feedback.
Now we added hal pins for jogging xyz in pause state.
The halui pins are unreachable from within the tpmod component.
Then tpmod has it's own hal pins for jog in pause.
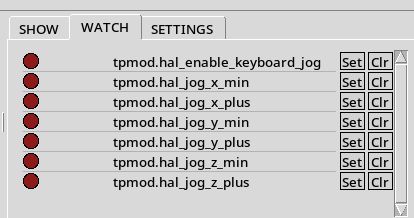
For the one's who still want to do keyboard jogging in pause state, like plasma cnc's :
Thanks for feedback.
Now we added hal pins for jogging xyz in pause state.
The halui pins are unreachable from within the tpmod component.
Then tpmod has it's own hal pins for jog in pause.
For the one's who still want to do keyboard jogging in pause state, like plasma cnc's :
- enable the jog keyboard hal pin.
The following user(s) said Thank You: robh, HalaszAttila, wellingtoncsouza, Darium
Please Log in or Create an account to join the conversation.
Time to create page: 0.547 seconds