
- Posts: 2419
- Thank you received: 2349
scurve trajectory planner
- Grotius
- Offline
- Platinum Member
-

Less
More
1 year 7 months ago #325108
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi all,
Today we added another feature to the scurve planner : tangential knife
The planner outputs a hal float value in degrees.
This rotational value can be used by tangential knife machines to direct the knife in
the vector direction of the trajectory.
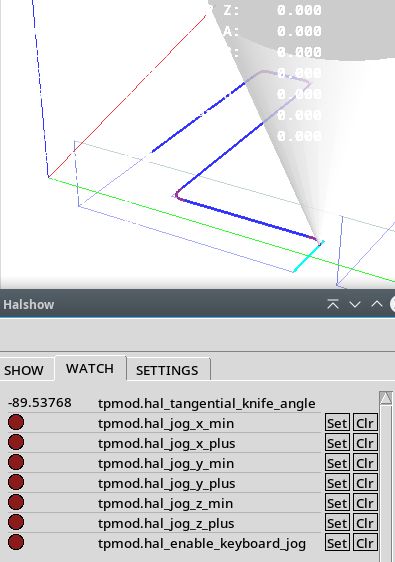
Today we added another feature to the scurve planner : tangential knife
The planner outputs a hal float value in degrees.
This rotational value can be used by tangential knife machines to direct the knife in
the vector direction of the trajectory.
The following user(s) said Thank You: akb1212, Clive S, HalaszAttila, wellingtoncsouza, DauntlessA, Rookie0
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
1 year 7 months ago #325166
by Aciera
Replied by Aciera on topic scurve trajectory planner
I did a quick test on my non-rt installation running 'cmake/nc_files/fillet/square_100x100_P5.ngc'.
1. it seems that inital deceleration and final acceleration along the fillet do not respect max_acceleration settings (50 for x in my case)
2. there seem to be acceleration spikes while traversing the fillet
Below is the captured accelerations for X and Y for the first corner of the rectangle:
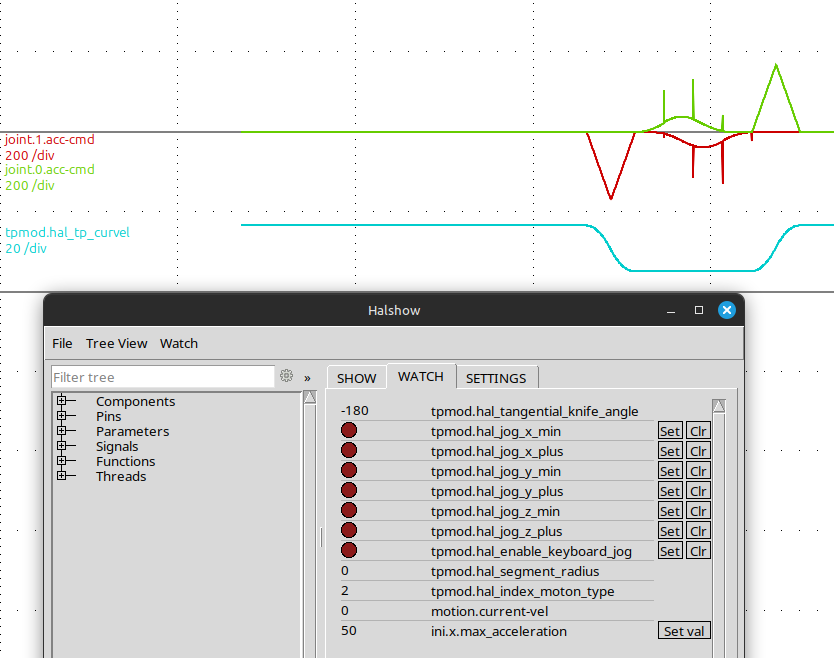
1. it seems that inital deceleration and final acceleration along the fillet do not respect max_acceleration settings (50 for x in my case)
2. there seem to be acceleration spikes while traversing the fillet
Below is the captured accelerations for X and Y for the first corner of the rectangle:
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago - 1 year 7 months ago #325176
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi Arciera,
Thanks for feedback.
If the acc in the ini file is 50, the scurve is max 2*50=100 at inflection point. This is normal.
However. I run the same file, and i got no spikes.
This is the first corner :
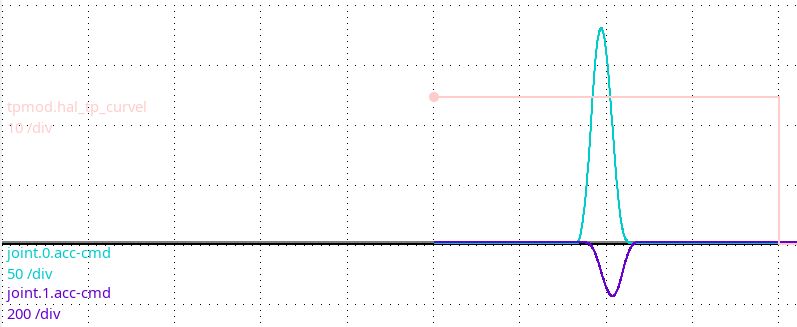
Maybe you did not update the clothoid lib? U used clone recursive wich is needed.
Or git is messed up.
For sure i just did a push for scurve planner, clothoid lib, scurve as up to date.
That's annoying when you have 3 repository's depending on each other.
Thanks for feedback.
If the acc in the ini file is 50, the scurve is max 2*50=100 at inflection point. This is normal.
However. I run the same file, and i got no spikes.
This is the first corner :
Maybe you did not update the clothoid lib? U used clone recursive wich is needed.
Or git is messed up.
For sure i just did a push for scurve planner, clothoid lib, scurve as up to date.
That's annoying when you have 3 repository's depending on each other.
Last edit: 1 year 7 months ago by Grotius.
The following user(s) said Thank You: Aciera
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
1 year 7 months ago - 1 year 7 months ago #325177
by Aciera
But the acc-cmd value reaches ~180?
[edit]
I did do a 'git pull' and reran './installer' but I can check again tomorrow.
Replied by Aciera on topic scurve trajectory planner
If the acc in the ini file is 50, the scurve is max 2*50=100 at inflection point. This is normal.
But the acc-cmd value reaches ~180?
[edit]
I did do a 'git pull' and reran './installer' but I can check again tomorrow.
Last edit: 1 year 7 months ago by Aciera.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago #325178
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi Arciera,
The scurve planner takes the [TRAJ] trajectory acceleration : MAX_LINEAR_ACCELERATION = 200
When tpAddLine, tpAddCircle is done, it gives this 200 value to the planner.
The scurve acceleration max is then 2*200=400 at inflection point.
However the planner does not lower the acceleration to a specifik max joint acceleration at the moment.
We have acces to all joint max acceleration values.
We could reduce max acceleration to satisfy max joint acc. We implement this without any problems.
The following user(s) said Thank You: tommylight, Aciera
Please Log in or Create an account to join the conversation.
- eneias_eringer
- Offline
- Junior Member
-

Less
More
- Posts: 24
- Thank you received: 4
1 year 7 months ago #325196
by eneias_eringer
Replied by eneias_eringer on topic scurve trajectory planner
Congratulations on the development!!!!!
I was able to test using the files, in version 2.10..
I have a machine here with ethercat and I can get 30mxmin, I would like to put it on it to test...
I tried to copy only the .so file in the modules folder, but I'm sure that this is not the correct way...
How do I make it work in version 2.94 normally???
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
Time to create page: 0.515 seconds