
- Posts: 2419
- Thank you received: 2349
Beckhoff ethercat 64 with bit linuxcnc, How to install.
- Grotius
- Offline
- Platinum Member
-

Less
More
7 years 9 months ago #124610
by Grotius
Replied by Grotius on topic Beckhoff ethercat 64 with bit linuxcnc, How to install.
Hi Rod,
I mentioned your manual is different then the 40i and 60i manual.
The interfacing of the power button is different at the 120 amp's inverter.
The 40i/60i has a power button based on a kind of rotary encoder, pulse type.
It was not easy, but it's now done. I soldered a 3-wire cable on the print.
I wrote a software component called POWER.comp that does the work for adjustment very nice.
The beckhoff EL2794 is a 4 channel solid state relais. This one uses 2 relais to adjust the power.
I had to write the EL2794 driver also. For reader's don't buy the EL7041 without the -1000 extension. So order only
EL7041-1000. The EL7041 works on the EL7041-1000 driver, but is about 30% slower trough the slower in motor output speed
using the slower internal encoder.
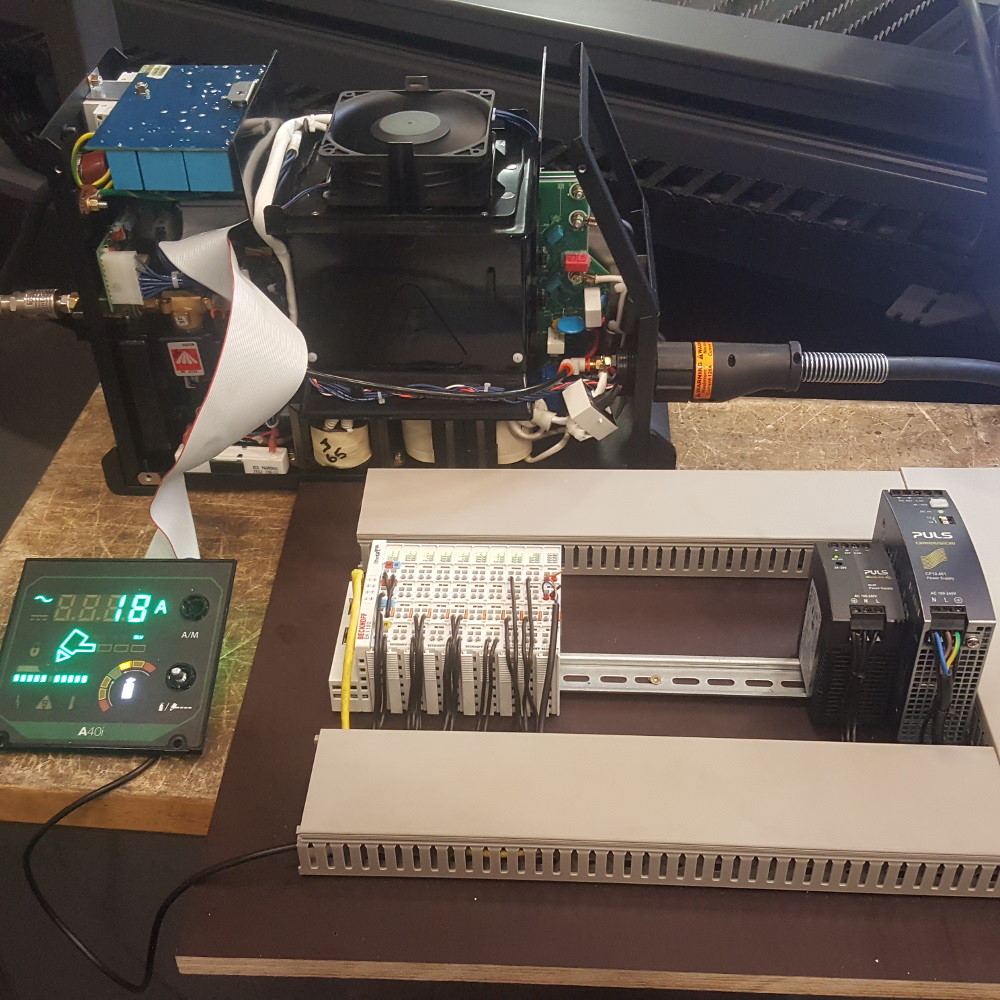
Now i am going to look, to adapt the kerf width offset into variable g-code, for G41/42 procedure's. When that is done,
The environment is almost independent of cam.
I mentioned your manual is different then the 40i and 60i manual.
The interfacing of the power button is different at the 120 amp's inverter.
The 40i/60i has a power button based on a kind of rotary encoder, pulse type.
It was not easy, but it's now done. I soldered a 3-wire cable on the print.
I wrote a software component called POWER.comp that does the work for adjustment very nice.
The beckhoff EL2794 is a 4 channel solid state relais. This one uses 2 relais to adjust the power.
I had to write the EL2794 driver also. For reader's don't buy the EL7041 without the -1000 extension. So order only
EL7041-1000. The EL7041 works on the EL7041-1000 driver, but is about 30% slower trough the slower in motor output speed
using the slower internal encoder.
Now i am going to look, to adapt the kerf width offset into variable g-code, for G41/42 procedure's. When that is done,
The environment is almost independent of cam.
Please Log in or Create an account to join the conversation.
- rodw
- Offline
- Platinum Member
-
Less
More
- Posts: 12170
- Thank you received: 4153
7 years 9 months ago #124632
by rodw
Replied by rodw on topic Beckhoff ethercat 64 with bit linuxcnc, How to install.
Very nice work. Ethercat certainly makes for a very neat installation. Are you going to run steppers or servos from the step and direction outputs? Will you add more IO modules for your limit and home switches etc?
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
7 years 9 months ago - 7 years 9 months ago #125093
by Grotius
Replied by Grotius on topic Beckhoff ethercat 64 with bit linuxcnc, How to install.
Hi Rod my friend,
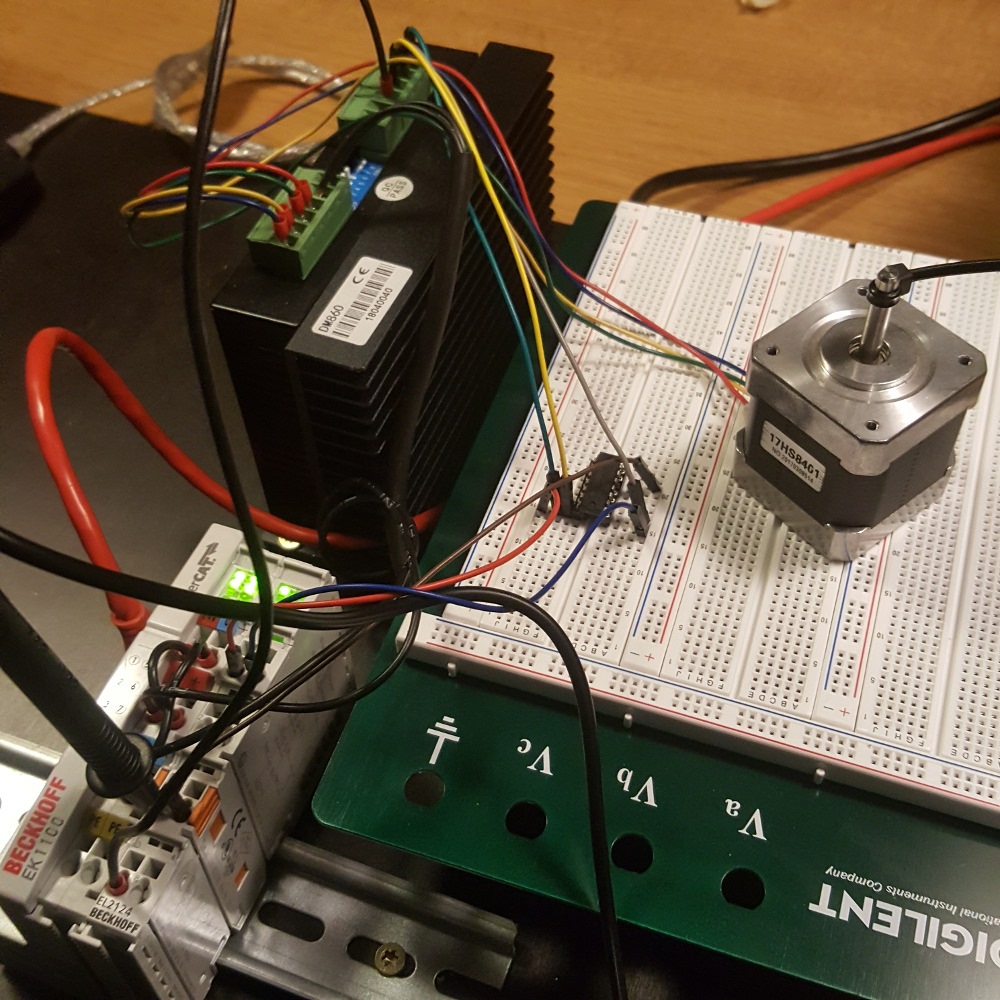
Today i made some Ethercat progress, but at the beginning i made first a smoke curtain at my factory and blown a EL2124 and a secondairy chip away on a 24 vdc circuit. Cheise. So at home i had a second EL2124... To try with. It's a small stepper at the picture to test with. It stay's alive at 2 amps.
The Beckhoff stepper drives are 50v 5amp's. This was to less power to drive my gantry portal x axis motor's after testing.
So Houston i have a problem.
I was looking for a solution. Watching youtube about the transistor. And i ordered a chip that works like a transistor.
Minimum order was 30 chips, so it was a bit risky to order if the test would fail. I also ordered a breadboard.
But finally it succeeded after tuning the Ethercat software side. Now i can drive my machine with 80 volts 8 amps on Ethercat. Also the price is reduced from Euro 250 a drive to Euro 50 a drive. I now use a EL2124 to guide 4 stepgen signals ( 4 motor pulse train's )
I will test this config on the machine coming day's. I hope it's good on a real machine. This test set up, run's like a servo.
I mentioned ethercat has no reset, parport has. But after all, that's no problem.
Will you add more IO modules for your limit and home switches etc?
Yes, yes...
I add multi i/o. THC analog in is working, I add a gas valve for plasma marking. Argon / Air valve. + Argon preflow function.
So soon we are the marking masters at 10 amp's argon.
I have good news, one of my customer's bought a second machine. It has Grotius LInux on it. He was cutting 30 hours first week on his new 64 bit linux machine. He want's to get rid of window's on his first cutting machine.
Reason is, he can't do active THC on 2 oxy fuel torches while cutting. So z + a axis floating head's looks impossible on window's.
In linux this is peanut's
Today i made some Ethercat progress, but at the beginning i made first a smoke curtain at my factory and blown a EL2124 and a secondairy chip away on a 24 vdc circuit. Cheise. So at home i had a second EL2124... To try with. It's a small stepper at the picture to test with. It stay's alive at 2 amps.
The Beckhoff stepper drives are 50v 5amp's. This was to less power to drive my gantry portal x axis motor's after testing.
So Houston i have a problem.
I was looking for a solution. Watching youtube about the transistor. And i ordered a chip that works like a transistor.
Minimum order was 30 chips, so it was a bit risky to order if the test would fail. I also ordered a breadboard.
But finally it succeeded after tuning the Ethercat software side. Now i can drive my machine with 80 volts 8 amps on Ethercat. Also the price is reduced from Euro 250 a drive to Euro 50 a drive. I now use a EL2124 to guide 4 stepgen signals ( 4 motor pulse train's )
I will test this config on the machine coming day's. I hope it's good on a real machine. This test set up, run's like a servo.
I mentioned ethercat has no reset, parport has. But after all, that's no problem.
Will you add more IO modules for your limit and home switches etc?
Yes, yes...
I add multi i/o. THC analog in is working, I add a gas valve for plasma marking. Argon / Air valve. + Argon preflow function.
So soon we are the marking masters at 10 amp's argon.
I have good news, one of my customer's bought a second machine. It has Grotius LInux on it. He was cutting 30 hours first week on his new 64 bit linux machine. He want's to get rid of window's on his first cutting machine.
Reason is, he can't do active THC on 2 oxy fuel torches while cutting. So z + a axis floating head's looks impossible on window's.
In linux this is peanut's
Last edit: 7 years 9 months ago by Grotius.
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
7 years 9 months ago - 7 years 9 months ago #125323
by Grotius
Replied by Grotius on topic Beckhoff ethercat 64 with bit linuxcnc, How to install.
I must add a correction reply.
The EL2124 can directly work on stepper drives like DM860.
I inverted the signal with ic. This works, but was not my problem.
I trapped my self in a software pre configure issue. Glad it works now without ic.
The pulse speed of the EL2124 is : typ. TON: < 1 µs, typ. TOFF: < 1 µs, so pulse timer looks quite quick. Ethercat is fastest protocol i read somewhere.
Solution is to make Ethercat read and write in base thread in stead of servo thread, in my case the timer is now 15000 in stead of 1000000. Machine speed's over 20 m/min with steppers. I stopped stable testing at 21 m/min.
Now beckhoff is coming to my factory to show some servo drives. I hope this will bring some luck. In the past i worked with Lenze
servo drives. So i am curious about their advise.
Keep up the good work !! And remember : if you do nothing, nothing will happen. :laugh:
Last edit: 7 years 9 months ago by Grotius.
Please Log in or Create an account to join the conversation.
- shameless
- Offline
- Junior Member
-

Less
More
- Posts: 27
- Thank you received: 3
7 years 8 months ago #127091
by shameless
Replied by shameless on topic Beckhoff ethercat 64 with bit linuxcnc, How to install.
I like it when I first see it: If you do nothing, nothing will happen. But I am stuck in how to use HAL to make the motor run.

But I am stuck in how to use HAL to make the motor run. Please Log in or Create an account to join the conversation.
- shameless
- Offline
- Junior Member
-
Less
More
- Posts: 27
- Thank you received: 3
7 years 7 months ago #129324
by shameless
Replied by shameless on topic Beckhoff ethercat 64 with bit linuxcnc, How to install.
Hi
I have a slave, IO module, which is not a beckhoff, but including DI,DO&AI, and I have done all the modifications to the .h&.c, until I finish all the steps. I start the Linuxcnc, the ethercat didn't change to OP, when I scan slaves, there shows a "E",indicating that there's a scan or configuration fault. So I just wanna know Is there any approached to locate the configuration error, so I can fix it.
Best regards!
Please Log in or Create an account to join the conversation.
Time to create page: 0.395 seconds