Advanced Search

Search Results (Searched for: stepper spindle)

  • Hakan
  • Hakan
24 Nov 2025 07:24 - 24 Nov 2025 07:52
Replied by Hakan on topic an CIA402 Stepper/Servo as Spindle

an CIA402 Stepper/Servo as Spindle

Category: EtherCAT

Yes, that's what I have in the example.

It might work with the cia402pv instead of the standard cia402 also in csp mode.
But I'm not sure, the goal with that component was to add PV, and I may have
broken csp. Not that I meant to, but I didn't check thoroughly.
Also the pv-mode=true and csp-mode=true doesn't work well together,
there should really be a new logic like op-mode=3 (for csp-mode)
  • Red_D85
  • Red_D85
24 Nov 2025 05:48
Replied by Red_D85 on topic an CIA402 Stepper/Servo as Spindle

an CIA402 Stepper/Servo as Spindle

Category: EtherCAT

Hello Hakan

can i had 2 instances Cia402

Cia402dBraun for xyz and cia402pv for spindle? did you know that?
  • aDm1N
  • aDm1N's Avatar
21 Nov 2025 14:57

EtherCAT + CiA402 Servo: OP state reached, but axis won’t move (only Following E

Category: General LinuxCNC Questions

That worked well. Currently, I'm just testing that the electronics are working; the hardware isn't connected yet, so scaling isn't realistic. What is working is the C-axis and the M commands for spindle movement. The stepper motors are also moving as they should. There are still problems with the M19 command (the servo might be trying to reach a position too quickly, which isn't possible). I'm also checking that the C-axis is working reliably. Currently, there are still problems switching from M3 to S500 for a short time after the C-axis. The servo goes into overload because it seems to be trying to reach a position too quickly, which isn't possible.
  • Hakan
  • Hakan
20 Nov 2025 11:00
Replied by Hakan on topic an CIA402 Stepper/Servo as Spindle

an CIA402 Stepper/Servo as Spindle

Category: EtherCAT

Yes there is an example. Two normal stepper drives and one stepper motor spindle.
In the example directory.
 
  • Red_D85
  • Red_D85
20 Nov 2025 10:59
Replied by Red_D85 on topic an CIA402 Stepper/Servo as Spindle

an CIA402 Stepper/Servo as Spindle

Category: EtherCAT

Hi Hakan
thank you
What should the whole thing look like in the hall and ini? is there an sample?
 
  • Hakan
  • Hakan
20 Nov 2025 10:48
Replied by Hakan on topic an CIA402 Stepper/Servo as Spindle

an CIA402 Stepper/Servo as Spindle

Category: EtherCAT

You can use this component instead of the standard cia402 component.
github.com/MetalMusings/cia402pv
The drive uses PV (Profile Velocity) mode which is more suitable
for a spindle motor as it has its own speed ramp up and down.
 
  • Red_D85
  • Red_D85
20 Nov 2025 07:02
an CIA402 Stepper/Servo as Spindle was created by Red_D85

an CIA402 Stepper/Servo as Spindle

Category: EtherCAT

Hallo at all

how can i get an CIA 402 Ethercat stepper work as spindle? I had 3axes (X Y Z) that works. Anybody can help?

Greetings
  • Hakan
  • Hakan
20 Nov 2025 02:17

EtherCAT + CiA402 Servo: OP state reached, but axis won’t move (only Following E

Category: General LinuxCNC Questions

Okay, so one drive is for a spindle?
I made an adaptation to the cia402 component for the driver to work in PV (Profile velocity) mode
which is better suited to run as spindle.
Check out here github.com/MetalMusings/cia402pv
This person made it work after a while forum.linuxcnc.org/38-general-linuxcnc-q...tor-as-spindle-motor
 
  • aDm1N
  • aDm1N's Avatar
19 Nov 2025 23:50

EtherCAT + CiA402 Servo: OP state reached, but axis won’t move (only Following E

Category: General LinuxCNC Questions

The reference to the forum post was helpful. I now have the basic framework up and running. The servo, which is supposed to act as a spindle, is working to the point that it can be controlled with M commands, and the stepper driver (one driver for two closed-loop steppers) is also working. I've attached the files. More to come.

de.aliexpress.com/item/1005008271228331....gatewayAdapt=glo2deu

de.aliexpress.com/item/1005010098887410....gatewayAdapt=glo2deu

 
  • dgdodo
  • dgdodo
18 Nov 2025 19:18
Replied by dgdodo on topic [SOLVED] Backlash issues on Y-AXIS

[SOLVED] Backlash issues on Y-AXIS

Category: Advanced Configuration

Thanks for all info so far.
I decided to change the Y-axis also with a M4-(screw) spindle drive (not M3 as I said before), as I did on the X-axis.
Had the (almost) same stepper-motor around, although after testing it needed 2 times more Volt to be powerful enough.
Now it all looks much better!
The old gear setup was too much worn out, I believe. And 2 (plastic) gears before driving the arm had 1.3 mm backlash is also kinda 'too much'.

PS. I thought I tried the write action at last position in the .hal file (base-thread), but was forgotten to change the .ini file accordingly.
It does run fine now and I am not (willing) able to build back the old situation to test this again, sorry for that.

And yes, I will cleanup my configuration files after this change, the X- and Y-axis are now the same.

Regards, DG.
 
  • Muftijaja
  • Muftijaja
18 Nov 2025 15:48

problems with Y-Axis, elliptic deviations after several changes -Probe Basic V.5

Category: QtPyVCP

Hello community!
I have a Mesa 7i76e running, the wiring is correct except for the alarm loop. Using a Lenovo ThinkCentre M910q with i7 4-core, 256/GB NVMe SSD, i7 16GB RAM WLAN Intel Core i7-6700T 4x 2.80 - 3.60GHz with Linuxcnc 2.9.4, Probe Basic V.5 on Debian 12. No latency problems.

Once again, I'm here with a big problem. My DIY milling machine (1000x500x220 with aluminum profile frame, 20mm HGR, 1605 ball screws, 3 axes, 2x OMC Stpperonline 400W integrated servo, 1x JMC CL Stepper 3.5Nm, set 2000 steps/rev) is now mechanically finally assembled. I also got a lot of help from this forum in setting up LinuxCNC, eliminating latency problems and spindle control problems, but now I have a milling problem that I can't solve.

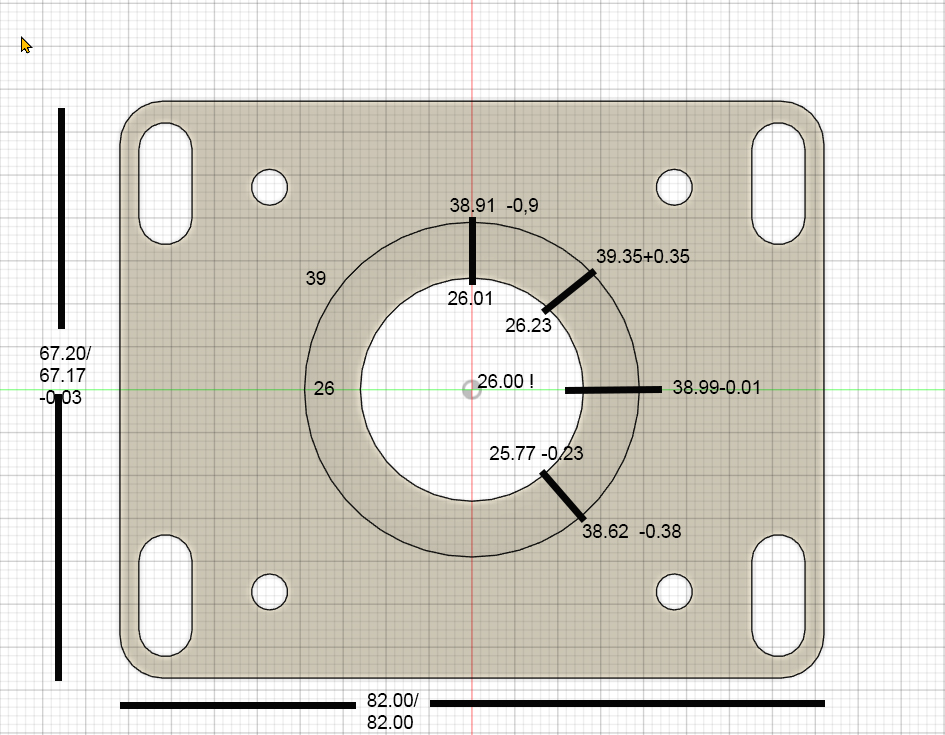
I have milled several test parts with drill holes, 2 circular pockets, and a rectangular outer contour, and have noticed that my circular pockets are becoming elliptical. The deviations in Y are approximately +0.35 mm at 45° and approximately -0.38 mm at 135°. The X values for the rectangular contour are perfect to within 0.01 mm in X and 0.09 mm in Y, X I consider to be acceptable, but Y is over tolerance. However, the circular movements contain deviations I cannot tolerate. I will show you a photo of the last test piece. After each individual test part, I made changes to rule out certain things.
The first change was to replace a simple Chinese C7 ball screw with a ground C5 spindle with double nuts. This reduced the originally even higher values by almost half. However, the deviations described above remained. After the next test part, I replaced the 400 W servo with a 3.5 Nm JMC CL stepper motor. The results remained almost the same. As a final attempt, a few days ago I replaced the spindle's fixed bearing with a new one, with 7002AC angular contact bearings in an O-arrangement with a 1 mm spacer ring between the outer rings. I inspected the previous fixed bearing and found no faults. There was a 1mm spacer also and the O arrangement was the same.  I had also taken measurements at the spindle end earlier and actually and found no backlash.

Yesterday, moving away from mechanical faults, I noticed a difference in the motor definitions for the X and Y axes in the .ini file. The Ferror and min_Ferror points differed by one decimal place. X was set to 0.1 and 0.01, while the Y axis was set to 1.0 and 0.1. After I corrected this difference, the motor on the Y axis went into alarm mode after a few position changes.

What could be the reason for this? How can it be that one motor runs perfectly with much lower tolerance values, while the other quickly goes into alarm mode with less load? The motor in question has the same power supply and is certainly less demanding in terms of starting currents than the servo on the X-axis. With the higher tolerance values, the Y motor runs without alarm, but has these deviations. Are these tolerance values in the .ini file responsible for these deviations?
The mechanics of the Y and Z axes are flawless, as checked with a dial gauge, and the repeat accuracy is also very good, less than one hundredth. 
Do you have any ideas about this? Where can I look further?
Thanks for your time and hints    


File Attachment:

File Name: Hanno_Nr5_...1-18.hal
File Size:12 KB

File Attachment:

File Name: Hanno_Nr5_...1-18.ini
File Size:6 KB
Displaying 61 - 71 out of 71 results.
Time to create page: 0.650 seconds
Powered by Kunena Forum