Advanced Search

Search Results (Searched for: )

  • Hakan
  • Hakan
13 Oct 2025 09:09

Issue with OP Entry Delay and Failures in LinuxCNC + EtherCAT System

Category: EtherCAT

It was just an "apt upgrade", I am using debian trixie on that computer.
It may not be the kernel for you. It may not have been for me either, I messed around with many things that day.
You can always try an "apt update" followed by "apt upgrade". That should install the latest kernel and many more upgraded apps.

The messages you get is what I got using Realtek network interface.
What network interface do you have? Find out with "lspci"
 
  • tommylight
  • tommylight's Avatar
13 Oct 2025 09:03

Upgrade of CNC Plasma Cutting Table with Mesa 7i96S, THCAD-2 And MyOhmic PRO

Category: Driver Boards

If using a THCAD for ohmic sensing has issues with water. the most likely issue
is that the sense  resistor is too high a value.

I agree and I am pretty sure i mentioned somewhere a long time ago that a lower value resistor should be used for sensing. Something that will result in 20-50mA current should do just fine, maybe more as the water used will get lower resistance the more cuts are done and as it evaporates.
  • GuessWho
  • GuessWho
13 Oct 2025 08:11

Upgrade of CNC Plasma Cutting Table with Mesa 7i96S, THCAD-2 And MyOhmic PRO

Category: Driver Boards

Thanks everyone for the feedback. I’ll keep you posted as things progress.
  • shaying526
  • shaying526
13 Oct 2025 08:04 - 13 Oct 2025 08:09

Issue with OP Entry Delay and Failures in LinuxCNC + EtherCAT System

Category: EtherCAT

Thank you for your response!
I'd like to try your method and hope it can resolve my current issue.
I haven't worked on updating the preempt-rt kernel before.
Are there any tutorial posts you could recommend to me?
Also, where can I download the 6.12-48 version you mentioned?

Current Kernel: Linux debian 6.1.0-23-rt-amd64
  • Hakan
  • Hakan
13 Oct 2025 07:54
Replied by Hakan on topic Servo analog command, PID and El5101

Servo analog command, PID and El5101

Category: EtherCAT

You can also investigate if it is possible to wire the glass scale directly to the servo drive.
The servo drive will then use the glass scale instead of the servo's encoder.
  • laurentl38
  • laurentl38
13 Oct 2025 06:34

increment 4 MPG jog wheels with Basic Probe

Category: QtPyVCP
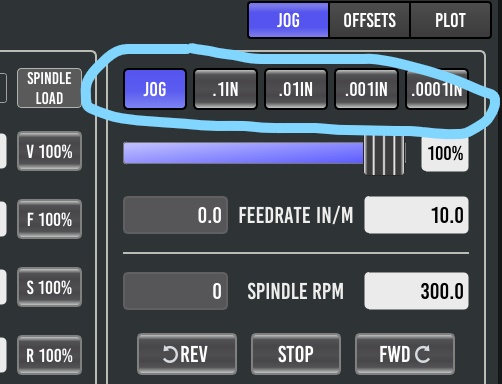
Hello,

I'm using 4 MPG jog wheels. I don't have a physical button to change the increment.
With Axis, there's a HAL pin to get the GUI information about the jog increment.
Now, I'm transferring the configuration to Basic Probe, but I can't find the information about the increment selected in the GUI (pictured).

Is there a simple way to get the information about the increment selected in the GUI?
 

Regards
  • endian
  • endian's Avatar
13 Oct 2025 03:39
Replied by endian on topic Ethercat, EL6751 and CANOpen

Ethercat, EL6751 and CANOpen

Category: EtherCAT

okay ... thats kind weird ..

it should not runs like you described ...

maybe help convert setpoint to bool and there will be signal enable ... or use some general enable to enable spindle.0 too

 
  • cmorley
  • cmorley
13 Oct 2025 03:14
Replied by cmorley on topic installing QTVCP

installing QTVCP

Category: Qtvcp

What version of linux are you using?
  • bnet
  • bnet's Avatar
13 Oct 2025 02:49

Fanuc Serial Pulse Coders - Red cap servos, mesa 7i76e, how to?

Category: Driver Boards

Here's a version that uses the digitally settable preset velocity mode to seek for the index of the encoder:
# =====================================================
#  LinuxCNC HAL — Ultra3000 preset velocity index seek
#  Board: 7i76e main + 7i84 (outputs) + 7i85 (encoder)
#  Axis: X
# =====================================================

loadrt threads name1=servo-thread period1=1000000

# --- Load components ---
loadrt bldc count=1
loadrt encoder num_chan=1
loadrt mux2 count=1
loadrt and2 count=1
loadrt not count=1
loadrt timedelay count=1
loadrt oneshot count=1

addf encoder.update servo-thread
addf bldc servo-thread
addf timedelay servo-thread
addf oneshot servo-thread

# =====================================================
#  Encoder setup (7i85)
# =====================================================
setp hm2_7i85.0.encoder.00.scale 800
setp hm2_7i85.0.encoder.00.counter-mode 0
setp hm2_7i85.0.encoder.00.filter 1

net x-enc-a     hm2_7i85.0.encoder.00.input-a
net x-enc-b     hm2_7i85.0.encoder.00.input-b
net x-enc-z     hm2_7i85.0.encoder.00.input-index

# =====================================================
#  BLDC Hall synthesis (for Ultra3000 commutation)
# =====================================================
# 8-pole motor = 4 pole pairs
setp bldc.0.pole-pairs 4
setp bldc.0.encoder-scale 800
setp bldc.0.hall-offset 0      # will be updated after index alignment

net x-enc-pos       hm2_7i85.0.encoder.00.position => bldc.0.enc-pos
net hall-u          bldc.0.hall-u => hm2_7i84.0.output-00
net hall-v          bldc.0.hall-v => hm2_7i84.0.output-01
net hall-w          bldc.0.hall-w => hm2_7i84.0.output-02

# =====================================================
#  Preset Velocity Control Output (7i84)
# =====================================================
# Choose an available output (here output-03)
net preset-vel-enable => hm2_7i84.0.output-03

# =====================================================
#  Step/Dir control enable (7i76e stepgen 0)
# =====================================================
net stepgen-enable => hm2_7i76e.0.stepgen.00.enable

# =====================================================
#  State control logic for startup alignment
# =====================================================

# --- Delay after power-up before preset allowed ---
setp timedelay.0.on-delay 0.25
net startup-delay timedelay.0.out => preset-allow
net always-true timedelay.0.in <= true

# --- Oneshoot from encoder index detection ---
setp oneshot.0.width 0.05
net x-enc-index hm2_7i85.0.encoder.00.index => oneshot.0.in
net index-found oneshot.0.out

# --- Preset velocity enable logic ---
# When not yet found index and startup delay done -> enable preset rotation
loadrt and2 count=1
net not-found-delay and2.0.in0 <= preset-allow
net not-found-delay and2.0.in1 <= not-index-found
net preset-active and2.0.out => hm2_7i84.0.output-03

# --- index found logic ---
loadrt not count=1
net index-found oneshot.0.out => not.0.in
net not-index-found not.0.out

# --- On index detection, disable preset and enable stepgen ---
net index-found stepgen-enable
# (this ties directly; optionally route through another delay)
Displaying 12826 - 12834 out of 12834 results.
Time to create page: 2.924 seconds
Powered by Kunena Forum