Search Results (Searched for: )

  • Konstantin
04 Mar 2026 16:20 - 04 Mar 2026 16:29
Replied by Konstantin on topic CiA 402 Folder Missing
@andrax
How do you know that the vid and pid are wrong? I have set them in the .xml file as per the manufacturer .xml when I created the configuration. Attached is the .xml file.

The "dmesg | grep ethercat" still does not seem to work, I executed the command sequence you posted and it just outputs a new row in the terminal.

I am still unaware why the synchronization error keeps appearing, cables are changed and I also have grounding on the metal parts of the bench.

Perhaps, there are some settings in the servo itself that need to be configured. I still think about the fixed and variable PDO mapping, if it could be the reason for this behaviour. There is a warning that says - 1 datagram UNMATCHED!.


  • PCW
04 Mar 2026 16:15
Replied by PCW on topic Trying to set up position control mode
When you say the motor moves, are you saying the DRO is changing
when no commanded motion is requested?

Do you get a following error?
 
  • hmnijp
04 Mar 2026 16:06 - 04 Mar 2026 16:07
Replied by hmnijp on topic motion channels for robotic atc library
It would be nice to have a simple_xyz_tp.comp component to support linear interpolation and be independent of the main TP.

I think this is a simple task for extending the simple_tp component, where smoothing and arcs are not required.
  • PCW
04 Mar 2026 16:04
Replied by PCW on topic 7i92T and mx3660 request for help
Did you verify that all home switch inputs work as expected in halshow?
that is, the motions home  switch pins (like joint.0.home-sw-in ) change from
red to yellow when activated.

You might also check that there is no noise on the switch inputs.
(setting halscope to trigger on the switch active level can catch single cycle noise pulses)


  • PCW
04 Mar 2026 15:48
Replied by PCW on topic RPI5_7i80HDT_7i52s+7i49+7i44+BISS
Can you post your PINxxxx.vhd file

 I can take a look
 
  • Lcvette
04 Mar 2026 15:45
Replied by Lcvette on topic Add Buttons in Probe Basic
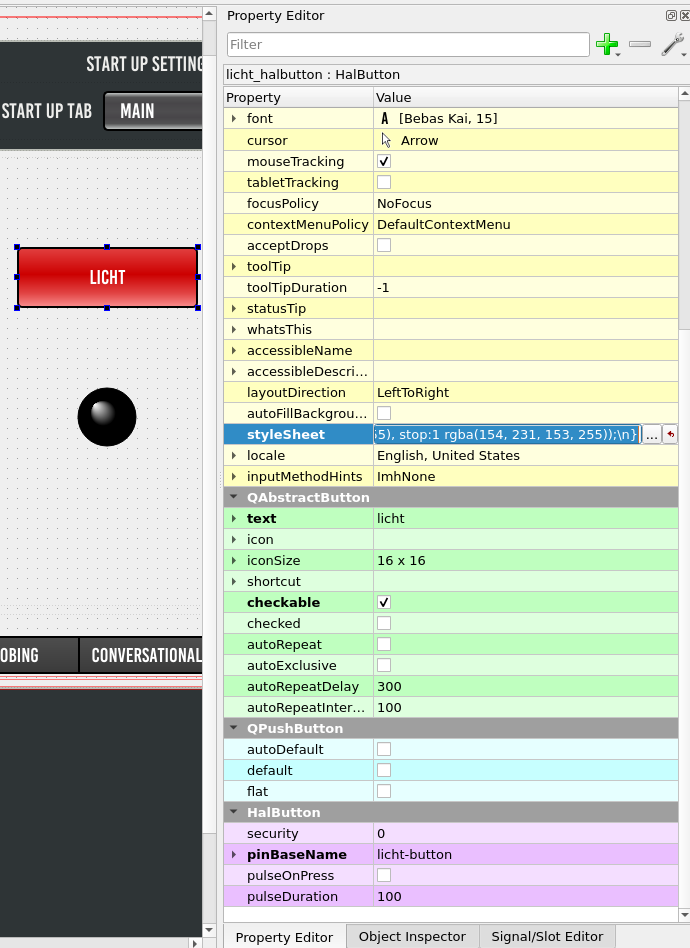
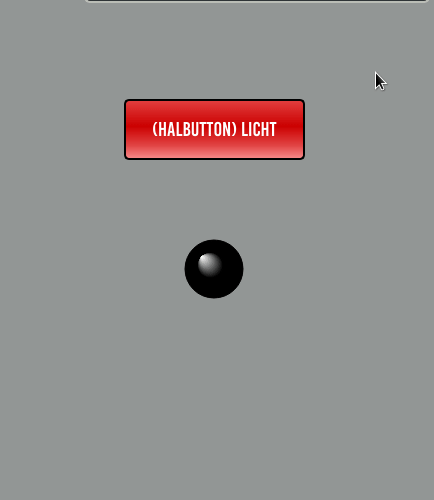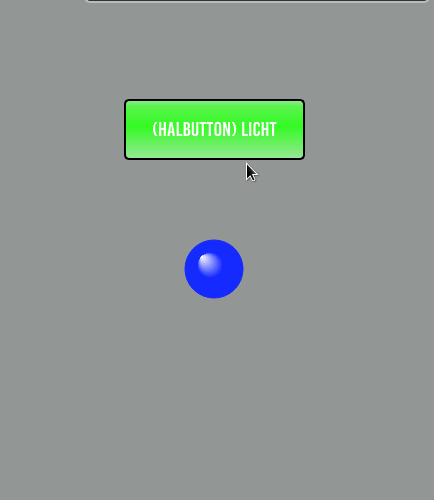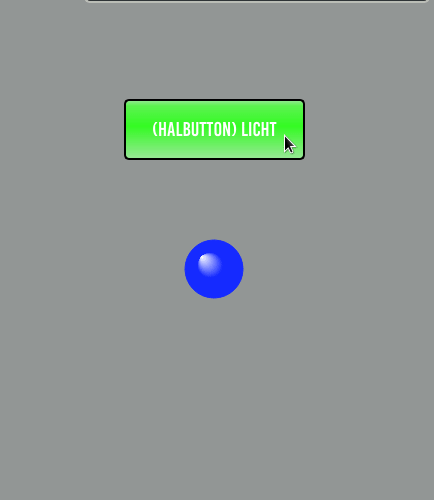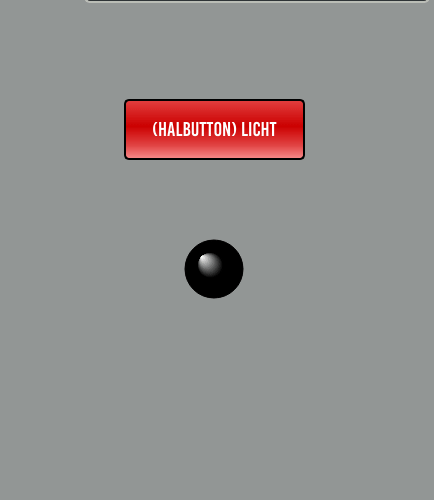
You are trying to control a hal pin, so you will want to use a HalButton from the custom widgets tree. the halpin will have the pinBaseName property you need to set for the button's connection to your licht net. see image below for references:


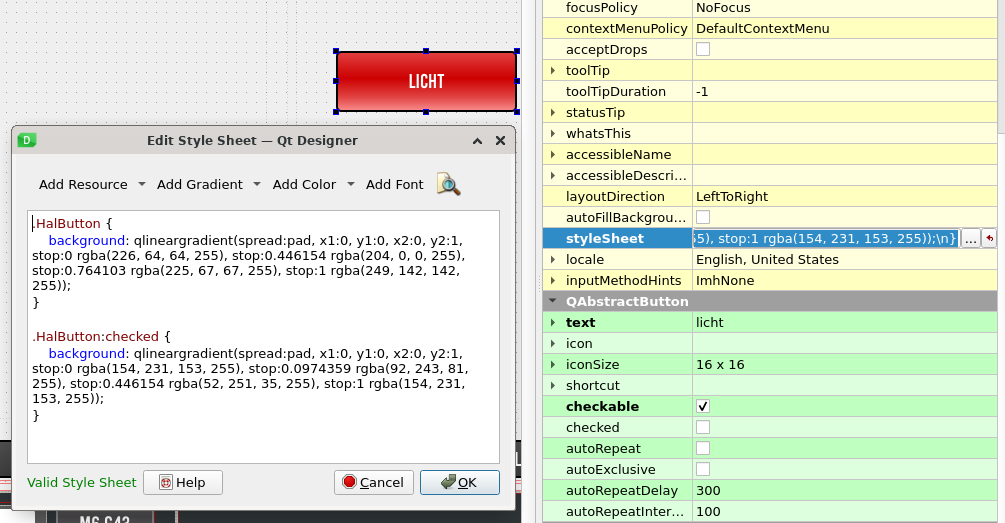
the button color can be style in the stylesheet (see image below) using the following color connections:
Code:
.HalButton { background: qlineargradient(spread:pad, x1:0, y1:0, x2:0, y2:1, stop:0 rgba(226, 64, 64, 255), stop:0.446154 rgba(204, 0, 0, 255), stop:0.764103 rgba(225, 67, 67, 255), stop:1 rgba(249, 142, 142, 255)); } .HalButton:checked { background: qlineargradient(spread:pad, x1:0, y1:0, x2:0, y2:1, stop:0 rgba(154, 231, 153, 255), stop:0.0974359 rgba(92, 243, 81, 255), stop:0.446154 rgba(52, 251, 35, 255), stop:1 rgba(154, 231, 153, 255)); }


The button probe_basic_postgui.hal file connection code is as follows:
Code:
loadrt time loadrt not addf time.0 servo-thread addf not.0 servo-thread # *** Time items required for Probe Basic to run *** net prog-running not.0.in <= halui.program.is-idle net prog-paused halui.program.is-paused => time.0.pause net cycle-timer time.0.start <= not.0.out net cycle-seconds qtpyvcp.timerseconds.in <= time.0.seconds net cycle-minutes qtpyvcp.timerminutes.in <= time.0.minutes net cycle-hours qtpyvcp.timerhours.in <= time.0.hours #  ---manual tool change signals--- net tool-change-request     =>  qtpyvcp_manualtoolchange.change net tool-change-confirmed   <=  qtpyvcp_manualtoolchange.changed net tool-number             =>  qtpyvcp_manualtoolchange.number # *** Probe graphic simulation trigger push probe tip *** net probe-in  =>  qtpyvcp.probe-in.out net probe-in  <=  qtpyvcp.probe-led.on # *** Set line below for actual spindle readout from your hal file *** net spindle-rpm-filtered scale_to_rpm.out  =>  qtpyvcp.spindle-encoder-rpm.in # *** custom gui hal widget connections *** net licht  <=  qtpyvcp.licht-button.checked net licht  =>  hm2_7i76e.0.7i76.0.0.output-02

once done you should have something that works like this gif below, but for your physical light:


  • hmnijp
04 Mar 2026 15:36 - 04 Mar 2026 15:43
1) It may not be a good idea to divide the architecture of a single module too much. This can cause unnecessary complications in the connections between them and race conditions between components...  For example, the state machine of the “homemode” module in some situations cyclically processes several states in one cycle, thanks to its flat structure, which would be difficult to do if it were broken down into modules.


2)

gantry_manager.comp
Possible responsibilities:
- synchronized homing of multiple drives
- gantry squaring


I think this should be handled by the built-in homing and kinematic module, regardless of the communication bus.

I recently encountered this using ethercat drives with absolute encoders - it is already partially successful. 
Alignment occurs during the homing procedure when jointY1 and joint Y2 move independently and synchronously (home sequence) by calling free_tp,
but requires a revision of the procedure for HOME_ABSOLUTE_ENCODER, which is used by cia402/ethercat ( github.com/LinuxCNC/linuxcnc/pull/3774/c...be947439e20fc5da9825 ), to prepare it for correct communication with the cia402 state machine

as a result, squaring control should take place in the trivkins module where, when declaring KINS=XYYZ, the connection is established 
joints[1] = pos->tran.y
joints[2] = pos->tran.y

I don't see the need for another layer  “motion -> trivkins -> gantry.comp -> pid -> cia402 ->lcec”   since we already have independent joints, each of which is connected to feedback for tracking following error.
  • NWE
04 Mar 2026 15:25
Replied by NWE on topic motion channels for robotic atc library
I'm convinced extrajoints handles such a case. It can even move multiple joints at the same time, they're just not synced with each other in any way unless extra hal logic is used to interpolate moves, which you don't need here.
  • Muecke
04 Mar 2026 15:18
Replied by Muecke on topic Forum Fehler, ... :-(
Was kann ich machen, damit ich auf die Beiträge antworten kann? Es ist jetzt schon mehrere Tage so. :-( 

Einen neuen/zweiten User anzulegen, ist nicht die richtige Lösung!
  • tykhon
04 Mar 2026 15:15 - 04 Mar 2026 16:46
chineese mesa 7i92 custom bit file was created by tykhon
I`m having some problems with customizing bit file to configure my mesa(clone) board. Previously I used effinity software but it seems that chineese boards running on xilinx base. Unfortunatelly I can`t download xilinx software. Could somebody help me with compiling custom bit? Pinout attached below in custom vhd file 

File Attachment:

File Name: PIN_G540x2D_34.zip
File Size:2.49 KB
 
  • HM
04 Mar 2026 13:49
Hello from the new guy!
I want to equip a relatively large machine with LinuxCNC.
For this, I’ve got the 7i80HDT, 7i52s, 7i49, and 7i44 cards.
Unfortunately, I’m struggling to create a suitable PIN file in Efinity.
Is there a description of what a PIN file should look like?
For example, something like “this block is for the 7i52s, … and the following parameters need to be adjusted.”
I would like to work with two configurations.
If possible, I’d prefer both configurations to be achievable with a single PIN file.

RPI5 to 7I80HDT to
- 7I52S Port 3 only needet in configuration 1
            o   6xStep/Dir (output)
            o   6xEncoder A/B/Z (input)
- 7I49 Port 2 only needet in configuration 2
- 7I44 Port 1
            o   4xSS
            o   4xBISS-C with 32Bit Port 5-8

Could it be that the FPGA chip on the 7i80HDT is too small for a configuration where all the mentioned cards are addressed?
Wich one should i choose?

Can someone help me with a PIN-File and/or a description?
That way, I might be able to spot my mistakes as a beginner and learn from them.

What is the meaning of "Unassignet Core Pins [2]" in Efinity (in red) is this important?
What is the meaning of "Missing Interface Pins [1]" is this important?

Best regards,
Michael from Austria

I also strugled with the Errors:
ERROR : C:\Efinity\2024.2\project\7i80hdt-alround-7i52-7i49-7i44\configs\hostmot2\source\7i80hdt-hm2\hostmot2_efx.vhd(1623): index 2 is out of array constraint 0 downto 0 for target 'muxedindex' [VHDL-1123]

Filename.hal:24: parameter or pin `hm2_7i80.0.dpll.01.timer-us`not found 2067
solution:  www.forum.linuxcnc.org/27-driver-boards/...1-timer-us-not-found

Problem with locale in PNC-Config
solution: forum.linuxcnc.org/39-pncconf/56472-lc-2...n-unsupported-locale
  • jrstokka
04 Mar 2026 13:48
Would love to compare notes. I'm about to do this exact thing. I have an old style PC running Mach 3 on a pcnc 1100-3 conversion. I am buying a standalone pc and ordered the PP usb stick. I tried to find the 7I92 and directed to the 7i92TF only to find out noone has them in stock, about to order the 7i92TM and use a gender bender like you mentioned.
  • tommylight
04 Mar 2026 13:35
Replied by tommylight on topic 5I20 replacement
No worries, you are welcomed, always.
  • billykid
04 Mar 2026 13:14 - 04 Mar 2026 13:21
Replied by billykid on topic 5I20 replacement
Thanks Tom, but I had already seen that they only have three ports and you need four like the 5i20. With the binary switches and tool changer we used three 7i37s and a 7i33 for the analog spindle.

My fault! I wasn't close to the lathe  so I couldn't see the model. It's actually a four-port  5i22. Sorry again.
  • ClarkSavage
04 Mar 2026 12:42
Replied by ClarkSavage on topic 7i92T and mx3660 request for help
First come in order, we can take it offline or stay on - one at a time.

I am frustrated so will check later. Can go from there. Already ordered a parallel port card for the new computer so we will see. Got to do what I have to in order to get this running.
Displaying 6151 - 6165 out of 11376 results.
Time to create page: 0.162 seconds
Powered by Kunena Forum