Search Results (Searched for: )

  • tommylight
25 Jan 2026 22:23
Did you try lowering the acceleration?
The default of 750mm/s/s is to much for some machines.
  • grandixximo
25 Jan 2026 21:33 - 25 Jan 2026 22:36
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations
github.com/grandixximo/linuxcnc/tree/9d

This is phase 0 completed, according to my plan, this is extremely experimental work in progress, there are known issues at the moment, no arcs no blends, no scurve, as illustrated by the plan you can find at this post, which I got not much feedback..

forum.linuxcnc.org/38-general-linuxcnc-q...ons?start=640#341856

Next phase it is IMO too hard to be vibe coded, but I will try in my spare time.
  • rodw
25 Jan 2026 19:46
Replied by rodw on topic Lichuan 4 axis stepper need help-
The issue with the original code was it was developed with a machine that homes to index so it does not work cleanly with home to sensor. The real problem  is that during device homing, Linuxcnc throws following errors because it has not commanded movement. What generally needs to happen is the position feedback is synced with commanded position so Linuxcnc is happy. This is why most working solutions also provide their own cia402.comp

Yes, I think homing can be standardized for cia402 devices and the new home comp is there now to support that. So much of homing.c becomes irrelavent with device homing so the homecomp allows control of what is needed. I've had a couple of goes at it. The first was obsoleted by a rewrite of the homecomp paradigm.

The cia402 state machine is actually very simple. very linear with the exception of error and safety steps to prior states. The flowchart here is a good resource
www.kebamerica.com/blog/comprehensive-gu...a-402-drive-profile/

Anyway, back on task. It occurred to me that I had included some standard PDO's that are not reported by Ethercat pdos. I will revisit that. 

 
  • Mr1576
25 Jan 2026 19:11
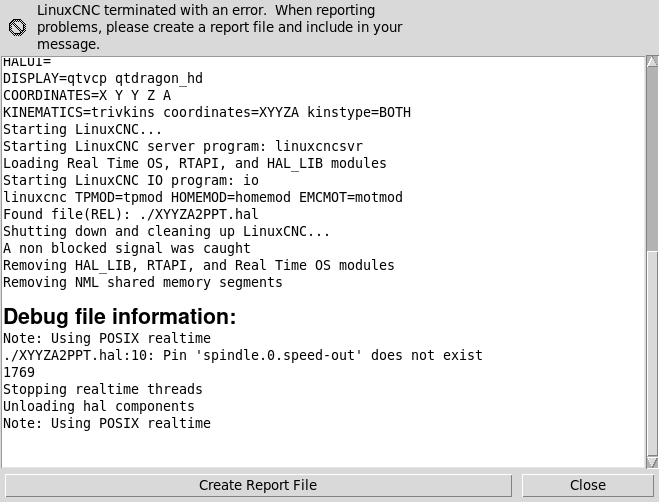
Replied by Mr1576 on topic HAL Edits for RS485 / VFD Spindle Control
Thanks for your reply @andypugh

I copied and pasted your suggestion into my HAL file, replacing the original erroneous text.

Unfortunately when launching Linuxcnc, an error is shown up as attached in the .png file.

Revised HAL file also attached.

Regards

Phil

File Attachment:

File Name: XYYZA2PPTREV1.txt
File Size:4.59 KB
  • grandixximo
25 Jan 2026 18:51
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations
I mostly run G64 P0.05 in metric, G64 P0.002 in inches, G61 is afterthought for us, but will be tested...
  • Lcvette
25 Jan 2026 18:07
Replied by Lcvette on topic Probe Basic Stable error
the on screen button and physical button cannot remain synchronized as the screen cannot physically change the mushroom buttons state. so you will need to add in some hal NOT allowing the UI estop button in probe basic to be in a state different from the physical mushroom button.
  • andypugh
25 Jan 2026 17:08
Replied by andypugh on topic Absolute encoder homing
  • andypugh
25 Jan 2026 17:03
You could quickly check if those have the desired affect by opening halshow, opening the "watch" tab and picking those pins from the tree. Then you can set values directly.

If that works then link them up in HAL.
  • andypugh
25 Jan 2026 16:59
Replied by andypugh on topic The Current Bread & Butter Setup?
One advantage of the Pi is that it is perfectly reasonable to have an identical spare to swap in in case of trouble.
  • andypugh
25 Jan 2026 16:57
Replied by andypugh on topic How to fix "Queue is not empty after probing"
This feels like possibly a race condition, I wonder what happens if the queue-empty check is just disabled?
(ie, I wonder if it indicates a real problem?)
  • andrax
25 Jan 2026 16:52
I use gmoccapy.

So far, I have found that these two signals control the feed rate:
gmocacapy.spc-feed.value
gmocacapy.spc-speed.value
  • andypugh
25 Jan 2026 16:49
Which GUI are you using?
  • andypugh
25 Jan 2026 16:48
Replied by andypugh on topic HAL Edits for RS485 / VFD Spindle Control
If this is your whole HAL file then the problem is that you have connected the HAL "net" to the VFD but not to the motion contoller.
Code:
# Connect HAL pins to motion controller net spindle-vel-cmd-rpm-abs hy_vfd.speed-command net spindle-cw hy_vfd.spindle-forward net spindle-enable hy_vfd.spindle-on net spindle-ccw hy_vfd.spindle-reverse net spindle-at-speed hy_vfd.spindle-at-speed

This creates "nets" with names like "spindle" enable but there is nothing at the other "end"

Try:
Code:
# Connect HAL pins to motion controller net spindle-vel-cmd-rpm-abs spindle.0.speed-out => hy_vfd.speed-command net spindle-cw spindle.0.forward => hy_vfd.spindle-forward net spindle-enable spindle.0.on => hy_vfd.spindle-on net spindle-ccw hy_vfd.spindle-reverse net spindle-at-speed spindle.0.at-speed <= hy_vfd.spindle-at-speed

The => are optional and ignored by the computer.

linuxcnc.org/docs/stable/html/man/man9/m....html#SPINDLE%20PINS
  • JT
25 Jan 2026 16:37
Replied by JT on topic Reload gcode
Sorry, I must have got distracted when changing the variable name and didn't finish changing every occurrence. The bug has been squashed.

JT
  • andypugh
25 Jan 2026 16:36
Replied by andypugh on topic PiBot Pendant
I have sent a query about how it interfaces. If it is USB HID then it will probably work fine with hal_input. Otherwise it might need a specific driver.
Displaying 8191 - 8205 out of 11906 results.
Time to create page: 0.215 seconds
Powered by Kunena Forum