
- Posts: 18115
- Thank you received: 5334
Servo Wiring and Tuning detailed How To example Mesa 7i77.
- PCW
- Offline
- Moderator
-

Less
More
7 years 2 months ago #143387
by PCW
Replied by PCW on topic Servo Wiring and Tuning detailed How To example Mesa 7i77.
Note that FF1 is not like P that you adjust up till you have too much and then back off.
FF1 needs to be set accurately and the best way is to see if the feedback position leads the commanded position or lags the commanded position. This is best done with a low P setting
(this is assuming velocity mode drives, torque mode drives are tuned very differently)
FF1 needs to be set accurately and the best way is to see if the feedback position leads the commanded position or lags the commanded position. This is best done with a low P setting
(this is assuming velocity mode drives, torque mode drives are tuned very differently)
Please Log in or Create an account to join the conversation.
- PCW
- Offline
- Moderator
-
Less
More
- Posts: 18115
- Thank you received: 5334
7 years 2 months ago #143389
by PCW
So you have a step/ dir driven machine with encoder feedback?
If not and its a plain step/dir machine (no external feedback), FF1=1 ,P=1000, and make sure the maxerror settings are commented out
Replied by PCW on topic Servo Wiring and Tuning detailed How To example Mesa 7i77.
Type_Zero_Design wrote: Pcw,
Dose what you said here not apply to me since I'm using step/for rather than analog?
You can either calculate FF1 (10/velocity@10V) or scale the analog output
in velocity in which case FF1 = 1.0
If not how do I measure the velocity?
So you have a step/ dir driven machine with encoder feedback?
If not and its a plain step/dir machine (no external feedback), FF1=1 ,P=1000, and make sure the maxerror settings are commented out
Please Log in or Create an account to join the conversation.
- randypetersen
- Offline
- Premium Member
-

Less
More
- Posts: 136
- Thank you received: 15
7 years 2 months ago #143390
by randypetersen
Replied by randypetersen on topic Servo Wiring and Tuning detailed How To example Mesa 7i77.
I can't really seem to find out of my drives are torque or velocity, I will have to take a closer look at them when I am at the shop tomorrow. Is there any easy way to tell?
Thanks!!
Thanks!!
Please Log in or Create an account to join the conversation.
- Type_Zero_Design
- Offline
- Premium Member
-
Less
More
- Posts: 133
- Thank you received: 7
7 years 2 months ago #143393
by Type_Zero_Design
Replied by Type_Zero_Design on topic Servo Wiring and Tuning detailed How To example Mesa 7i77.
PCW,
Yes I have servo machine with encoder feedback using step/dir.
Currently I have gone through and set all my PIDS and FFn to 0 as Tony recommend in his tutorial and adjusted my P up until I got oscillations after joging and then backed down until they cleared.
Then I started running FF1 bring my error in to be inline.
Currently though when I get FF1 high enough to get my Error in line, after releasing the jog I get osscilations as shown in the video in the link here: photos.app.goo.gl/eiimAkZXWb9CGVqG6
Also attached are the current running settings that were running in this video.
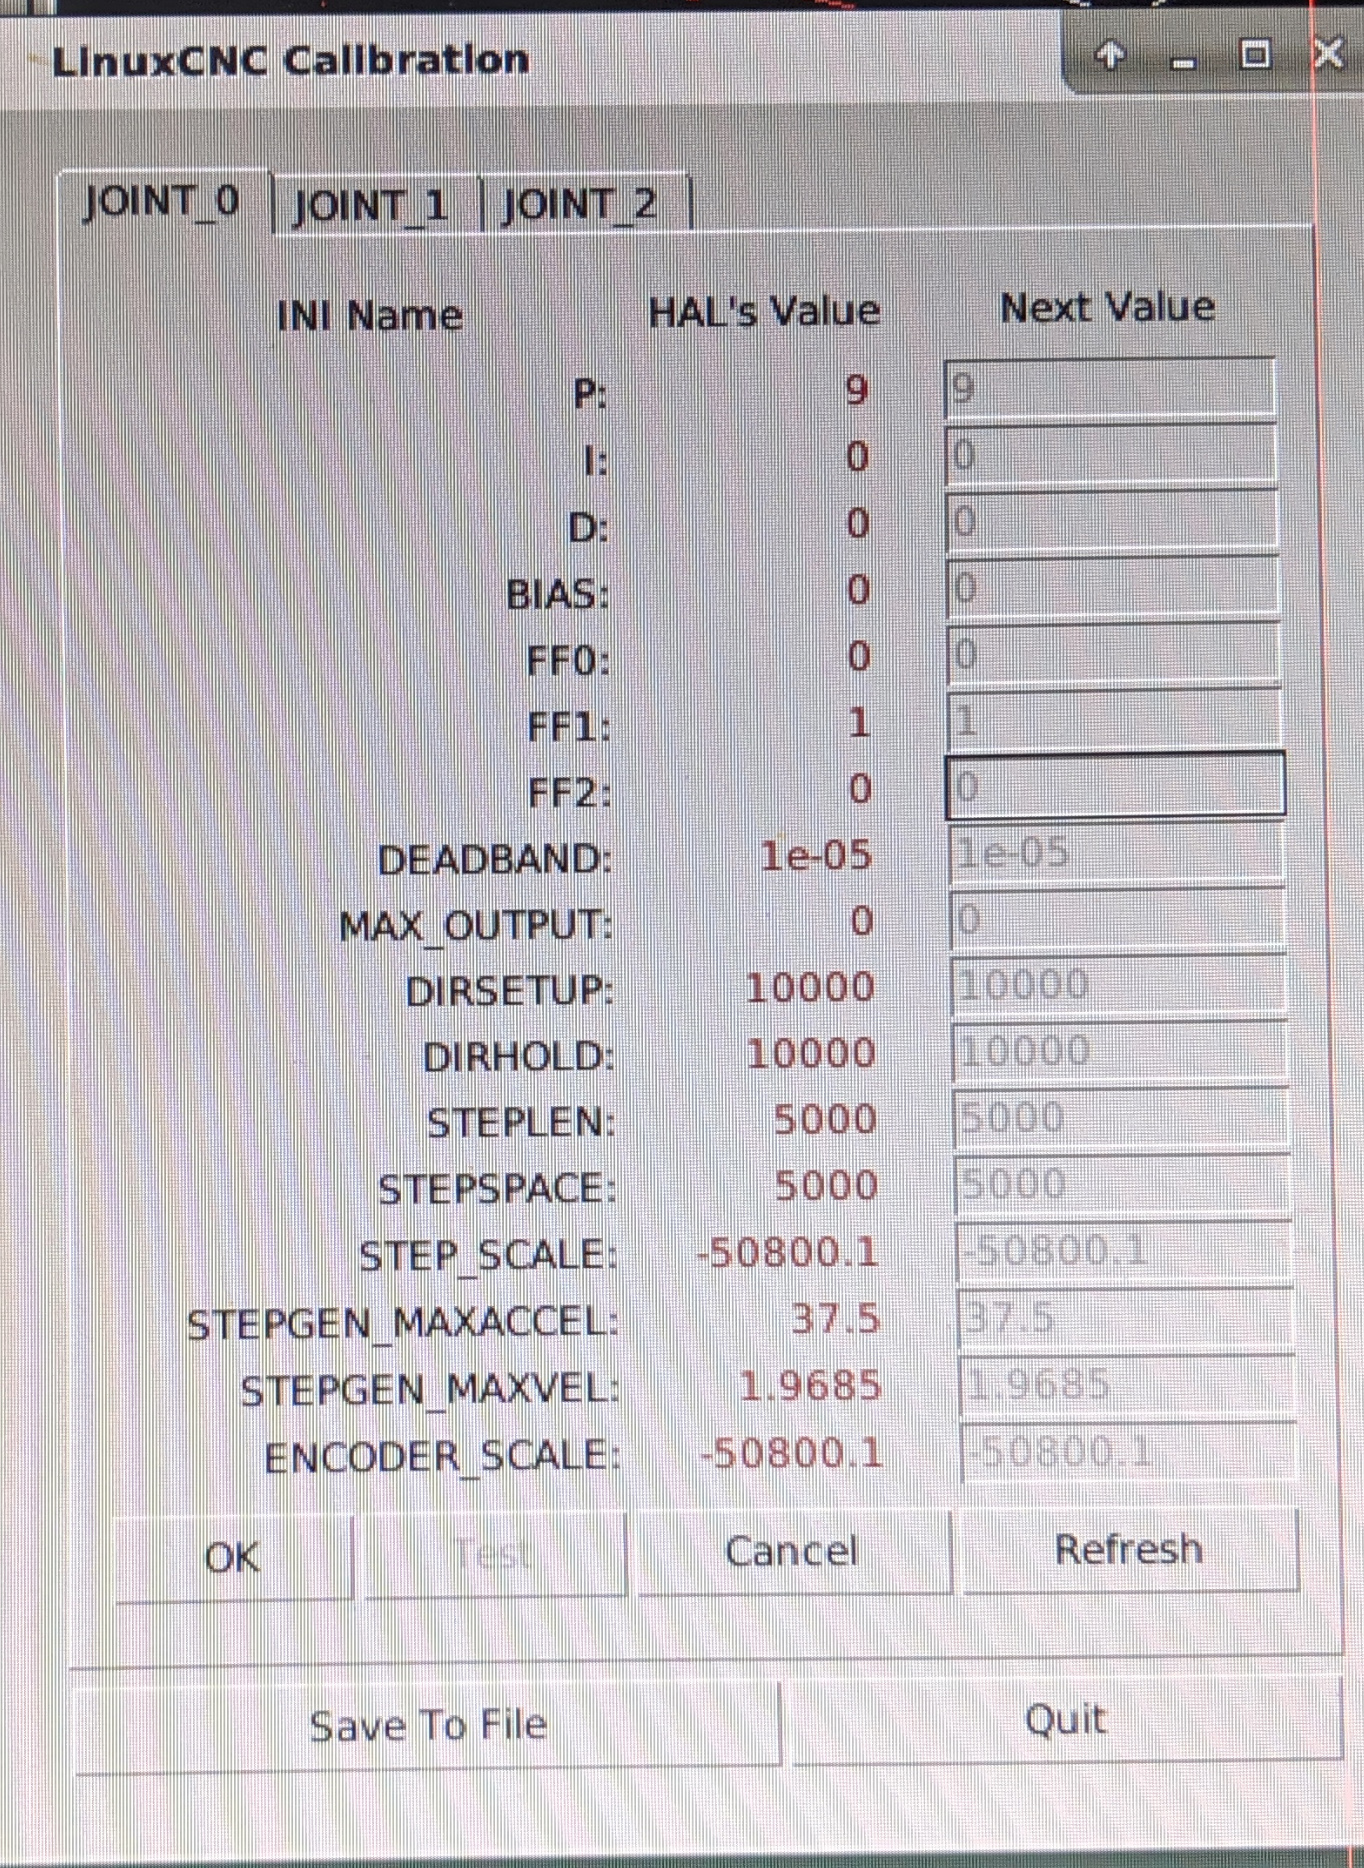
Yes I have servo machine with encoder feedback using step/dir.
Currently I have gone through and set all my PIDS and FFn to 0 as Tony recommend in his tutorial and adjusted my P up until I got oscillations after joging and then backed down until they cleared.
Then I started running FF1 bring my error in to be inline.
Currently though when I get FF1 high enough to get my Error in line, after releasing the jog I get osscilations as shown in the video in the link here: photos.app.goo.gl/eiimAkZXWb9CGVqG6
Also attached are the current running settings that were running in this video.
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-

Less
More
- Posts: 4793
- Thank you received: 1480
7 years 2 months ago #143442
by Todd Zuercher
Replied by Todd Zuercher on topic Servo Wiring and Tuning detailed How To example Mesa 7i77.
On a step/dir machine with encoder feedback, your FF1 should almost certainly be 1 assuming you started with a config made by PNCconf, and your encoder scale and stepgen scales match. You should only need to tune your P to get the best response. (Increase P until you start to see some overshoot, or instability, then back it off a little.)
If you are having a lot of trouble getting a good tune with just P, it is possible the servo drives need better tuning them selves (they have their own PID loops to tune) or the machine may have mechanical issues causing problems.
If you are having a lot of trouble getting a good tune with just P, it is possible the servo drives need better tuning them selves (they have their own PID loops to tune) or the machine may have mechanical issues causing problems.
Please Log in or Create an account to join the conversation.
- Type_Zero_Design
- Offline
- Premium Member
-
Less
More
- Posts: 133
- Thank you received: 7
7 years 2 months ago #143445
by Type_Zero_Design
Replied by Type_Zero_Design on topic Servo Wiring and Tuning detailed How To example Mesa 7i77.
Todd,
Are you suggesting that I would leave my FF1 @ 1 and then start making additional running on P. Just asking as that is the oppot of what I've been doing to this point.
Are you suggesting that I would leave my FF1 @ 1 and then start making additional running on P. Just asking as that is the oppot of what I've been doing to this point.
Please Log in or Create an account to join the conversation.
Time to create page: 0.297 seconds