Dual PID loops with motor encoder + scale encoder per axis

More
2 years 6 months ago #298182 by Tinine
Drive needs to be in torque mode, not velocity.

My experience is that it's better to have PI from the load-mounted encoder.

Dual-loop has always been my standard. Motor shaft angle is unimportant, we care about where the load is. Within reason, backlash becomes a non-issue.

Please Log in or Create an account to join the conversation.

More
2 years 6 months ago #298183 by TangentAudio
Tinine,
These are 35 year old dumb servo amps, there's no option to set torque mode on them unfortunately. They take offset PWM in and output +/- DC voltage. The motors have 2000CPR encoders, but they do not connect to the servo amps.

Please Log in or Create an account to join the conversation.

More
2 years 6 months ago #298184 by TangentAudio
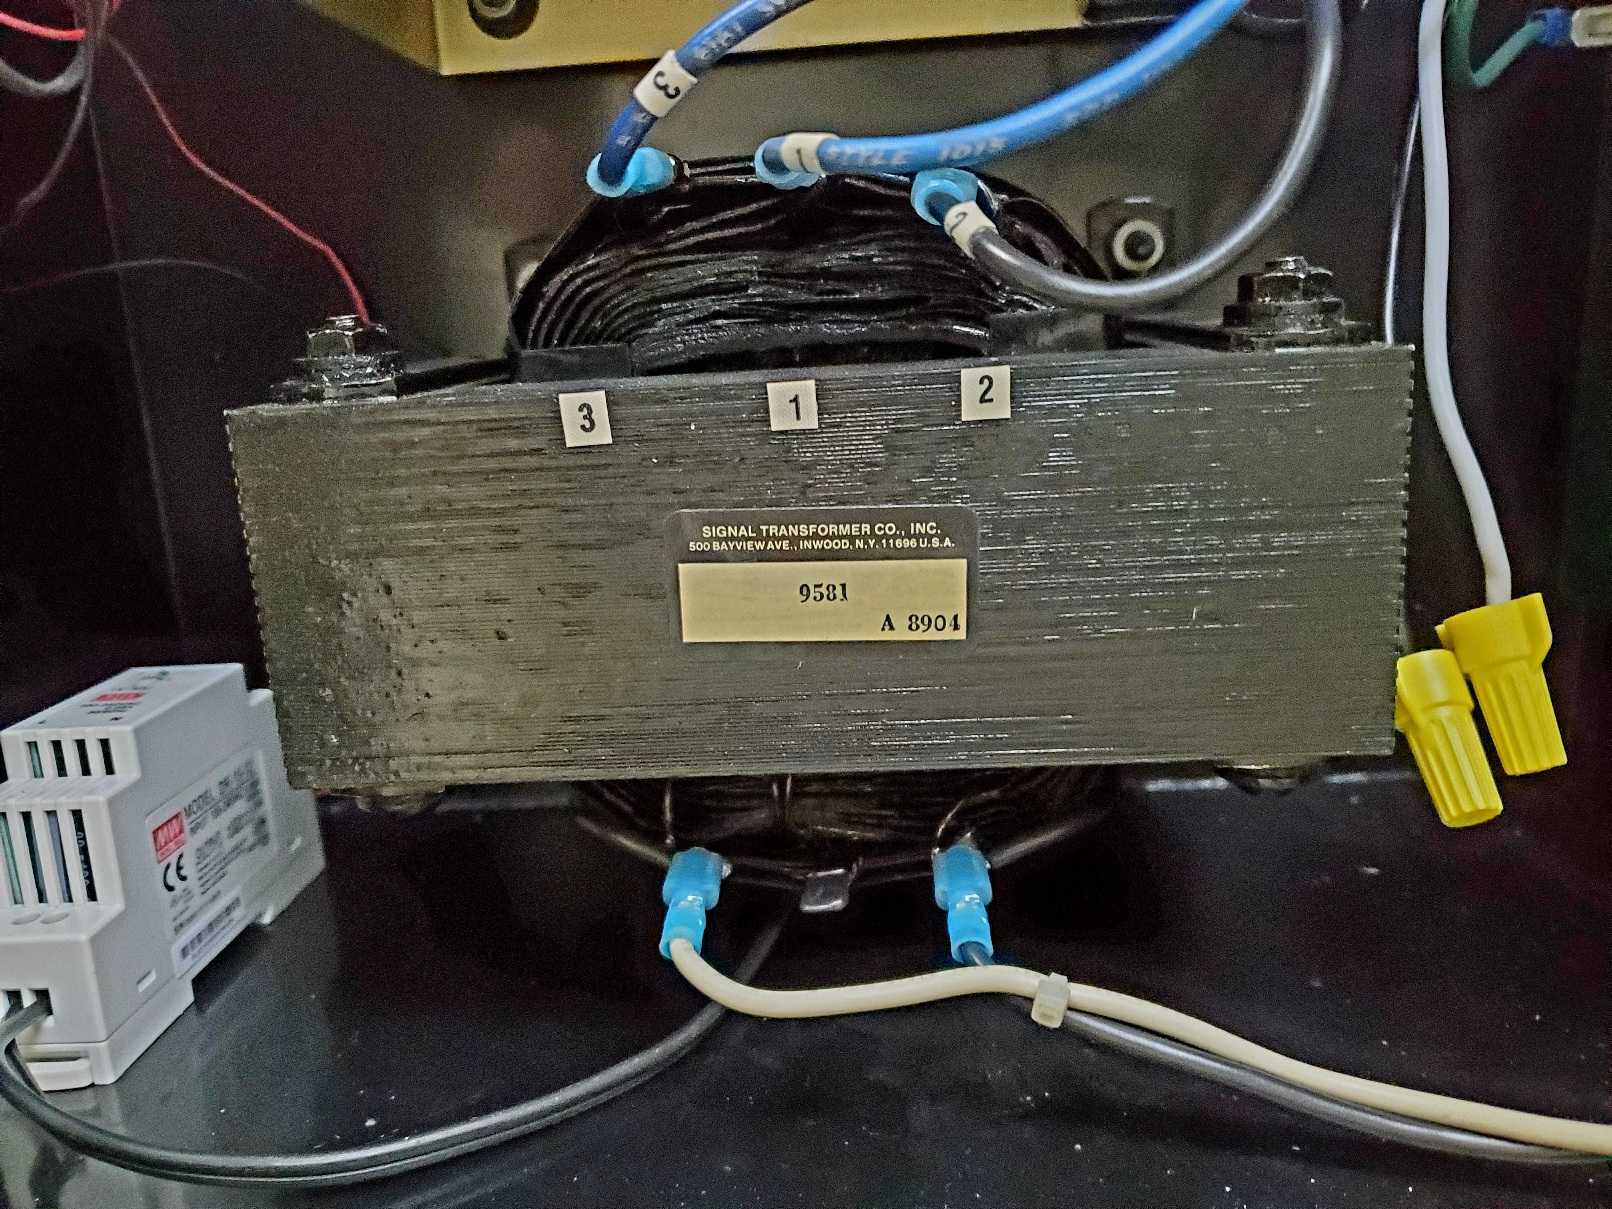
These are the parts of the old ProtoTrak Plus system from 1989 that I am still using for the moment, because they came with the machine and still work.

I have not pulled the amp boards from the cage to get photos, but they are pretty primitive.  Not much more than a DC power supply really.


The servo motors are big, brushed DC with a 16T:44T belt drive to couple to 5mm pitch ball screws.  The 2000CPR encoder hangs off the back.
 

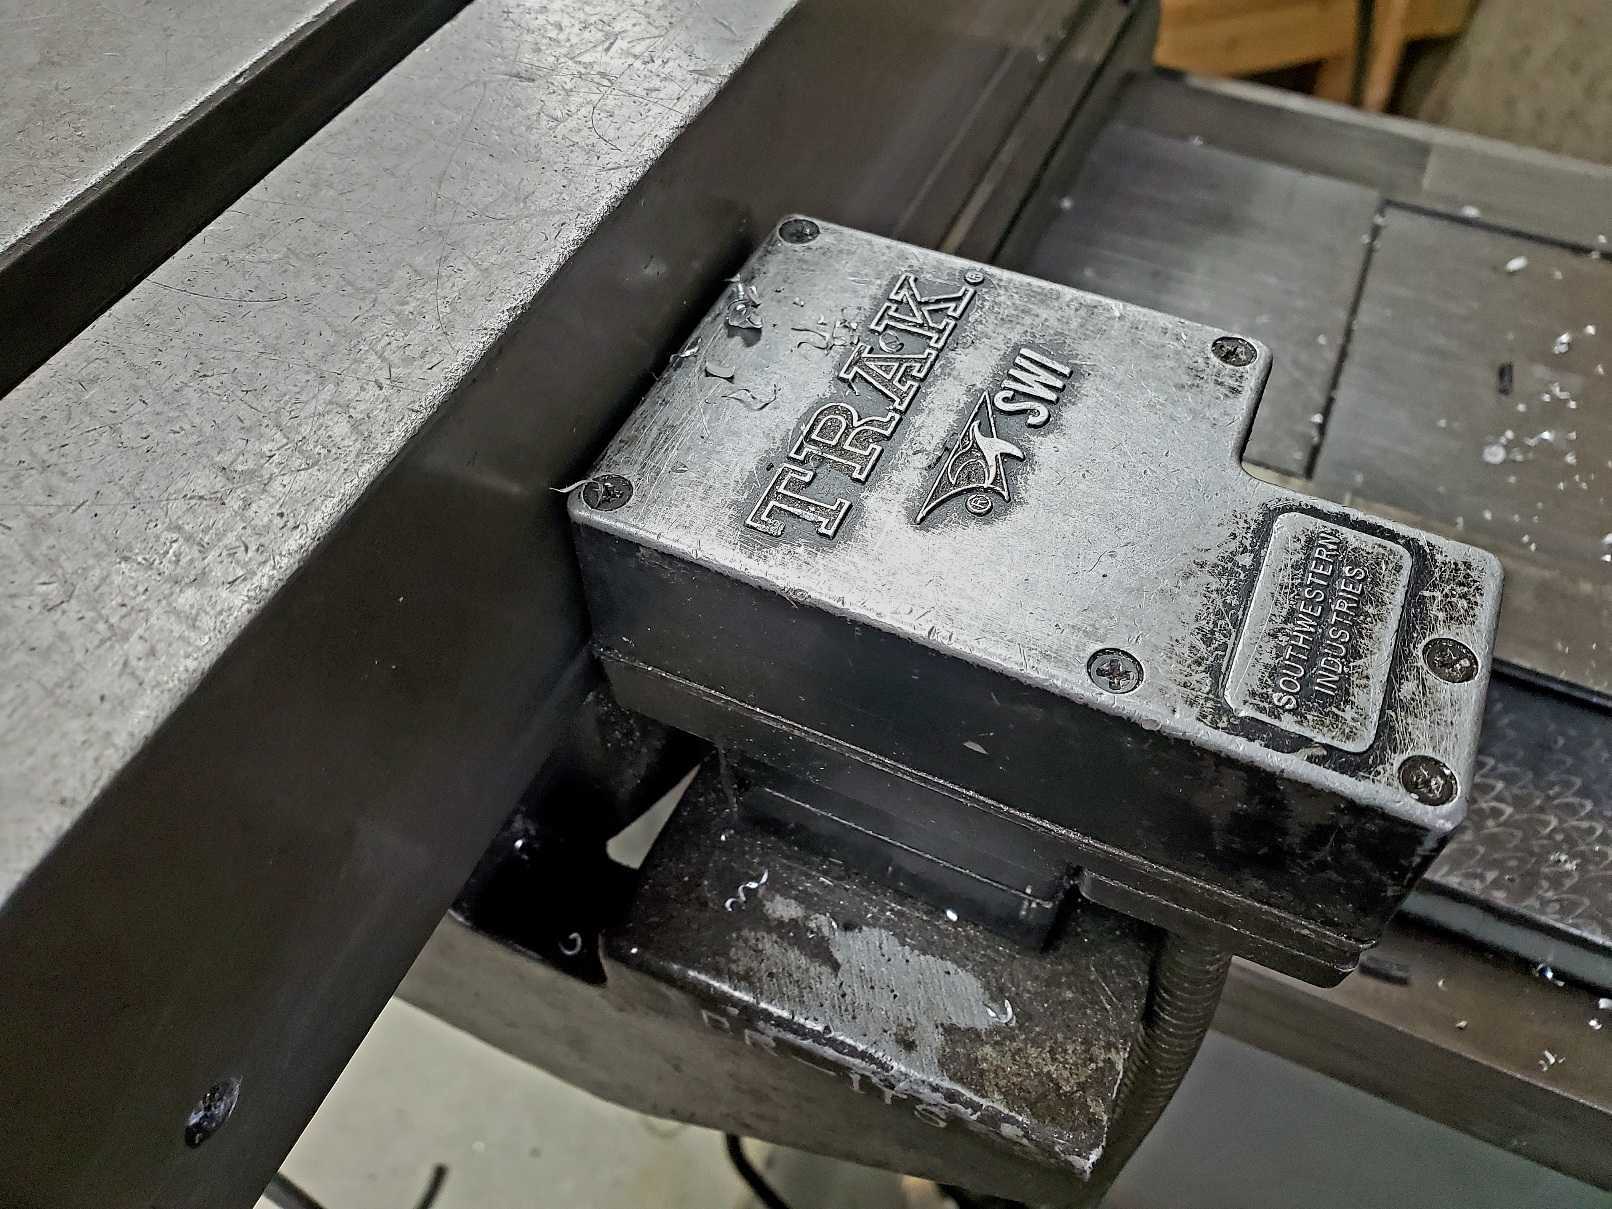
And these are the "infamous" Trak gage wheel table position encoders (on X, Y and the non-motorized quill).  They work, kinda, until they get chips in them or they get misaligned.


Please Log in or Create an account to join the conversation.
More
2 years 6 months ago #298189 by Tinine

Tinine,
These are 35 year old dumb servo amps, there's no option to set torque mode on them unfortunately. They take offset PWM in and output +/- DC voltage. The motors have 2000CPR encoders, but they do not connect to the servo amps.

 
Dumb=good. All you need the amp for is transconductance from a low-level command to a current. Encoder should feed to your controller, not the amp.
First thing I do with a modern drive is switch it to dumb torque-mode.
Do you have schematics for the drive? Sometimes the conversion is a matter of a solder-jumper.
The following user(s) said Thank You: TangentAudio

Please Log in or Create an account to join the conversation.

More
2 years 6 months ago #298190 by TangentAudio

 Dumb=good. All you need the amp for is transconductance from a low-level command to a current. Encoder should feed to your controller, not the amp.
First thing I do with a modern drive is switch it to dumb torque-mode.
Do you have schematics for the drive? Sometimes the conversion is a matter of a solder-jumper.

I have not stumbled across any schematics yet.  The cage with both X and Y amps is Trak part number 15047, but all I can find are listings for a full replacement.  I'm not opposed to pulling it apart and doing some reverse engineering, but I haven't gone there just yet.
 

Please Log in or Create an account to join the conversation.
More
2 years 6 months ago - 2 years 6 months ago #298226 by TangentAudio
After doing more reading, now I'm questioning what mode these amps actually use. This thread in particular: www.cnczone.com/forums/servo-motors-driv...d-velocity-mode.html

Without documentation or reverse engineering the board, is there a sort of "black box" bench test I could perform to determine if these amps are actually running in velocity or torque mode? I've got a scope, current probe, DMMs, a programmable DC load, optical tachometer...
Last edit: 2 years 6 months ago by TangentAudio.

Please Log in or Create an account to join the conversation.

Time to create page: 0.224 seconds
Powered by Kunena Forum
