Dual PID loops with motor encoder + scale encoder per axis

More
2 years 5 months ago #300126 by Tinine


I need to decide if I'm going to either build or buy a means of getting +/-10V output so I could try running the drive in torque or velocity mode.  With step/dir I'm limited to position mode, or faking velocity mode using the stepgen velocity output mode.


1-RPi Pico
2-74HC4050 (level-shifter, 5V to 3.3V)
1-MC3486 (differential line receiver - assuming that the encoder has diff outputs)
1-MC3486 if the pulse/dir is differential
1-MCP4922 DAC
1-OP-amp (TL072 or LM358)
2-LS7366R (one for quad decode and one for pulse/dir)

1- +/- 15V PSU (although I seem to remember that +/- 12V was fine. Bit fuzzy on that one)

Might not need the LS7366Rs because the PIO of the Pico can do it. I am already doing high-speed quad decode
but need to look at the pulse/direction thing.

Craig

Please Log in or Create an account to join the conversation.

More
2 years 5 months ago #300770 by TangentAudio
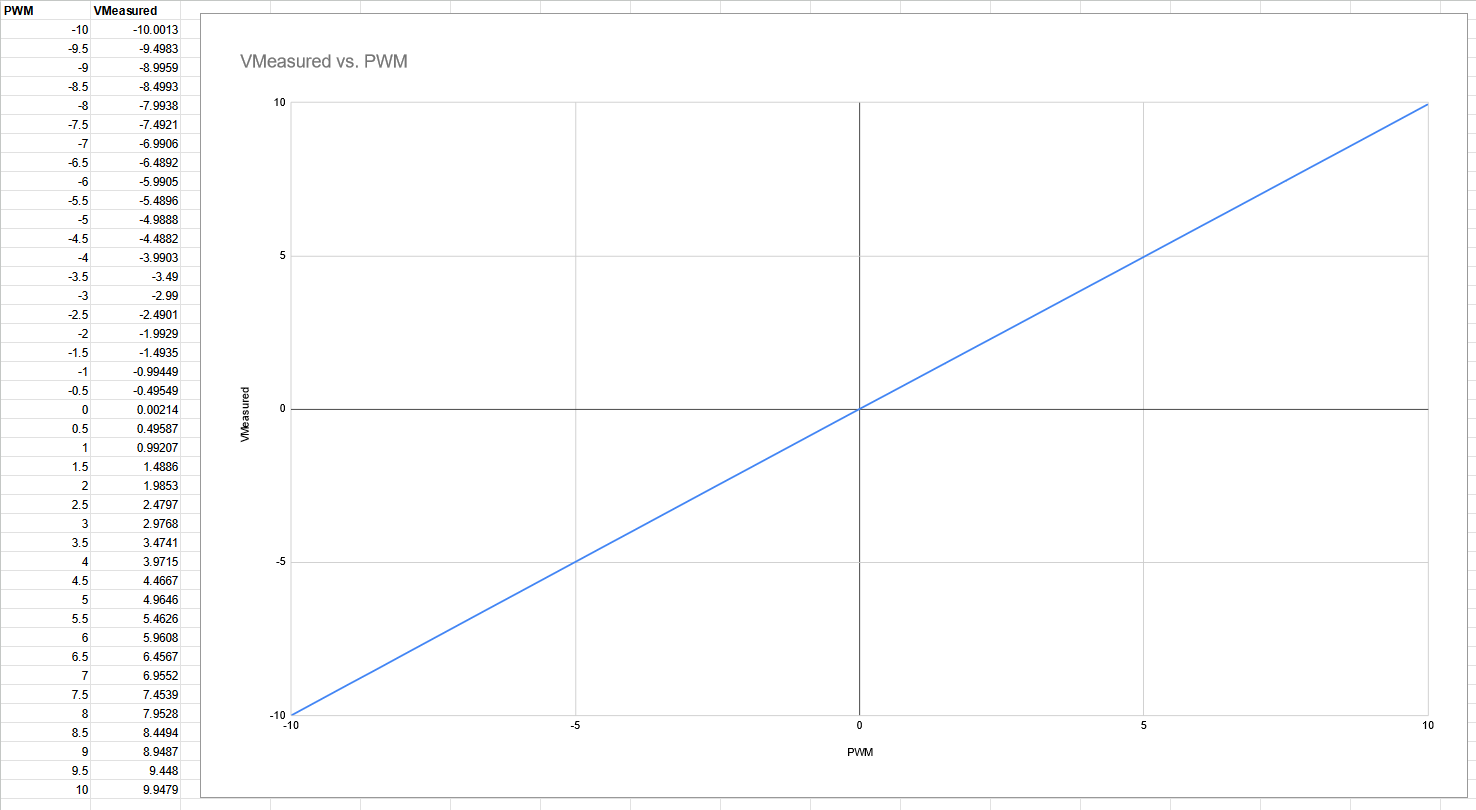
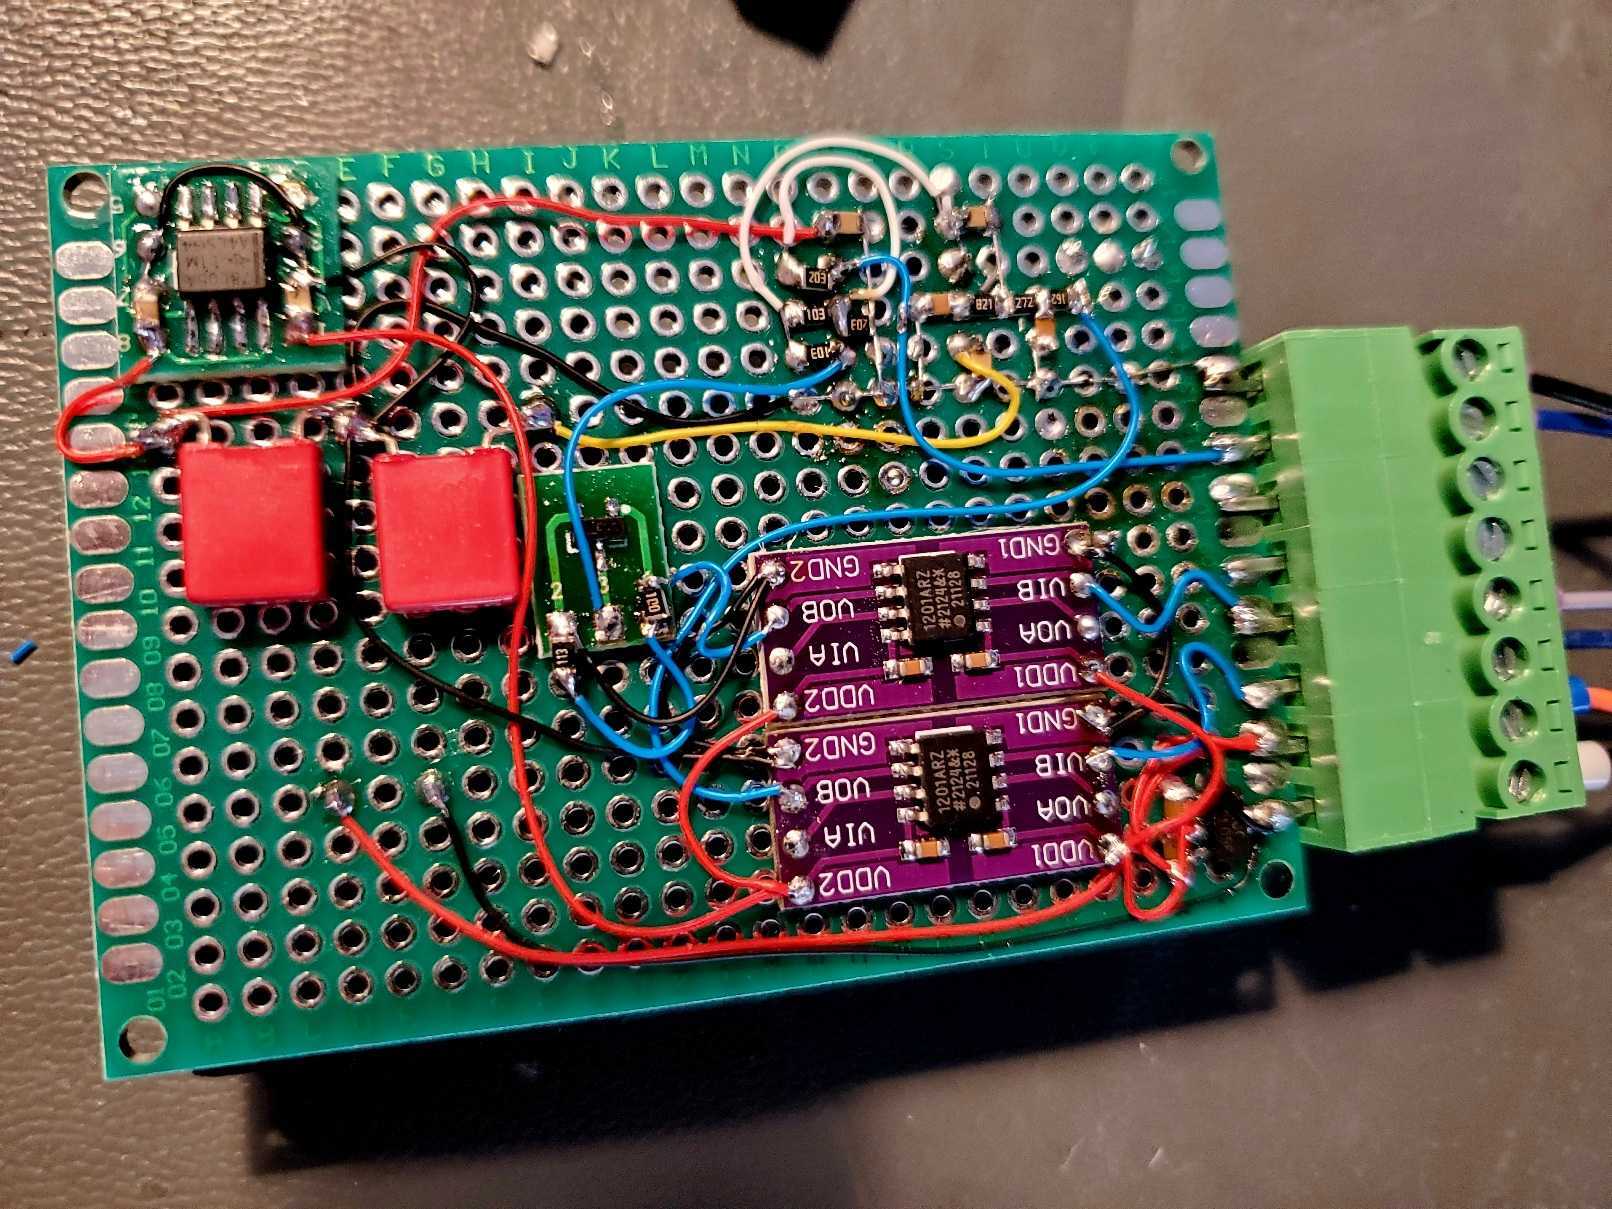
Still tinkering on this as time allows.  I did some junk box engineering this week and put together a little isolated PWM+direction to +/-10V circuit.  Now that it's validated I can reconfigure the servo drive from step+direction to analog input.


Seems to be nice and linear.


.. but it won't win any awards for the neatest prototyping job I've ever done.

   
The following user(s) said Thank You: tommylight, Tinine

Please Log in or Create an account to join the conversation.

More
2 years 5 months ago #301011 by Tinine
I love it image missing /media/kunena/emoticons/smile.png

Isolation and that's quite an LPF for motor control image missing /media/kunena/emoticons/laughing.png

My compliments.

Craig
The following user(s) said Thank You: TangentAudio

Please Log in or Create an account to join the conversation.
More
2 years 5 months ago #301012 by TangentAudio
Thanks, Craig.  Over the weekend, I managed to get a half decent tune with the drive in velocity mode (analog input).  Velocity loop closed on the drive, tuned using the DMM software, and position loop closed on the LinuxCNC side using the drive's encoder output only for feedback (no table scales yet).

I finally feel like I am gaining understanding and confidence with the loop topologies and tuning process.  Taking my time with it and getting my brain wrapped around it has proven valuable so far.  Next up will be resuming experiments with adding the table scales back into the mix, and maybe later if I'm feeling bold I can try my hand at switching the drives to torque mode as you suggested a while back.

I'm also keeping an eye on ebay to try to find a mate to this single 750W DMM servo motor + drive that I have.  I can't really justify buying new for this conversion when the original DC servos are honestly probably fine for my intended use, but I would like to ditch them in the name of modernity (and electrical cabinet real estate) anyway.


Please Log in or Create an account to join the conversation.
Time to create page: 0.167 seconds
Powered by Kunena Forum
