
- Posts: 711
- Thank you received: 9
Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
- new2linux
- Offline
- Platinum Member
-

Less
More
9 years 6 months ago #92215
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
many thanks for the links and thoughts, Andy!!
After reading more about 2nd loop, my thinking is to make shore I have tried all combinations 1st. Attached is a better trace for the heavy axes "y", I think the correct pins are referenced in the scope trace elements, ""listed as: pid.y.error; pid.y.output; encoder.01.velocity; jount-vel-cmd""
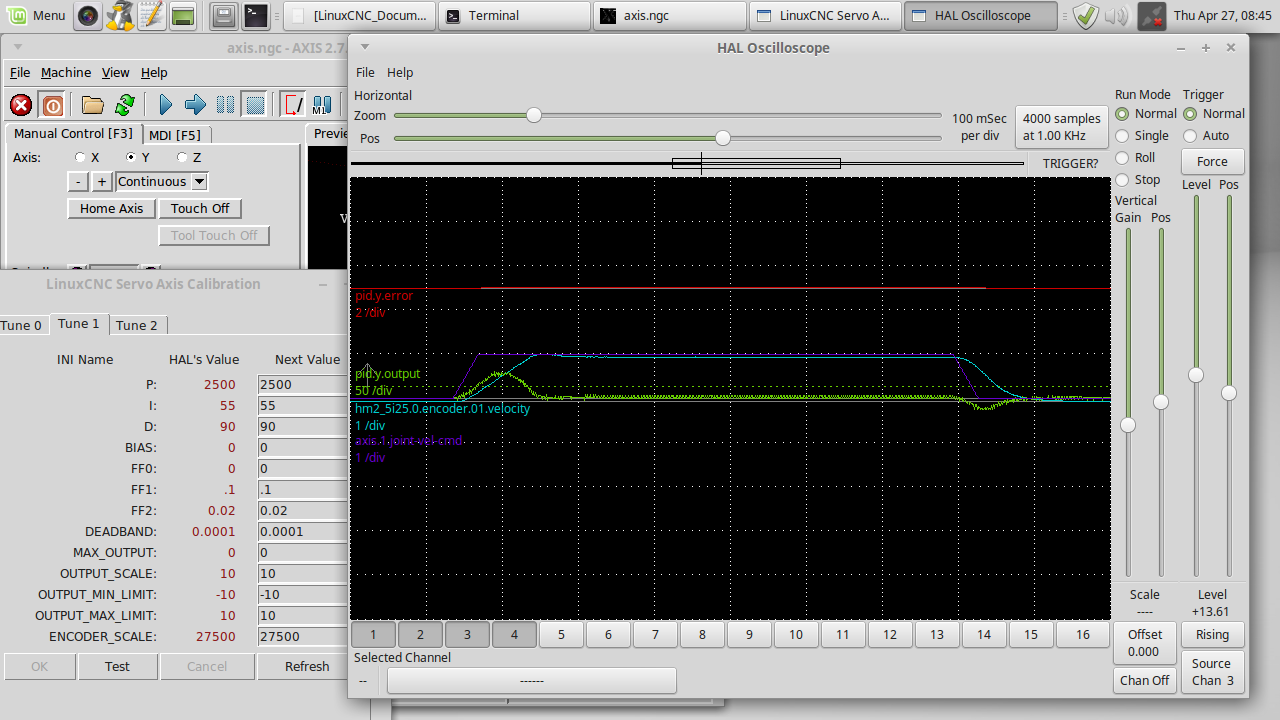
Is the thinking is to have as much "of the other 3 trace" as possible under the "joint-vel-cmd" trace. With as small amount of "encoder.01.velocity" as possible, to push past. What am I looking for in the trace? All suggestions are welcomed.
many thanks for all the help!
After reading more about 2nd loop, my thinking is to make shore I have tried all combinations 1st. Attached is a better trace for the heavy axes "y", I think the correct pins are referenced in the scope trace elements, ""listed as: pid.y.error; pid.y.output; encoder.01.velocity; jount-vel-cmd""
Is the thinking is to have as much "of the other 3 trace" as possible under the "joint-vel-cmd" trace. With as small amount of "encoder.01.velocity" as possible, to push past. What am I looking for in the trace? All suggestions are welcomed.
many thanks for all the help!
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
9 years 6 months ago #92218
by Todd Zuercher
Replied by Todd Zuercher on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
In your hal scope plot you will want to increase the gain on the pid.N.error so that you can actually see what is going on. You are looking for micron sized errors. So your current gain setting of 2 (inches?) per division is all but useless. So select channel 1 (your pid.y.error) and slide the gain slider up until the error spikes fill the screen.
Your goal is to minimize those errors and get the encoder velocity trace to match the joint-vel-cmd as closely as possible. More FF2 can help some with your error spikes during acceleration/deceleration.
Your goal is to minimize those errors and get the encoder velocity trace to match the joint-vel-cmd as closely as possible. More FF2 can help some with your error spikes during acceleration/deceleration.
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
9 years 6 months ago #92223
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Many Thanks!
I have worked on these for a while, the "encoder.00.velocity" trace is as close as I have seen to tracking the "joint-vel-cmd". Does this look acceptable? jog feed is 60"/min. I can see the slower the feed the less chance for error.
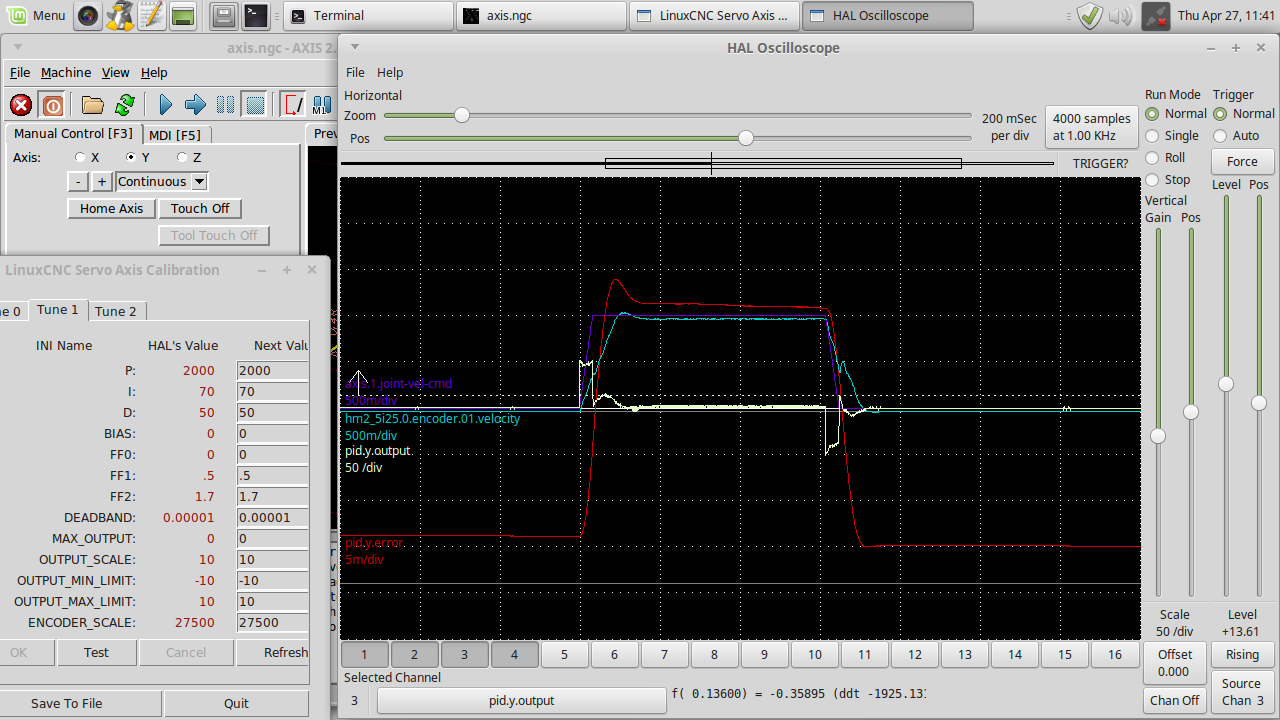
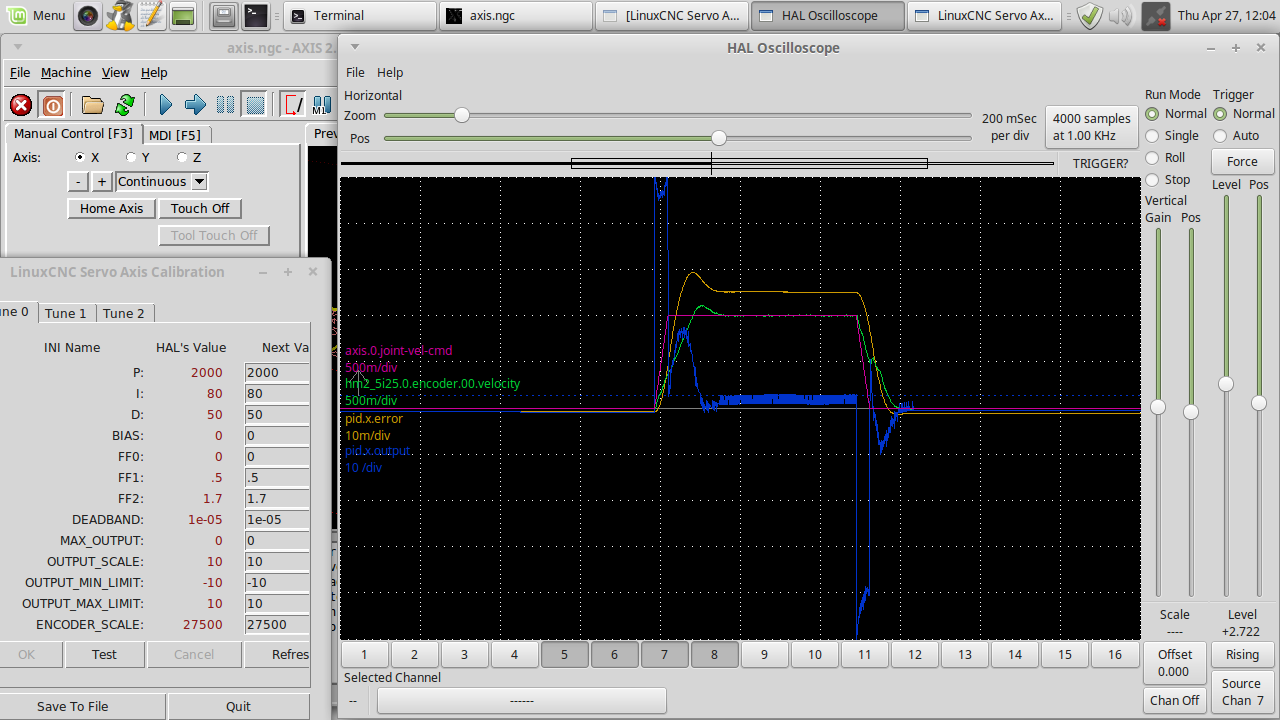
I tried FF2 all the way to 10; P all the way to 9000; I & D to 90. I will try more if this is not close enough or there is more tuning to do.
Many, many thanks!!
I have worked on these for a while, the "encoder.00.velocity" trace is as close as I have seen to tracking the "joint-vel-cmd". Does this look acceptable? jog feed is 60"/min. I can see the slower the feed the less chance for error.
I tried FF2 all the way to 10; P all the way to 9000; I & D to 90. I will try more if this is not close enough or there is more tuning to do.
Many, many thanks!!
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
9 years 6 months ago - 9 years 6 months ago #92231
by Todd Zuercher
Replied by Todd Zuercher on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
No, not there yet. You want the pid.N.error to be as close to 0 as you can get it all the time. You don't want that to follow the velocity command.
In the attached screen shot notice how the following error never is more that about +/- 0.0015 (that or better is what you are after.) More P (if it doesn't make it unstable) more FF2 (until you start to see too much overshoot).
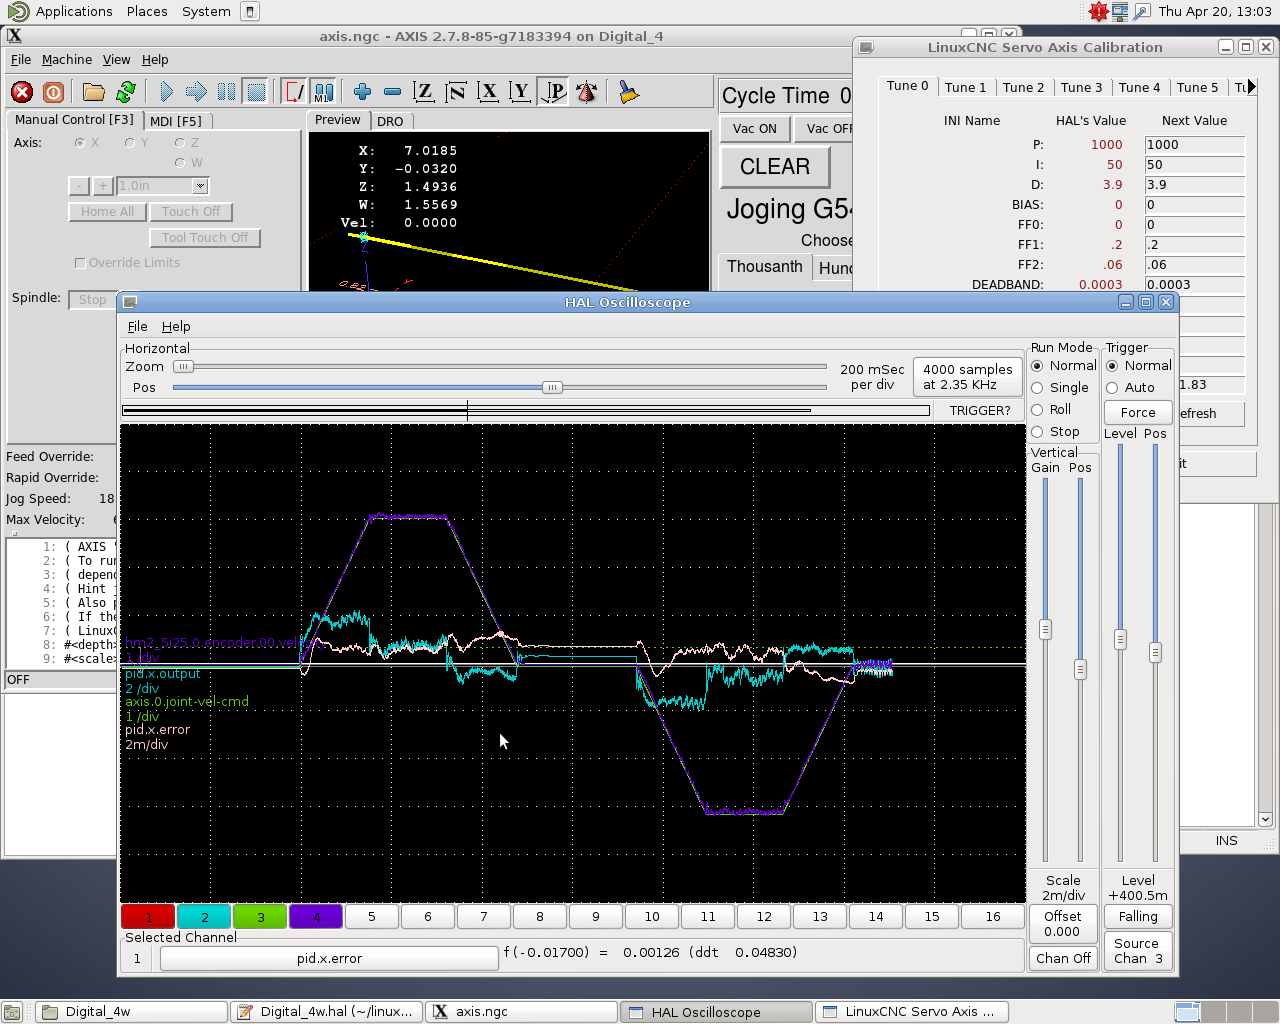
In the attached screen shot notice how the following error never is more that about +/- 0.0015 (that or better is what you are after.) More P (if it doesn't make it unstable) more FF2 (until you start to see too much overshoot).
Last edit: 9 years 6 months ago by Todd Zuercher.
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
9 years 6 months ago #92258
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Thank you, Todd!!
You reference, +/- .0015 this is at the bottom of the hal screen in line "= 0.00126"(ddt 0.04830) is this correct?
Thank you
You reference, +/- .0015 this is at the bottom of the hal screen in line "= 0.00126"(ddt 0.04830) is this correct?
Thank you
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
9 years 6 months ago #92260
by Todd Zuercher
Replied by Todd Zuercher on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Yes, If you click on the trace number button at the bottom of the screen, then hover the mouse over the trace, it will show you the values for that point on the trace there at the bottom of the screen.
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
Time to create page: 1.069 seconds