
- Posts: 4793
- Thank you received: 1480
Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
- Todd Zuercher
- Offline
- Platinum Member
-

Less
More
9 years 5 months ago - 9 years 5 months ago #92669
by Todd Zuercher
Replied by Todd Zuercher on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Yes, FF1 = 25 looks pretty close to right.
Now to deal with that huge spike and it's associated oscillation at start of the move. (The smaller one at the end is probably related).
I suspect too much FF2 is to blame. Try FF2 = 1.5.
Now to deal with that huge spike and it's associated oscillation at start of the move. (The smaller one at the end is probably related).
I suspect too much FF2 is to blame. Try FF2 = 1.5.
Last edit: 9 years 5 months ago by Todd Zuercher.
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
9 years 5 months ago #92670
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Thanks, Todd!
This is a group of screenshots, no order. 1.375 looks the best to me, but need to review.

Many thanks!!
This is a group of screenshots, no order. 1.375 looks the best to me, but need to review.
Many thanks!!


Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
9 years 5 months ago - 9 years 5 months ago #92671
by Todd Zuercher
Replied by Todd Zuercher on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Try FF2 = 0.
If that still looks about the same. You probably have too much P.
After that keep FF2 at 0 and start reducing P until the over shoot settles down.
Then gradually add FF2 back to try to reduce the following error during acceleration. (The final FF2 number might be quite small, FF2 is often less than 0.01)
Once you find the optimal settings for FF1 and FF2. You may be able to increase P some to stiffen the axis.
Last edit: 9 years 5 months ago by Todd Zuercher.
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
9 years 5 months ago - 9 years 5 months ago #92705
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Thanks for all the great advise, could not of gotten this far w/o all the support!!
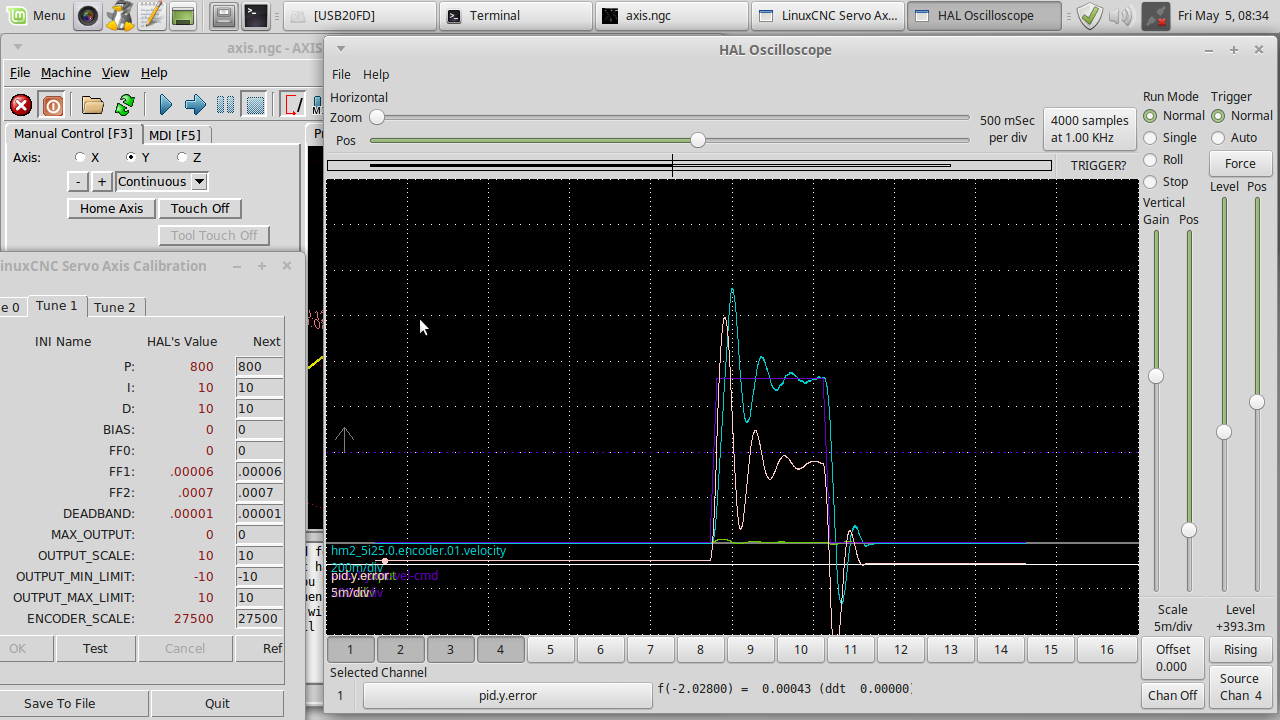
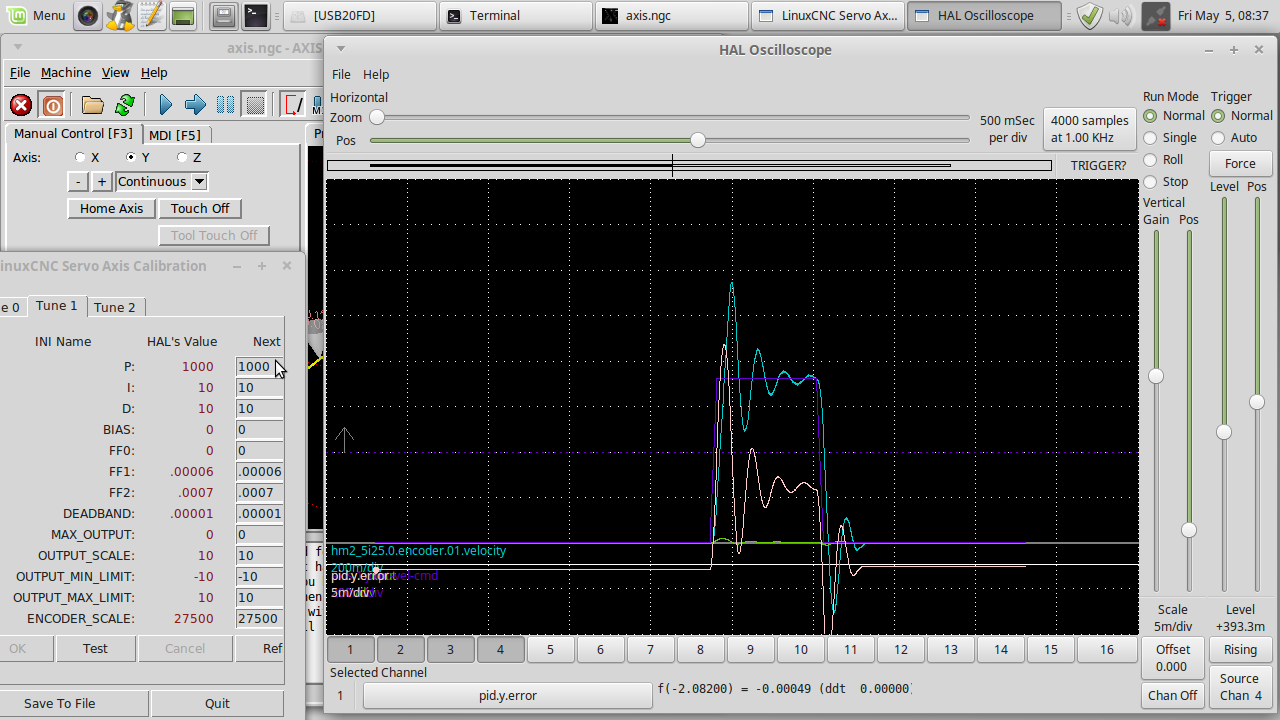
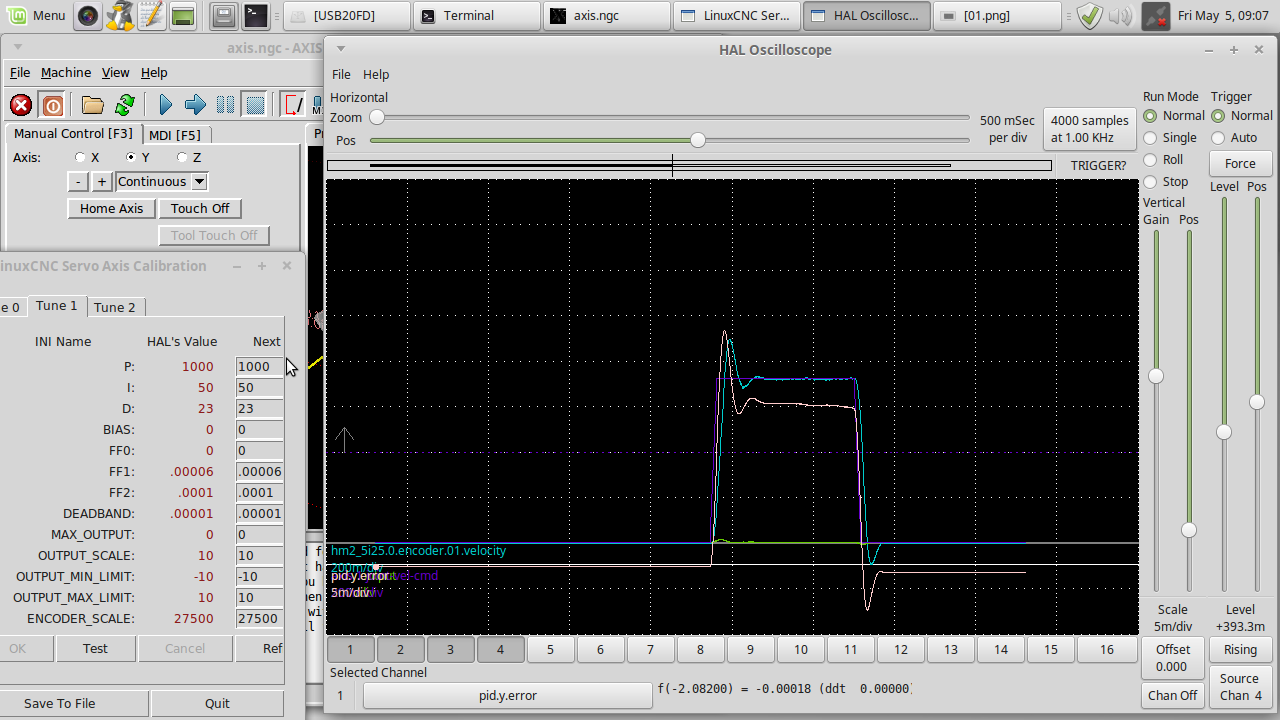
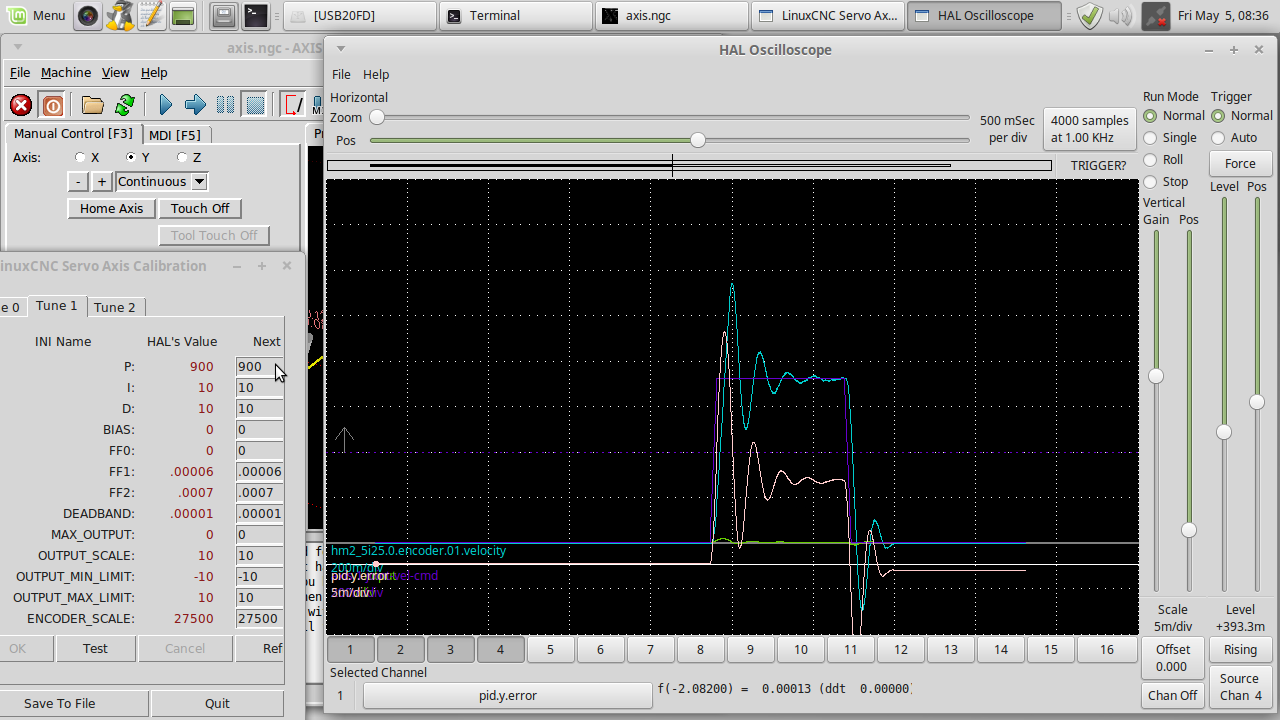
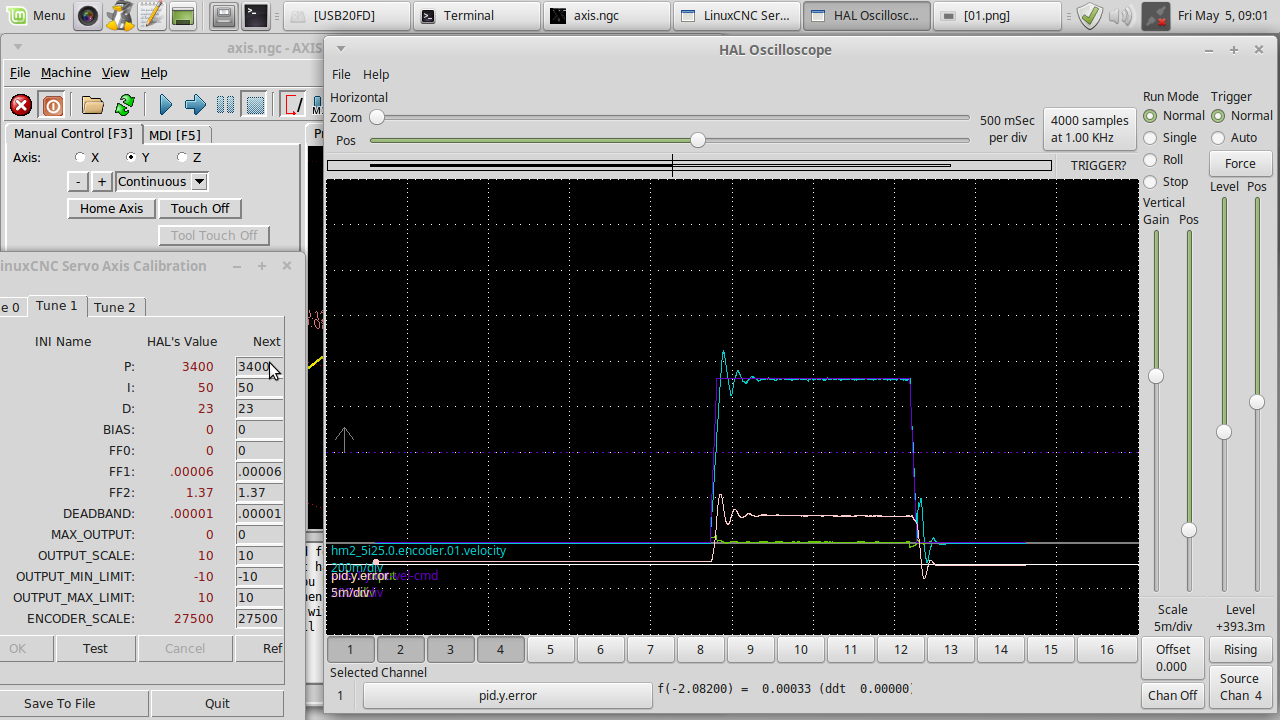
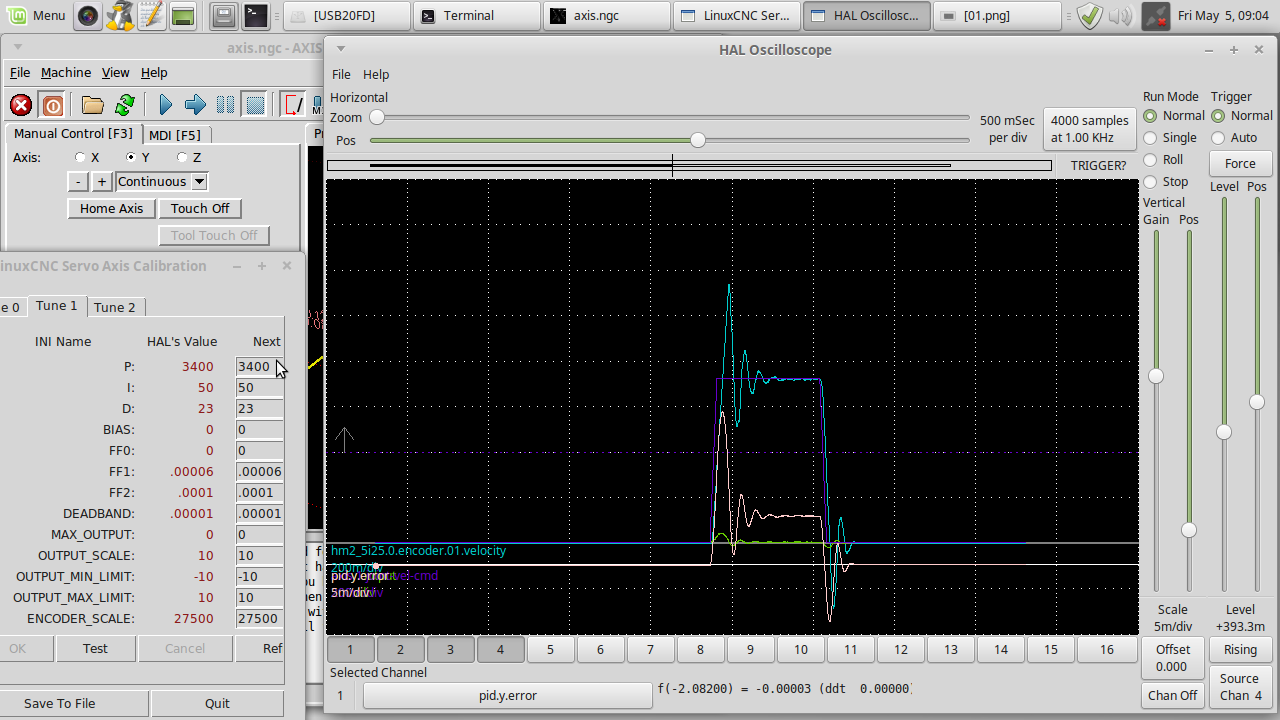
Attached are several screenshots, 01 to 03 have lower P,I,D as per Todd's suggestion, screenshot 06 to (no 08 ) 09 higher P,I,D, with the 06 the original settings with FF2=1.37. The gain has been set lower to see all of scale. Is there any more .ini tweaking required?
many thanks!
Edit: Earlier in the tuning process some reference to increase "P" until vibration or noise came from motor, it was difficult to get this to happen with my project, I have increased "P" a great amount past what this screenshot show.
Attached are several screenshots, 01 to 03 have lower P,I,D as per Todd's suggestion, screenshot 06 to (no 08 ) 09 higher P,I,D, with the 06 the original settings with FF2=1.37. The gain has been set lower to see all of scale. Is there any more .ini tweaking required?
many thanks!
Edit: Earlier in the tuning process some reference to increase "P" until vibration or noise came from motor, it was difficult to get this to happen with my project, I have increased "P" a great amount past what this screenshot show.
Last edit: 9 years 5 months ago by new2linux. Reason: clearify
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
9 years 5 months ago - 9 years 5 months ago #92706
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
This is the ini file, just trying to keep all in the same spot for reference.
many thanks!!
Edit: The duel loop, is the 2nd loop designed to limit the overshoot that is in question?
Depending on how important the "pid.n.error" is, other than the referenced (06 pic, in earlier thread) all other "pid.n.error" required "lower gain" to see on scope trace, so best yet I think.
many thanks!!
Edit: The duel loop, is the 2nd loop designed to limit the overshoot that is in question?
Depending on how important the "pid.n.error" is, other than the referenced (06 pic, in earlier thread) all other "pid.n.error" required "lower gain" to see on scope trace, so best yet I think.
Last edit: 9 years 5 months ago by new2linux. Reason: question&thought
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
9 years 5 months ago #92782
by new2linux
Replied by new2linux on topic Prototrak Plus Retrofit with Mesa 7i77 & 5i25 cards
Many thanks for all the great help!!
The following is the "x axes, the lighter one" hal trace, the 01 to 04 are FF2 in small increments. The inserted 05 has "P" to 3450, it that this to get "pis.n.error" down. There is enough stiffness at "P=2500", just fyi.
The one thing that seemed to me is that the "FF2" needs to be in the 1.0 range.
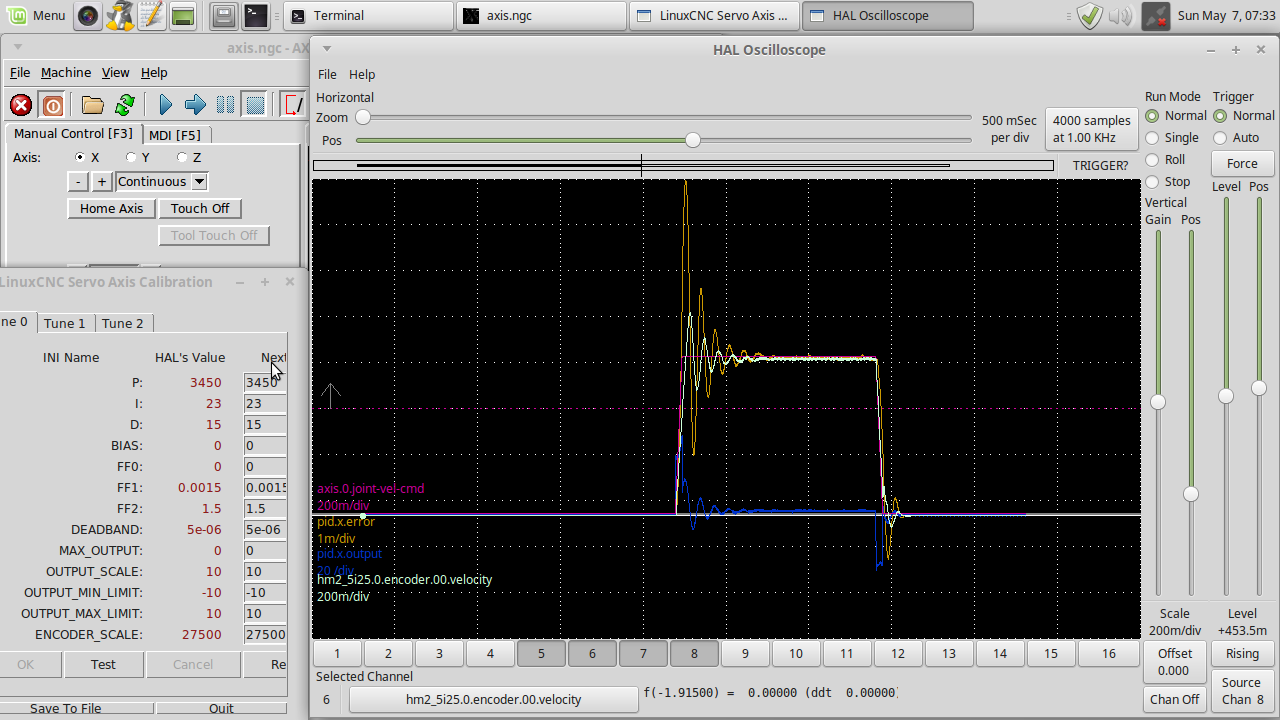
This is about as good as I know what to look for.
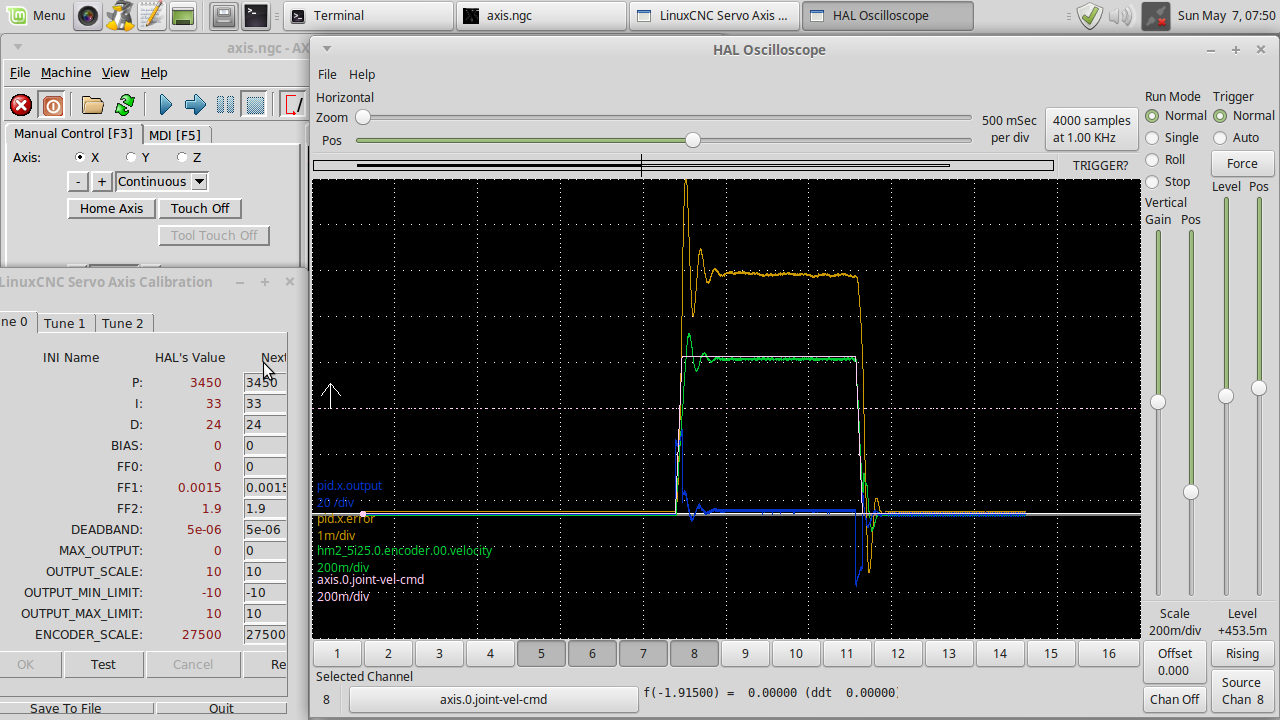
The ini file has .68 max-velocity & 17 max-acceleration. Jog at 60"/min, not shore this is correct, seems slow. Will try to post "y axes" next.
Many thanks!
The following is the "x axes, the lighter one" hal trace, the 01 to 04 are FF2 in small increments. The inserted 05 has "P" to 3450, it that this to get "pis.n.error" down. There is enough stiffness at "P=2500", just fyi.
The one thing that seemed to me is that the "FF2" needs to be in the 1.0 range.
This is about as good as I know what to look for.
The ini file has .68 max-velocity & 17 max-acceleration. Jog at 60"/min, not shore this is correct, seems slow. Will try to post "y axes" next.
Many thanks!


Please Log in or Create an account to join the conversation.
Time to create page: 7.506 seconds