
- Posts: 265
- Thank you received: 40
Retrofitting a 1986 Maho MH400E
- drimaropoylos
- Offline
- Elite Member
-

Less
More
8 years 10 months ago #102602
by drimaropoylos
Replied by drimaropoylos on topic Retrofitting a 1986 Maho MH400E
Congratulations for the successful latching of the machine. Now it is time to set the correct p,I,d, settings on linux cnc. Until you set the correct values it is normal for linuxcnc to disengage do to fallowing errors. Temporary for the tests set a larger accepted fallowing error in linuxcnc settings and keep one hand at the estop at all time.
Try the whole configuration that I have post, don’t just copy the gearchange.clp to your configuration, if it works than you can change it with the pncconf to match the wiring on your machine. If it is not working than plz post some screenshot of the error message to find a solution
John
Try the whole configuration that I have post, don’t just copy the gearchange.clp to your configuration, if it works than you can change it with the pncconf to match the wiring on your machine. If it is not working than plz post some screenshot of the error message to find a solution
John
Please Log in or Create an account to join the conversation.
- drimaropoylos
- Offline
- Elite Member
-
Less
More
- Posts: 265
- Thank you received: 40
8 years 10 months ago - 8 years 10 months ago #102603
by drimaropoylos
Replied by drimaropoylos on topic Retrofitting a 1986 Maho MH400E
During the tests don’t try to move the axis with hand, there is a possibility one axis to be reversed and just stay still until you try to move it with your hand, than the servo will run at full speed and your may loose a finger of worse.
John
John
Last edit: 8 years 10 months ago by drimaropoylos.
Please Log in or Create an account to join the conversation.
- RotarySMP
- Offline
- Platinum Member
-

Less
More
- Posts: 1635
- Thank you received: 595
8 years 10 months ago #102604
by RotarySMP
Replied by RotarySMP on topic Retrofitting a 1986 Maho MH400E
Thanks John, good idea, I'll try the full set of config files from your machine.
Do you mean putting a "not" on the end of this line?
net x-output => hm2_5i25.0.7i77.0.1.analogout0
Mark
If the encoder (DRO) reads properly, the fix is to change the sign of the analog output in HAL
Do you mean putting a "not" on the end of this line?
net x-output => hm2_5i25.0.7i77.0.1.analogout0
Mark
Please Log in or Create an account to join the conversation.
- PCW
- Offline
- Moderator
-

Less
More
- Posts: 18115
- Thank you received: 5334
8 years 10 months ago #102606
by PCW
Replied by PCW on topic Retrofitting a 1986 Maho MH400E
For the pncconf created config it would be changing
#********************
# Axis X
#********************
[AXIS_0]
...
OUTPUT_SCALE = -10.0
to
OUTPUT_SCALE = 10.0
#********************
# Axis X
#********************
[AXIS_0]
...
OUTPUT_SCALE = -10.0
to
OUTPUT_SCALE = 10.0
Please Log in or Create an account to join the conversation.
- RotarySMP
- Offline
- Platinum Member
-
Less
More
- Posts: 1635
- Thank you received: 595
8 years 10 months ago - 8 years 10 months ago #102615
by RotarySMP
Replied by RotarySMP on topic Retrofitting a 1986 Maho MH400E
Thanks, that was it.
I could then move on to PID tuning. To the guys who programmed the HAL Oscilloscope, and the calibration screens, a big thank you. So far:
#********************
# Axis X
#********************
[AXIS_0]
TYPE = LINEAR
HOME = 0.0
FERROR = 20.0
MIN_FERROR = 1.0
MAX_VELOCITY = 45
MAX_ACCELERATION = 750.0
P = 6.5
I = 0
D = 0
FF0 = 0
FF1 = 0.22
FF2 = 0.03
BIAS = 0
DEADBAND = 0
MAX_OUTPUT = 0 # shouldnt this be 10V?
ENCODER_SCALE = -1000
OUTPUT_SCALE = 10
OUTPUT_MIN_LIMIT = -10
OUTPUT_MAX_LIMIT = 10
MIN_LIMIT = -20.0
MAX_LIMIT = 380.0
HOME_OFFSET = 0.000000
HOME_SEARCH_VEL = -1.000000
HOME_LATCH_VEL = -0.500000
HOME_FINAL_VEL = 0.000000
HOME_USE_INDEX = YES
HOME_SEQUENCE = 1
returns the following performance:
100mm/min,about 0.06mm overshoot during start and stopping.
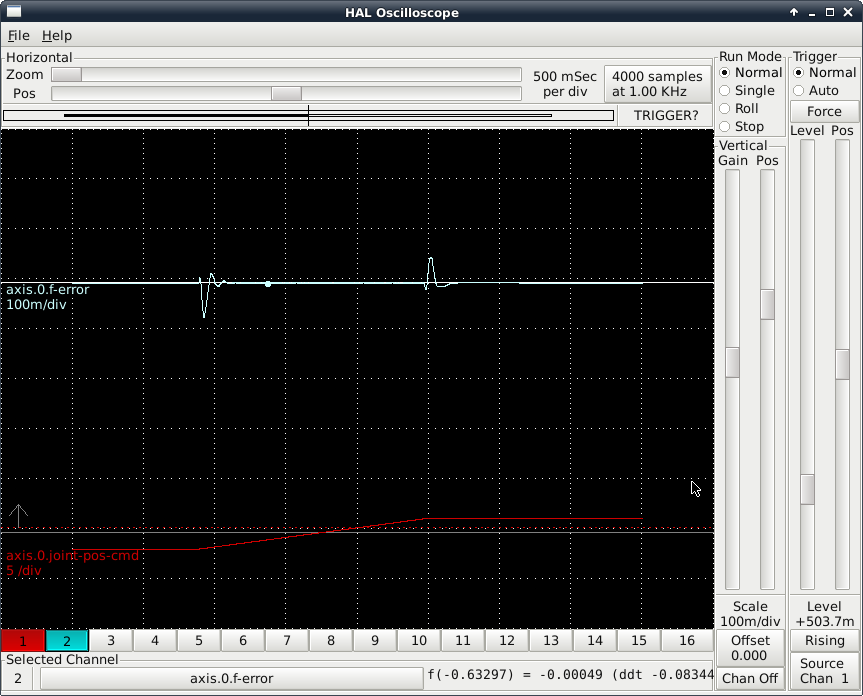
500mm/min - Still about 0.1mm oversoots, but will a little more hunting.
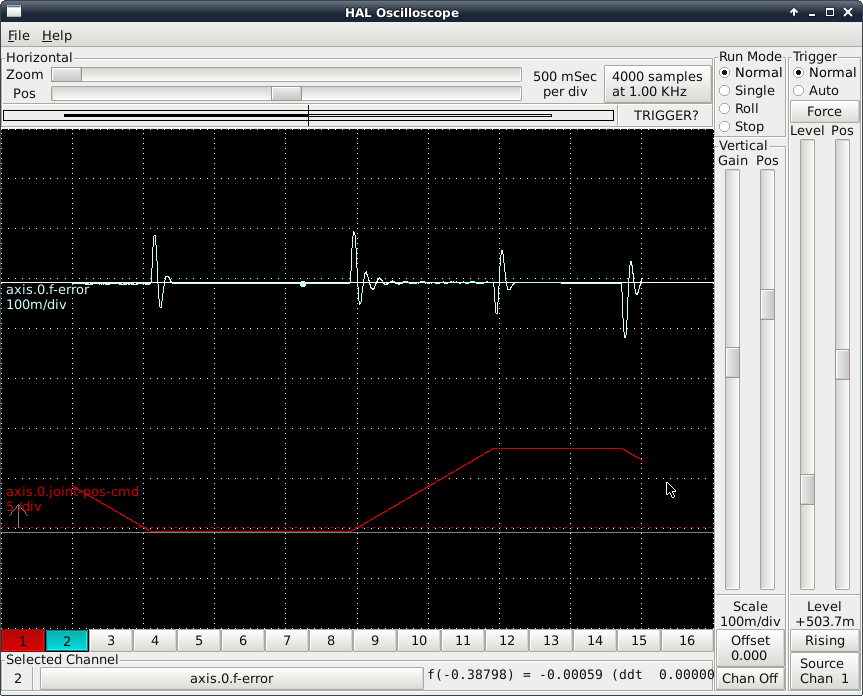
1000mm/min - Overshoots now up to 0.3mm, with two overshoots.

2000mm/min - Errors up to 0.6mm.
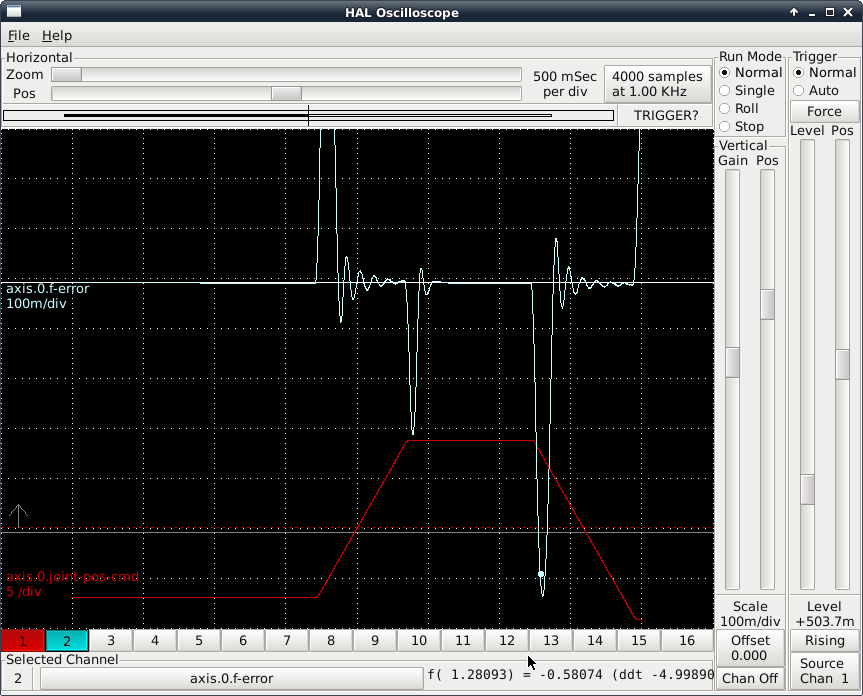
I have been working through this #how-to"
www.wiki.eusurplus.com/index.php?title=Category:Tuning
In test 7 he states, "And finally the tuned system response:" but it is not clear to me what was done here.
I could then move on to PID tuning. To the guys who programmed the HAL Oscilloscope, and the calibration screens, a big thank you. So far:
#********************
# Axis X
#********************
[AXIS_0]
TYPE = LINEAR
HOME = 0.0
FERROR = 20.0
MIN_FERROR = 1.0
MAX_VELOCITY = 45
MAX_ACCELERATION = 750.0
P = 6.5
I = 0
D = 0
FF0 = 0
FF1 = 0.22
FF2 = 0.03
BIAS = 0
DEADBAND = 0
MAX_OUTPUT = 0 # shouldnt this be 10V?
ENCODER_SCALE = -1000
OUTPUT_SCALE = 10
OUTPUT_MIN_LIMIT = -10
OUTPUT_MAX_LIMIT = 10
MIN_LIMIT = -20.0
MAX_LIMIT = 380.0
HOME_OFFSET = 0.000000
HOME_SEARCH_VEL = -1.000000
HOME_LATCH_VEL = -0.500000
HOME_FINAL_VEL = 0.000000
HOME_USE_INDEX = YES
HOME_SEQUENCE = 1
returns the following performance:
100mm/min,about 0.06mm overshoot during start and stopping.
500mm/min - Still about 0.1mm oversoots, but will a little more hunting.
1000mm/min - Overshoots now up to 0.3mm, with two overshoots.
2000mm/min - Errors up to 0.6mm.
I have been working through this #how-to"
www.wiki.eusurplus.com/index.php?title=Category:Tuning
In test 7 he states, "And finally the tuned system response:" but it is not clear to me what was done here.
Last edit: 8 years 10 months ago by RotarySMP.
Please Log in or Create an account to join the conversation.
- PCW
- Offline
- Moderator
-
Less
More
- Posts: 18115
- Thank you received: 5334
8 years 10 months ago #102616
by PCW
Replied by PCW on topic Retrofitting a 1986 Maho MH400E
It look like the acceleration is set much higher than the machine can follow
( there should be a visible parabolic corner on the position trace during acceleration but it looks like a sharp corner )
( there should be a visible parabolic corner on the position trace during acceleration but it looks like a sharp corner )
The following user(s) said Thank You: RotarySMP
Please Log in or Create an account to join the conversation.
Moderators: piasdom
Time to create page: 0.724 seconds