
- Posts: 711
- Thank you received: 9
Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
- new2linux
- Offline
- Platinum Member
-

Less
More
6 years 3 weeks ago #185128
by new2linux
Replied by new2linux on topic Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
Todd, many thanks! This pic shows the current set up using only the channel 1 (N.joint-vel-cmd)& channel 4(hm2-5i25.0.encoder.00.velocity); all others are off, this is the "x" axis only. I need to make these trace look as close as possible to each other, this at approx 40'/min, as in pic. When I start y axis, will have values in the low P (just like this), with low feed rate, work up to 40"/min.
many thanks!
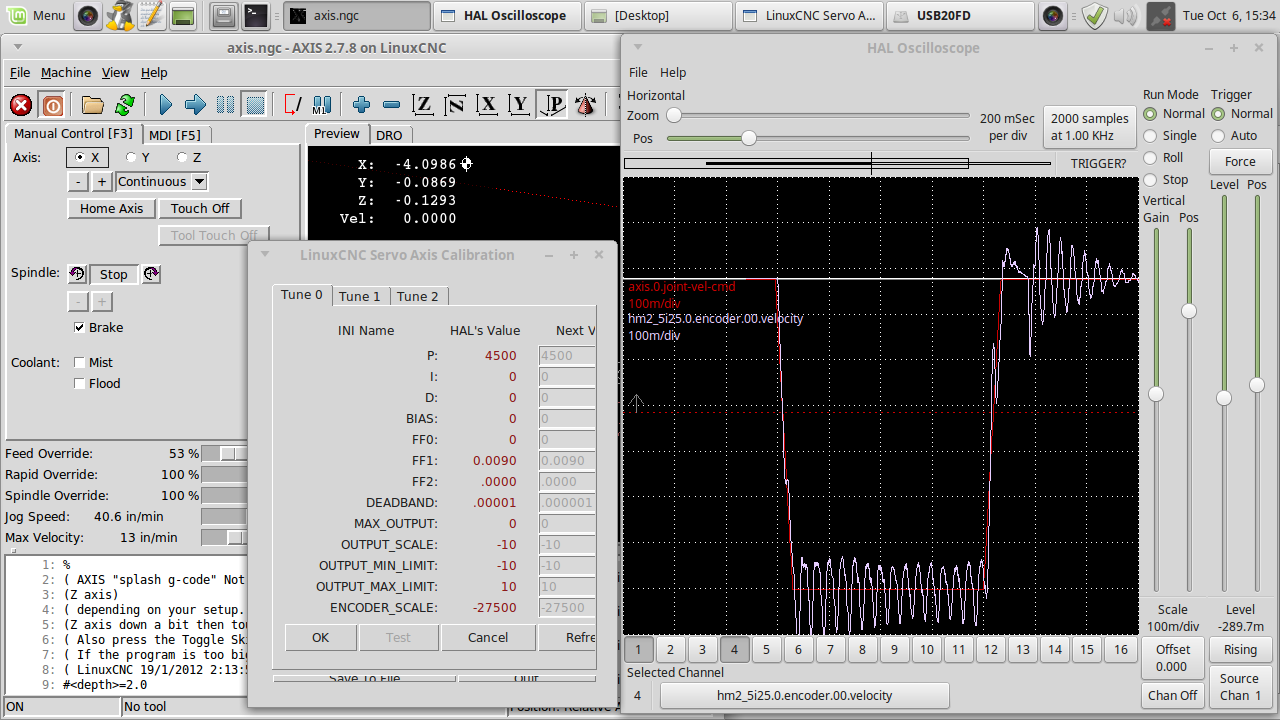
From tommylight post: Example:
say the 0.5 value had a slower rise or fall of the f-error line on the scope, put 0.4 and test again. If the move of the f-error line was slower, lower it a bit more say 0.3 and test again, it it was faster, increase it a bit to 0.45 and test again.
End of example
Am I to look at the height of the line or the amount it goes above the reference line?
many thanks!
From tommylight post: Example:
say the 0.5 value had a slower rise or fall of the f-error line on the scope, put 0.4 and test again. If the move of the f-error line was slower, lower it a bit more say 0.3 and test again, it it was faster, increase it a bit to 0.45 and test again.
End of example
Am I to look at the height of the line or the amount it goes above the reference line?
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
6 years 3 weeks ago #185136
by Todd Zuercher
Replied by Todd Zuercher on topic Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
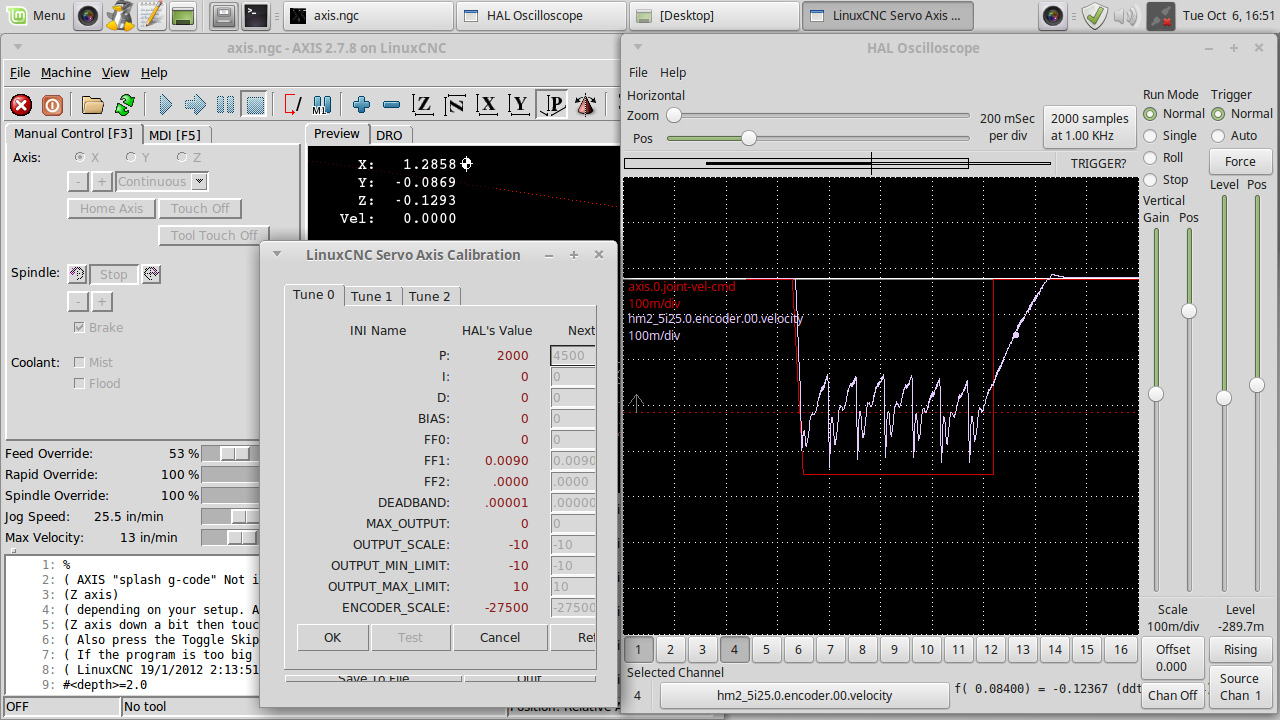
Still too much P, You're trying to get rid of those oscillations. What does it look like with P=2000?
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
6 years 3 weeks ago - 6 years 3 weeks ago #185139
by new2linux
Replied by new2linux on topic Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
This is most recent, 46.7"/min. some how the original text from this post may not appear.
many thanks!
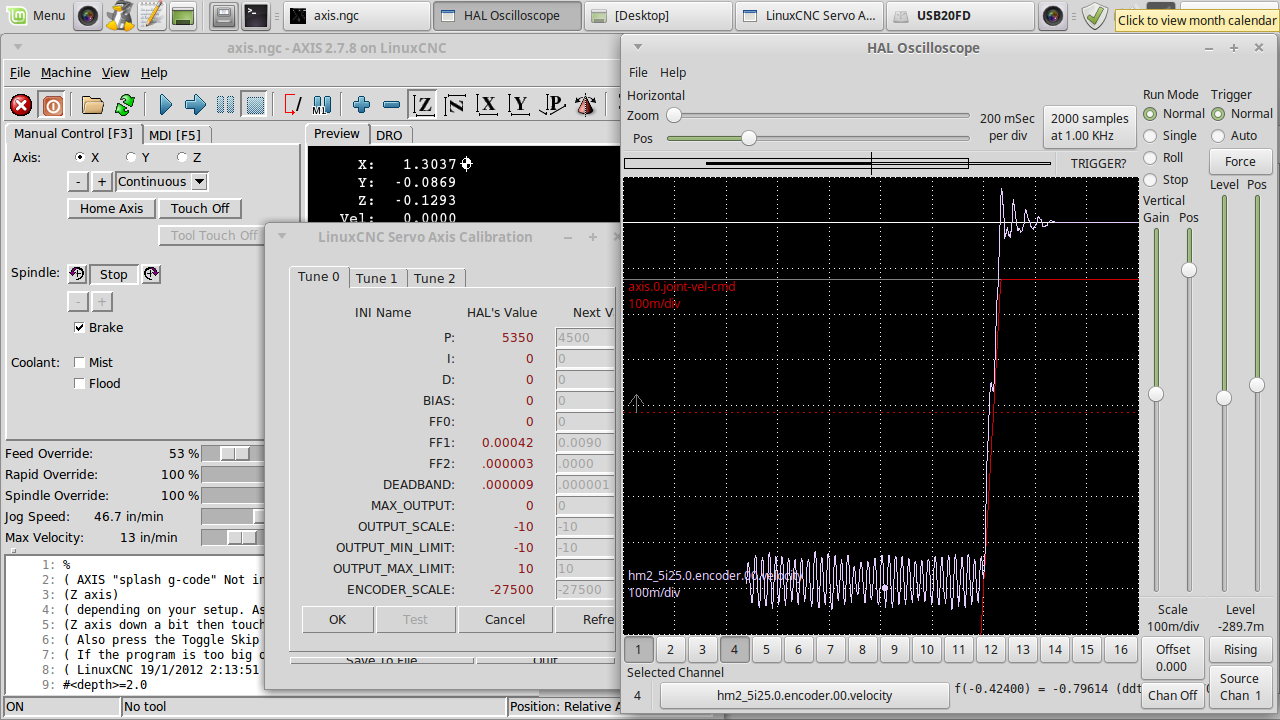

many thanks!
Last edit: 6 years 3 weeks ago by new2linux. Reason: add pic; EDIT; P=5350 Edit:Removed pic.
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
6 years 3 weeks ago #185237
by Todd Zuercher
Replied by Todd Zuercher on topic Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
Ok, now with P set to 2000, increase the FF1 until the average velocity feedback matches the commanded velocity during the cruse part of the move.
You need to dial in the feed forwards better before cranking up the P. When the P is set very high it makes it very hard to see what the feed forward terms are doing as you tune them.
The cyclic error during cruse is a little disappointing. Can you describe the mechanics of the axis? Also the drive may need better tuning. Is the drive receiving any form of feedback from the motor for calculating velocity (tach, encoder)?
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
- new2linux
- Offline
- Platinum Member
-
Less
More
- Posts: 711
- Thank you received: 9
6 years 3 weeks ago - 6 years 3 weeks ago #185257
by new2linux
Replied by new2linux on topic Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
Todd, Thank you. The pic shows the setting as per prior post, need to verify is this ok. The feed is low (10"/min), if I set it higher will have joint error. This axis is the "x" axis of Bridgeport Mill. The motors have encoders (2000 count seems correct) built in. Will it help to add the other channels?
Many thanks!
Edit: When testing axis in question I only compare (or take pic) if the direction is the same (facing machine "x axis" moves to the left) as the other tests.
Many thanks!
Edit: When testing axis in question I only compare (or take pic) if the direction is the same (facing machine "x axis" moves to the left) as the other tests.

Last edit: 6 years 3 weeks ago by new2linux.
Please Log in or Create an account to join the conversation.
- Todd Zuercher
- Offline
- Platinum Member
-
Less
More
- Posts: 4793
- Thank you received: 1480
6 years 3 weeks ago #185263
by Todd Zuercher
Replied by Todd Zuercher on topic Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier
Yes, showing the f-error and the PID output could be helpful.
Is the servo drive receiving any form of feedback from the motor?
Is the servo drive receiving any form of feedback from the motor?
The following user(s) said Thank You: new2linux
Please Log in or Create an account to join the conversation.
Time to create page: 2.872 seconds