HURCO KMB-1 Control Update

More
1 year 8 months ago - 1 year 8 months ago #321843 by NT4Boy
Replied by NT4Boy on topic HURCO KMB-1 Control Update
Homing is now driving out to the limit switches.
I've set x axis (joint(0):-
HOME_SEQUENCE = 2
HOME_SEARCH_VEL = -100
HOME_LATCH_VEL = 10
HOME_USE_INDEX = YES
HOME_OFFSET = 5.08
HOME = 25.4
But not returning to the index.


Thanks
Last edit: 1 year 8 months ago by NT4Boy. Reason: Typo in hal fixed.

Please Log in or Create an account to join the conversation.
More
1 year 8 months ago #321864 by NT4Boy
Replied by NT4Boy on topic HURCO KMB-1 Control Update
It helps if I spell HOME_SEARCH_VEL correctly.
So, pressing home, the axis travels to the minus limit, where is stops with an error.

I think the relevant hal lines are.:-

net x-home-sw <= hm2_7i92.0.encoder.03.input-a
(I have 5volt limit switches, so I have then connected to unused encoder pins)
net x-index-enable joint.0.index-enable <=> hm2_7i92.0.encoder.00.index-enable
net x-home-sw => joint.0.home-sw-in
net x-home-sw => joint.0.neg-lim-sw-in
net x-home-sw => joint.0.pos-lim-sw-in
Quite confused about why its hitting the limit switch as an end of travel, but not using that as the home trip, and returning to the encoder index.
Appreciate any thoughts.
Thanks

Please Log in or Create an account to join the conversation.
More
1 year 8 months ago - 1 year 8 months ago #322084 by NT4Boy
Replied by NT4Boy on topic HURCO KMB-1 Control Update
In fact there is nothing much wrong with the hal and ini entries,
HOME_OFFSET = 25.4
HOME = 0
I understand these better now, and to have the machine Home position at 0.0 25.4mm away from the limit switch after the encoder index has registered was my intention.
But even after I have tuned the axis I cannot get a successful home.
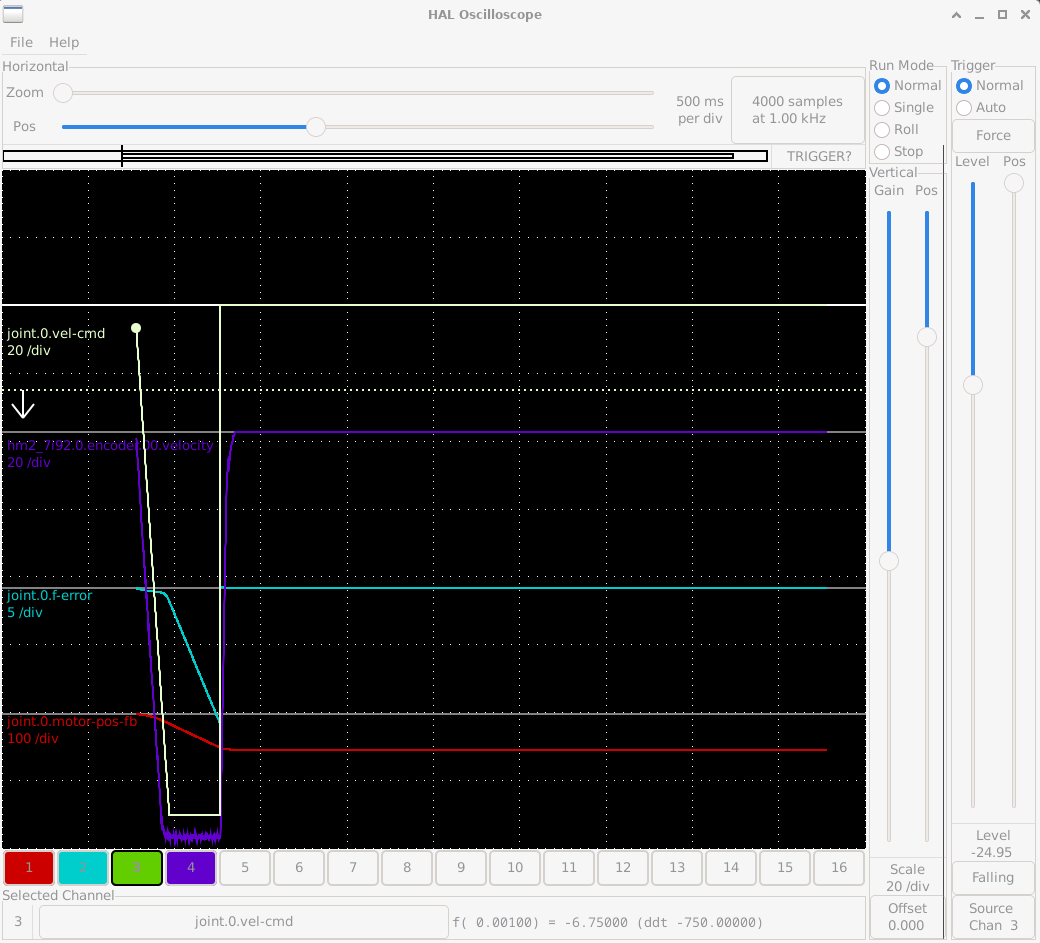
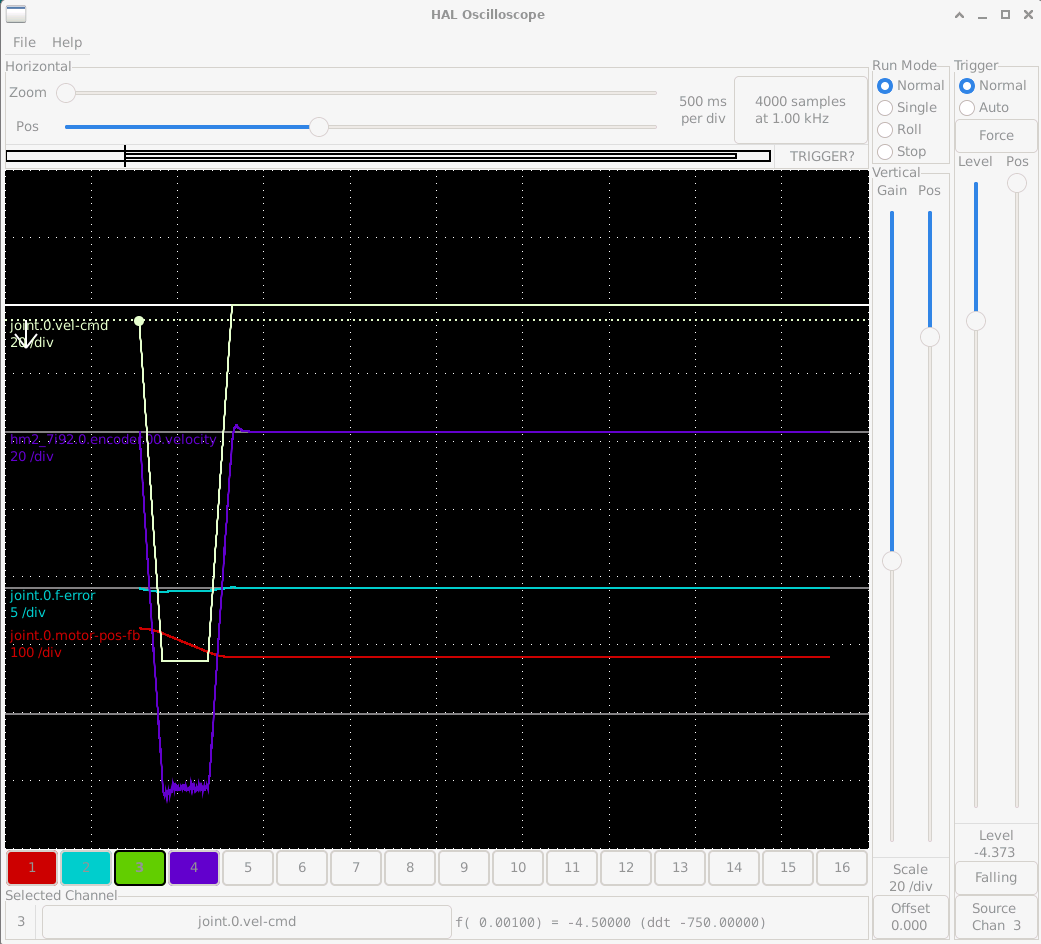
It has however stopped parking on the limit switch, but but can generate a big joint following error. The Rapid Halscope image, is at 6350mm/min and to me from what I've learned from the tutorial is pretty good.
I've set the HAlscope f-error at 5/DIV to match the tutorials, but wonder if that's correct for a metric setup
The Home image is the follower error up to the shutdown, which shows a massive figure that I cannot reproduced with the jog buttons even at max table speed. 
Not quite making sense to me yet.
I'd appreciate some comments.
Last edit: 1 year 8 months ago by NT4Boy. Reason: Typo noticed

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago #322086 by PCW
Replied by PCW on topic HURCO KMB-1 Control Update
In the  top plot, it looks to me like you have the maximum velocity faster the the drive can go
(so the following error rapidly increases when you reach the limit)

Normally you will need to set LinuxCNCs velocity limit to 80-90% of the machine velocity at 10V
The following user(s) said Thank You: NT4Boy

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago #322088 by NT4Boy
Replied by NT4Boy on topic HURCO KMB-1 Control Update
I see what you mean.
I'll look at the numbers again, especially as I've only recently realised the INI stores velocities as mm/sec, and the GUI is in mm/min.

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago #322096 by NT4Boy
Replied by NT4Boy on topic HURCO KMB-1 Control Update
Homed...!
After getting my head around these units, then I found the max acceleration set to something monstrous I'd entered randomly in pncconf, (mildly entertained by setting so slow it looks almost drunk). Any way, the final realisatioin was looking at the position trace in halscope, expanded vertically, which showed that its goes in reverse back over the limit switch after finding the index....
Yes HOME_OFFSET needs to be negative DOH.
I had in my head that anything moving the spindle to the right is a positive number, but I think that in fact when the index is picked up, that sets a zero, and to home at zero, this point we've found has to be at -25.4 in these coordinates.
Ha

Please Log in or Create an account to join the conversation.

Time to create page: 0.097 seconds
Powered by Kunena Forum
