
- Posts: 76
- Thank you received: 27
LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
- epineh
- Offline
- Senior Member
-

Less
More
6 months 1 week ago #345862
by epineh
I think keeping the uart at 5v will save level shifting headaches, keep 24v on the machine hardware side of things. I have some PCB's turning up soon and I will try out the satellite expansions, looking forward to it
Replied by epineh on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
I was going to ask you this very question, I would lean towards RJ45, tx with a gnd twisted pair, same with rx. Otherwise a properly shielded/grounded (at the source point only) cable over a short run, possibly with a bit of passive filtering. I think if either are kept as short runs and don't go looping around a spindle drive it should be OK.I'm trying to decide on a connection for my satellites
Ethernet or Firewire Cables, 5V or 24V ?
* RJ45 is cheaper, but could be confused with Ethernet
* FireWire uses thicker cablesCheaper
* satellite boards can be built using 5V, but 24V is practical for many sensors and limit switches
* RJ45 and 5V are compatible with Mesa-SmartSerial (except for the firmware)
Does anyone have any ideas?
I think keeping the uart at 5v will save level shifting headaches, keep 24v on the machine hardware side of things. I have some PCB's turning up soon and I will try out the satellite expansions, looking forward to it
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-

Less
More
- Posts: 806
- Thank you received: 502
6 months 1 week ago #345880
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
A little preview of what’s coming soon.
This will soon allow you to create a board from the flow config,
or at least a template.
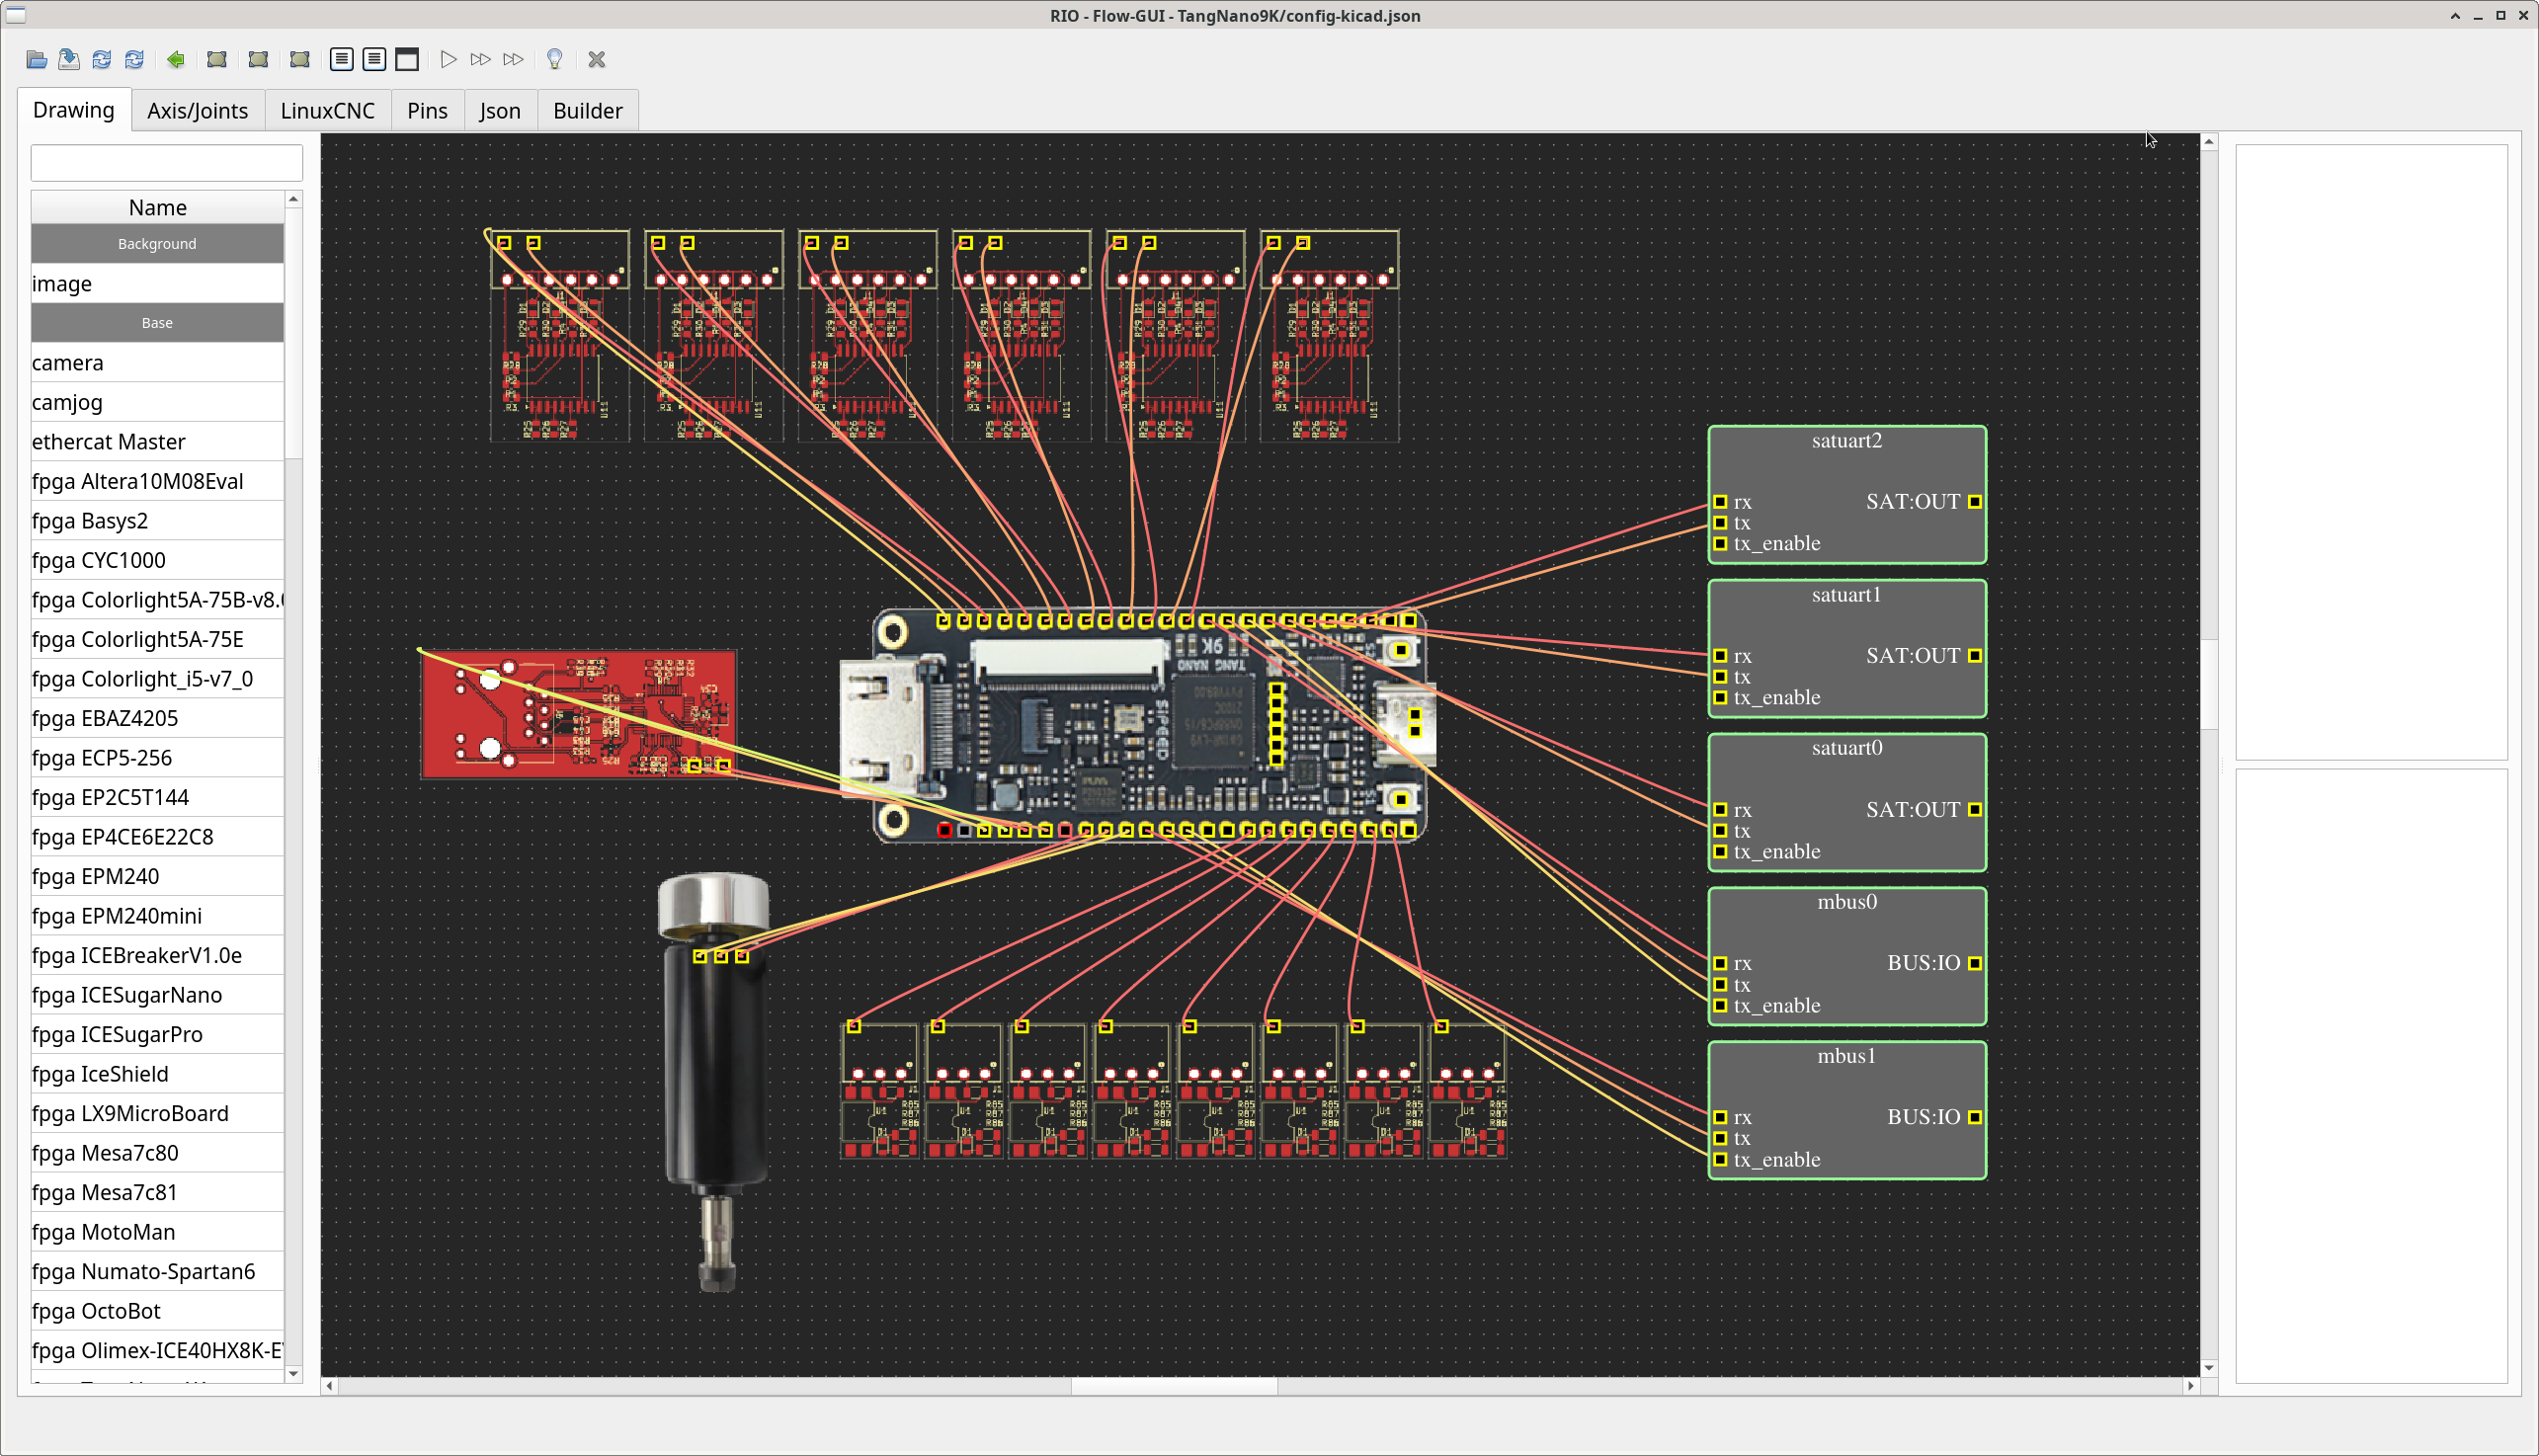
->
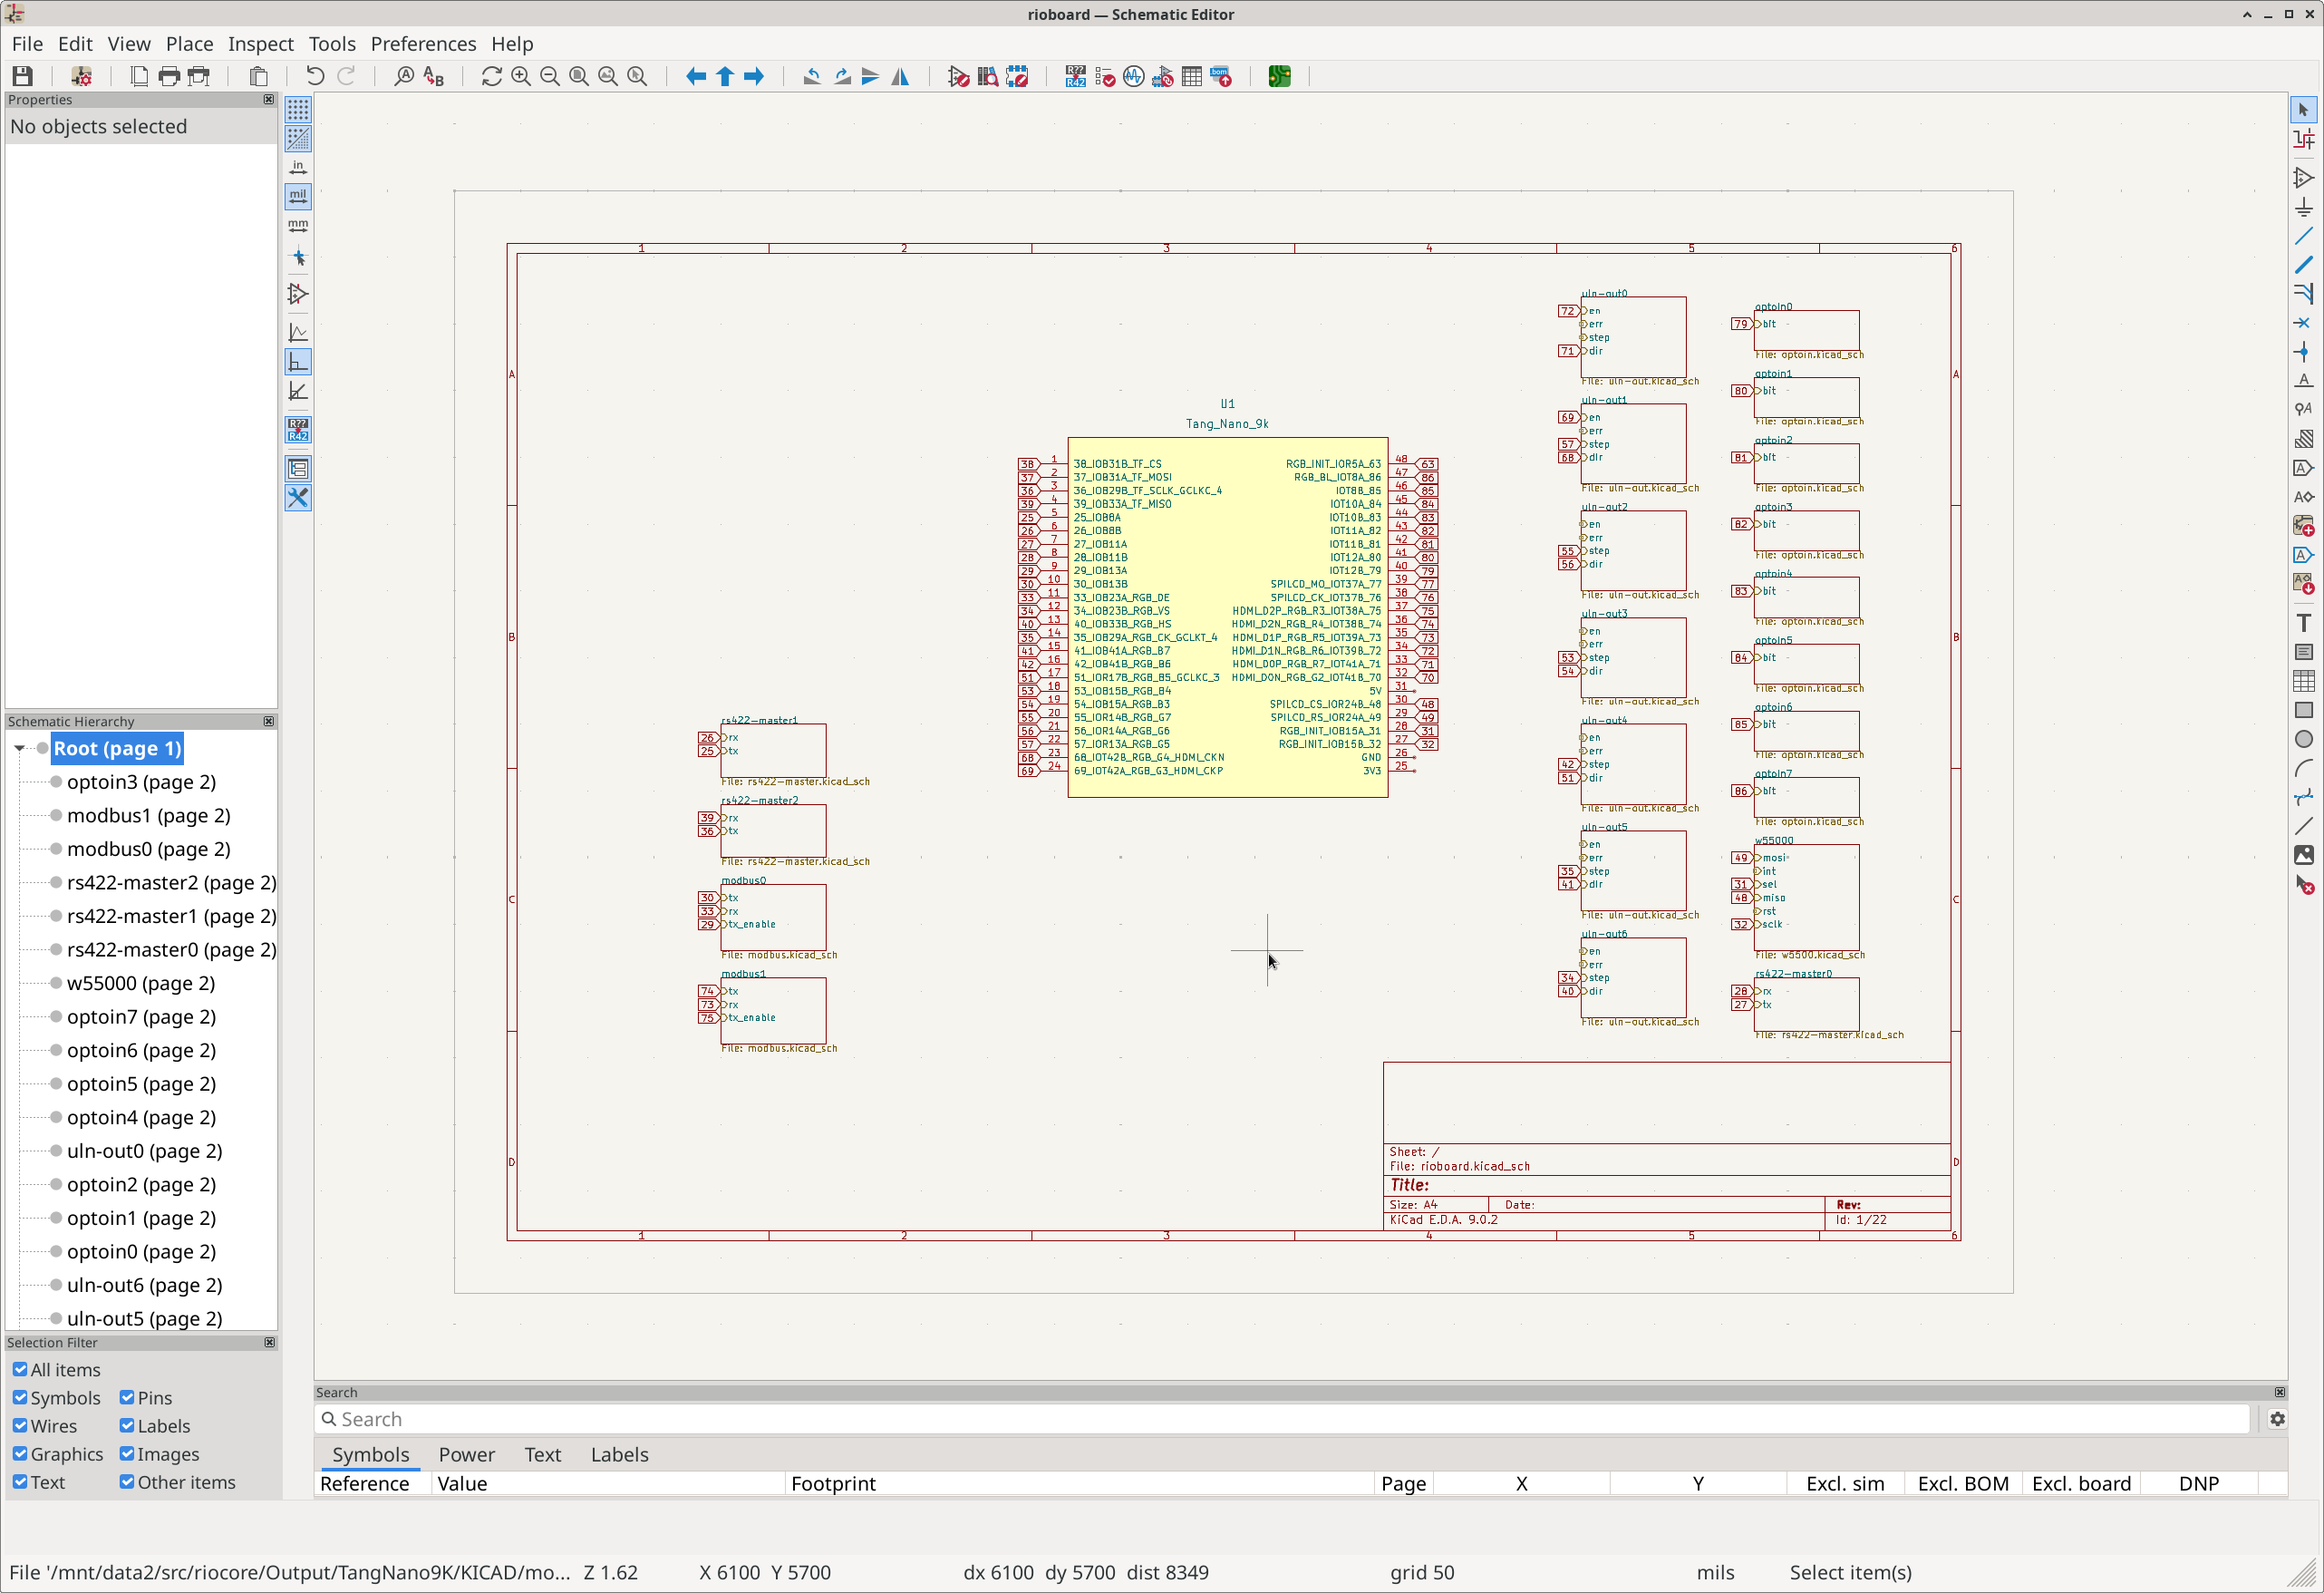
->
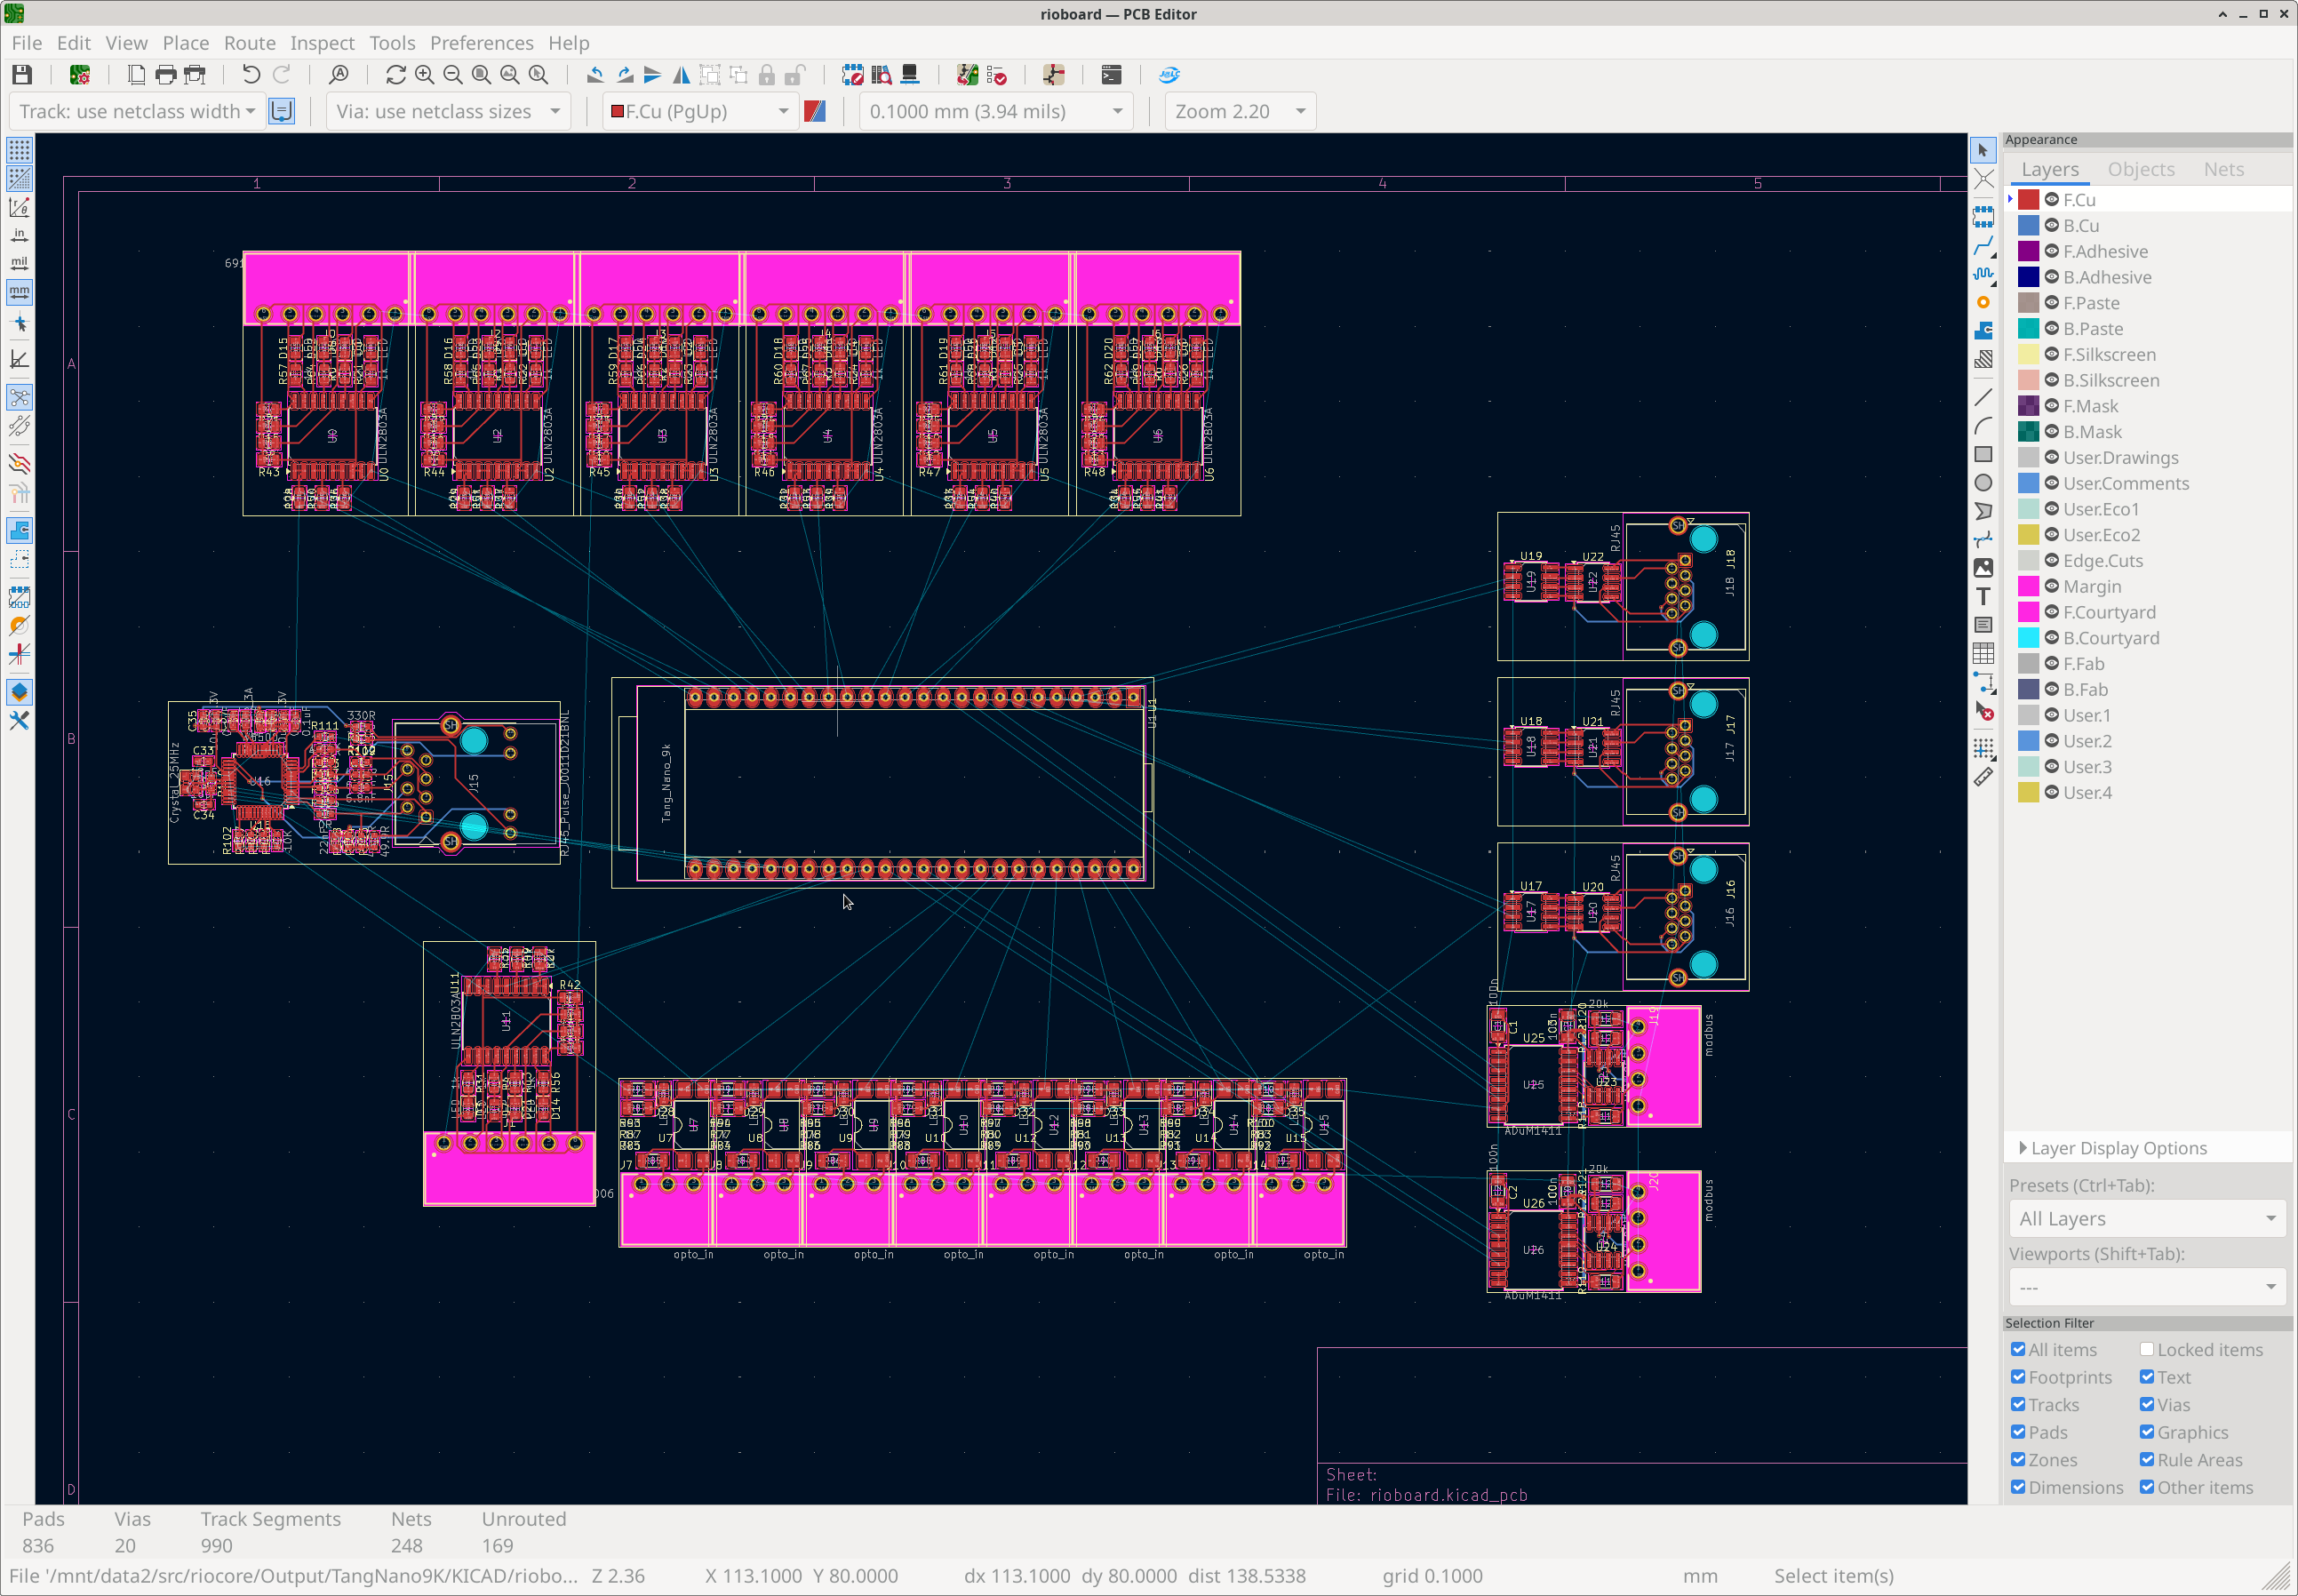
->
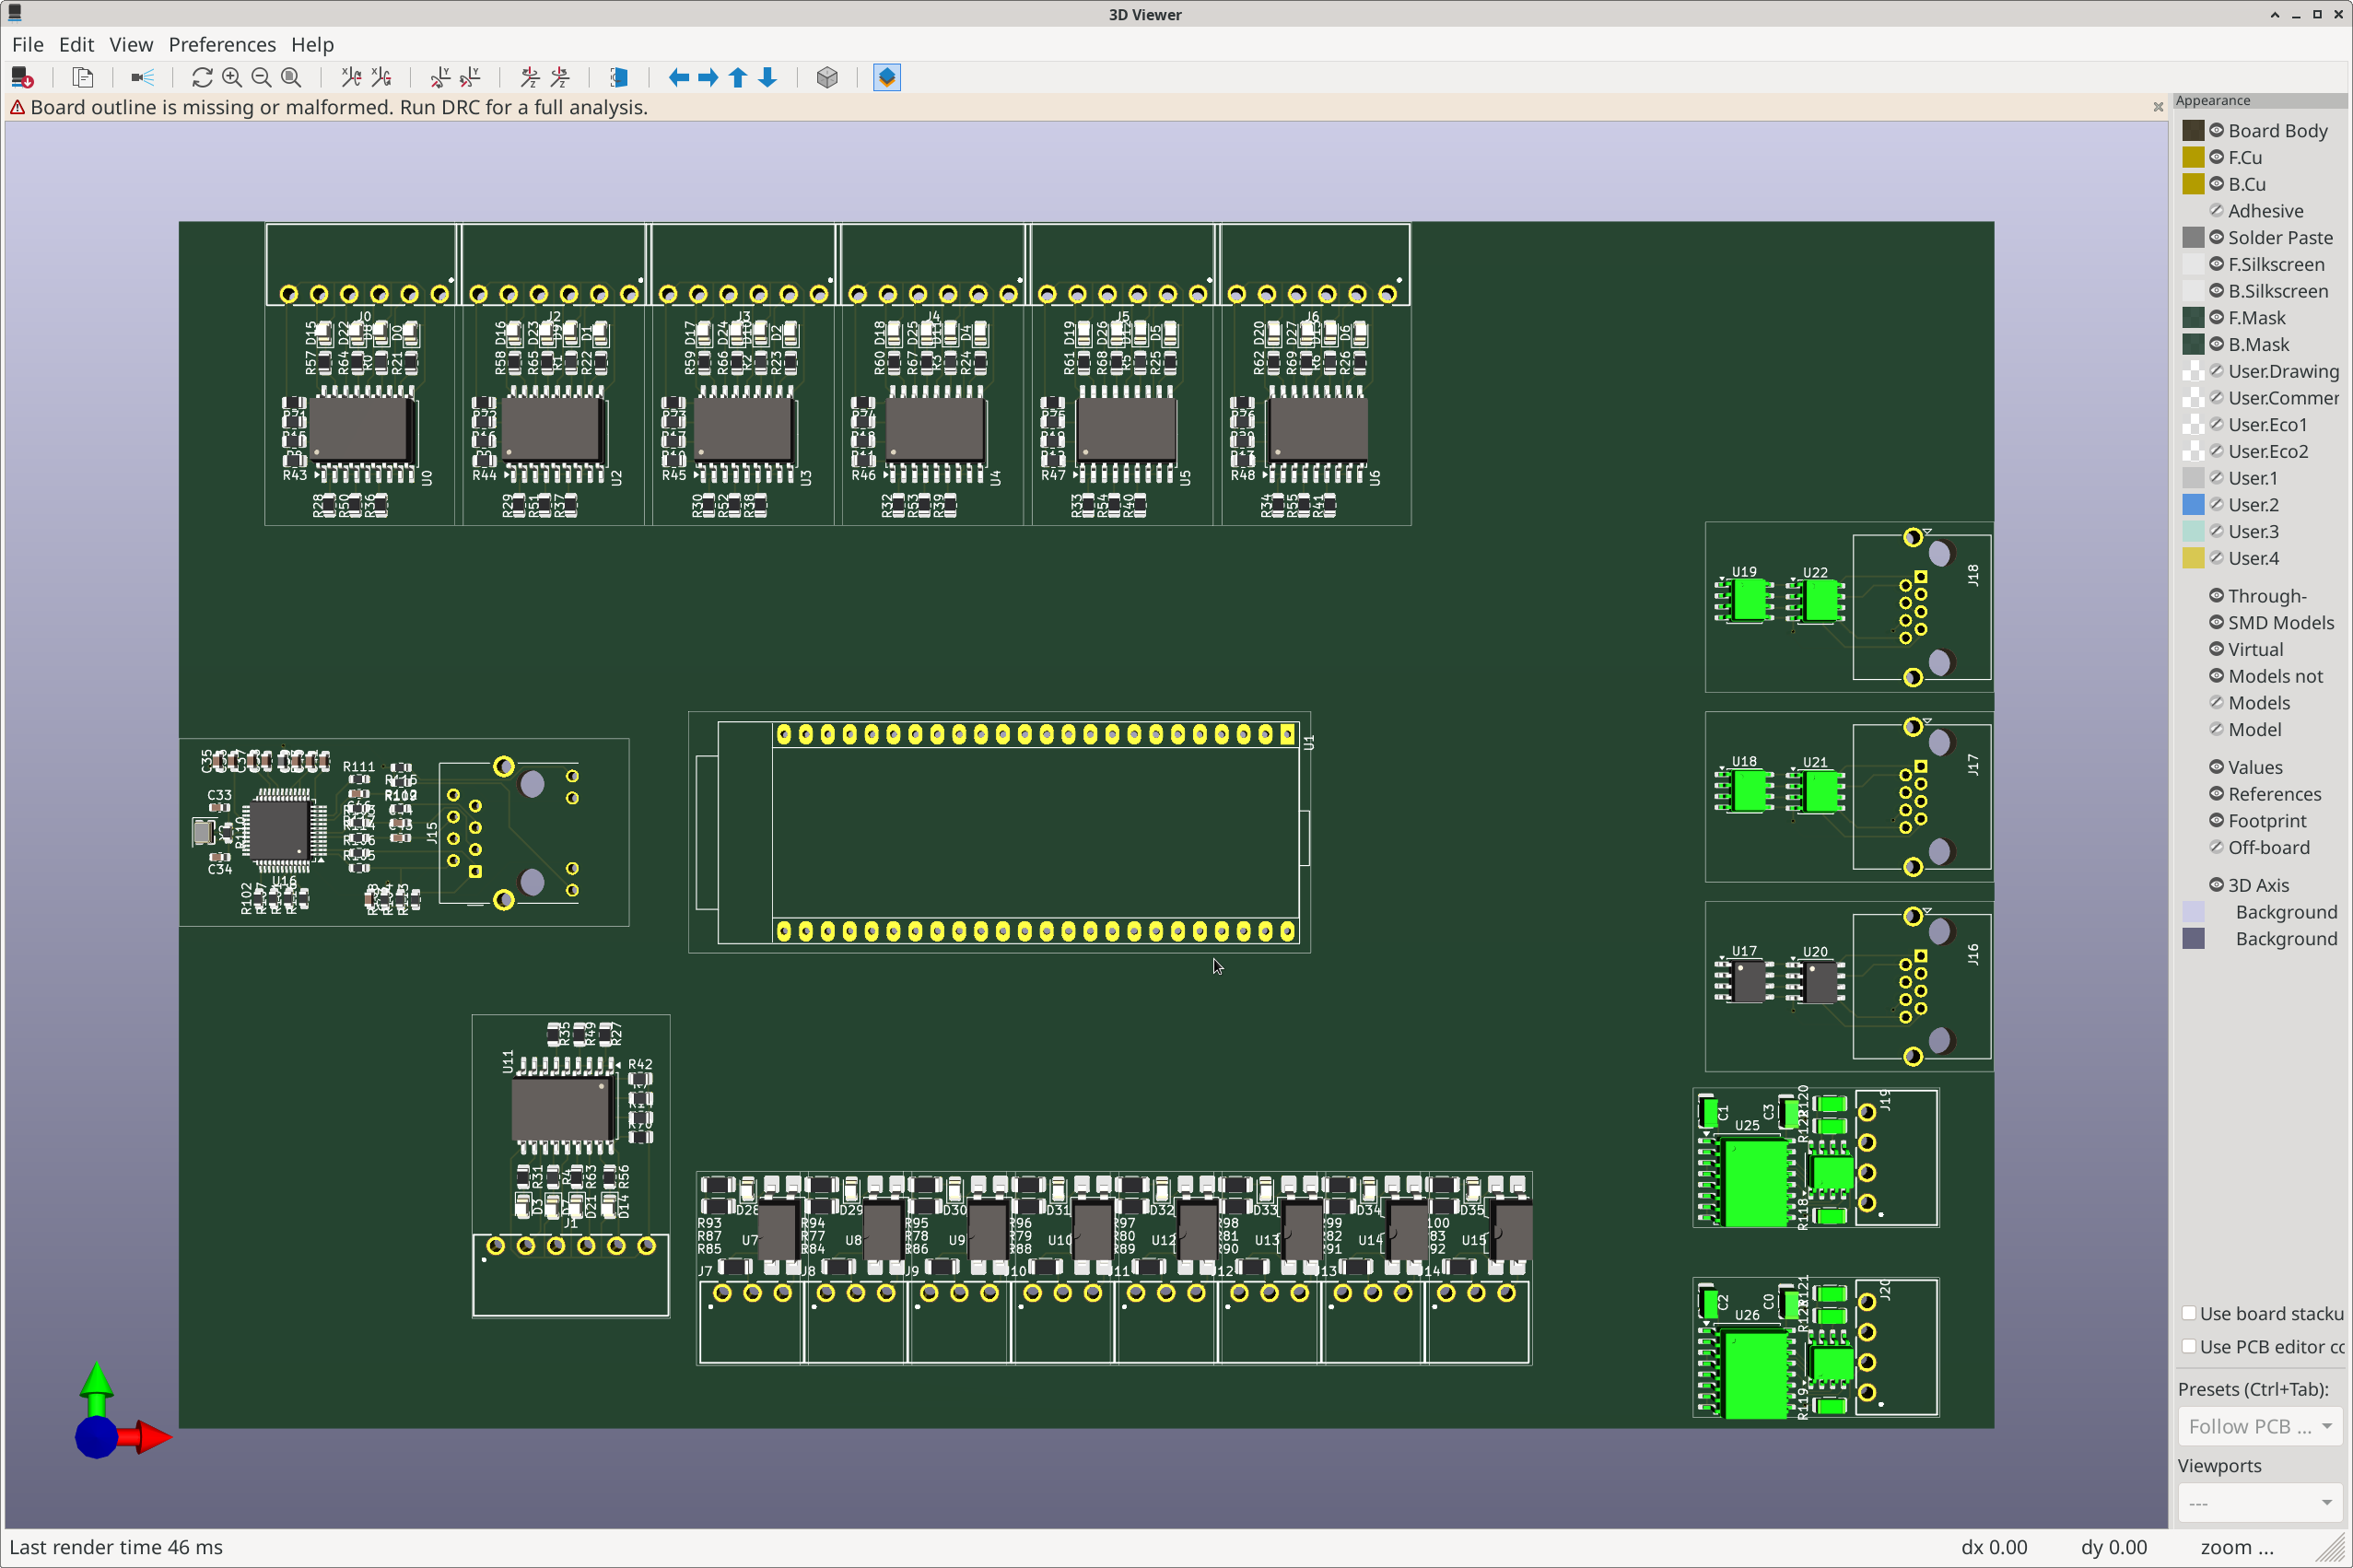
This will soon allow you to create a board from the flow config,
or at least a template.
->
->
->
The following user(s) said Thank You: tommylight, besriworld, kzali, NWE
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
Less
More
- Posts: 806
- Thank you received: 502
6 months 6 days ago #345923
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
It should be noted that Riocore can generate the gateware for the FPGA, as well as the complete LinuxCNC configuration (hal/ini/vcp).
In future, however, it will also be possible to build your own boards from this;
to this end, a KiCad template is generated, which can be turned into a complete board with relatively little effort.
already in dev branch, but still need some work:
* verify the kicad modules
* add more kicad modules
* some fixes while update the pcb
Please Log in or Create an account to join the conversation.
- Tim Bee
- Offline
- Junior Member
-

Less
More
- Posts: 31
- Thank you received: 13
5 months 1 week ago #346517
by Tim Bee
Replied by Tim Bee on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
Dear meister:
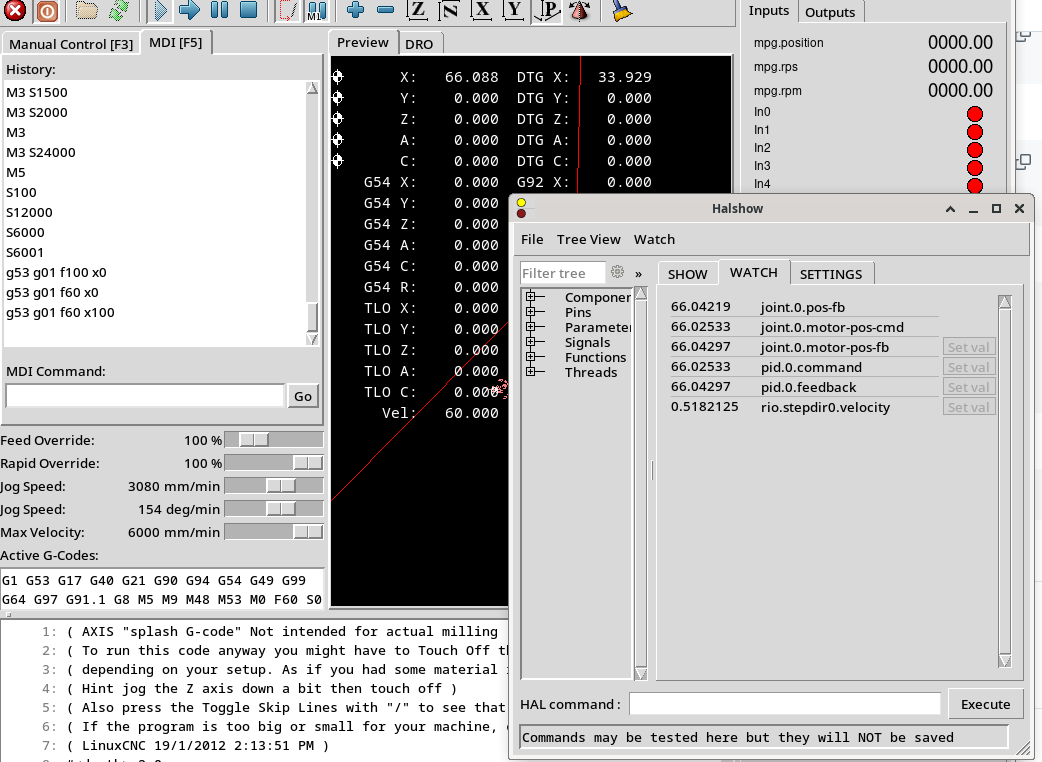
I used MDI command to move x axis for a example. The velocity is 60mm/min, and used halshow to watch pin:rio.stepdir0.velocity
the value is about 0.5mm/s, but the motor run in right speed,and I probe the x axis's pules signal used a oscilloscope
and it show the freqency is about 12.78khz, my scale is 1280 in .ini file
if I use stepdir to drive a servo motor to run a spindle, I net the spindle rps to some one stepdir.velocity then spindle run in a wrong speed
whitch parameter I set wrong?
Tim
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
Less
More
- Posts: 806
- Thank you received: 502
5 months 1 week ago #346519
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
The only parameters that affect the frequency are
* stepdir0.velocity
* stepdir0.velocity-scale
* stepdir0.velocity-offset
and the FPGA clock frequency
Could you please attach your .json file?
* stepdir0.velocity
* stepdir0.velocity-scale
* stepdir0.velocity-offset
and the FPGA clock frequency
Could you please attach your .json file?
The following user(s) said Thank You: NWE
Please Log in or Create an account to join the conversation.
- Tim Bee
- Offline
- Junior Member
-
Less
More
- Posts: 31
- Thank you received: 13
5 months 1 week ago - 5 months 1 week ago #346523
by Tim Bee
Replied by Tim Bee on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
meister:
my json file
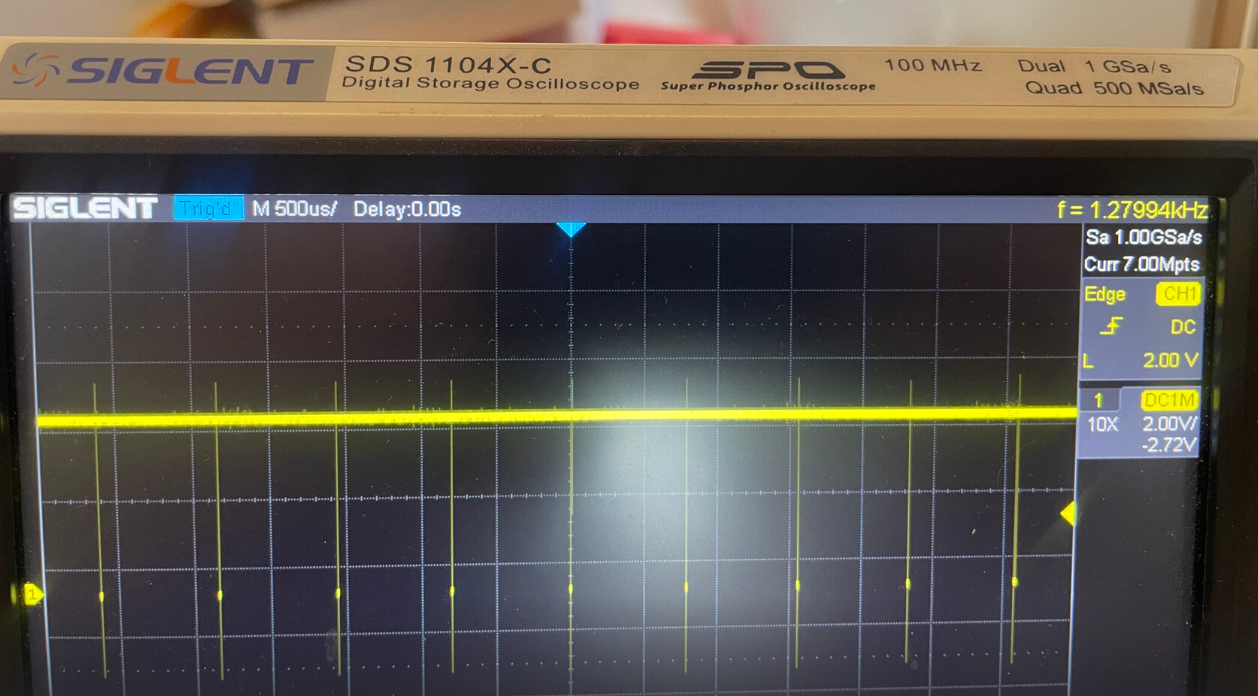
and sorry about the frequecy I write wrong: when command is :G53 G01 F60 X100output pules frequency is about 1.28khz
because my scale is 1280, when F60 (1mm/s), output frequency is 1280 * 1 = 1.28Khz
the stepdir.velocity is show about 0.5mm/s
Tim
my json file
and sorry about the frequecy I write wrong: when command is :G53 G01 F60 X100output pules frequency is about 1.28khz
because my scale is 1280, when F60 (1mm/s), output frequency is 1280 * 1 = 1.28Khz
the stepdir.velocity is show about 0.5mm/s
Tim
Last edit: 5 months 1 week ago by Tim Bee.
Please Log in or Create an account to join the conversation.
Time to create page: 0.409 seconds