
- Posts: 1111
- Thank you received: 114
Kinematics... again:/
- bkt
- Offline
- Platinum Member
-

Less
More
9 years 5 months ago #93312
by bkt
Replied by bkt on topic Kinematics... again:/
in your sketch "offset?" label is distance from centerline of joint3 and centerline of joint4 ... your label "D3" you can use as tool lenght (so it seems you have inverted the label ... offset instead D3 and vice-versa ... I hope I undestand well).
regards
giorgio
regards
giorgio
Please Log in or Create an account to join the conversation.
- Boogie
- Offline
- Premium Member
-

Less
More
- Posts: 97
- Thank you received: 9
9 years 5 months ago #93376
by Boogie
Replied by Boogie on topic Kinematics... again:/
Andy, I'm not thinking about 4-axis right now. It is too complitacted now and 4th axis will make it even more complicated. I can't agree with you Giorgio about joint 3 and joint 4: look on the robokins.c:
This model assumes THERE IS NO OFFSET between joint3 and joint4 - so this is the situation a drew here:
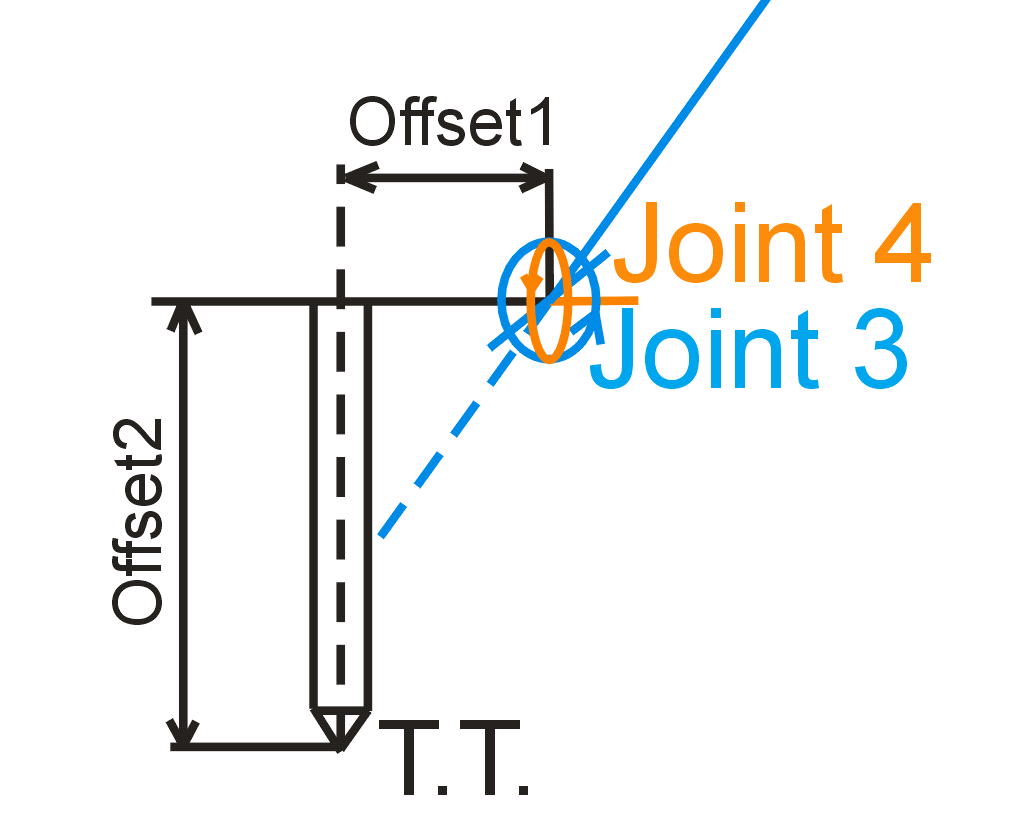
Joint3 rotation axis and joint4 rotation axis has common point and those axes are prependicular to each other and at the same time joint3 is parallel to Cartesian X and joint4 is parallel to Cartesian Y.
So if the assumption is there is no offset1, and that D3 is the distance from joint3&joint4rotational axes then it will look like this:

Guys am I reading robokins description in the right way?
And this is not exactly what we see in the video, right? If I put spindle in place of that unused stepper motor (let's call it spindle platform) we can see in the video, Offset1 is not important AS LONG AS joints 1 thru 3 keep spindle platform PARALLEL to X-Y plane. In fact if i do not use A-axis (rotational around X-axis) that kinematics keeps spindle platform at constant angle in respect to X-Y plane. Am i clear?
Andy have you got INI and HAL files axamples for the kinematics you wrote for Viesturs? I can't contact him (no respond:()
Have a good day guys!
joint[3] = End effector rotates around horizontal axis, that is
parallel to previous rotation axis and also X axis.
A value of zero means that the tooltip (if offset from the axis)
is pointing in the same direction as the centerline of the outer arm.
joint[4] = End effector rotates around horizontal axis, that is
perpendicular to previous rotation axis and is parallel to Y axis.
This module assumes there is no offset between joint[3] and joint[4] axes.
This model assumes THERE IS NO OFFSET between joint3 and joint4 - so this is the situation a drew here:
Joint3 rotation axis and joint4 rotation axis has common point and those axes are prependicular to each other and at the same time joint3 is parallel to Cartesian X and joint4 is parallel to Cartesian Y.
So if the assumption is there is no offset1, and that D3 is the distance from joint3&joint4rotational axes then it will look like this:
Guys am I reading robokins description in the right way?
And this is not exactly what we see in the video, right? If I put spindle in place of that unused stepper motor (let's call it spindle platform) we can see in the video, Offset1 is not important AS LONG AS joints 1 thru 3 keep spindle platform PARALLEL to X-Y plane. In fact if i do not use A-axis (rotational around X-axis) that kinematics keeps spindle platform at constant angle in respect to X-Y plane. Am i clear?
Andy have you got INI and HAL files axamples for the kinematics you wrote for Viesturs? I can't contact him (no respond:()
Have a good day guys!
Please Log in or Create an account to join the conversation.
- bkt
- Offline
- Platinum Member
-
Less
More
- Posts: 1111
- Thank you received: 114
9 years 5 months ago - 9 years 5 months ago #93379
by bkt
Replied by bkt on topic Kinematics... again:/
As i see, Andy modify scarakins for your use .... so in robokins there are still pin names that report scarakins ... I've draw a sketch with scarakins axis structure .... than I draw an other sketch with scarakin joint/axis structure ant your joint/axis structures ... as you can see joint4 in scarakins is exactly 90 ° compared to your joint4 .... as i can see from my sketch and your last image with label name on your post 17 May 2017 15:35 #932.
any how (using your label name on your post 17 May 2017 15:35 #9329) you have 2 offset ... the plane of joint3 is not the same of joint4 ... joint4 plane is 90° referred to joint3 plane + have 2 offset from centerline of each joint .... I'm quite sure that Andy make these calc on robokins (not remember now with precision, but i'm quite sure).
In your of "19 May 2017 10:22" your offset2 is only tool leght I think ..... or you install a some sort of tool after offset2 lenght?
After these .... you can able to work with joint0-1-2-3 only? these question for know if you have solve the configuration problem before furter exploring. For try you can eliminate every refer to join4 into robokins and try, or make joint4 equal to axis without cos calculation.... (for "cancel" you can use /* world...*/ way, so not delete it).
p.s. I'm reading better your mail .... if your plane where install the joint4 (is an axis or only a spindle?) why not use a parallelogram to keep the weight in place?
regards
giorgio
Last edit: 9 years 5 months ago by bkt.
Please Log in or Create an account to join the conversation.
- Boogie
- Offline
- Premium Member
-
Less
More
- Posts: 97
- Thank you received: 9
9 years 5 months ago #93382
by Boogie
Replied by Boogie on topic Kinematics... again:/
Giorgio, i'm not the guy Andy modified kinematics for:) I'm the guy who wants to use it almost in the same way. Or even in simpler way as i don't need 4th axis. If i understand you right here:
the answer is: parallelogram is mechanically complicated and more constrained in comparision with robokins mechatronics. And not suitable for future modifications if any needed.
Yes, you are right: in my case i don't want joint4. I want only a spindle in this place. And what i want from kinematics is to keep that spindle perpendicular to the X-Y plane.
... if your plane where install the joint4 (is an axis or only a spindle?) why not use a parallelogram to keep the weight in place?
the answer is: parallelogram is mechanically complicated and more constrained in comparision with robokins mechatronics. And not suitable for future modifications if any needed.
Yes, you are right: in my case i don't want joint4. I want only a spindle in this place. And what i want from kinematics is to keep that spindle perpendicular to the X-Y plane.
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-

Less
More
- Posts: 19899
- Thank you received: 4655
9 years 5 months ago #93385
by andypugh
To be honest, I wouldn't take the descriptions in robokins too literally. It was modified by Visteurs from Scarakins, and it is possible that he only modified the equations for his own one-off machine, and didn't change the description.
You will need to look at the mathematics to see if that matches your machine, and then alter it if it doesn't.
Replied by andypugh on topic Kinematics... again:/
Boogie wrote: Guys am I reading robokins description in the right way?
To be honest, I wouldn't take the descriptions in robokins too literally. It was modified by Visteurs from Scarakins, and it is possible that he only modified the equations for his own one-off machine, and didn't change the description.
You will need to look at the mathematics to see if that matches your machine, and then alter it if it doesn't.
The following user(s) said Thank You: Boogie
Please Log in or Create an account to join the conversation.
- Boogie
- Offline
- Premium Member
-
Less
More
- Posts: 97
- Thank you received: 9
9 years 5 months ago #93386
by Boogie
Replied by Boogie on topic Kinematics... again:/
Andy this is sooo game changing information:/ ok, so back to study of robokins.c...
Please Log in or Create an account to join the conversation.
Time to create page: 0.162 seconds