Pressbrake CNC Control Setup Questions

More
5 years 6 months ago #205828 by EW_CNC
How do I get the ram press position set to 0 at the right location?
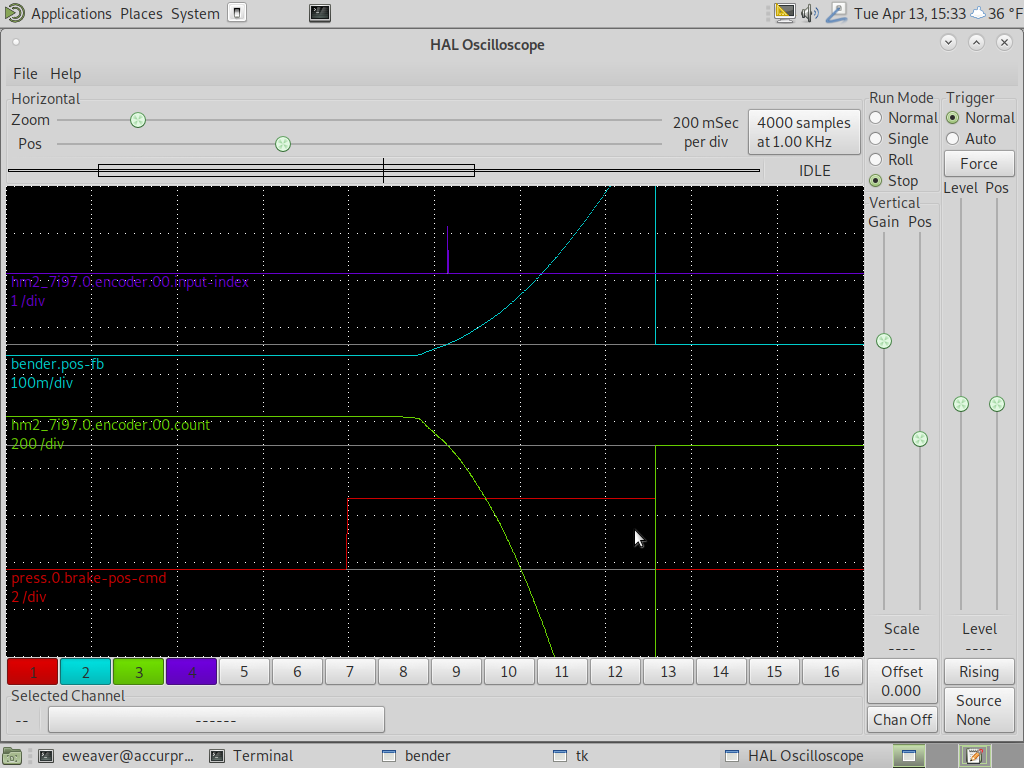
The encoder's index is about 40mm (1.57 in. on our side of the pond) down from the top of the ram travel.
The encoder's count and position pins both line up 0 with the index. (attached index halscope)
Should I put a HAL offset between
Code:
net brake-fb <= hm2_7i97.0.encoder.00.position net brake-fb => press.0.brake-pos-fb bender.pos-fb pressgui.pos
Do I somehow need to home the ram at startup?

Also the encoder reading shows about .024 in. negative from commanded position and when at rest.
Does that indicate that I am off on the PID tuning?

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #205833 by andypugh

flamecutter wrote: Do I somehow need to home the ram at startup?


I think so.
It would be an extra state in the press.comp state machine.
I think that in this case you can use the mesa card index-enable to get very accurate homing.

It's a bit late here to add it tonight. I will try to remember tomorrow.
The following user(s) said Thank You: EW_CNC

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206521 by EW_CNC
Another thing we need to add yet is a jog mode to the down control for setting the dies. (Attached manuel page)
If anyone else has any input or suggestions on what options we might need yet, let us know. It's been years since I worked with a CNC pressbrake.
Thanks,
Earl W.

Your browser does not support embedded PDFs. Please download the file here: Download PDF.

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206529 by andypugh
I am starting to think that the HAL component was a mistake. As the number of axes goes up, and the requirements appear for homing and jogging it starts to look more and more like a conventional CNC machine.

Though there is still the issue of pedal-controlled up/stop/down in realtime, that really doesn't want to be handled in the GUI.

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206639 by EW_CNC

andypugh wrote: I am starting to think that the HAL component was a mistake. As the number of axes goes up, and the requirements appear for homing and jogging it starts to look more and more like a conventional CNC machine.

Though there is still the issue of pedal-controlled up/stop/down in realtime, that really doesn't want to be handled in the GUI.

Ok, I gave this a little more thought.
Some ideas:
  • Set up the homing as a conventional CNC, keep it separate from the component.
  • Use a HAL component only for the ram y axis control. The component you made works good! Maybe have a second component for jogging, like the one you set up only it does not return to start position when I leave off the peddle. Or use my machine's 2 button hand control for jogging mode and the foot peddle for auto mode. The ram control settings would not need to be saved in a file.
  • Keep the backstop separate from the ram, It does not need to be controlled in realtime, gcode control would be good enough.

A few questions:
  • For homing the ram y axis, is my best option to add a homing switch, or is there a way I can home to the index?
  • Would it be possible to add the pressure(preset tonnage limit) to the component, or should it be kept separate, maybe in the e-stop / enable chain?
Andy, your help with the component is greatly appreciated, I have not gained the ability for that kind of programming yet.
E.W.

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago - 5 years 6 months ago #206735 by andypugh

flamecutter wrote: Some ideas:

  • Set up the homing as a conventional CNC, keep it separate from the component.
  • Use a HAL component only for the ram y axis control.


That might work. I need to think whether it is easier or harder than adding generic homing and jogging to the component.

If we decide that _all_ jogging is by jogwheel, and all homing is to index it is not too bad. If we want to support keyboard jogging, mouse jogging, network jogging, mdi jogging... and homing to switches, probes and absolute encoders, then it gets too hard.

So, for your machine, if you want to jog the axes by jogwheel, and all axes have a glass scale with a midpoint index, then it's not so hard to expand the component.


For homing the ram y axis, is my best option to add a homing switch, or is there a way I can home to the index?

I think that you need a switch to know which way to move to find the index. But perhaps that is built-in.

As far as I know you have a single 5µm pulse in the middle of the scale. So from a cold start the system has no way to know if it needs to move up or move down to find it. But this seems like a daft way to make a scale. It would make more sense for half the scale to be Z=0 and half to be Z=1. I can work with what you have, but I do need to know what you have.


Would it be possible to add the pressure(preset tonnage limit) to the component, or should it be kept separate


It belongs in the component.
Last edit: 5 years 6 months ago by andypugh.

Please Log in or Create an account to join the conversation.

Time to create page: 0.176 seconds
Powered by Kunena Forum