
- Posts: 116
- Thank you received: 33

andypugh wrote:
If we decide that _all_ jogging is by jogwheel, and all homing is to index it is not too bad. If we want to support keyboard jogging, mouse jogging, network jogging, mdi jogging... and homing to switches, probes and absolute encoders, then it gets too hard.
So, for your machine, if you want to jog the axes by jogwheel, and all axes have a glass scale with a midpoint index, then it's not so hard to expand the component.
As far as I know you have a single 5µm pulse in the middle of the scale. So from a cold start the system has no way to know if it needs to move up or move down to find it. But this seems like a daft way to make a scale. It would make more sense for half the scale to be Z=0 and half to be Z=1. I can work with what you have, but I do need to know what you have.

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Yes, that's ok! I only have a limited amount of time available myself to spend on this project. So I don't get to stick on it like I'd like to.andypugh wrote: Sorry, I am aware that I got you going and then seem to have stopped.
It looks like I should have some time tomorrow, and will try to get back to this.
Yes I think that would work.Would it make sense to have a "pressure mode" where the brake moves down to a pre-set pressure?
Please Log in or Create an account to join the conversation.
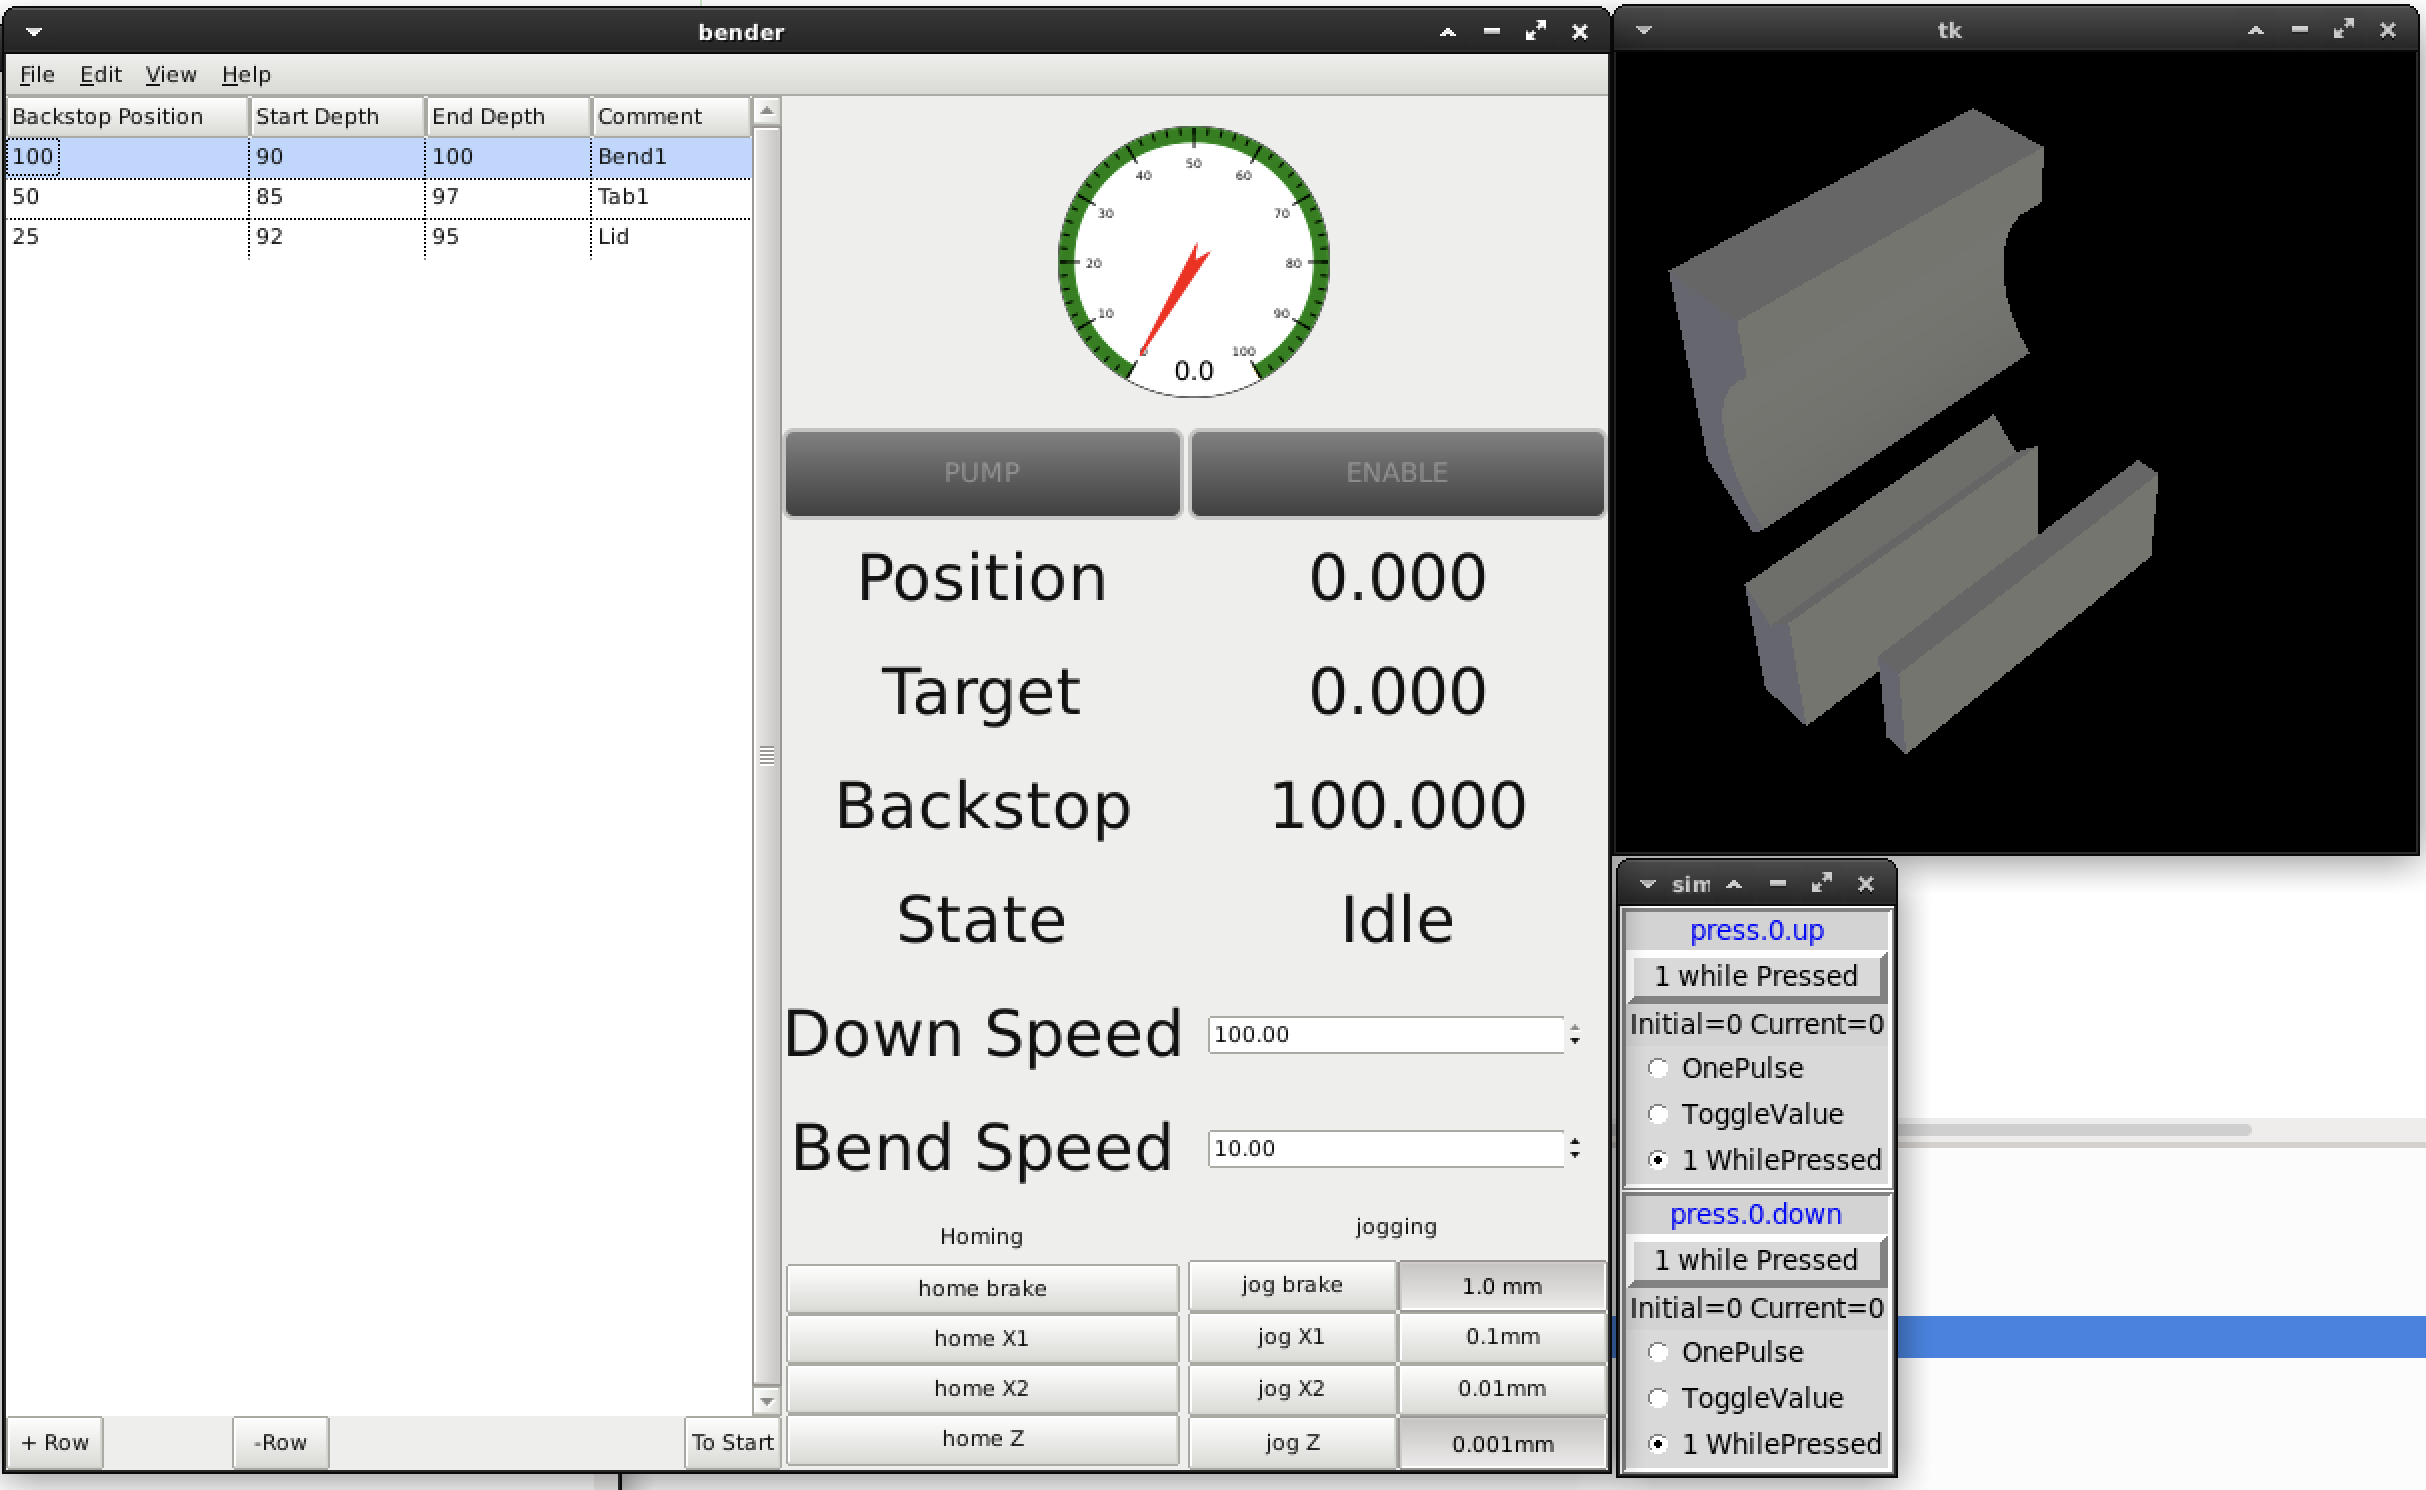
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
