Boxford 125 lathe Tool Changer Comp FERROR (SOLVED)

More
6 years 5 days ago #187474 by Mike_Eitel
I do not understand your comp but when i see the diagram i'm asking myself how is feedback of the movement done? Who tells stepgen how many steps to do and who controls that stepgen generated enough pulses?
Mike

Please Log in or Create an account to join the conversation.

More
6 years 5 days ago #187482 by Clive S

Mike_Eitel wrote: I do not understand your comp but when i see the diagram i'm asking myself how is feedback of the movement done? Who tells stepgen how many steps to do and who controls that stepgen generated enough pulses?
Mike

The comp is this one. it can be opened with a txt editor it has instructions and I compiled it.

File Attachment:

File Name: toolchange...-27.comp
File Size:12.5 KB


There is also a readme file.

File Attachment:

File Name: README.txt
File Size:2.62 KB


I have used halshow and I can see the various pins like toolchanger , toolnumber etc that side of things seems to work.

but I cannot move the turret more that one unit. Disclosure I see the DTG on the dro show 1 unit but not the A axis I do see the counts in halshow apos-cmd toolchanger.position-cmd but not axis.3.motor-pos-cmd. So I know I have some more wiring in hal to do

I am using the word unit as I am not sure if it is degrees or mm

Please Log in or Create an account to join the conversation.

More
6 years 4 days ago #187516 by Mike_Eitel
Sorry, but i do not understand why the axis A should be the moving componend of a toolchanger.

Axis pins are in my understanding part of a n dimensional motion planer.

What you need in my eyes to move your turret is a component to generate steps. I think this is independent from motion planning and i guess it can be done by stepgen.

I can not help you furtheron.

Please Log in or Create an account to join the conversation.

More
6 years 4 days ago #187520 by Clive S

Mike_Eitel wrote: Sorry, but i do not understand why the axis A should be the moving componend of a toolchanger.

Axis pins are in my understanding part of a n dimensional motion planer.

What you need in my eyes to move your turret is a component to generate steps. I think this is independent from motion planning and i guess it can be done by stepgen.

I can not help you furtheron.


Mike. The turret is driven by a stepper motor and need to move it about 45' and then back a short way to lock it.

Thanks for your help.

Please Log in or Create an account to join the conversation.

More
6 years 4 days ago #187523 by Aciera
In the comp file I read

### must unlink these 2 to access stepgen.3.position-cmd
### and prevent continual following errors if motor-pos-fb left linked
#net apos-cmd axis.3.motor-pos-cmd => stepgen.3.position-cmd
#net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb


You have:

setp stepgen.3.maxaccel [AXIS_A]STEPGEN_MAXACCEL
net apos-cmd => stepgen.3.position-cmd
net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb


Maybe try to comment out net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb ?

Please Log in or Create an account to join the conversation.

More
6 years 4 days ago - 6 years 4 days ago #187533 by Clive S

Aciera wrote: In the comp file I read

### must unlink these 2 to access stepgen.3.position-cmd
### and prevent continual following errors if motor-pos-fb left linked
#net apos-cmd axis.3.motor-pos-cmd => stepgen.3.position-cmd
#net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb


You have:

setp stepgen.3.maxaccel [AXIS_A]STEPGEN_MAXACCEL
net apos-cmd => stepgen.3.position-cmd
net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb


maybe try to comment out net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb ?
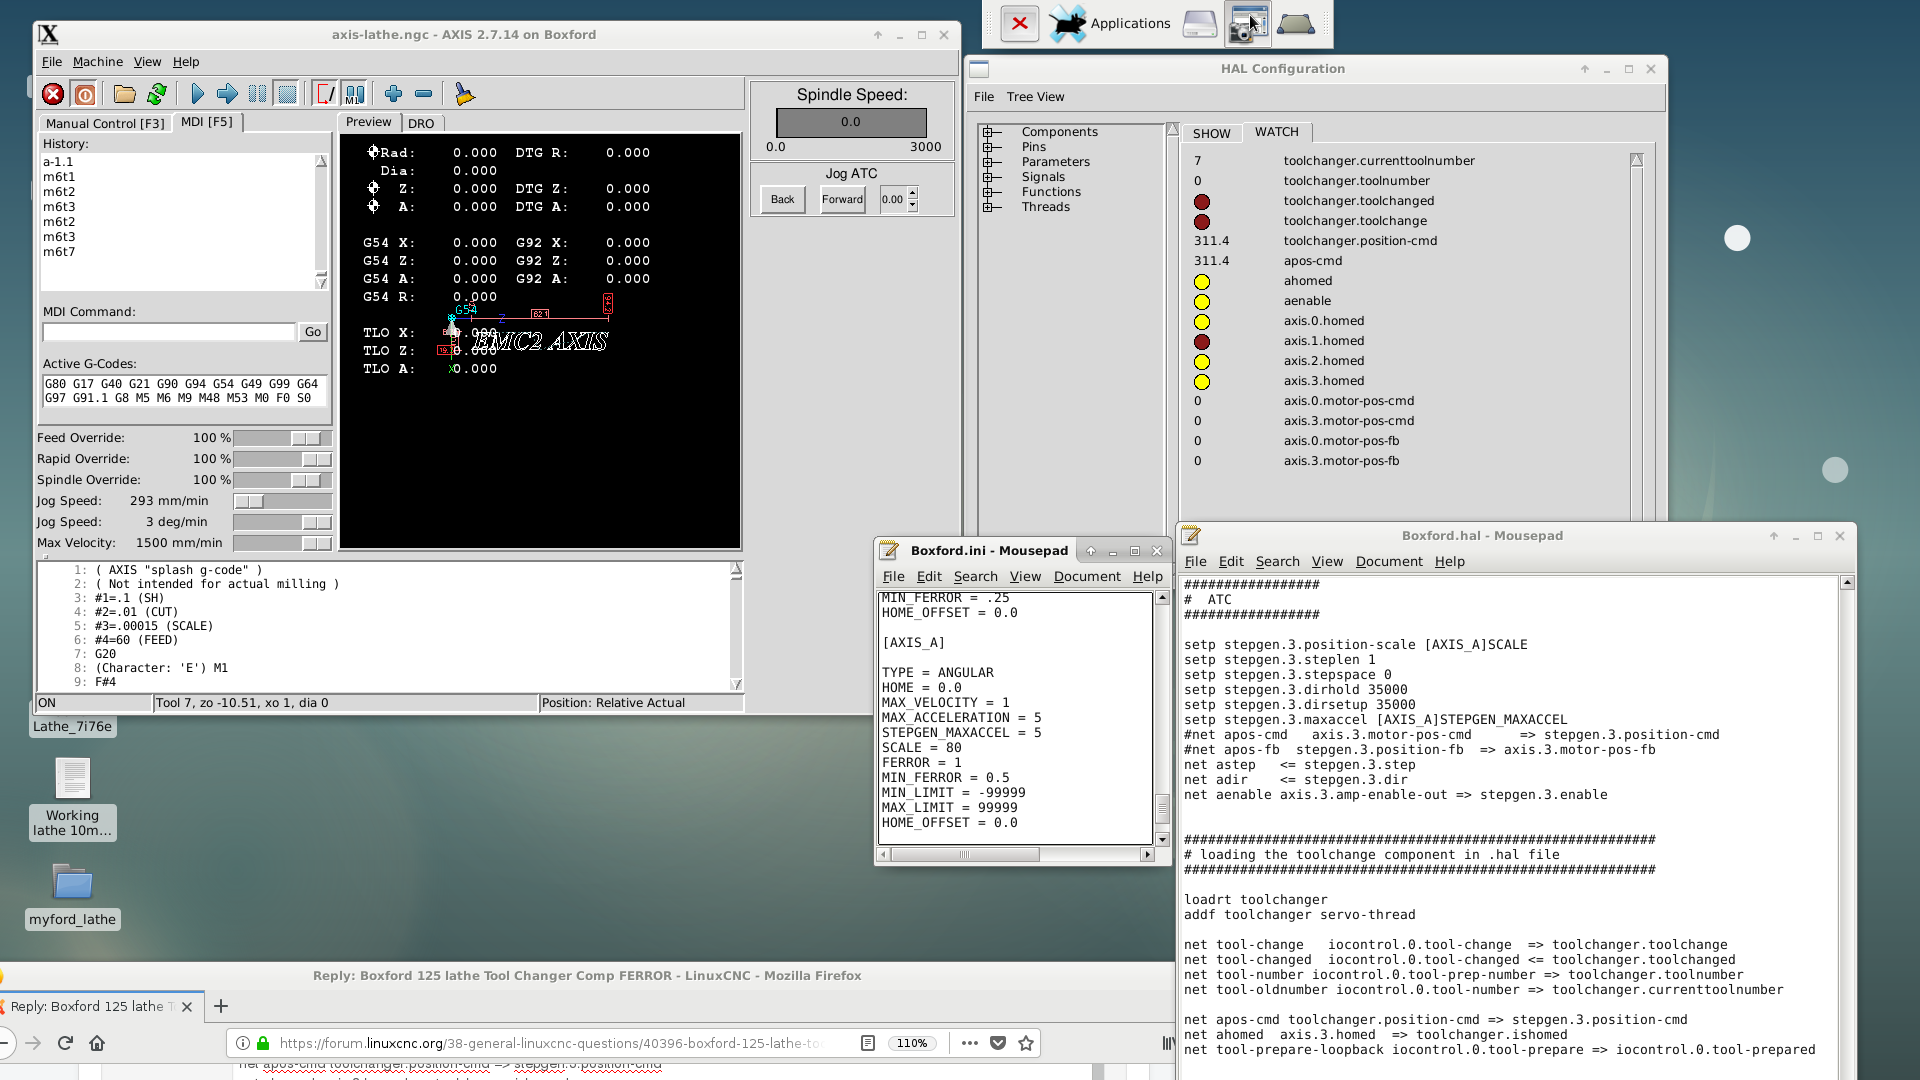

Yes I tried that last night:-

setp stepgen.3.position-scale [AXIS_A]SCALE
setp stepgen.3.steplen 1
setp stepgen.3.stepspace 0
setp stepgen.3.dirhold 35000
setp stepgen.3.dirsetup 35000
setp stepgen.3.maxaccel [AXIS_A]STEPGEN_MAXACCEL
#net apos-cmd axis.3.motor-pos-cmd => stepgen.3.position-cmd
#net apos-fb stepgen.3.position-fb => axis.3.motor-pos-fb
net astep <= stepgen.3.step
net adir <= stepgen.3.dir
net aenable axis.3.amp-enable-out => stepgen.3.enable

loadrt toolchanger
addf toolchanger servo-thread

net tool-change iocontrol.0.tool-change => toolchanger.toolchange
net tool-changed iocontrol.0.tool-changed <= toolchanger.toolchanged
net tool-number iocontrol.0.tool-prep-number => toolchanger.toolnumber
net tool-oldnumber iocontrol.0.tool-number => toolchanger.currenttoolnumber

net apos-cmd toolchanger.position-cmd => stepgen.3.position-cmd
net ahomed axis.3.homed => toolchanger.ishomed
net tool-prepare-loopback iocontrol.0.tool-prepare => iocontrol.0.tool-prepared

ini file:-
[AXIS_A]
TYPE = ANGULAR
HOME = 0.0
MAX_VELOCITY = 1
MAX_ACCELERATION = 5
STEPGEN_MAXACCEL = 5
SCALE = 80
FERROR = 1
MIN_FERROR = 0.5
MIN_LIMIT = -99999
MAX_LIMIT = 99999
HOME_OFFSET = 0.0

That got rid of the error.
Can you help me rewire the hal in that it is not driving the net apos-cmd toolchanger.position-cmd => stepgen.3.position-cmd

As you can see the DRO is not updating - ie not passing the steps to the motor
.


Thank you for your help.

File Attachment:

File Name: boxford_1.tar
File Size:40 KB
Last edit: 6 years 4 days ago by Clive S.

Please Log in or Create an account to join the conversation.

Time to create page: 0.356 seconds
Powered by Kunena Forum
