
- Posts: 87
- Thank you received: 17
Ethercat HAL driver
- jc2ktr
- Offline
- Premium Member
-

Less
More
5 years 10 months ago #192956
by jc2ktr
@Chimeno
i think it's can't be that big mistake, but i don't see it / get it what the problem is. My complete config is attached.
The Gui starts and the mapped IO's are shown in HAL-Show, and the drive can be enabled but will not move.
Greetings Sven
Replied by jc2ktr on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
chimeno wrote: Hello @jc2ktr
I'm sure it's silly, I can't think of anything myself, you can publish your .hal files and I'll take a look at it
Greeting
Chimeno
@Chimeno
i think it's can't be that big mistake, but i don't see it / get it what the problem is. My complete config is attached.
The Gui starts and the mapped IO's are shown in HAL-Show, and the drive can be enabled but will not move.
Greetings Sven
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-

Less
More
- Posts: 295
- Thank you received: 125
5 years 10 months ago #193012
by chimeno
Replied by chimeno on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hello @jc2ktr,
I can't find the configuration signals?
Greeting
Chimeno
I can't find the configuration signals?
Code:
setp lcec.0.7.opmode 8
setp lcec.0.7.X-cmd-OPmodeRel1 1
Greeting
Chimeno
Please Log in or Create an account to join the conversation.
- jc2ktr
- Offline
- Premium Member
-
Less
More
- Posts: 87
- Thank you received: 17
5 years 10 months ago - 5 years 10 months ago #193014
by jc2ktr
The lcec.0.7.opmode 8 is set in the custom_postgui.hal under only under another name setp lcec.0.7.opmode-3 true
its defined in the ethercat.xml <pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="opmode" halType="bit"/>
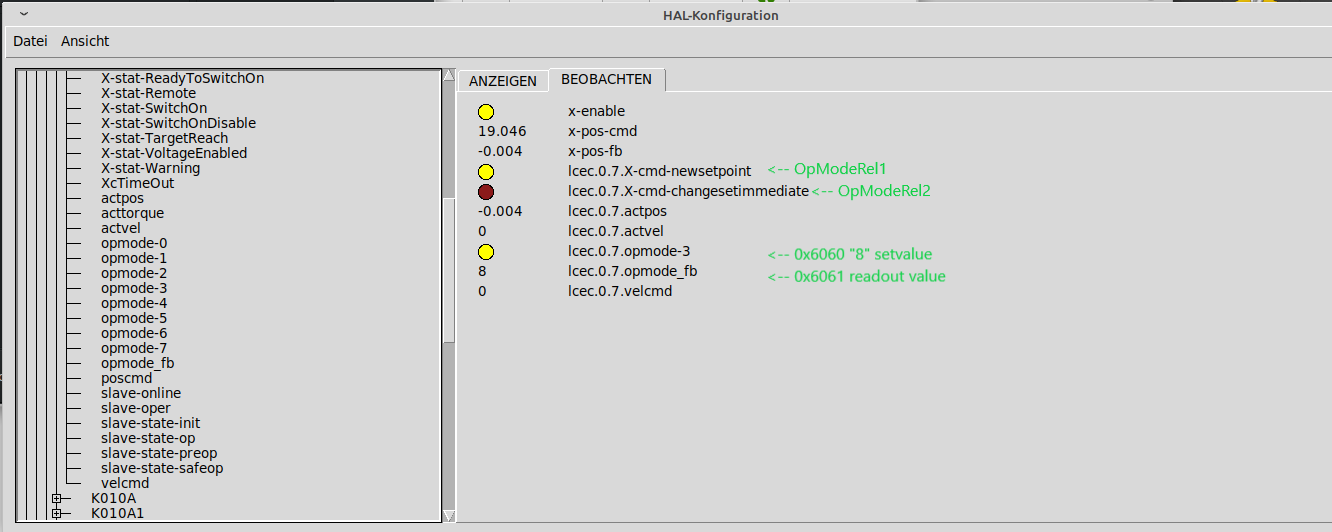
the other one i must have missed in my config, though i dont really know what it does at the moment.
addition
the setp lcec.0.7.X-cmd-OPmodeRel1 1 < i have renamed it as i added some changes from MRBaird
addition 2
is it possible that the drive does not move because the joint.0.acc-cmd does not change its state it remains allways 0 when i jog the axis
Replied by jc2ktr on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
chimeno wrote: Hello @jc2ktr,
I can't find the configuration signals?
Code:setp lcec.0.7.opmode 8 setp lcec.0.7.X-cmd-OPmodeRel1 1
Greeting
Chimeno
The lcec.0.7.opmode 8 is set in the custom_postgui.hal under only under another name setp lcec.0.7.opmode-3 true
its defined in the ethercat.xml <pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="opmode" halType="bit"/>
the other one i must have missed in my config, though i dont really know what it does at the moment.
addition
the setp lcec.0.7.X-cmd-OPmodeRel1 1 < i have renamed it as i added some changes from MRBaird
addition 2
is it possible that the drive does not move because the joint.0.acc-cmd does not change its state it remains allways 0 when i jog the axis
Last edit: 5 years 10 months ago by jc2ktr. Reason: picture added
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
5 years 10 months ago #193018
by chimeno
Replied by chimeno on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hello @jc2ktr
Ok, I don't know what else to tell you, check that the engine moves with TWINCAT3 and check the status that is the same in linuxcnc, you will have to ask for help from the colleague @MRBaird that he does have the drivers and can help you
Greeting
Chimeno
Ok, I don't know what else to tell you, check that the engine moves with TWINCAT3 and check the status that is the same in linuxcnc, you will have to ask for help from the colleague @MRBaird that he does have the drivers and can help you
Greeting
Chimeno
The following user(s) said Thank You: jc2ktr
Please Log in or Create an account to join the conversation.
- jc2ktr
- Offline
- Premium Member
-
Less
More
- Posts: 87
- Thank you received: 17
5 years 10 months ago #193024
by jc2ktr
Hello @Chimeno
Thank you i will try it further and ask also @MRBaird.
Although i want to Thank you for your great kindness and the really good help.
Wish you Merry Christmas and much luck
Replied by jc2ktr on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hello @jc2ktr
Ok, I don't know what else to tell you, check that the engine moves with TWINCAT3 and check the status that is the same in linuxcnc, you will have to ask for help from the colleague @MRBaird that he does have the drivers and can help you
Greeting
Chimeno
Hello @Chimeno
Thank you i will try it further and ask also @MRBaird.
Although i want to Thank you for your great kindness and the really good help.
Wish you Merry Christmas and much luck
The following user(s) said Thank You: chimeno
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
5 years 10 months ago - 5 years 10 months ago #193034
by chimeno
Replied by chimeno on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hello @jc2ktr
I think the problem is that it lacks the speed at which it has to move, register this pin
Merry Christmas
Chimeno
I think the problem is that it lacks the speed at which it has to move, register this pin
Code:
<syncManager idx="2" dir="out">
<pdo idx="1600">
<!-- Target Velocity -->
<pdoEntry idx="60ff" subIdx="00" bitLen="32" halPin="TargetVelocity" halType="float" scale="1000"/>
net xvel-cmd => lcec.0.7.TargetVelocity
Merry Christmas
Chimeno
Last edit: 5 years 10 months ago by chimeno. Reason: Edit
The following user(s) said Thank You: jc2ktr
Please Log in or Create an account to join the conversation.
Time to create page: 2.110 seconds