
- Posts: 1111
- Thank you received: 114
Ethercat HAL driver
- bkt
- Offline
- Platinum Member
-

Less
More
5 years 9 months ago #193872
by bkt
Replied by bkt on topic Ethercat HAL driver
@sven ... my drives are Chinese too, but before complaining and saying that the assistance and manuals are bad I would like to give them the benefit of the doubt and wait for their end-of-year parties to end and finally back to the office to answer mine requests. Up to now I have been happy with them .... I tried their ethercat and I'm having problems, but I don't usually use ethercat in my work .... so maybe the cause is mine..... but I use different china drive type and brand .... however it is Chinese practice, and I think they have learned from the Japanese for this, consider the manual a kind of optional .... if you need a specific one you have to request it ... too often I have found some facts just for me ... .. also from famous Japan brands .... it seems to me that the user manual is a wholly European and American habit .... some mail makes a user complained of bad control on vdf thoshiba .... I guess he didn't ask the specific manual of the modbus .... Japanese "transcribe their secrets and most lustful commands" on the field bus in general (even ethercat or other) ..... this just to talk with friends. 
Regarding my drives obviously if they don't give an answer I'll be happy to do bad publicity here on the forum.
in each case they are ethercat cia402 compliant drives, therefore objects 6091 subidx01 and 02 and 6092 subidx 01 and 02 should keep the gear ratio in memory so that the control units and encoder units can match .... now how now if I try to ascribing this from xml is not accepted (but this would also be correct, the values should be permanently written in eeprom) and from twincat I don't see the registers. I believe at this point that I need a software from the manufacturer. Your ET60 must be the same I think .... but your manual is not online on producer sites I see .... so that ssnz a well written manual is impossible to know how things are, for you as well as for me.
regards
btk
Please Log in or Create an account to join the conversation.
- bkt
- Offline
- Platinum Member
-
Less
More
- Posts: 1111
- Thank you received: 114
5 years 9 months ago - 5 years 9 months ago #193876
by bkt
Replied by bkt on topic Ethercat HAL driver
I foud your manual here  )
forum.linuxcnc.org/24-hal-components/223...mkjlovaxfw&start=910
I see your problem .... nothing about gear scaling or scaling on manual .... :pinch: :pinch: and in xml many references to modbus world .... I have the supect you must set scaling parameter via modbus .... than you can use axis correctly.
regards
bkt
)
forum.linuxcnc.org/24-hal-components/223...mkjlovaxfw&start=910
I see your problem .... nothing about gear scaling or scaling on manual .... :pinch: :pinch: and in xml many references to modbus world .... I have the supect you must set scaling parameter via modbus .... than you can use axis correctly.
regards
bkt
Last edit: 5 years 9 months ago by bkt.
The following user(s) said Thank You: jc2ktr
Please Log in or Create an account to join the conversation.
- jc2ktr
- Offline
- Premium Member
-

Less
More
- Posts: 87
- Thank you received: 17
5 years 9 months ago - 5 years 9 months ago #193938
by jc2ktr
Hi @bkt,
I am new to LinuxCNC and this is why i have little experience in Configuring ... so on, its obvius that i made many failures.
it was not my intention to complain about the drive's/manufacturer. :laugh:
I am only an electrician, i usually mount the EtherCAT drives and Devices in an Electrical Control Cabinet and wire them only
About the objects 6091 / 6092 when i try to readout the object in terminal with ethercat upload -p 7 -t int16 0x6092 01
it outputs this:
SDO transfer aborted with code 0x06020000: This object does not exist in the object directory
Also in TwinCAT it does not exist.
I try to get some information from the manufacturer too, and share my expirience here.
I have the manual, but it's sometimes little confusing
Replied by jc2ktr on topic Ethercat HAL driver
bkt wrote: @sven ... my drives are Chinese too, but before complaining and saying that the assistance and manuals are bad I would like to give them the benefit of the doubt and wait for their end-of-year parties to end and finally back to the office to answer mine requests. Up to now I have been happy with them .... I tried their ethercat and I'm having problems, but I don't usually use ethercat in my work .... so maybe the cause is mine..... but I use different china drive type and brand .... however it is Chinese practice, and I think they have learned from the Japanese for this, consider the manual a kind of optional .... if you need a specific one you have to request it ... too often I have found some facts just for me ... .. also from famous Japan brands .... it seems to me that the user manual is a wholly European and American habit .... some mail makes a user complained of bad control on vdf thoshiba .... I guess he didn't ask the specific manual of the modbus .... Japanese "transcribe their secrets and most lustful commands" on the field bus in general (even ethercat or other) ..... this just to talk with friends.
Regarding my drives obviously if they don't give an answer I'll be happy to do bad publicity here on the forum.
in each case they are ethercat cia402 compliant drives, therefore objects 6091 subidx01 and 02 and 6092 subidx 01 and 02 should keep the gear ratio in memory so that the control units and encoder units can match .... now how now if I try to ascribing this from xml is not accepted (but this would also be correct, the values should be permanently written in eeprom) and from twincat I don't see the registers. I believe at this point that I need a software from the manufacturer. Your ET60 must be the same I think .... but your manual is not online on producer sites I see .... so that ssnz a well written manual is impossible to know how things are, for you as well as for me.
regards
btk
Hi @bkt,
I am new to LinuxCNC and this is why i have little experience in Configuring ... so on, its obvius that i made many failures.
it was not my intention to complain about the drive's/manufacturer. :laugh:
I am only an electrician, i usually mount the EtherCAT drives and Devices in an Electrical Control Cabinet and wire them only
About the objects 6091 / 6092 when i try to readout the object in terminal with ethercat upload -p 7 -t int16 0x6092 01
it outputs this:
SDO transfer aborted with code 0x06020000: This object does not exist in the object directory
Also in TwinCAT it does not exist.
I try to get some information from the manufacturer too, and share my expirience here.
Code:
I foud your manual here :)) forum.linuxcnc.org/24-hal-components/223...mkjlovaxfw&start=910
I see your problem .... nothing about gear scaling or scaling on manual .... :pinch: :pinch: and in xml many references to modbus world .... I have the supect you must set scaling parameter via modbus .... than you can use axis correctly.
regards
bkt
I have the manual, but it's sometimes little confusing
Last edit: 5 years 9 months ago by jc2ktr. Reason: edit
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-

Less
More
- Posts: 295
- Thank you received: 125
5 years 9 months ago - 5 years 9 months ago #193969
by chimeno
Replied by chimeno on topic Ethercat HAL driver
Hello @btk,
-the scale you have in the .ini file doesn't point to any signals.
-you are sure that the registry of
-It seems to me that the record would be
but I could be wrong
-Have you tried to change the scale here?
Hello @jc2ktr
-Have you used the manufacturer's program to find the appropriate values?
* you need to configure the engine parameters, I assume you are using an ECT60
When configuring in position mode, linux no longer has control over the diver, it only sends position and reads position, you have to apply the scale here
-the scale you have in the .ini file doesn't point to any signals.
-you are sure that the registry of
Code:
<pdo idx="1A03">
<pdoEntry idx="6041" subIdx="00" bitLen="16" halPin="driverStatus" halType="bit"/>
<pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="posActual" halType="float" scale="0.001"/>
<pdoEntry idx="6077" subIdx="00" bitLen="16" halPin="torActual" halType="float"/>
<pdoEntry idx="606C" subIdx="00" bitLen="32" halPin="velActual" halType="float" scale="0.001"/>
<pdoEntry idx="603F" subIdx="00" bitLen="16" halPin="errorStat" halType="float"/>
-It seems to me that the record would be
Code:
1A00
-Have you tried to change the scale here?
Code:
scale="0.001"
Hello @jc2ktr
-Have you used the manufacturer's program to find the appropriate values?
* you need to configure the engine parameters, I assume you are using an ECT60
When configuring in position mode, linux no longer has control over the diver, it only sends position and reads position, you have to apply the scale here
Code:
<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1000"/>
Code:
<pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="actpos" halType="float" scale=".001"/>
Last edit: 5 years 9 months ago by chimeno. Reason: edit
The following user(s) said Thank You: bkt, jc2ktr
Please Log in or Create an account to join the conversation.
- jc2ktr
- Offline
- Premium Member
-
Less
More
- Posts: 87
- Thank you received: 17
5 years 9 months ago - 5 years 9 months ago #193971
by jc2ktr
Hello @Chimeno,
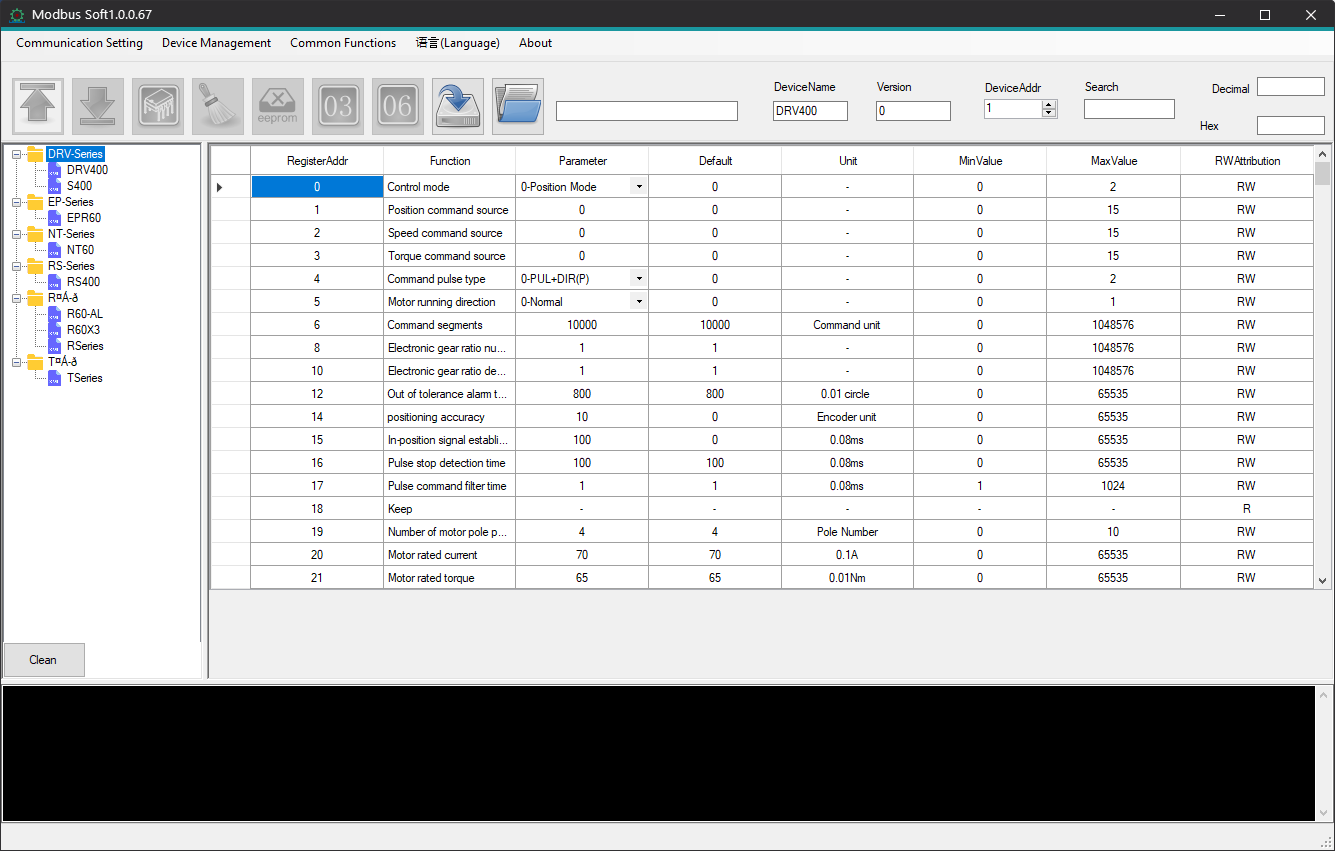
i tried to setup/configure my driver with the program, but it seems that my driver is not compatible with it. I always got error messages.
And in the Selection window my driver was not listed, even when i tried to load the .xml file which i got with my driver.
even when i try to scale my signals in these lines:
it does not change the moved distance... when jog 10mm the axis moves 25
i will write a email to rtelligent about my scaling issue, and wait what they have to say.
Maybe it´s a stupid simple solution
Thanks again chimeno
Replied by jc2ktr on topic Ethercat HAL driver
chimeno wrote: Hello @jc2ktr
-Have you used the manufacturer's program to find the appropriate values?
* you need to configure the engine parameters, I assume you are using an ECT60
When configuring in position mode, linux no longer has control over the diver, it only sends position and reads position, you have to apply the scale here
Code:<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1000"/>Code:<pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="actpos" halType="float" scale=".001"/>
Hello @Chimeno,
i tried to setup/configure my driver with the program, but it seems that my driver is not compatible with it. I always got error messages.
And in the Selection window my driver was not listed, even when i tried to load the .xml file which i got with my driver.
even when i try to scale my signals in these lines:
Code:
<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1000"/>
Code:
<pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="actpos" halType="float" scale=".001"/>
it does not change the moved distance... when jog 10mm the axis moves 25
i will write a email to rtelligent about my scaling issue, and wait what they have to say.
Maybe it´s a stupid simple solution
Thanks again chimeno
Last edit: 5 years 9 months ago by jc2ktr. Reason: picture added
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
5 years 9 months ago #193973
by chimeno
Replied by chimeno on topic Ethercat HAL driver
Hello @jc2ktr
If it may be a good idea to send an email if they can help you,
can you check this if the scale changes?
Greeting
Chimeno
If it may be a good idea to send an email if they can help you,
can you check this if the scale changes?
Greeting
Chimeno

Please Log in or Create an account to join the conversation.
Time to create page: 0.253 seconds