
- Posts: 87
- Thank you received: 17
Ethercat HAL driver
- jc2ktr
- Offline
- Premium Member
-

Less
More
5 years 8 months ago #198796
by jc2ktr
I´ve got my Drive up and running under LinuxCNC, with the Firmware 20V26 and the Rexroth XML for COE which is delivered with the Indraworks DS Software from Rexroth.
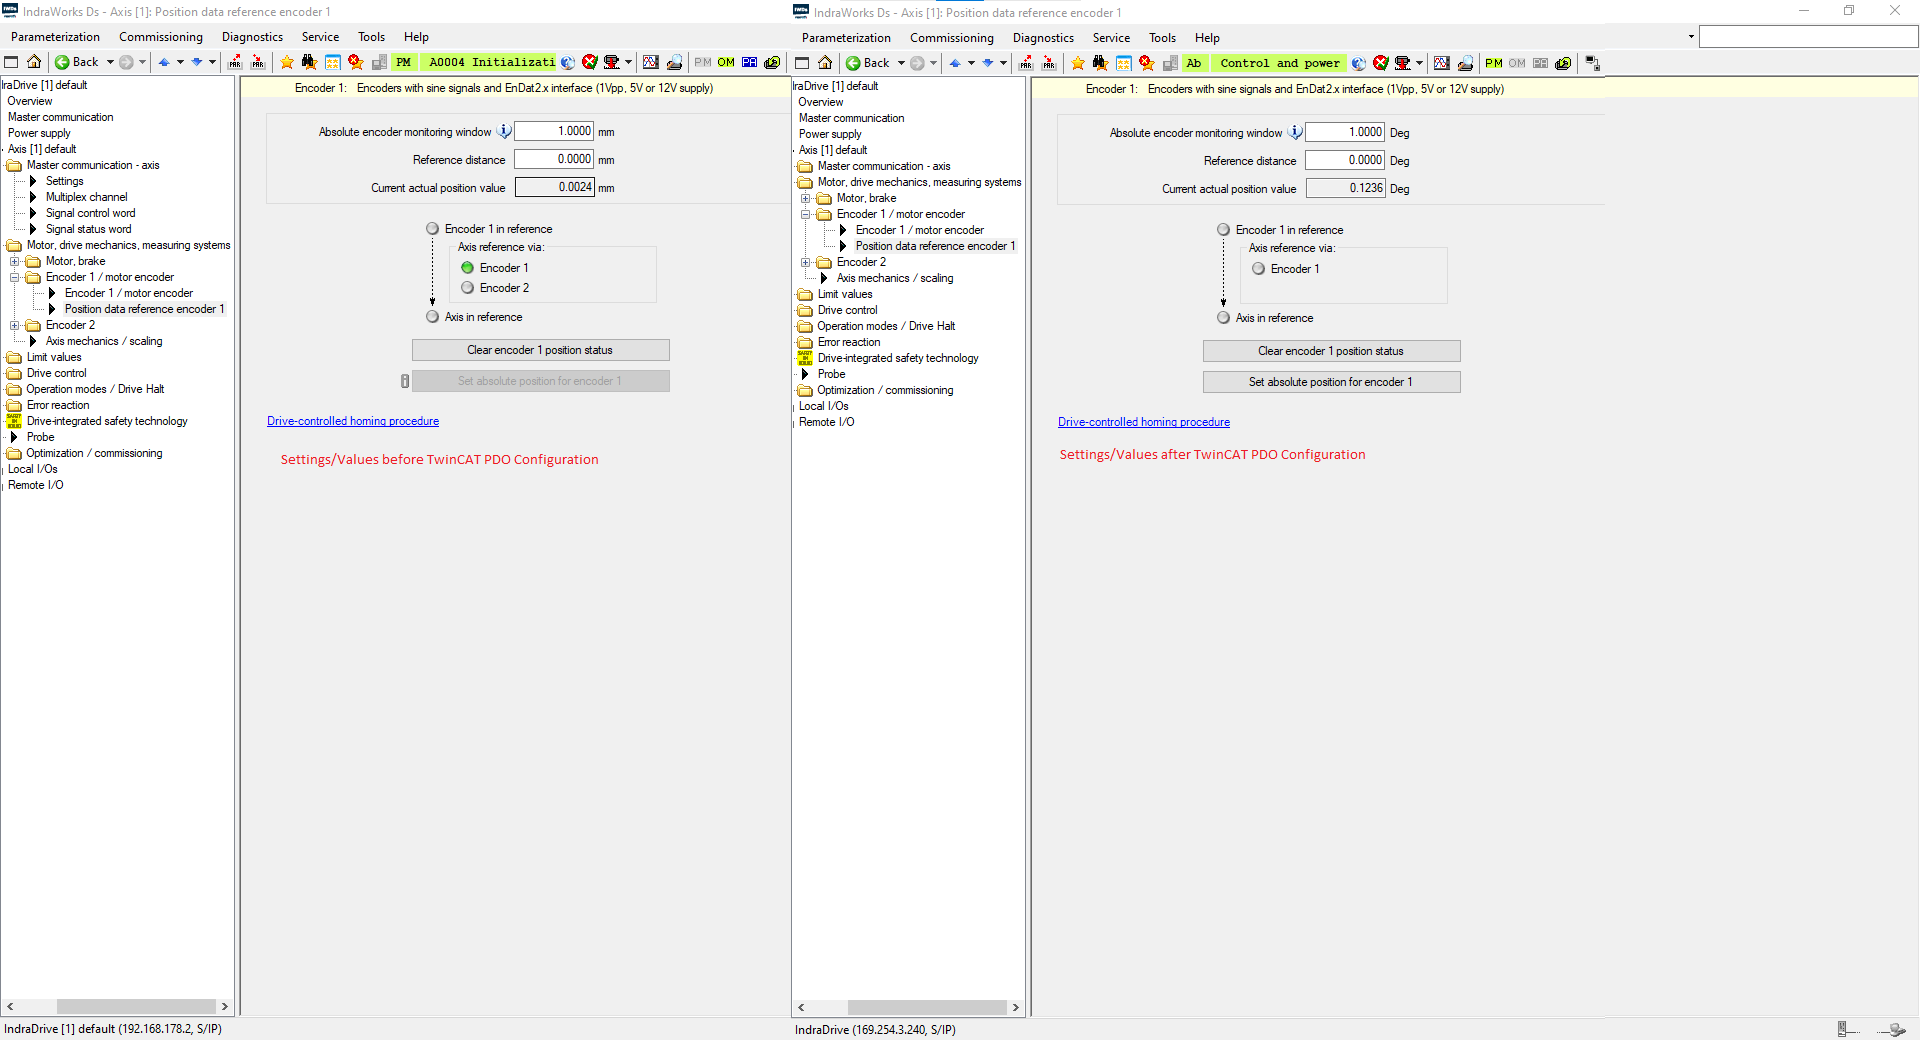
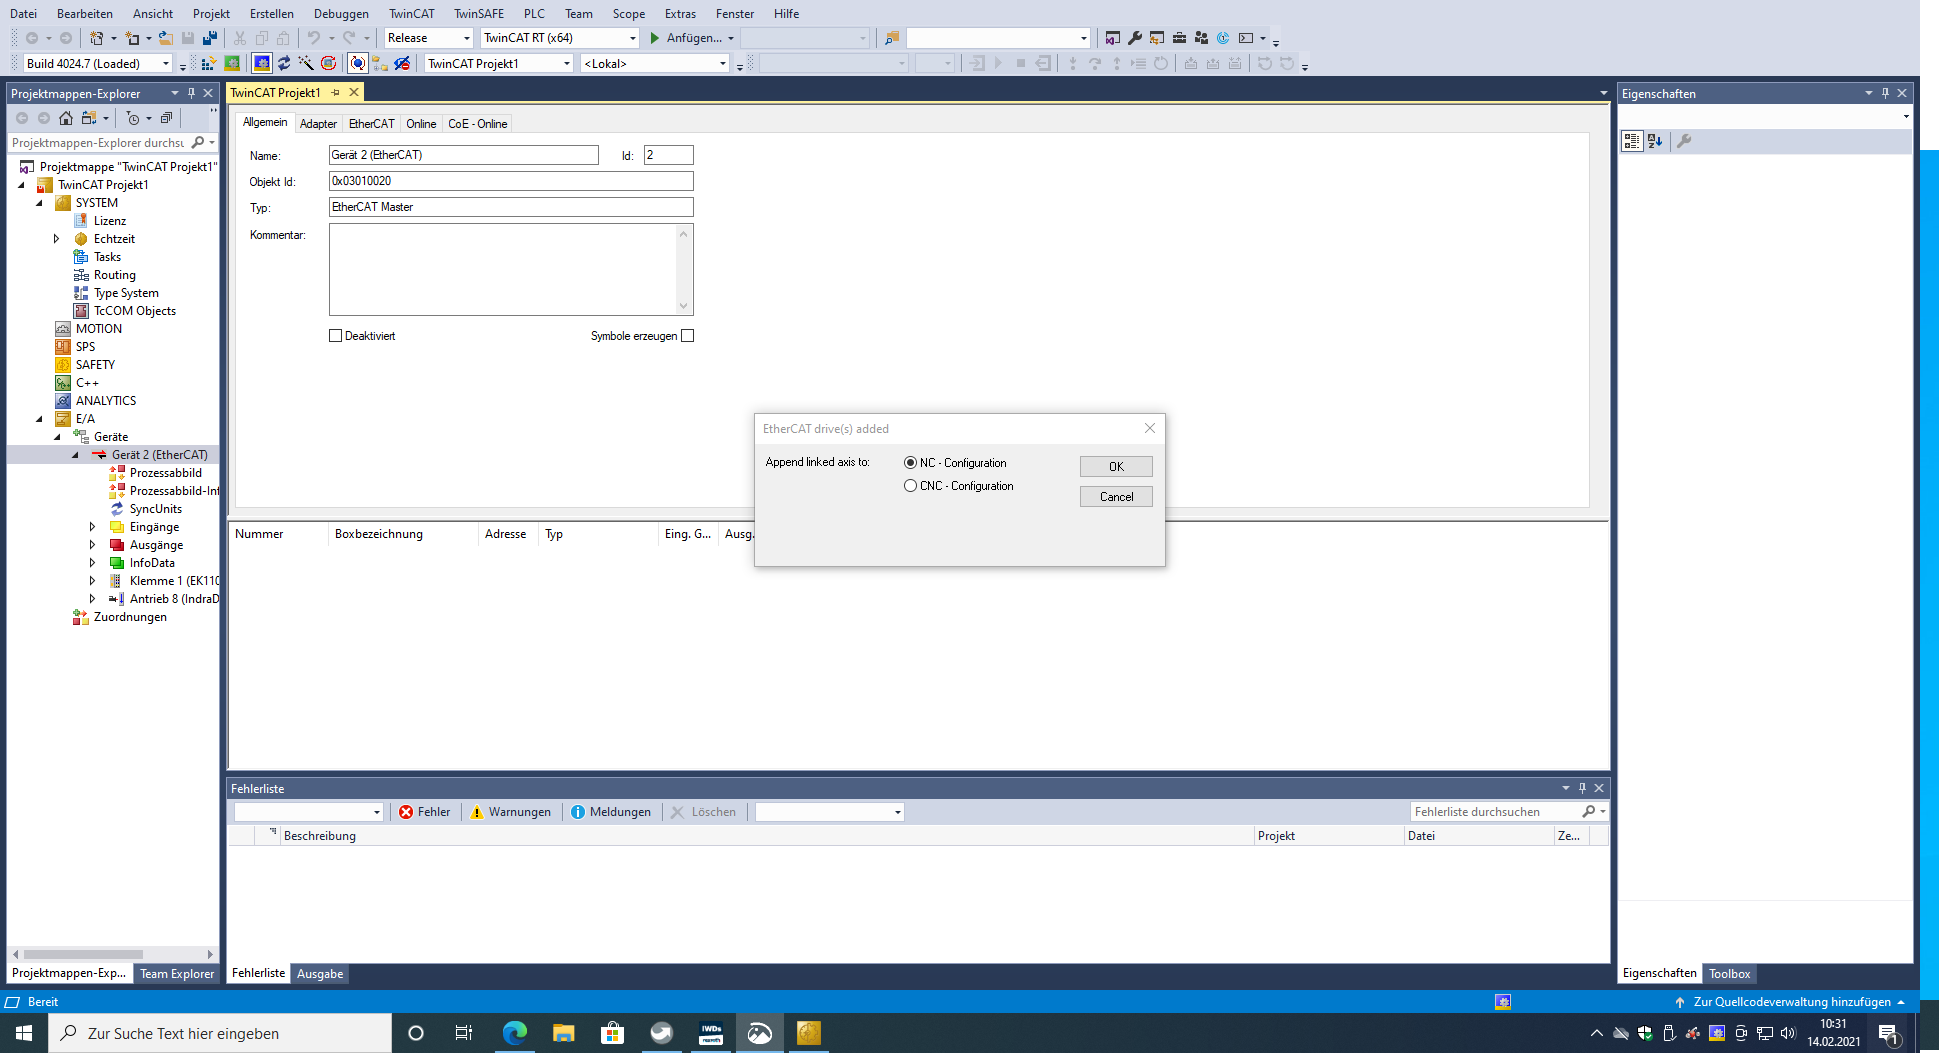
But when i setup the drive with indraworks DS to my needed Scaling and Mechanical setting, and then let TwinCAT configure the Drive that LinuxCNC is able to "control" the drive. all of my previous Parameters will be overridden.
I will add some Images which should provide some of my issues.
When i try to change the Settings after TwinCAT reconfigured them the Indraworks software generates various Error messages which i can´t resolve with my momentary knowledge.
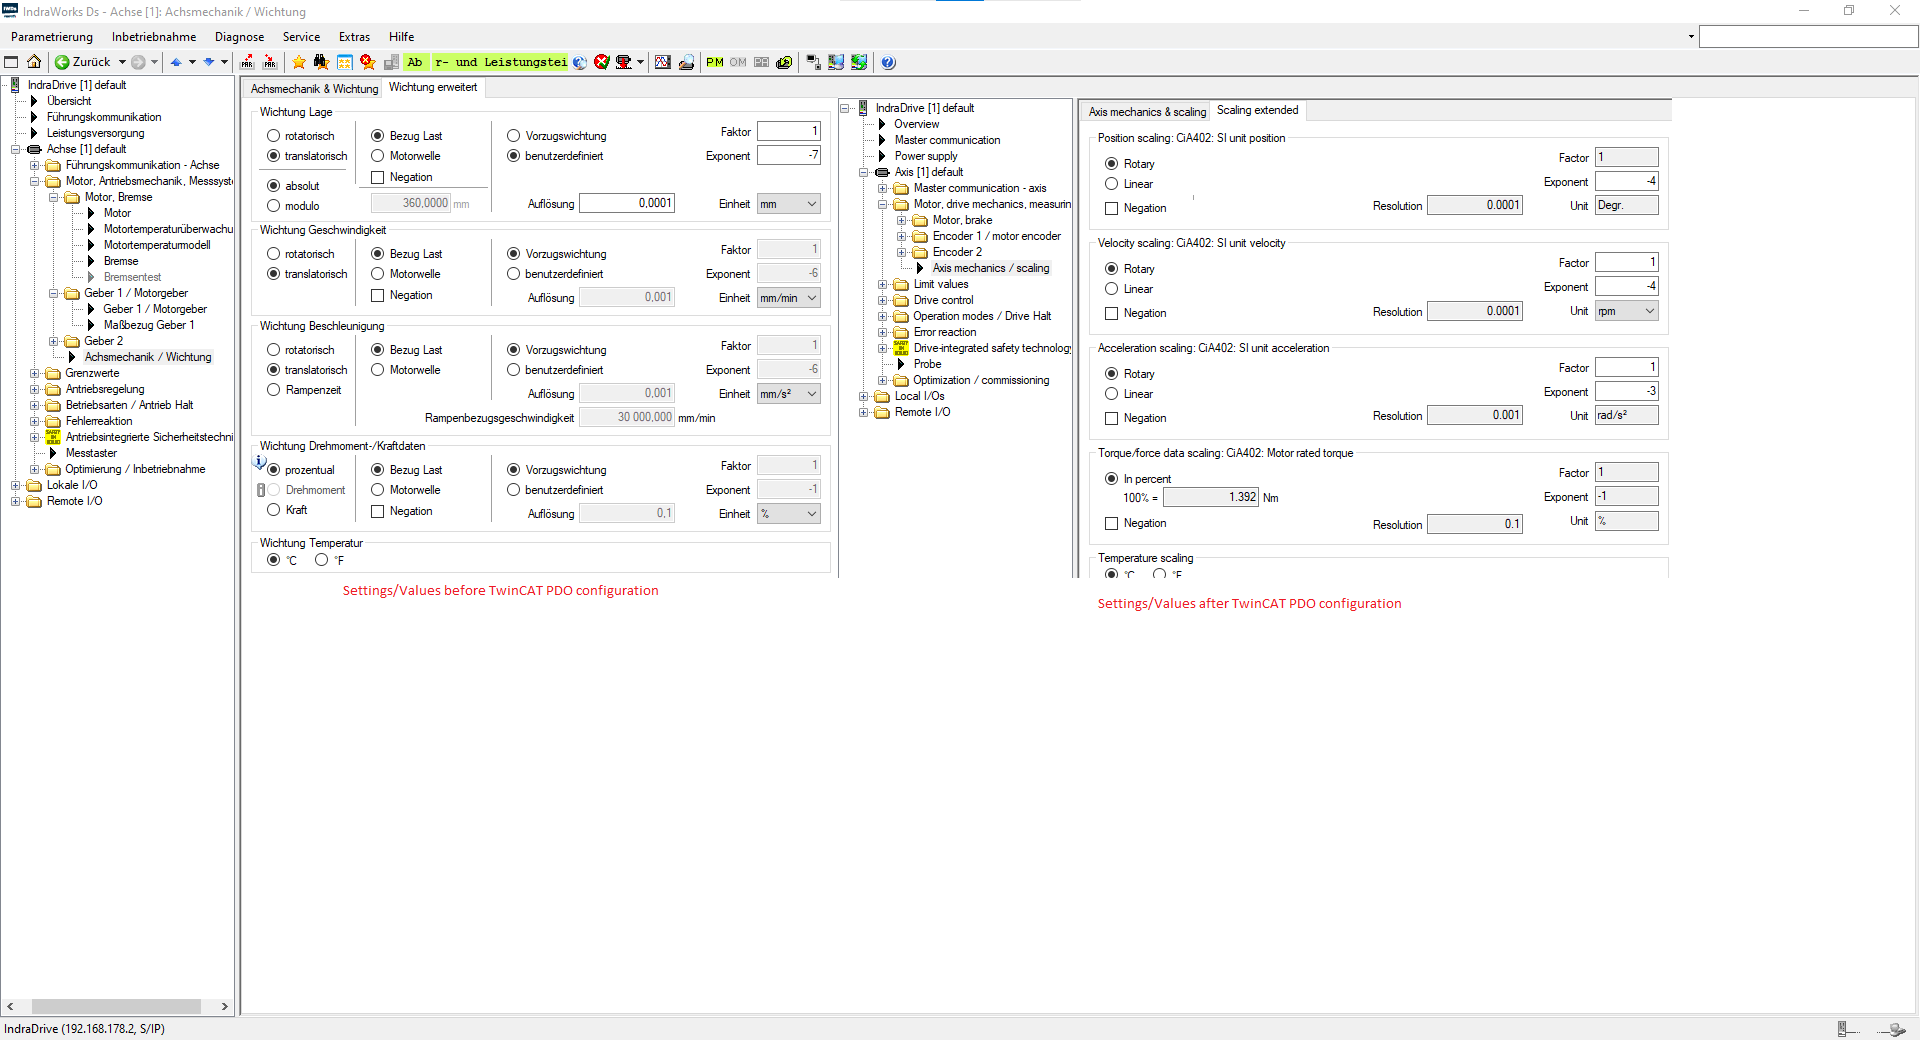
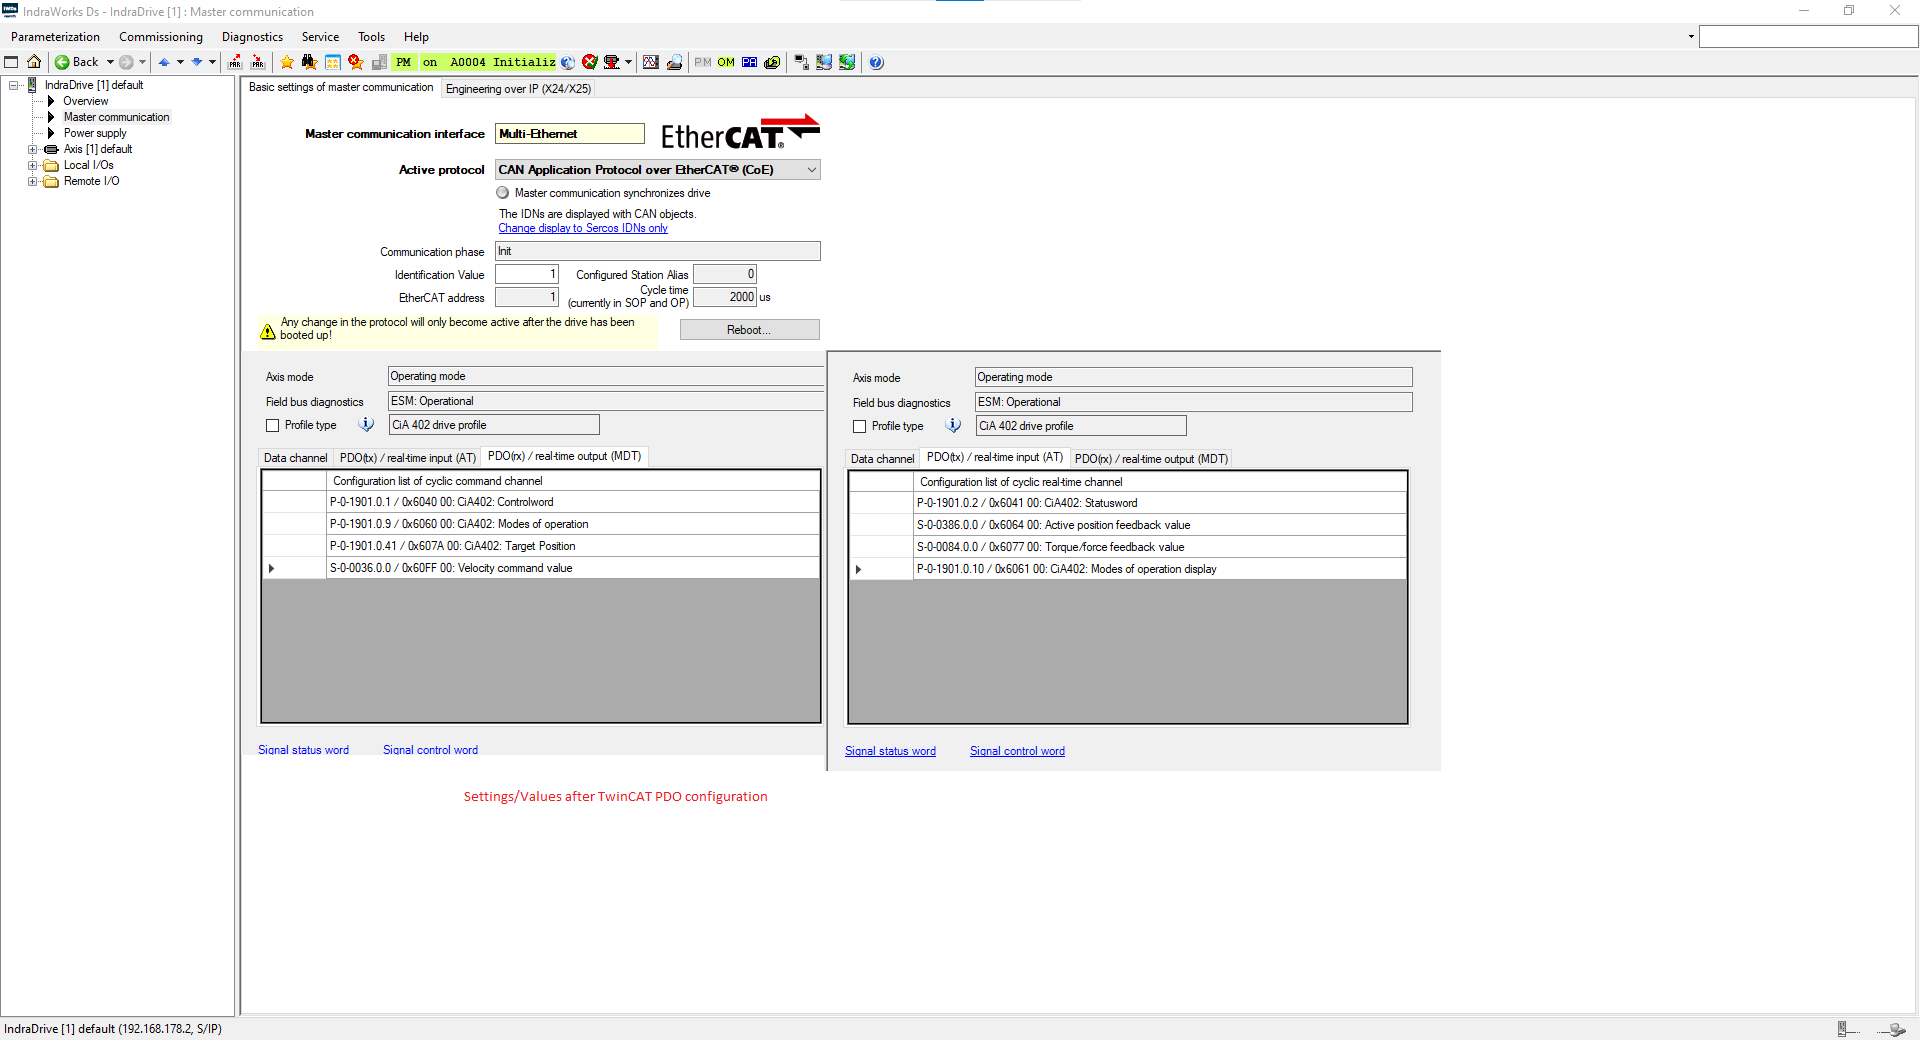
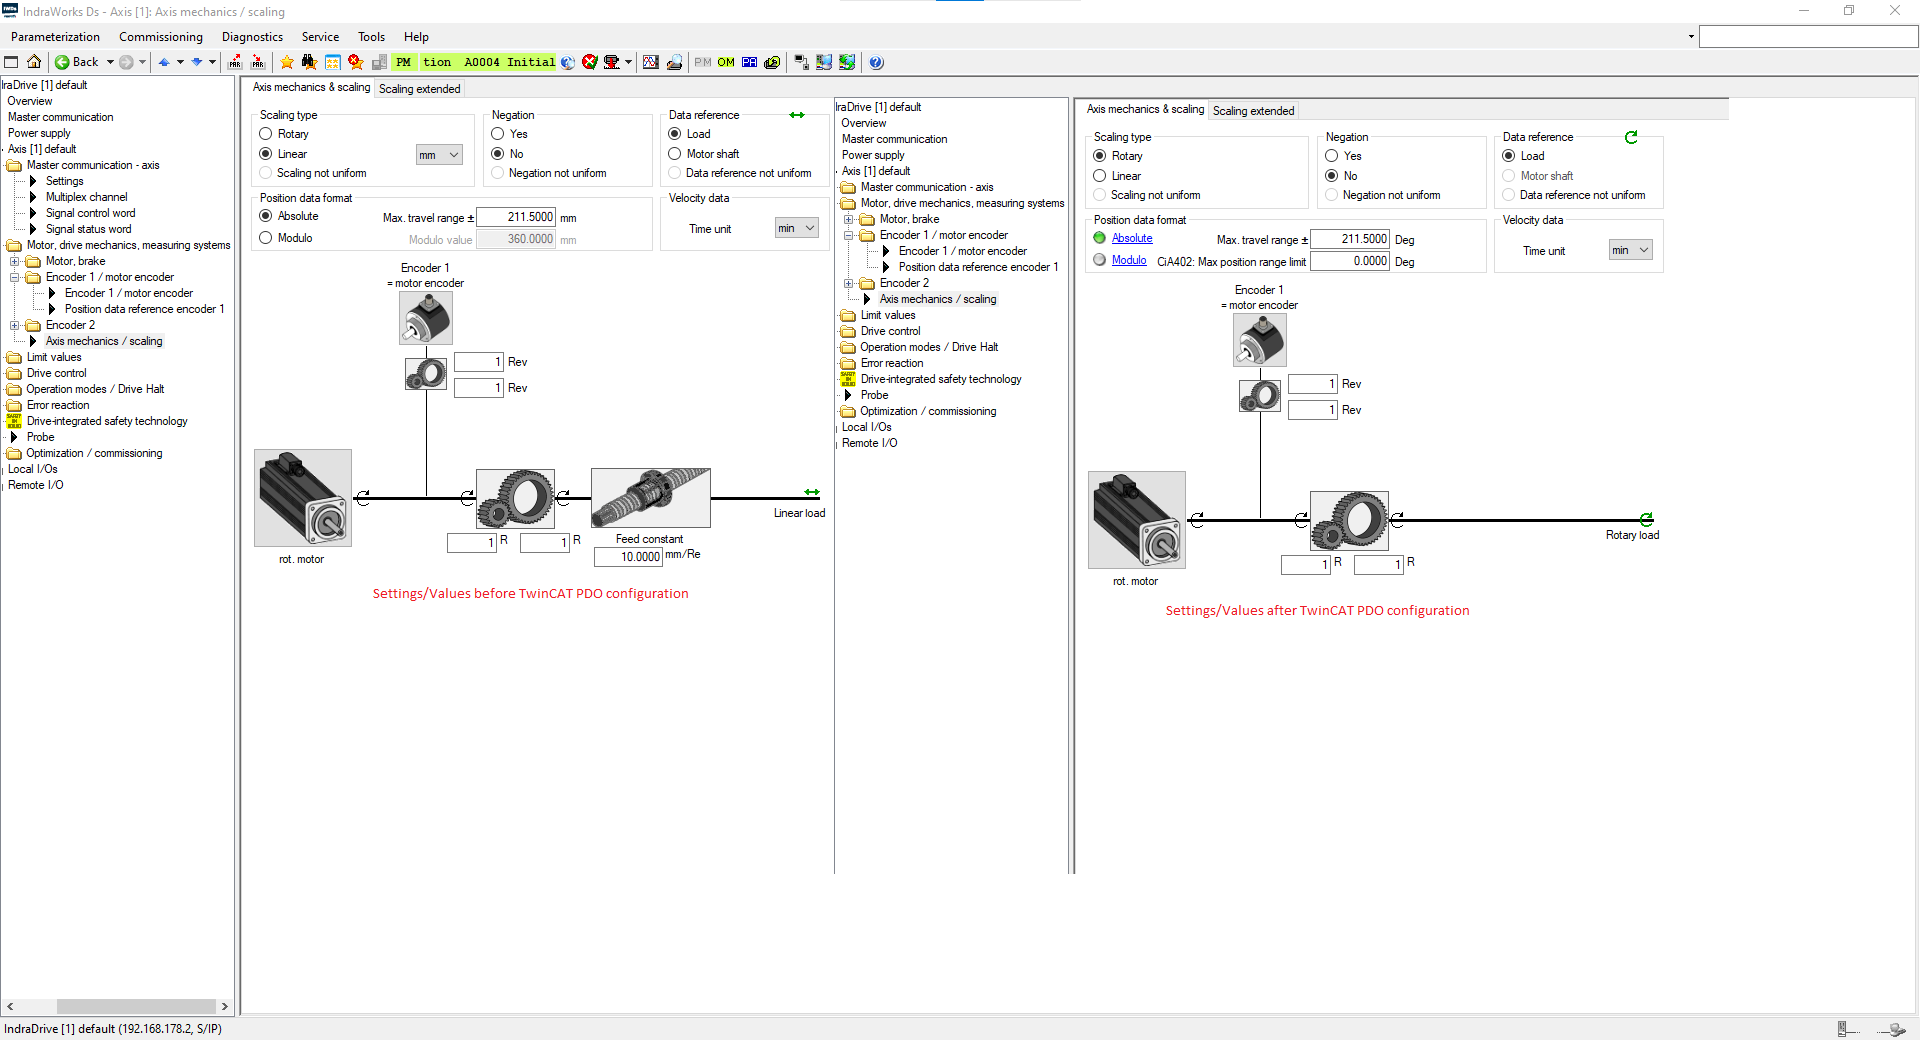
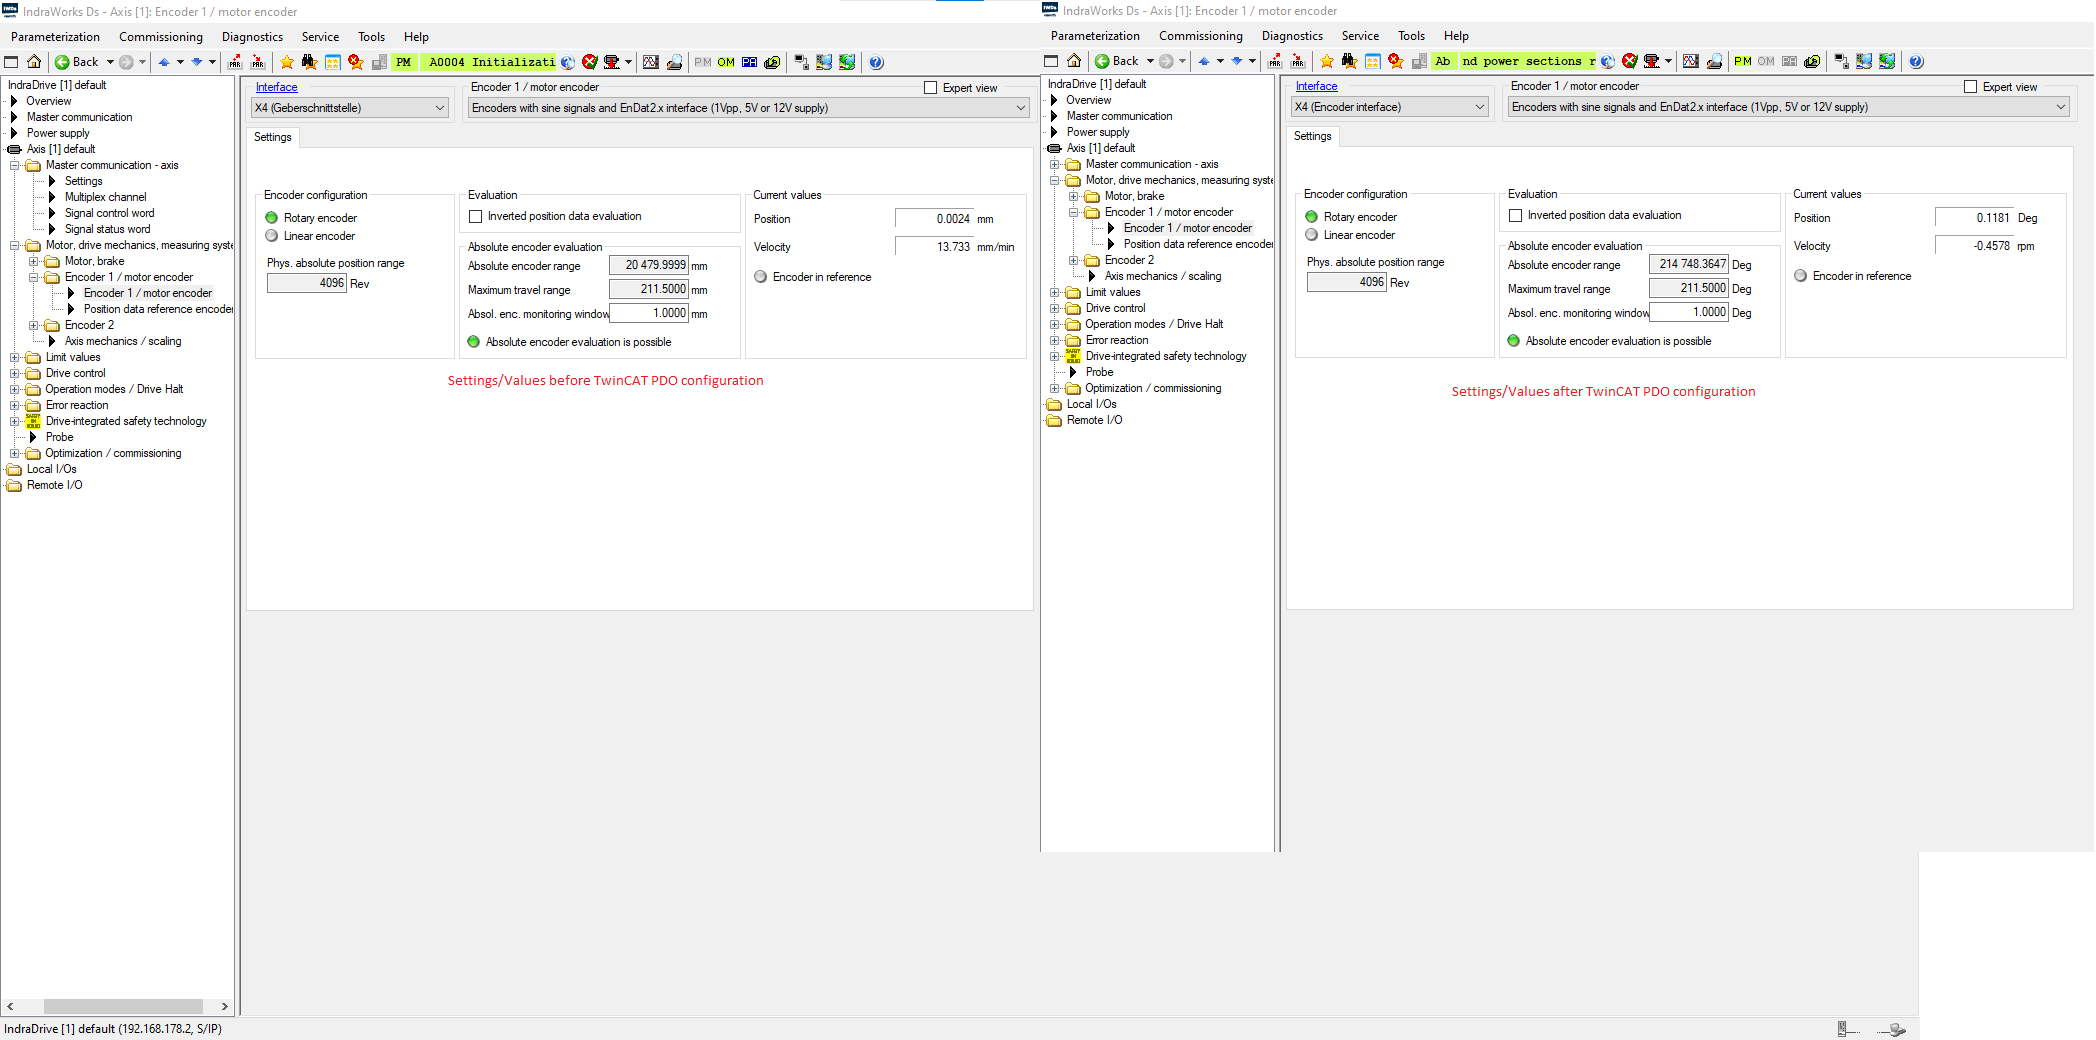
Replied by jc2ktr on topic Ethercat HAL driver
chimeno wrote: Hello @jc2ktr
not if you have already solved it, but the error is in line 11 and 13It stucks at line 12 with a Parse error but i can't solve it.
Hope anyone can take a short look over my File.
I attach the example
ErrorSolutionCode:<syncManager idx="0" dir="out"/> </syncManager> <syncManager idx="1" dir="in"/> </syncManager>Code:<syncManager idx="0" dir="out"> </syncManager> <syncManager idx="1" dir="in"> </syncManager>
I think you would have to send an email to the Bosch company to see if they can send you the file.Hi folks,
#does someone have the original Bosch-Rexroth XML Description for TwinCAT? The one i can download from the Rexroth page does #not support the firmware of my drive. The drive is FW version 18V34 and the downloadable XML is for 20V26.
#Unfortunatley Rexroth does not have an Donwload Archive on their Website.
#And my Servomotor is not supportet by the new Firmware version.
Greeting Chimeno
I´ve got my Drive up and running under LinuxCNC, with the Firmware 20V26 and the Rexroth XML for COE which is delivered with the Indraworks DS Software from Rexroth.
But when i setup the drive with indraworks DS to my needed Scaling and Mechanical setting, and then let TwinCAT configure the Drive that LinuxCNC is able to "control" the drive. all of my previous Parameters will be overridden.
I will add some Images which should provide some of my issues.
When i try to change the Settings after TwinCAT reconfigured them the Indraworks software generates various Error messages which i can´t resolve with my momentary knowledge.
The following user(s) said Thank You: Nico2017
Please Log in or Create an account to join the conversation.
- db1981
- Offline
- Platinum Member
-

Less
More
- Posts: 790
- Thank you received: 276
5 years 8 months ago - 5 years 8 months ago #198812
by db1981
Replied by db1981 on topic Ethercat HAL driver
Hello,
the drives get its SDO Parameters at the startup from the Ethercat master, so if this is a drive in which you can't permanently save the initcmds, you will start with an empty drive config.
if you don't tell twincat the values of the idn's, it will change the drives config.
Why do you need twincat to make the drive controlable with linuxcnc?
Last edit: 5 years 8 months ago by db1981.
The following user(s) said Thank You: jc2ktr
Please Log in or Create an account to join the conversation.
- jc2ktr
- Offline
- Premium Member
-
Less
More
- Posts: 87
- Thank you received: 17
5 years 8 months ago - 5 years 8 months ago #198838
by jc2ktr
I don´t know where to set up the IDN´s in TwinCAT, in the Tutorials it was mentioned to first set up the drive and then let TwinCAT configure the PDO and the Telegrams.
I saved my Drives Parameters after the Initial Setup of the Motor and Encoder in Indraworks, when i change the Master Communication to Ethercat CoE and i reboot the drive, i can not get the Drive in OP state under Linuxcnc, it only boots in INIT state, and the Status light on the Ethernet jack don´t show any Activity. it seems that TwinCAT is needed to Setup the PDO´s and some other settings. I don´t know much about EtherCAT and/or Rexroth Servodrives to tell what´s going on in the background. I tried to get the drive working without TwinCAT but was not succesfull so far.
I also tried this way Linuxcnc ethercat vs Indradrive rexroth HCS01
But i don´t speak Czech, and the Translation from Google Chrome is sometimes a bit Tricky to understand.
And also the Configuration tutorial for IndraDrives don´t get me very far, in both Tutorials is TwinCAT or the Ethercat Configurator used to Change/Map the Drives PDO´s
But these Tutorials are rarther old and the actual Firmware and XML configuration file from Rexroth is capable to use Canopen over EtherCAT (cia402) to control the drive, And the Tutorials are meant for Servo over EtherCAT.
Replied by jc2ktr on topic Ethercat HAL driver
db1981 wrote: Hello,
the drives get its SDO Parameters at the startup from the Ethercat master, so if this is a drive in which you can't permanently save the initcmds, you will start with an empty drive config.
if you don't tell twincat the values of the idn's, it will change the drives config.
Why do you need twincat to make the drive controlable with linuxcnc?
I don´t know where to set up the IDN´s in TwinCAT, in the Tutorials it was mentioned to first set up the drive and then let TwinCAT configure the PDO and the Telegrams.
I saved my Drives Parameters after the Initial Setup of the Motor and Encoder in Indraworks, when i change the Master Communication to Ethercat CoE and i reboot the drive, i can not get the Drive in OP state under Linuxcnc, it only boots in INIT state, and the Status light on the Ethernet jack don´t show any Activity. it seems that TwinCAT is needed to Setup the PDO´s and some other settings. I don´t know much about EtherCAT and/or Rexroth Servodrives to tell what´s going on in the background. I tried to get the drive working without TwinCAT but was not succesfull so far.
I also tried this way Linuxcnc ethercat vs Indradrive rexroth HCS01
But i don´t speak Czech, and the Translation from Google Chrome is sometimes a bit Tricky to understand.
And also the Configuration tutorial for IndraDrives don´t get me very far, in both Tutorials is TwinCAT or the Ethercat Configurator used to Change/Map the Drives PDO´s
But these Tutorials are rarther old and the actual Firmware and XML configuration file from Rexroth is capable to use Canopen over EtherCAT (cia402) to control the drive, And the Tutorials are meant for Servo over EtherCAT.
Last edit: 5 years 8 months ago by jc2ktr. Reason: Edit
Please Log in or Create an account to join the conversation.
- db1981
- Offline
- Platinum Member
-
Less
More
- Posts: 790
- Thank you received: 276
5 years 8 months ago #198841
by db1981
Replied by db1981 on topic Ethercat HAL driver
Linuxcnc ethercat can also do native SoE Drives.
What ServoDrive is this exactly?
Do you have an working Twincat Setup for your drive?
If yes, please select the drive in the left tree -> right click -> export box,
select the drive in the left tree -> actions menu -> export xml.
post the .tce and the .xml file.
What ServoDrive is this exactly?
Do you have an working Twincat Setup for your drive?
If yes, please select the drive in the left tree -> right click -> export box,
select the drive in the left tree -> actions menu -> export xml.
post the .tce and the .xml file.
The following user(s) said Thank You: jc2ktr
Please Log in or Create an account to join the conversation.
- jc2ktr
- Offline
- Premium Member
-
Less
More
- Posts: 87
- Thank you received: 17
5 years 8 months ago #198850
by jc2ktr
It is an Rexroth HCS01.1E-W0009-A-02-B-ET-EC-NN-L4-NN-FW with the Firmware version MPB20V26.
What do you mean with working TwinCAT Setup? I can Enable the Drive and jog it around, but not very far and then it gets a Position Following Error.
I can post the Files tomorrow when i´am in the Office/Shop where my Testbench is.
Thank you for your help so far.
Replied by jc2ktr on topic Ethercat HAL driver
db1981 wrote: Linuxcnc ethercat can also do native SoE Drives.
What ServoDrive is this exactly?
Do you have an working Twincat Setup for your drive?
If yes, please select the drive in the left tree -> right click -> export box,
select the drive in the left tree -> actions menu -> export xml.
post the .tce and the .xml file.
It is an Rexroth HCS01.1E-W0009-A-02-B-ET-EC-NN-L4-NN-FW with the Firmware version MPB20V26.
What do you mean with working TwinCAT Setup? I can Enable the Drive and jog it around, but not very far and then it gets a Position Following Error.
I can post the Files tomorrow when i´am in the Office/Shop where my Testbench is.
Thank you for your help so far.
Please Log in or Create an account to join the conversation.
- db1981
- Offline
- Platinum Member
-
Less
More
- Posts: 790
- Thank you received: 276
5 years 8 months ago #198853
by db1981
Replied by db1981 on topic Ethercat HAL driver
okay, please post also your indraworks version and the config file.
Please Log in or Create an account to join the conversation.
Time to create page: 2.710 seconds