Search Results (Searched for: 7i76e)

  • RaspII
08 Dec 2025 22:02 - 08 Dec 2025 22:10
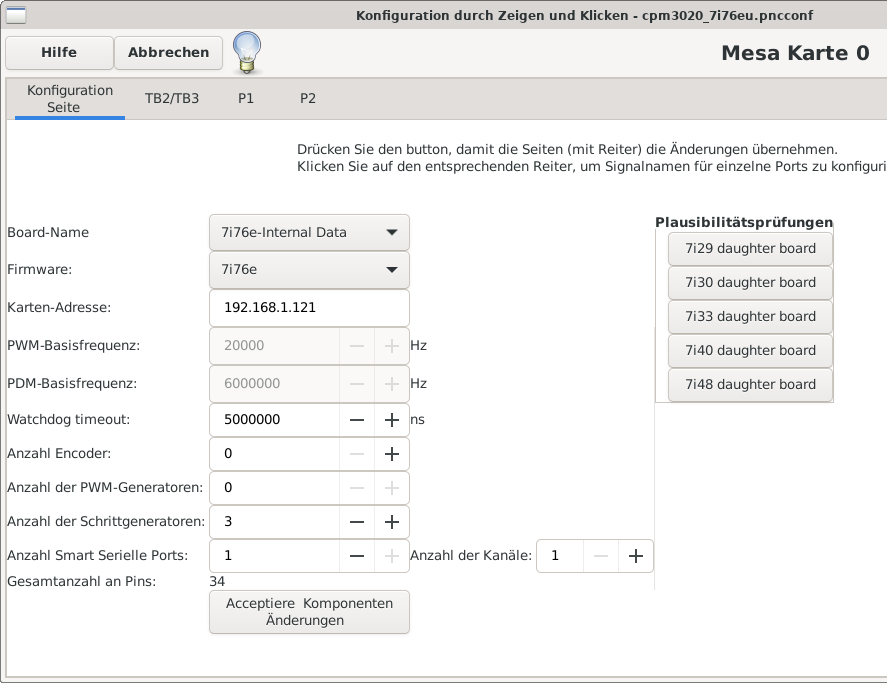
I don't have the tab with "7i76 I/O,

 
  • PCW
08 Dec 2025 19:47 - 08 Dec 2025 19:49
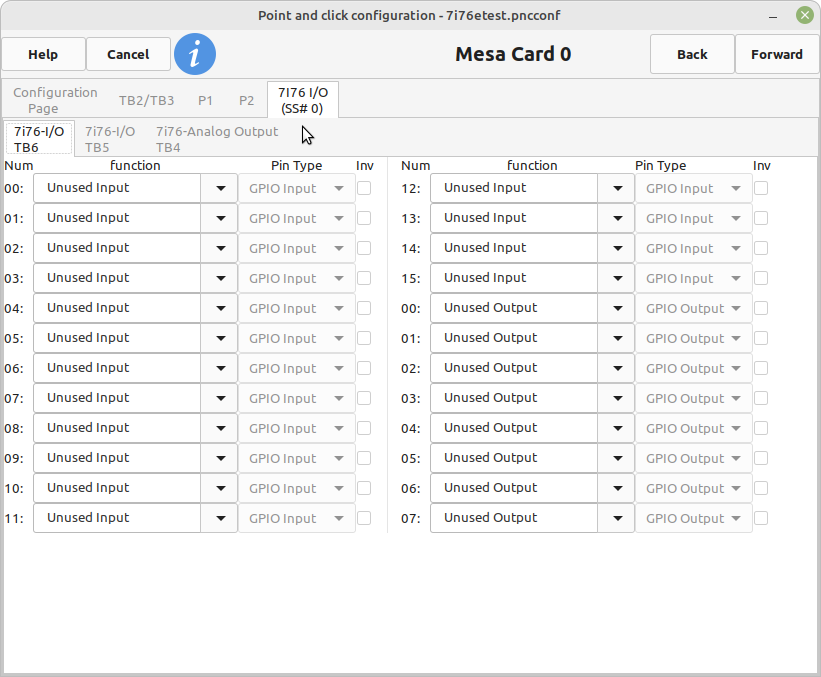
You should get a screen like this:


If not. it may be that you have hit a locale bug in pncconf and may have to
temporarily set the locale language to  en_US to work around the issue.
  • RaspII
08 Dec 2025 19:13
Hallo,
ich bin gerade am Umbau einer ISEL CPM3020 von IMC4 auf MESA 7i76EU. Die Kommunikation von LinuxCNC zur Karte funktioniert.
Aktuell hänge ich an der Konfiguration der Referenz- und Endschalter fest. Ich versuche via Pncconf die Pins festzulegen, finde aber im Menu "Mesa Karte 0" nur Zuordungen für TB2/TB3, P1 und P2. Bei P1/P2 könnte ich die Schalter zwar anlegen, dann bekomme ich aber Pin Nummern die m.E. mit den Field I/Os nichts zu tun haben sondern nur mit den I/O Expansion connectoren. Ich habe trotzdem mal darüber die Schalter konfiguriert, das Ergebnis sieht in der HAL Datei dann wie folgt aus (Leerzeilen entfernt):# externe Signaleingänge
# --- MIN-HOME-X ---
net min-home-x     <=  hm2_7i76e.0.gpio.017.in
# --- MAX-X ---
net max-x     <=  hm2_7i76e.0.gpio.018.in
# --- MIN-HOME-Y ---
net min-home-y     <=  hm2_7i76e.0.gpio.019.in
# --- MAX-Y ---
net max-y     <=  hm2_7i76e.0.gpio.020.in
# --- MIN-Z ---
net min-z     <=  hm2_7i76e.0.gpio.021.in
# --- MAX-HOME-Z ---
net max-home-z     <=  hm2_7i76e.0.gpio.022.in


Eine Konfigurationsseite für TB5 oder TB6 zur Konfiguration der Field I/Os kann ich nicht finden. Wo ist mein Denkfehler? 
  • djdelorie
07 Dec 2025 21:46 - 07 Dec 2025 21:47
Replied by djdelorie on topic Clearpath HLFB amp.joint.delay
I just did this for my CNC. Here are the HAL bits I used.  Amusingly, I can't find where <axis>-fault is connected, but I *do* get following errors when I hit things.  More testing required...

addf and2.3 servo-thread
addf and2.4 servo-thread
addf and2.5 servo-thread
addf and2.6 servo-thread
addf and2.7 servo-thread
addf timedelay.0 servo-thread

setp timedelay.0.on-delay 1
setp timedelay.0.off-delay 0

net machine-is-on => timedelay.0.in
net enable-faults <= timedelay.0.out

net x-enable  => hm2_7i76e.0.7i76.0.0.output-08 # TB5 leftmost output
net y-enable  => hm2_7i76e.0.7i76.0.0.output-09
net y2-enable => hm2_7i76e.0.7i76.0.0.output-10
net z-enable  => hm2_7i76e.0.7i76.0.0.output-11
net a-enable  => hm2_7i76e.0.7i76.0.0.output-12

# HLFB is true when enabled *and* following
net hlfb_x  hm2_7i76e.0.7i76.0.0.input-16-not # TB5 leftmost
net hlfb_y  hm2_7i76e.0.7i76.0.0.input-17-not
net hlfb_y2 hm2_7i76e.0.7i76.0.0.input-18-not
net hlfb_z  hm2_7i76e.0.7i76.0.0.input-19-not
net hlfb-a  hm2_7i76e.0.7i76.0.0.input-20-not

net hlfb_x        => and2.3.in0
net enable-faults => and2.3.in1
net x-fault       <= and2.3.out

net hlfb_y        => and2.4.in0
net enable-faults => and2.4.in1
net y-fault       <= and2.4.out

net hlfb_y2       => and2.5.in0
net enable-faults => and2.5.in1
net y2-fault      <= and2.5.out

net hlfb_z        => and2.6.in0
net enable-faults => and2.6.in1
net z-fault       <= and2.6.out

net hlfb_a        => and2.7.in0
net enable-faults => and2.7.in1
net a-fault       <= and2.7.out
 
  • endian
06 Dec 2025 15:20
Replied by endian on topic Reduce read-all timing 7i76e + 7i77
Code:
sudo apt install linux-cpupower sudo cpupower frequency-set --governor performance

I have had loong time before network tunning done this ... it is basic stuff for latency reduction at any hardware

I will do the kill of EEE and I will share the resaults in comming weeks .. thanks for hint !

regards 
  • LearningLinuxCNC
06 Dec 2025 02:42
Replied by LearningLinuxCNC on topic Mesa Configuration Tool
I did not get a working stepper configuration out of MesaCT with a 7i76eu. I have posted the output and my working config here forum.linuxcnc.org/configuration-tools/5...erated-configuration

The output was supposed to be on the 02 stepper but it was connected to the 00 stepper. The feedback loop was not closed and it was not set to be in velocity mode. Look at the two configurations.
  • PCW
05 Dec 2025 17:26
You might post a link to this thread on the MesaCT topic
  • LearningLinuxCNC
04 Dec 2025 22:57
Replied by LearningLinuxCNC on topic MesaCT and 7i76eu Issues with generated configuration
Here is a generated HAL file X axis configuration.
Code:
# Axis: X Joint: 0 Output: 2 # PID Setup setp pid.x.Pgain [JOINT_0](P) setp pid.x.Igain [JOINT_0](I) setp pid.x.Dgain [JOINT_0](D) setp pid.x.bias [JOINT_0](BIAS) setp pid.x.FF0 [JOINT_0](FF0) setp pid.x.FF1 [JOINT_0](FF1) setp pid.x.FF2 [JOINT_0](FF2) setp pid.x.deadband [JOINT_0](DEADBAND) setp pid.x.maxoutput [JOINT_0](MAX_OUTPUT) setp pid.x.error-previous-target True # joint-0 enable chain net joint-0-index-enable <=> pid.x.index-enable net joint-0-index-enable <=> joint.0.index-enable net joint-0-enable <= joint.0.amp-enable-out net joint-0-enable => pid.x.enable # position command and feedback net joint-0-pos-cmd <= joint.0.motor-pos-cmd net joint-0-pos-cmd => pid.x.command net joint-0-pos-fb <= hm2_[MESA](BOARD).0.stepgen.00.position-fb net joint-0-pos-fb => joint.0.motor-pos-fb net joint-0-pos-fb => pid.x.feedback # PID Output net joint.0.output <= pid.x.output # Axis: Z Joint: 1 Output: 3

This is what I had to change it to in order to make it work properly.
Code:
# Axis: X Joint: 0 Output: 2 # PID Setup setp pid.x.Pgain [JOINT_0](P) setp pid.x.Igain [JOINT_0](I) setp pid.x.Dgain [JOINT_0](D) setp pid.x.bias [JOINT_0](BIAS) setp pid.x.FF0 [JOINT_0](FF0) setp pid.x.FF1 [JOINT_0](FF1) setp pid.x.FF2 [JOINT_0](FF2) setp pid.x.deadband [JOINT_0](DEADBAND) setp pid.x.maxoutput [JOINT_0](MAX_OUTPUT) setp pid.x.error-previous-target True setp pid.x.maxerror 0.0005 # joint-0 enable chain net joint-0-index-enable <=> pid.x.index-enable net joint-0-index-enable <=> joint.0.index-enable net joint-0-enable <= joint.0.amp-enable-out net joint-0-enable => pid.x.enable net joint-0-enable => hm2_[MESA](BOARD).0.stepgen.02.enable # position command and feedback net joint-0-pos-cmd <= joint.0.motor-pos-cmd net joint-0-pos-cmd => pid.x.command net joint-0-vel-cmd <= joint.0.vel-cmd net joint-0-pos-fb <= hm2_[MESA](BOARD).0.stepgen.02.position-fb net joint-0-pos-fb => joint.0.motor-pos-fb net joint-0-pos-fb => pid.x.feedback # PID Output net joint.0.output <= pid.x.output net joint.0.output => hm2_[MESA](BOARD).0.stepgen.02.velocity-cmd
  • LearningLinuxCNC
04 Dec 2025 20:23 - 04 Dec 2025 20:23
Replied by LearningLinuxCNC on topic Mesa 7i76eu Encoder Questions
7i76eud.bin firmware did the trick. Interesting this firmware does not show up in the MesaCT list when using the Configuration Tool. It was in the /lib/firmware/hm2/ folder but it was not showing up in the drop down list.
  • LearningLinuxCNC
04 Dec 2025 02:06
It could be that I am an imbecile. However when I used MesaCT as installed per the instructions here using apt  gnipsel.com/linuxcnc/mesact/install.html#install-with-apt . I did not get an anywhere near working configuration out of the tool. The stepper configurations were very incomplete. The feedback loop was not closed in fact the PID output was not even sent to the mesa stepper driver. 

I will post up my configuration files from the output shortly. 
  • PCW
04 Dec 2025 02:03 - 04 Dec 2025 20:41
Replied by PCW on topic Mesa 7i76eu Encoder Questions
If you don't have an added parallel daughtercard, you should normally not change the
installed firmware.

The default 7I76EU firmware is 7i76eud.bin, to re-install:

mesaflash --device 7i76eu --addr [card_ip_address] --write 7i76eud.bin --reload

where [card_ip_address]  is either 192.168.1.121 or 10.10.10.10 depending on how you
have the card setup.

 
  • LearningLinuxCNC
04 Dec 2025 01:54
Mesa 7i76eu Encoder Questions was created by LearningLinuxCNC
I have a 7i76eu that I am using on a new lathe conversion. I must have something wrong with firmware or something on the 7i76eu. The configuration is set up with 3 encoders is what it says. I only have one encoder connected to the 7i76 on tb3. It is configured as single ended jumpers w11 w12 and w16 all set to the left position (up in my case). When I look at the inputs in halshow the A signal is showing up as the A signal on encoder 0, the B signal is showing up as the A signal on encoder 1 and the index signal is showing up as the A signal on encoder 2.

What do I have incorrect here. My mesa setup is a 7i76eu with just a 7i73 pendant smart serial card. I have one spindle drive, one encoder that I am using on the 7i76 two steppers and several io.

I downloaded the firmware pack from Mesa. I installed one that just had the 7i76in the name but no other cards. Which firmware should I use in this case? 

Not sure if this is a config or a firmware mismatch issue. Any help would be appreciated.
  • rodw
04 Dec 2025 01:38
Replied by rodw on topic Reduce read-all timing 7i76e + 7i77
Working through this,

irqbalance was not installed by default in Debian since Debian 9 Stretch because the kernel now does its own rebalancing. In some case irqbalance has caused  instabilities. Accordingly any advice about irqbalance is obsolete. If you have installed it, you should purge it
sudo apt purge irqbalance

Also cpufrequtils is deprecated in Trixie and has been replaced by the  linux-cpupower package. to set your governor to performance, use ( I think)
Code:
sudo apt install linux-cpupower sudo cpupower frequency-set --governor performance
  • rodw
03 Dec 2025 20:13
Replied by rodw on topic Reduce read-all timing 7i76e + 7i77
Also, I did not see where you are disabling Energy Efficient Ethernet.  It is supposed to be disabled by default but this is not always the case. There are some flags that can be set in GRUB but they are driver specific. eg. igb.EEE=0 

I have not tested this but This is a robust way to ensure EEE is disabled on every boot. Create a new systemd service file:
sudo geany /etc/systemd/system/disable-eee.service
  1. Add the following content, replacing enp6s0 with your interface name. This service will run ethtool after the network is up.
Code:
[Unit]Description=Disable Energy Efficient Ethernet (EEE)After=network-online.target [Service]Type=oneshotExecStart=/usr/sbin/ethtool --set-eee enp6s0 eee off [Install]WantedBy=multi-user.target
  1. Save and close the file.
Reload the systemd daemon:
Code:
sudo systemctl daemon-reload
Enable and start the service:
Code:
sudo systemctl enable disable-eee.service sudo systemctl start disable-eee.service
  • endian
03 Dec 2025 20:06
Replied by endian on topic Reduce read-all timing 7i76e + 7i77
Yes, i read thier manual 1k times.. it is pretty solid extraction of what we all need...

Yes I am recompiling everytime to native NIC driver as common e1000e or rtl8190too ... It works pretty solid for 8khz thread 
8190too are basically free stuff on the market right now it cost few bucks

There are native drivers for beckhoff too but I have never tried them yet ... 

I am not expert in this drivers ..but if it will improve my latency i need them all ...
 
Displaying 316 - 330 out of 352 results.
Time to create page: 0.314 seconds
Powered by Kunena Forum