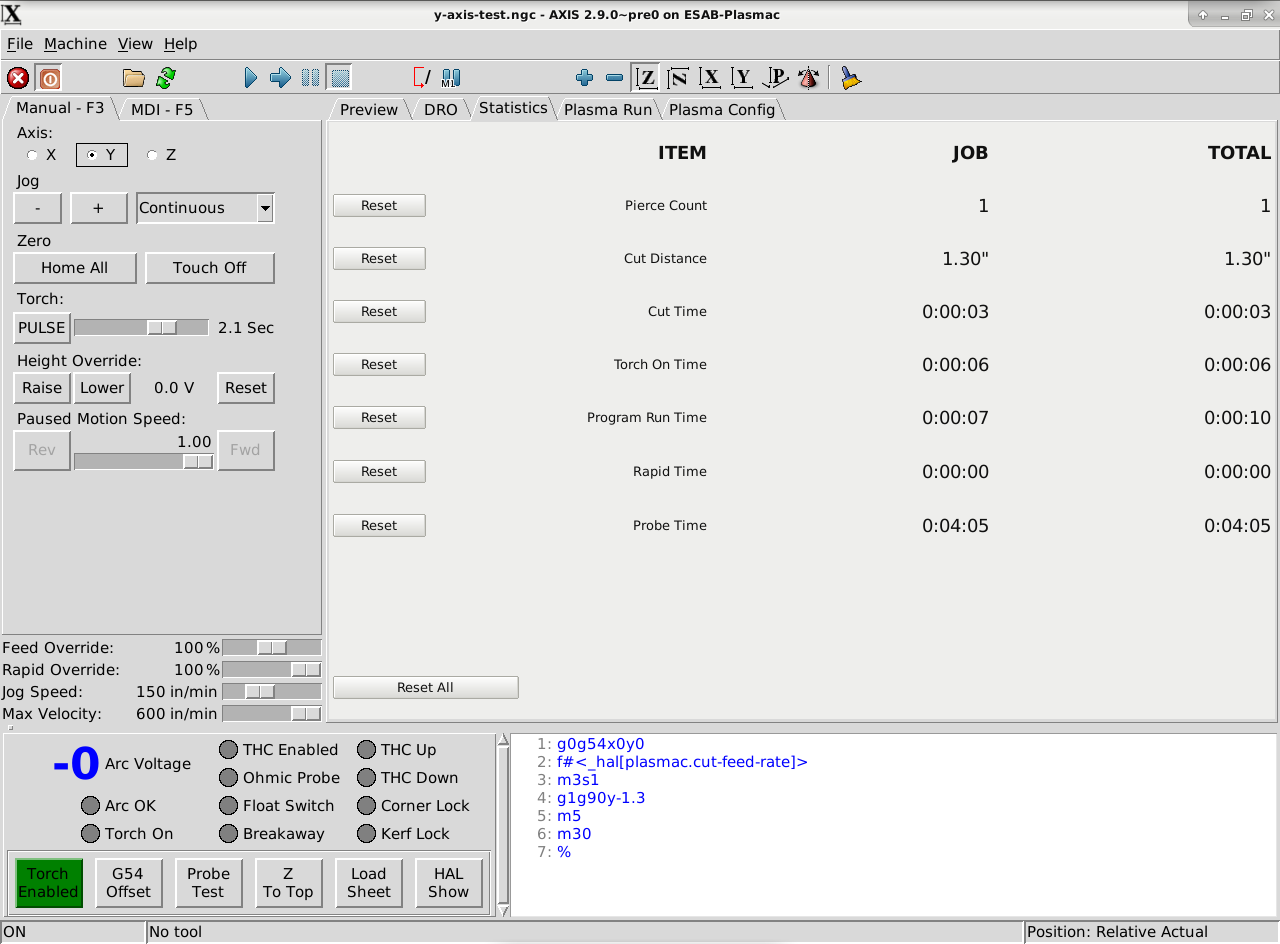
No PROBE: OFF message the counter keeps running until I quit. I've attached my files if that helps you duplicate.
Code:
mkardasi@LinuxCNC:~$ cd linuxcnc-dev/src
mkardasi@LinuxCNC:~/linuxcnc-dev/src$ source ../scripts/rip-environment
mkardasi@LinuxCNC:~/linuxcnc-dev/src$ linuxcnc
LINUXCNC - 2.9.0~pre0
Machine configuration directory is '/home/mkardasi/linuxcnc/configs/esab-plasmac'
Machine configuration file is 'esab-plasmac.ini'
Starting LinuxCNC...
twopass:invoked with <> options
twopass:found ./esab-plasmac.hal
twopass:found ./plasmac.hal
twopass:found ./esab-plasmac_connections.hal
Note: Using POSIX realtime
hm2: loading Mesa HostMot2 driver version 0.15
hm2_eth: loading Mesa AnyIO HostMot2 ethernet driver version 0.2
hm2_eth: 10.10.10.10: Hardware address: 00:60:1b:16:00:c4
hm2_eth: discovered 7I96
hm2/hm2_7i96.0: Smart Serial Firmware Version 43
hm2/hm2_7i96.0: 51 I/O Pins used:
hm2/hm2_7i96.0: IO Pin 000 (TB3-01): IOPort
hm2/hm2_7i96.0: IO Pin 001 (TB3-02): IOPort
hm2/hm2_7i96.0: IO Pin 002 (TB3-03): IOPort
hm2/hm2_7i96.0: IO Pin 003 (TB3-04): IOPort
hm2/hm2_7i96.0: IO Pin 004 (TB3-05): IOPort
hm2/hm2_7i96.0: IO Pin 005 (TB3-06): IOPort
hm2/hm2_7i96.0: IO Pin 006 (TB3-07): IOPort
hm2/hm2_7i96.0: IO Pin 007 (TB3-08): IOPort
hm2/hm2_7i96.0: IO Pin 008 (TB3-09): IOPort
hm2/hm2_7i96.0: IO Pin 009 (TB3-10): IOPort
hm2/hm2_7i96.0: IO Pin 010 (TB3-11): IOPort
hm2/hm2_7i96.0: IO Pin 011 (TB3-13/TB3-14): SSR #0, pin Out-00 (Output)
hm2/hm2_7i96.0: IO Pin 012 (TB3-15/TB3-16): SSR #0, pin Out-01 (Output)
hm2/hm2_7i96.0: IO Pin 013 (TB3-17/TB3-18): SSR #0, pin Out-02 (Output)
hm2/hm2_7i96.0: IO Pin 014 (TB3-19/TB3-20): SSR #0, pin Out-03 (Output)
hm2/hm2_7i96.0: IO Pin 015 (TB3-21/TB3-22): SSR #0, pin Out-04 (Output)
hm2/hm2_7i96.0: IO Pin 016 (TB3-23/TB3-24): SSR #0, pin Out-05 (Output)
hm2/hm2_7i96.0: IO Pin 017 (TB1-02/TB1-03): StepGen #0, pin Step (Output)
hm2/hm2_7i96.0: IO Pin 018 (TB1-04/TB1-05): StepGen #0, pin Direction (Output)
hm2/hm2_7i96.0: IO Pin 019 (TB1-08/TB1-09): StepGen #1, pin Step (Output)
hm2/hm2_7i96.0: IO Pin 020 (TB1-10/TB1-11): StepGen #1, pin Direction (Output)
hm2/hm2_7i96.0: IO Pin 021 (TB1-14/TB1-15): StepGen #2, pin Step (Output)
hm2/hm2_7i96.0: IO Pin 022 (TB1-16/TB1-17): StepGen #2, pin Direction (Output)
hm2/hm2_7i96.0: IO Pin 023 (TB1-20/TB1-21): StepGen #3, pin Step (Output)
hm2/hm2_7i96.0: IO Pin 024 (TB1-22-TB1-23): StepGen #3, pin Direction (Output)
hm2/hm2_7i96.0: IO Pin 025 (TB2-01/TB2-03): IOPort
hm2/hm2_7i96.0: IO Pin 026 (TB2-04/TB2-05): IOPort
hm2/hm2_7i96.0: IO Pin 027 (TB2-07/TB2-08): Encoder #0, pin A (Input)
hm2/hm2_7i96.0: IO Pin 028 (TB2-10/TB2-11): Encoder #0, pin B (Input)
hm2/hm2_7i96.0: IO Pin 029 (TB2-13/TB2-14): Encoder #0, pin Index (Input)
hm2/hm2_7i96.0: IO Pin 030 (TB2-16/TB2-17): IOPort
hm2/hm2_7i96.0: IO Pin 031 (TB2-18/TB2-19): IOPort
hm2/hm2_7i96.0: IO Pin 032 (internal): IOPort
hm2/hm2_7i96.0: IO Pin 033 (internal): SSR #0, pin AC Ref (internal) (Output)
hm2/hm2_7i96.0: IO Pin 034 (P1-01): IOPort
hm2/hm2_7i96.0: IO Pin 035 (P1-02): IOPort
hm2/hm2_7i96.0: IO Pin 036 (P1-03): IOPort
hm2/hm2_7i96.0: IO Pin 037 (P1-04): IOPort
hm2/hm2_7i96.0: IO Pin 038 (P1-05): IOPort
hm2/hm2_7i96.0: IO Pin 039 (P1-06): IOPort
hm2/hm2_7i96.0: IO Pin 040 (P1-07): IOPort
hm2/hm2_7i96.0: IO Pin 041 (P1-08): IOPort
hm2/hm2_7i96.0: IO Pin 042 (P1-09): IOPort
hm2/hm2_7i96.0: IO Pin 043 (P1-11): IOPort
hm2/hm2_7i96.0: IO Pin 044 (P1-13): IOPort
hm2/hm2_7i96.0: IO Pin 045 (P1-15): IOPort
hm2/hm2_7i96.0: IO Pin 046 (P1-17): IOPort
hm2/hm2_7i96.0: IO Pin 047 (P1-19): IOPort
hm2/hm2_7i96.0: IO Pin 048 (P1-21): IOPort
hm2/hm2_7i96.0: IO Pin 049 (P1-23): IOPort
hm2/hm2_7i96.0: IO Pin 050 (P1-25): IOPort
hm2/hm2_7i96.0: registered
note: MAXV max: 10.000 units/sec 600.000 units/min
note: LJOG max: 10.000 units/sec 600.000 units/min
note: LJOG default: 2.500 units/sec 150.000 units/min
waiting for s.joints<0>, s.kinematics_type<0>
waiting for s.joints<0>, s.kinematics_type<0>
waiting for s.joints<0>, s.kinematics_type<0>
waiting for s.joints<0>, s.kinematics_type<0>
Warning: Forward kinematics must handle duplicate coordinate letters:yy
Note:
Individual axis homing is not currently supported for
KINEMATICS_IDENTITY with duplicate axis letter <Y>
note: jog_order='XYZ'
note: jog_invert=set([])
task: main loop took 0.153903 seconds
PROBE: ON 0.0
task: main loop took 0.148993 seconds
task: main loop took 0.141449 seconds
Shutting down and cleaning up LinuxCNC...
task: 9536 cycles, min=0.000007, max=0.153903, avg=0.010069, 3 latency excursions (> 10x expected cycle time of 0.010000s)
hm2_eth: HostMot2 ethernet driver unloaded
hm2: unloading
Note: Using POSIX realtime
mkardasi@LinuxCNC:~/linuxcnc-dev/src$