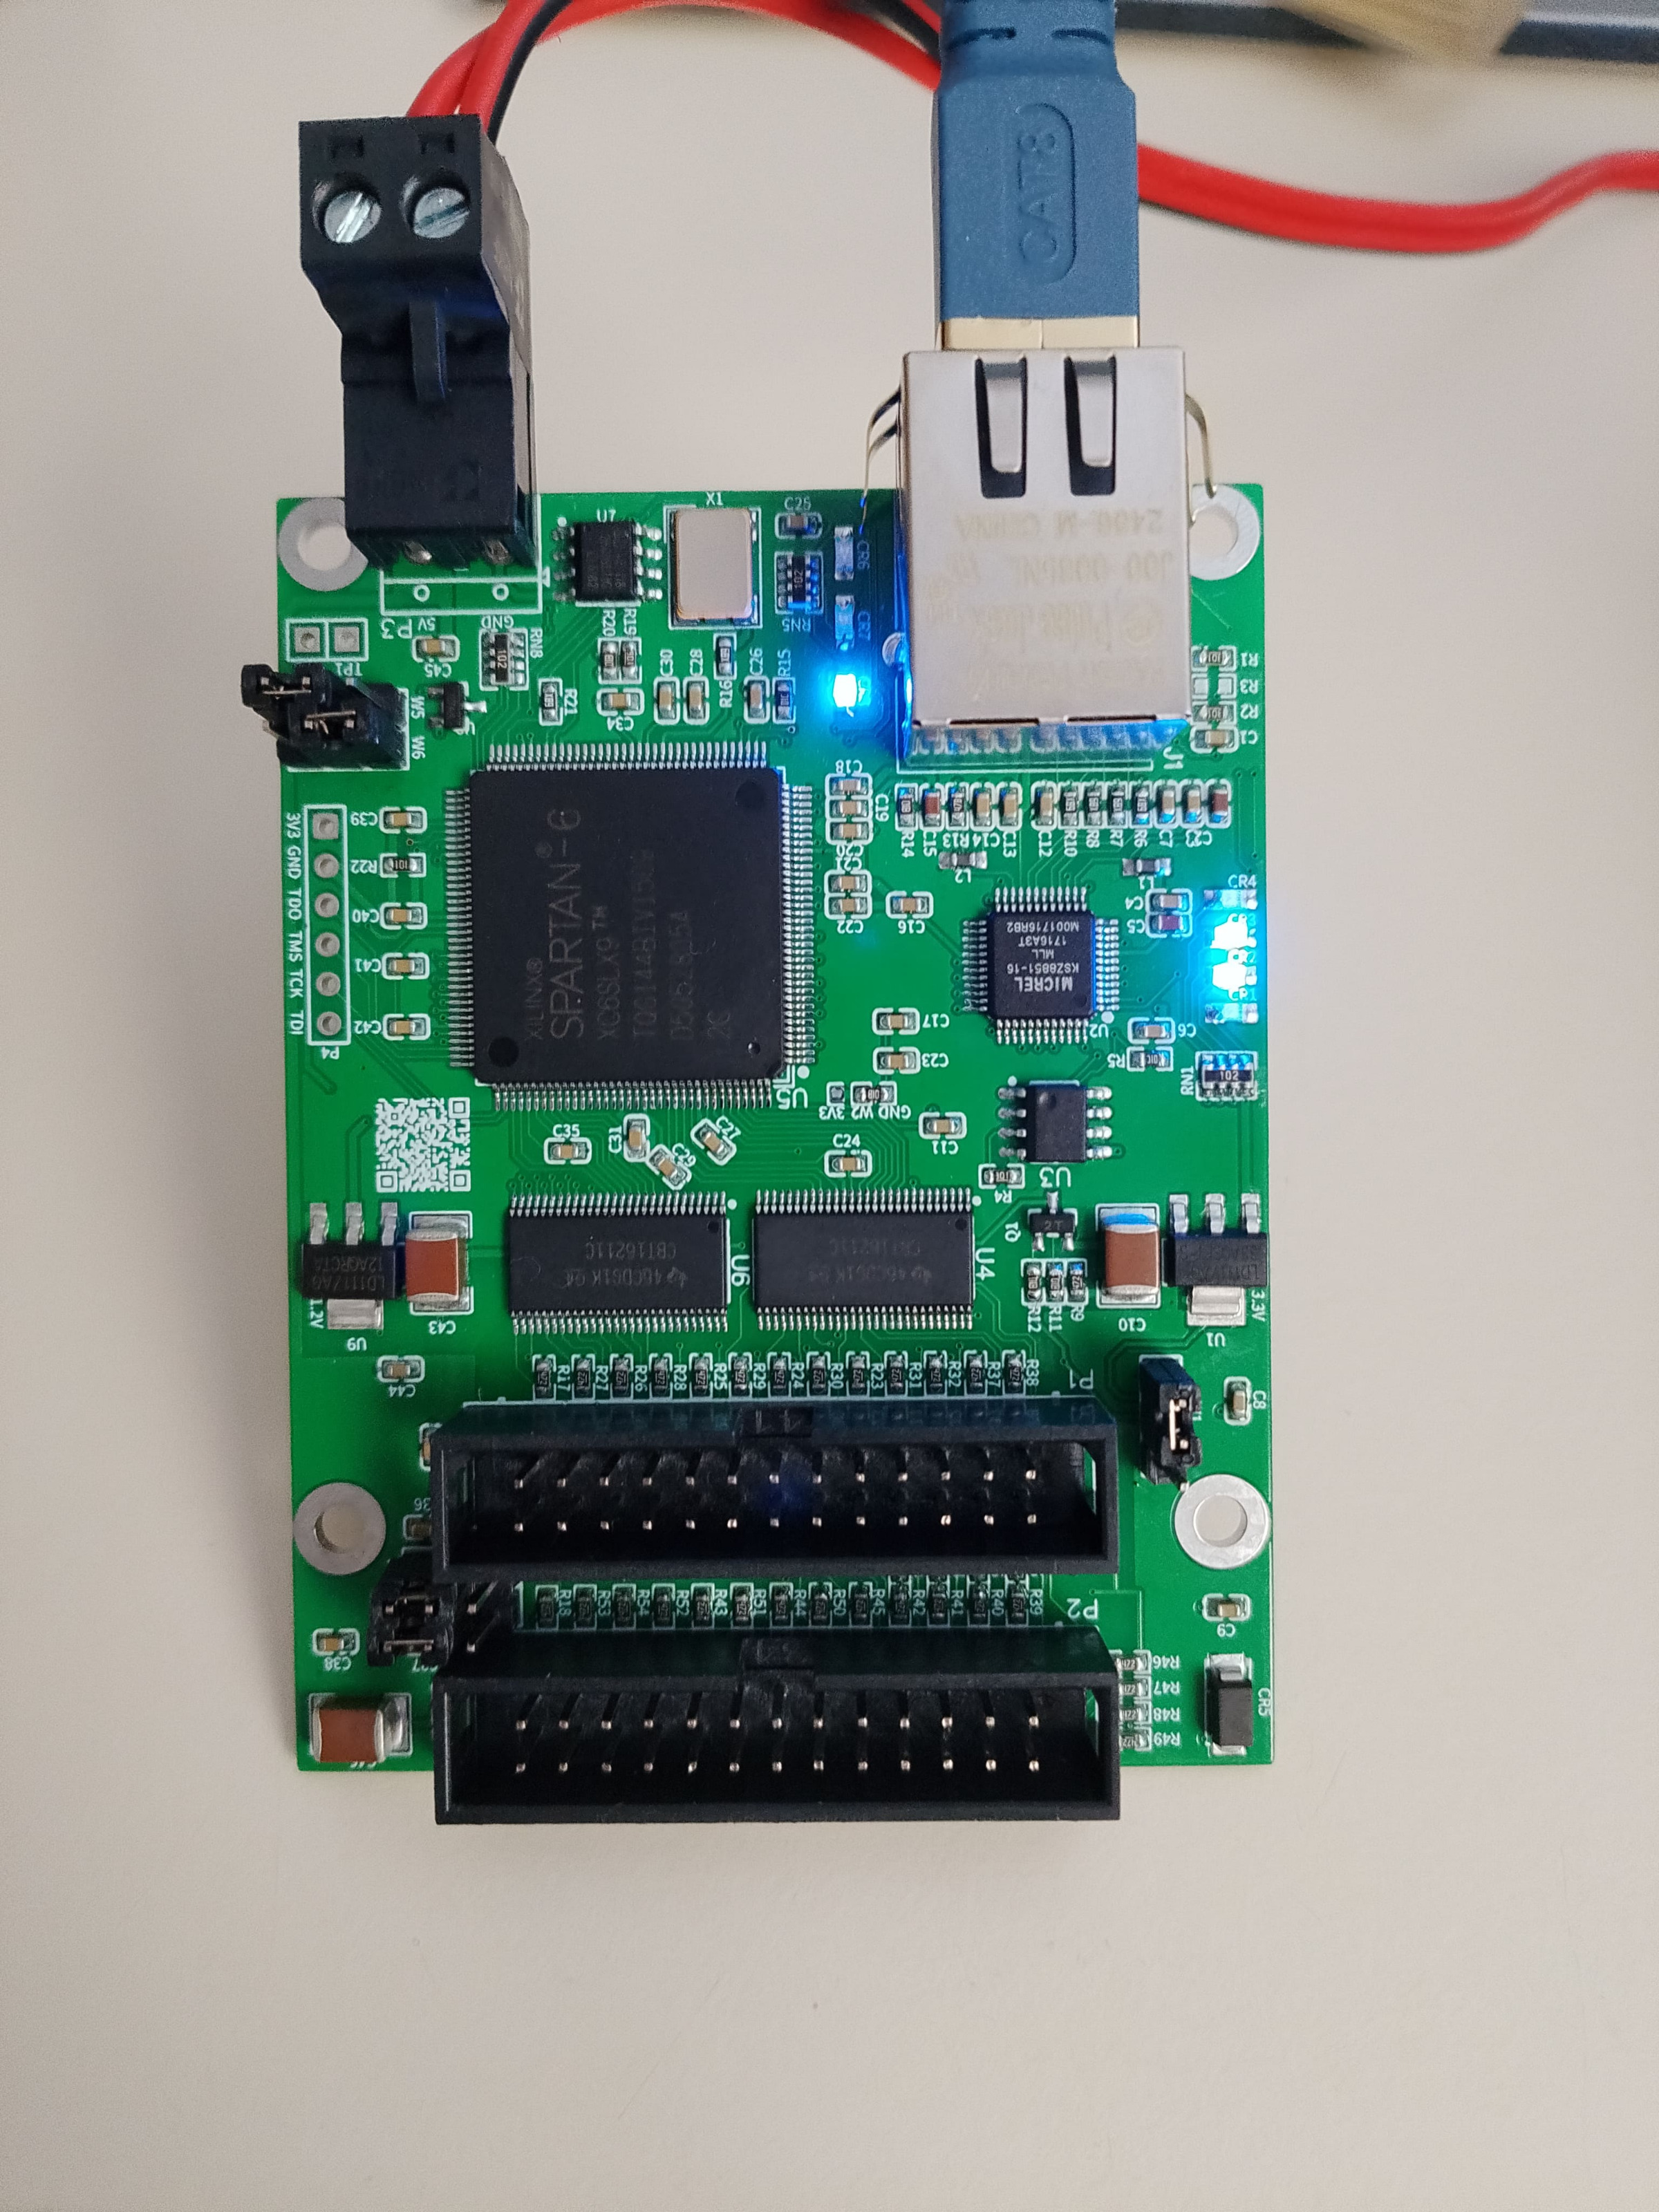
My SetupRaspberry Pi 5 8GBByte2Bot Parallel Port Raspberry Pi HatByte2Bot 5 Axis CNC Interface Adapter Parallel Breakout Board For Stepper Motor DriversPicture 1My wiring is as follows:Picture2
The motors move, the home switches register as functioning, the probe is not hooked up and the eStop appears to do nothing.From LinuxCNC V2.9.7 Documentation PDF Page 1854.9.3.7 External ESTOP button The standard_pinout.hal file assumes no external ESTOP button. For more information on an external E-Stop see the estop_latch man page.Yet from 2 pages earlier in LinuxCNC V2.9.7 Documentation PDF Page 183 I see this line in the HAL file:# create a signal for the estop loopbacknet estop-loop iocontrol.0.user-enable-out iocontrol.0.emc-enable-in I assume “man page” is a typo and this is unnecessary if I am trying to connect it to GPIO25. A search of the document looking for “estop_latch” only reveals this on page 254Picture 3So my estop is on pin10, but that is GPIO25 on the Pi 5. I must refer to it as such.In my .Hal file I have the following lines:loadrt hal_gpio inputs=GPIO7,GPIO8,GPIO25,GPIO12,GPIO13 outputs=GPIO5,GPIO6,GPIO11,GPIO9,GPIO10,GPIO23,GPIO16,GPIO17,GPIO19,GPIO20,GPIO21,GPIO22,GPIO24,GPIO26net estop-out <= hal_gpio.GPIO25-in ornet estop-ext <= hal_gpio.GPIO25-in Using tools I can identify that all my limit switches are being read, but I have nothing to suggest the estop is being read.I have added“Addf gpio-input servo-thread” as recommended by ChatGPT, and that is not read by the programThe advice I am looking for is:
I would like to know how to connect GPIO25 to LinuxCNC’s E-Stop chain.I have tried:
net estop-out hal_GPIO.GPIO25.out => iocontrol.0.emc-enable-inand any variation thereof I could think of, failed.Eventually, I lost control of my servos and only when I removed all lines I gained control of F1, which controls the estop and F2, which powers the servos.