
Search Results (Searched for: )

  • rodw
25 Mar 2026 10:01
Replied by rodw on topic Updating Old GladeVCP Files?
So long ago to remember but if you want to use gcode and gui buttons to do the same thing, I seem to remember you need to manage it in the python screen handler. Sorry I no longer have an example.
  • ts
25 Mar 2026 10:00
I have worked configuration for this, if it is actually question.
I connected aux encoder 1u resoluution to aux to drive. Connected it to hal by xml config, named linear-pos.
And change actual position to linear-pos. And its works.
About points to 1 rotation - i connected to drive, and calculate gear ratio, on my case it was 1.4 - you put electronic gear 1:1 and move 1 rotation of motor, and look at measurement "clocks" what is movement on mm. And calculate. Also coefficient in my case for linear aux was 7000 . There are manual from delta for calculation.
Also important point that i put in xml file in linuxcnc (lcec some.xml) electronic gear values, and every load of linuxcnc it download by ethercat .
  • alangibson
25 Mar 2026 09:58 - 26 Mar 2026 12:40
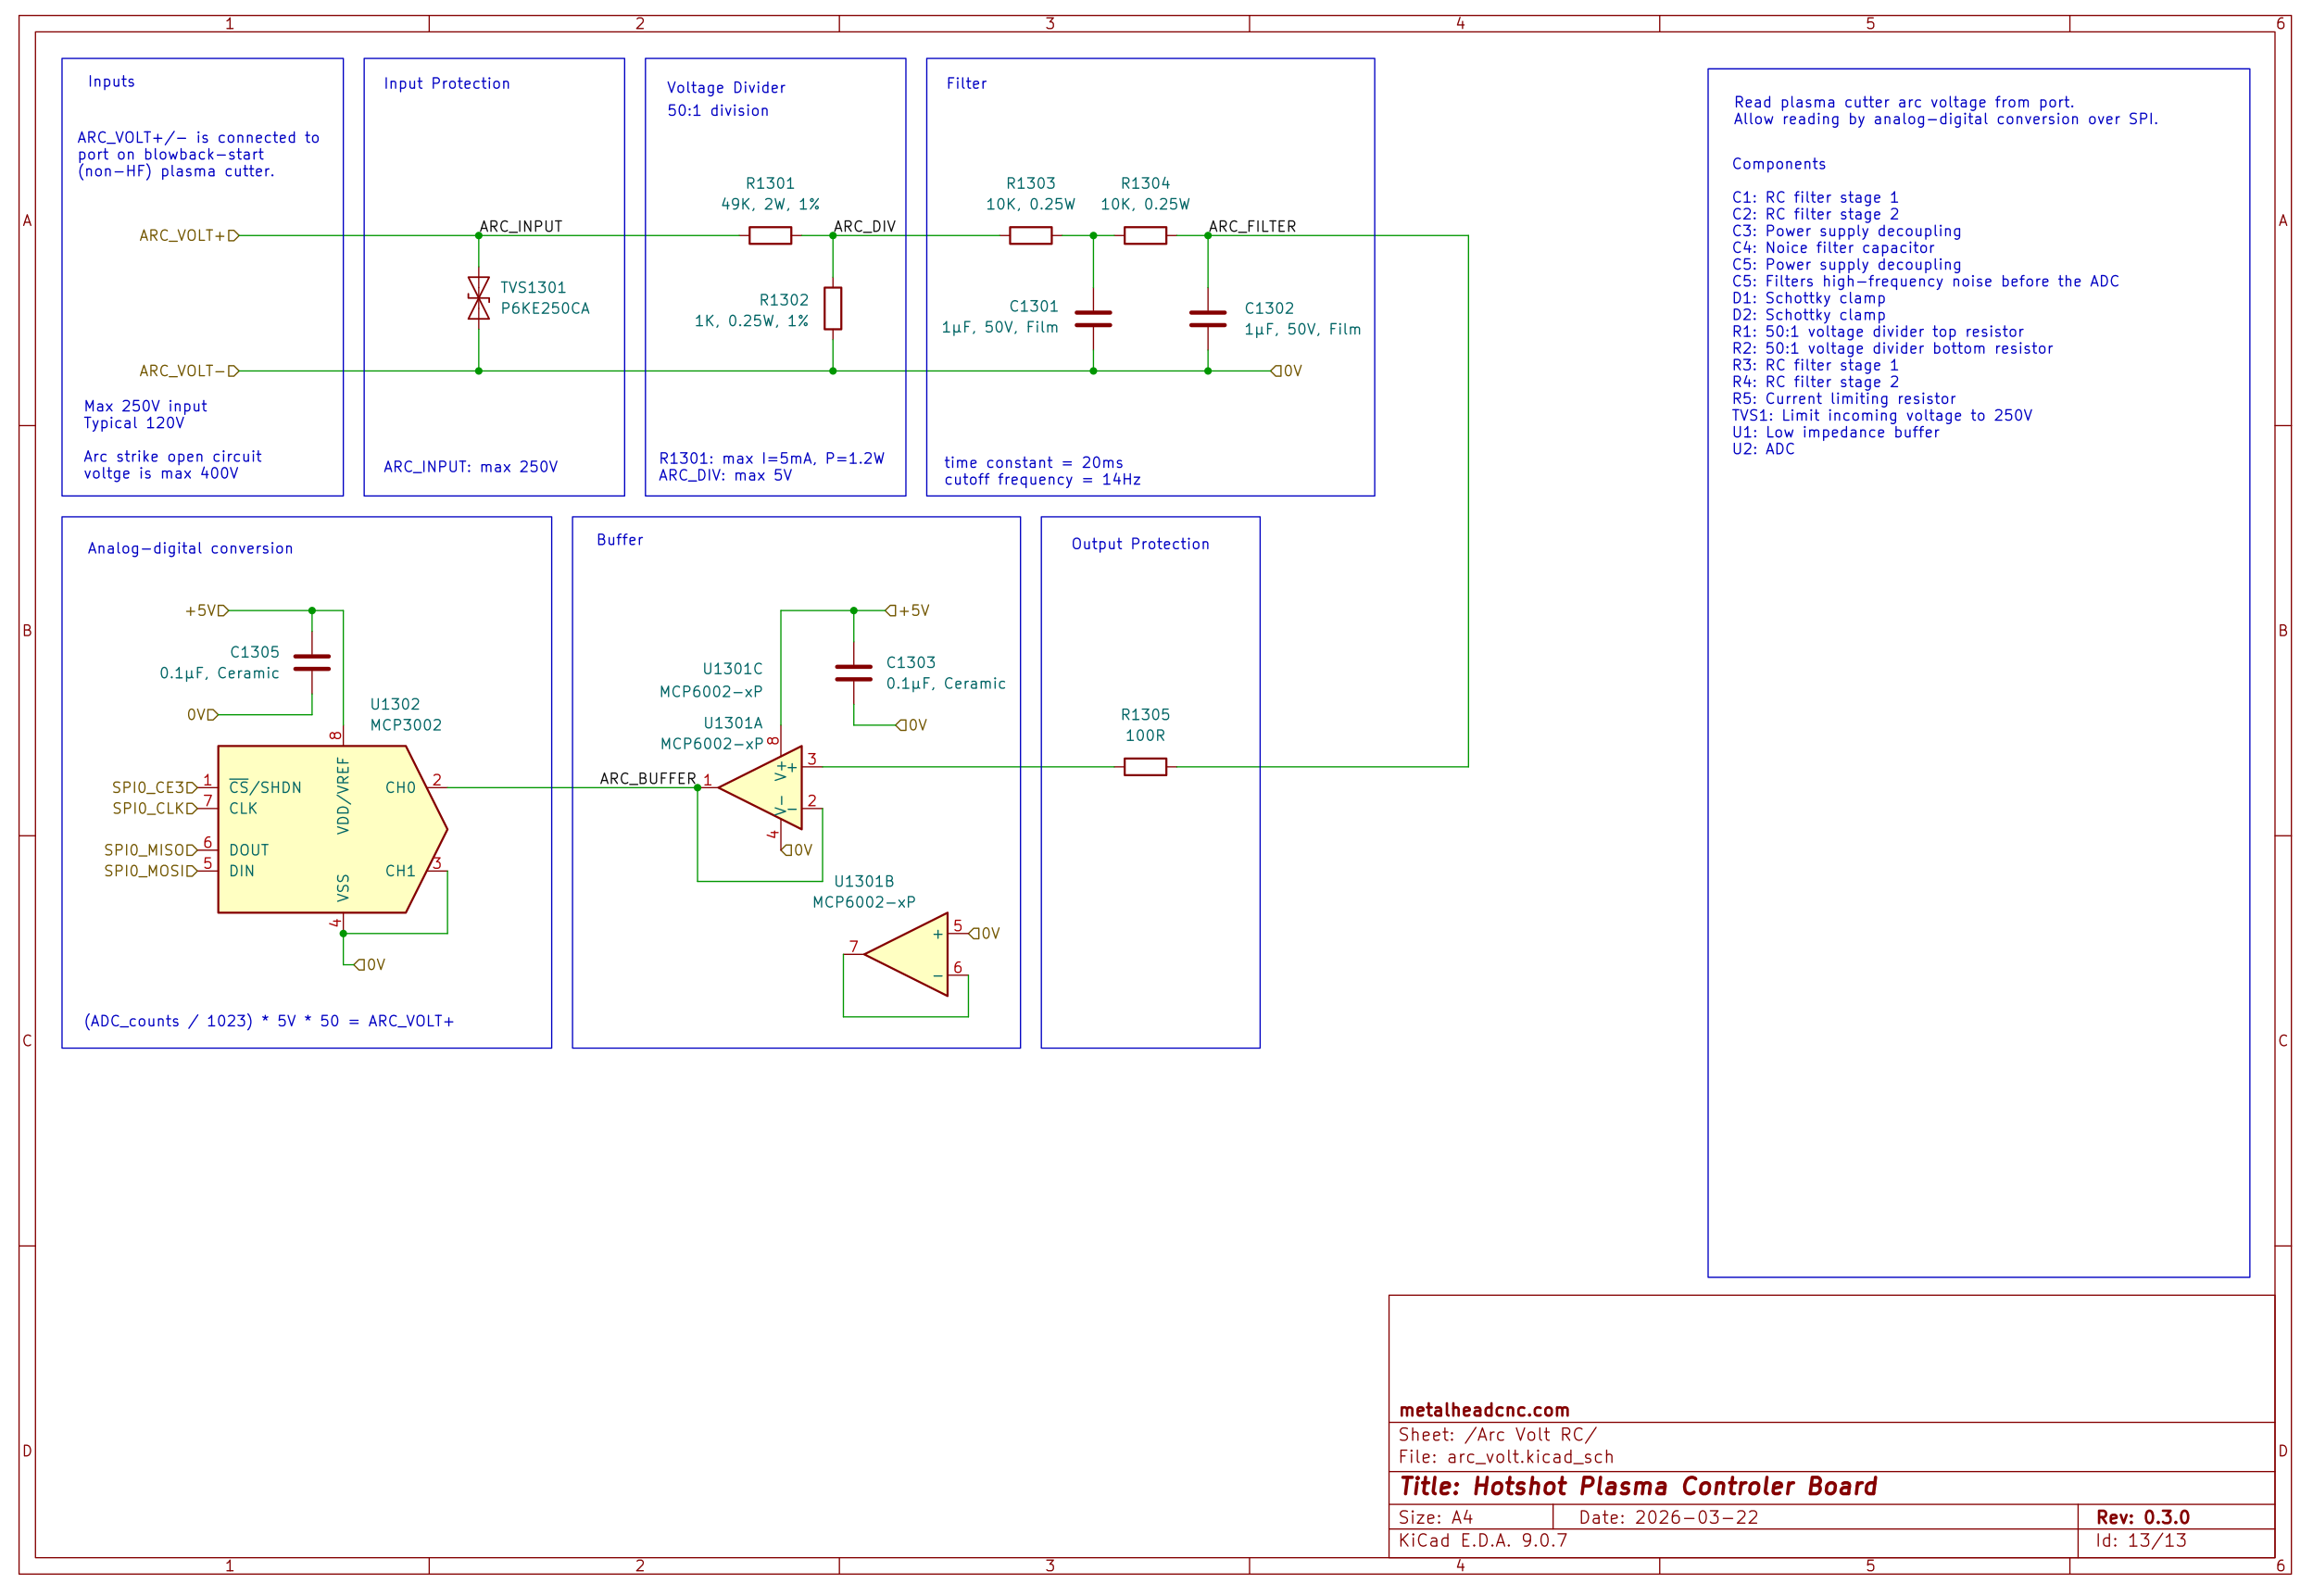
Hi all. I've been playing with a design for a board that will allow me to read arc voltage with a Raspberry Pi. I think I've got something that will plausibly work. I'd appreciate a review of the attached schematic because circuit design is not my core competency.

Here's a quick tour:
1. Inputs are expected to be connected to the arc volt port of a blowback-start plasma power supply. 
2. Input voltage is limited to 250V by a TVS diode
3. Voltage is divided 50:1
4. RCRC filter limits frequency to 14Hz
5. Raspberry Pi reads divided voltage via ADC

Thanks!
 
  • my1987toyota
25 Mar 2026 09:21
Replied by my1987toyota on topic FreeCAD 1.0 Who's using it?
FreeCAD 1.1 stable has been released. Get it now 
  • Plasmanfm
25 Mar 2026 09:07
I have a Lorch plama cutter that ignites with hf....

By me was it the monitor cable ...


MfG
Juergen
  • ts
25 Mar 2026 07:21
Jog troubles was created by ts
JT, hi. Its me again for today)

I have Cnc machine with axis - xyz and C. (C because it is rotated around Z axis).
when im powerup the machine and starting jogging it, i have to use axis C as axis for jog number 3 - jog_plus_pb_3. But after homing  that axis became axis number 5. And after homing i have to use jog_plus_pb_5.

It is strange, and i found only that i could block jogging button for C axis until homing is conpleted. Is there any more flex solutolions for this issue?)

Thanks in advance!
TS
  • ts
25 Mar 2026 07:15
Hi, JT!

i didnt understand how to add functionallity, to doplicate fleglxgui buttons like a PowerPB and Reset (included functions, and there are not in Hal components) to the external hard electrical contacf buttons (ext btn already in hal, but where the pin signals to connect it)?

Thanks in advace!
TS
  • bladekel
25 Mar 2026 07:01

I tried it as you said but nothing changed.
Again receving "USRMOT: ERROR: command timeout" errors and couldnt control the LEDs.


    "rpi5": "true",
->
    "rpi5": true,


Thats the trick, thank you.
Its working now... 
 
  • rock861261
25 Mar 2026 04:11
Replied by rock861261 on topic El5101 Config
Seems to all be working correctly open to any additional inputs
  • rock861261
25 Mar 2026 04:00
Replied by rock861261 on topic El5101 Config
loadusr -W lcec_conf ethercat-conf.xml
loadrt lcec

loadrt ddt names=spindle-v
loadrt mult2 names=rpm-calc
loadrt near names=spindle-at-speed
loadrt lowpass names=spindle-filter

addf rpm-calc servo-thread
addf spindle-at-speed servo-thread
addf spindle-v servo-thread
addf spindle-filter servo-thread

addf lcec.read-all servo-thread
addf lcec.write-all servo-thread

setp lcec.0.El5101.enc-pos-scale 2000

net spindle-pos-fb lcec.0.El5101.enc-pos => spindle-v.in => spindle.0.revs

setp rpm-calc.in1 60
net spindle-rps spindle-v.out => rpm-calc.in0
setp spindle-filter.gain 0.1

net spindle-rpm-raw rpm-calc.out => spindle-filter.in
net spindle-rpm-fb spindle-filter.out => spindle.0.speed-in

setp spindle-at-speed.scale 1.1
setp spindle-at-speed.difference 10

net spindle-vel-cmd spindle.0.speed-out => spindle-at-speed.in1
net spindle-rpm-fb => spindle-at-speed.in2

net spindle-at-speed-sig spindle-at-speed.out => spindle.0.at-speed

net spindle-index-enable lcec.0.El5101.enc-index-c-enable => spindle.0.index-enable

net spindle-rpm-fb => pyvcp.spindle-speed
  • grandixximo
25 Mar 2026 02:36
Replied by grandixximo on topic LinuxCNC S-Curve Accelerations
I will try to replicate, thank you!
  • Lcvette
25 Mar 2026 00:52
Replied by Lcvette on topic QTPYVCP+VISMACH+LINUXCNC ROLLED INTO ONE?
If you want to contribute to the pyside6 branch you can use the new Trixie installer in my GitHub, but this is for development use only, not for machine use yet.
  • Lcvette
25 Mar 2026 00:50
Replied by Lcvette on topic QTPYVCP+VISMACH+LINUXCNC ROLLED INTO ONE?
It's still work in progress, not ready for official release yet. Once it is it will be available for normal install with updated docs. The latest vtk edits are still in a testing branch and have not even been merged into the pyside6 branch.
  • Lcvette
25 Mar 2026 00:46
How about the SIM, does the SIM start and work as expected? If so it's almost certainly a config setting issue.

This sounds like maybe an estop conflict. Or perhaps a post gui hal file issue.
  • PCW
24 Mar 2026 22:06
Replied by PCW on topic What's the opposite of skipping steps?
Needs to be done with physical wiring
 
Displaying 5536 - 5550 out of 11898 results.
Time to create page: 0.275 seconds
Powered by Kunena Forum

