
- Posts: 959
- Thank you received: 489

Hi, Thanks for reporting the error in the EC500 configuration file. I had the NVEM and EC300 correct. The JSON key words need to be as expected by the code. Capitalisation.Hi Scott.
I have managed to upload the config file to the newly flashed EC500 board & am starting to play with it.
Looking at the hal show all (most) of the inputs seem to be inverted. Assuming this may just be a quirk I have gone into th econfig file & tried to invert some of the pins & this seem to have no effect.
{
"Thread": "Servo",
"Type": "Digital Pin",
"Comment": "IN01",
"Pin": "P3_25",
"Mode": "Input",
"Data Bit": 4,
"Invert": "true"
},
I believe the upload is working as I get no errors....
(2:01:52pm)> python3 upload_config.py ec500-rt1052.txt
Valid JSON config file, uploading to board
Config file length (words) = 1716
Config file length (bytes) = 6861
Remainder = 1
Padding added = [0, 0, 0]
Config file length with padding (bytes) = 6864
CRC-32 = 0xbf67a0b8
And if I go through & toggle the inputs the red light on the board comes on & the yellow light in hal show turns red (deactivates)
Two questions
Should they be high by default.
Why does changing false to true in the config file have no effect.
Thanks
Please Log in or Create an account to join the conversation.
For the STM32 version of the EC500, please refer to this repo.I would like to know the following, using the firmware for the "nvem" everything works perfectly, but I changed the processor, f207 to f407, I also changed the numbers of the timers " baseThread = new pruThread(TIM9, TIM1_BRK_TIM9_IRQn, base_freq);
//NVIC_SetVector(TIM1_BRK_TIM9_IRQn, (uint32_t)TIM9_IRQHandler);
NVIC_SetPriority(TIM1_BRK_TIM9_IRQn, 2);
servoThread = new pruThread(TIM10, TIM1_UP_TIM10_IRQn, servo_freq);
//NVIC_SetVector(TIM1_UP_TIM10_IRQn, (uint32_t)TIM10_IRQHandler);
NVIC_SetPriority(TIM1_UP_TIM10_IRQn, 3);
I did all the reconfiguration in the "timer.cpp" folder and also the clock reconfiguration, however the following is happening, when I use the firmware of the "nvem" itself with the reconfiguration, everything works perfectly, however when trying to do everything from scratch, that is create a new configuration, nothing works, do you need some version of " "Stm Cube IDE" to do that? I want to make a new configuration, that is to start so as not to use the firmware of the "nvem" itself, at the moment I am using this version "STM32CubeIDE
Version: 1.12.0.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

Brand new to LinuxCNC. Couldn't find any Mesa controller in stock and bumped into Scott's YouTube videos. Ordered an EC300, which arrived today. I didn't have any ST-Link but had a few RPI Pico boards so I gave it a try. Worked first time. Now I have a long and steep learning curve ahead on how to configure it allI really think I should take down the stuff relating to the DAPlink. It's causing more issues then it solved.
CMSIS-DAP has been the most successful but converting an ST-Link is a pain.
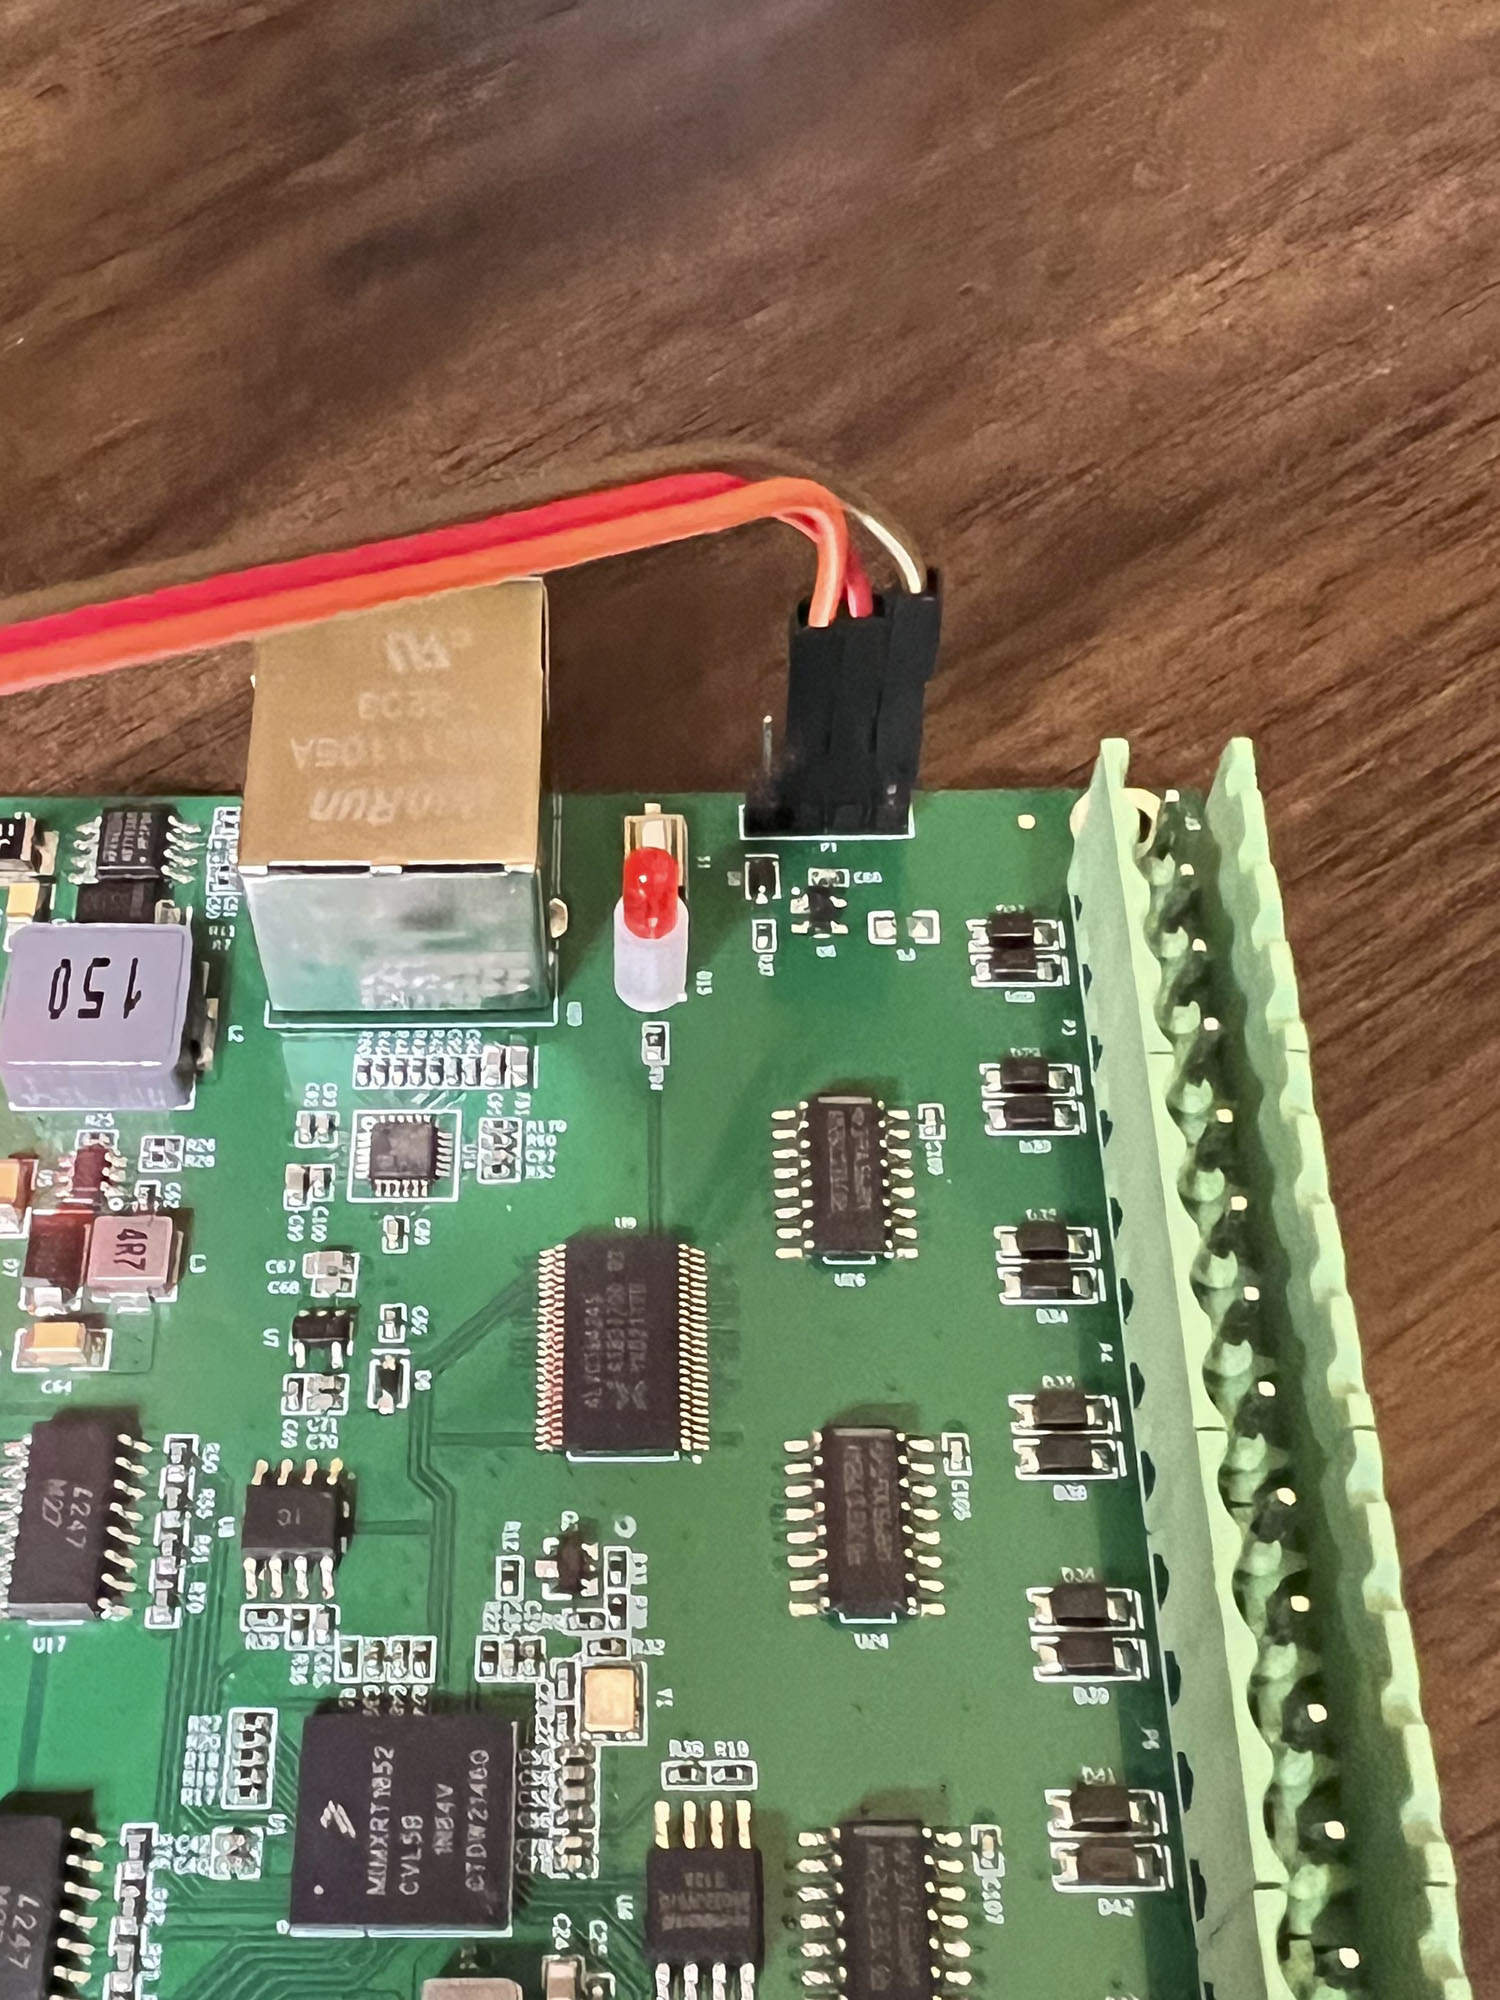
There is a solution, a PicoProbe! Just tested and works out of the box with pyOCD.
pyocd remora-rt1052-1.0.0.bin --target mimxrt1050_quadspi


Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

