- Hardware & Machines
- Computers and Hardware
- LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
- meister
- Offline
- Platinum Member
-

- Posts: 805
- Thank you received: 502
Please Log in or Create an account to join the conversation.
- viewsat
- Offline
- Junior Member
-

- Posts: 33
- Thank you received: 10
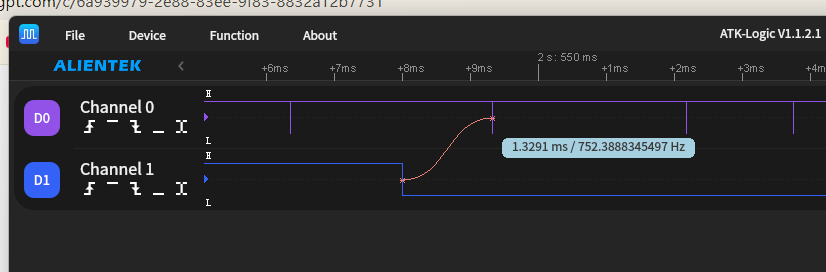
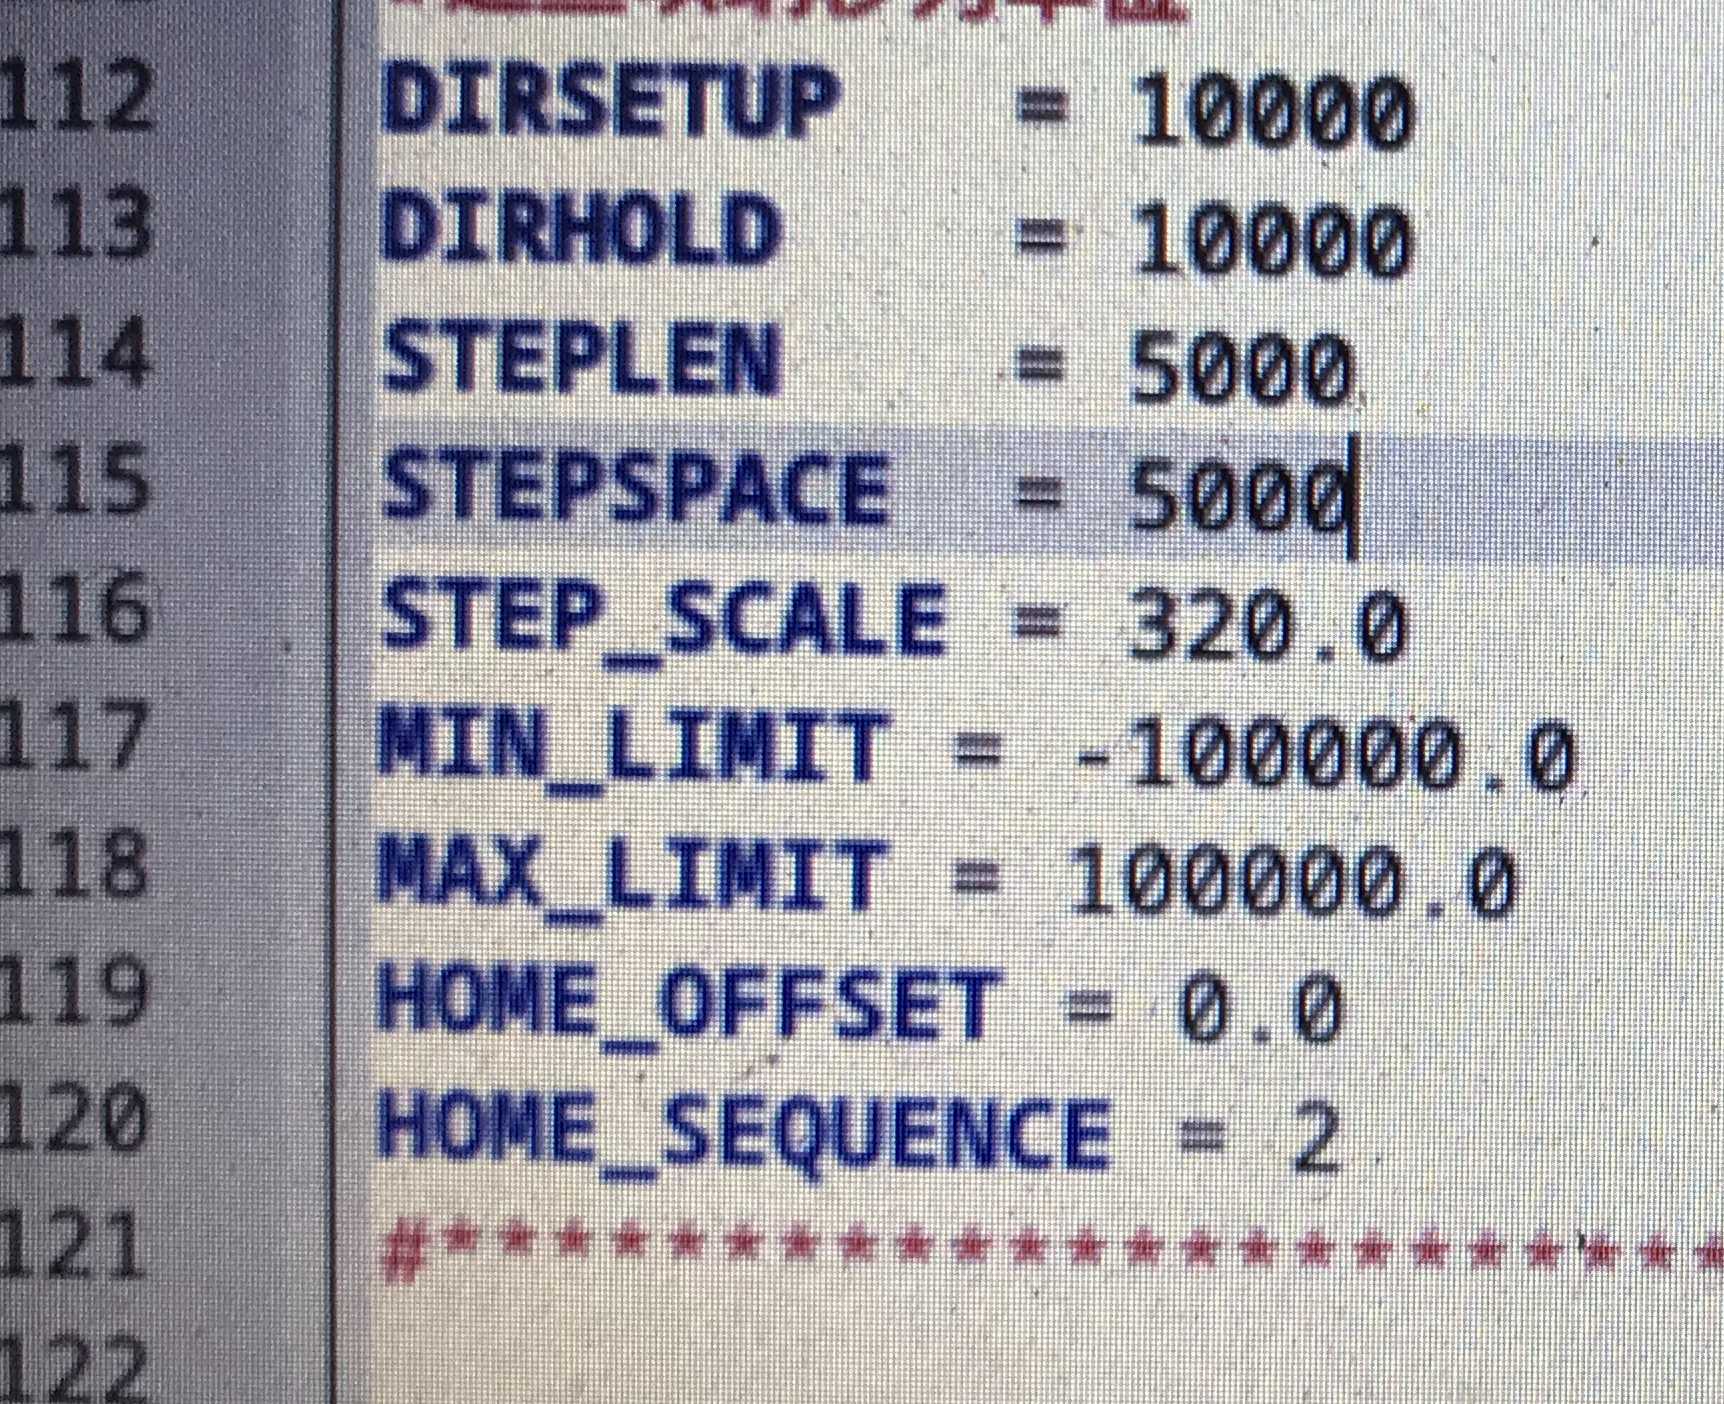
mesa7i92 step/dir
Attachments:
Please Log in or Create an account to join the conversation.
- PCW
-
- Offline
- Moderator
-

- Posts: 18104
- Thank you received: 5328
the actual direction change may be some distance from the step pulse time because
the actual step direction logic depends on the sign of the velocity command and at slow speeds
this velocity change may occur at a time determined by the _fractional_ position count. The hostmot2 stepgen
hardware position is a 16.16 bit number so has a resolution of 1/65536th of an external step.
The setup and hold timings set the minimum timings, but not the maximums.
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
- Posts: 805
- Thank you received: 502
and please set the Register address to 192.
Please Log in or Create an account to join the conversation.
- Oxbown
- Offline
- New Member
-

- Posts: 10
- Thank you received: 2
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
- Posts: 805
- Thank you received: 502
go to mbus plugin-config and set the new debug flag
hope that help's
Please Log in or Create an account to join the conversation.
- Oxbown
- Offline
- New Member
-
- Posts: 10
- Thank you received: 2
Seems that the mistake is in the LinuxCNC HAL config.
IN1
> MODBUS_TX(mbus0): 1 3 0 192 0 2 196 55
MODBUS_RXmbus0: 1 3 4 0 1 0 0 171 243
IN2
> MODBUS_TX(mbus0): 1 3 0 192 0 2 196 55
MODBUS_RXmbus0: 1 3 4 0 2 0 0 91 243
IN1 + IN2
>MODBUS_TX(mbus0): 1 3 0 192 0 2 196 55
MODBUS_RXmbus0: 1 3 4 0 3 0 0 10 51
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
- Posts: 805
- Thank you received: 502
01 03 00 192 00 02 196 55
01: The SlaveID
   03: The Function Code 3 (read Analog Output Holding Registers)
      00 192: start register
             00 02: number of bytes

01 03 04 00 02 00 00 91 243
01: The SlaveID
   03: The Function Code 3 (read Analog Output Holding Registers)
      04: The number of data bytes to follow
         00: The contents of register 192
            02: The contents of register 193
               00: The contents of register 194
                  00: The contents of register 195


please try to change the 16 'values' to 32
you need to pull dev to incrase the values, with my simulation it works, but it's a workaround,
i will write a fix, to read the values in the right order and ignore the last 16bit's
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
- Posts: 805
- Thank you received: 502

Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
- Posts: 805
- Thank you received: 502
please set back to 16 values, update dev and try again
Please Log in or Create an account to join the conversation.
- Hardware & Machines
- Computers and Hardware
- LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)