
- Posts: 295
- Thank you received: 125
Kinematics... again:/
- chimeno
- Offline
- Elite Member
-

Less
More
7 years 10 months ago #122719
by chimeno
Replied by chimeno on topic Kinematics... again:/
Hello Andy,
If I think I have an inverted joint as you say, I will try to reassemble everything again following the rule of the right hand.
hi Todd Zuercher,
If possible, I will look at it with more details if I have not followed the rule of the right hand well.
Hello Thang,
Well that was an easy solution to see how he behaved, I will look at what you have explained to me and I can apply it, I am not an expert on this topic but I am going to try it !.
thanks for everything guys, great guys!
Chimeno
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
7 years 9 months ago - 7 years 9 months ago #123426
by chimeno
Replied by chimeno on topic Kinematics... again:/
Hi guys,
I attach a new model according to the rule of the right hand, there are still some problems that comes from the cinematic model, I will try if I can make some changes,
thanks Chimeno
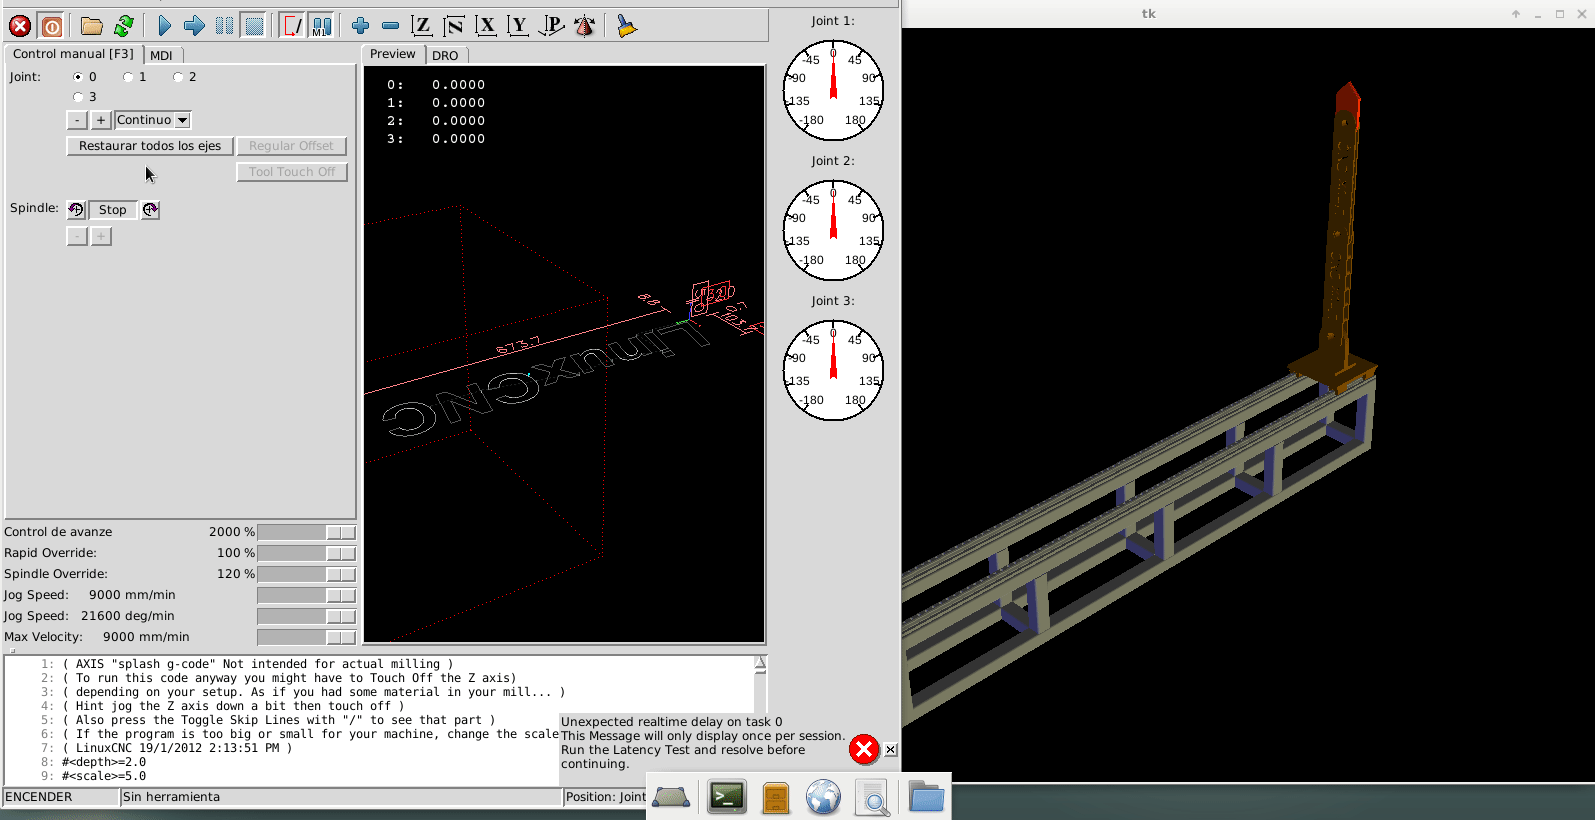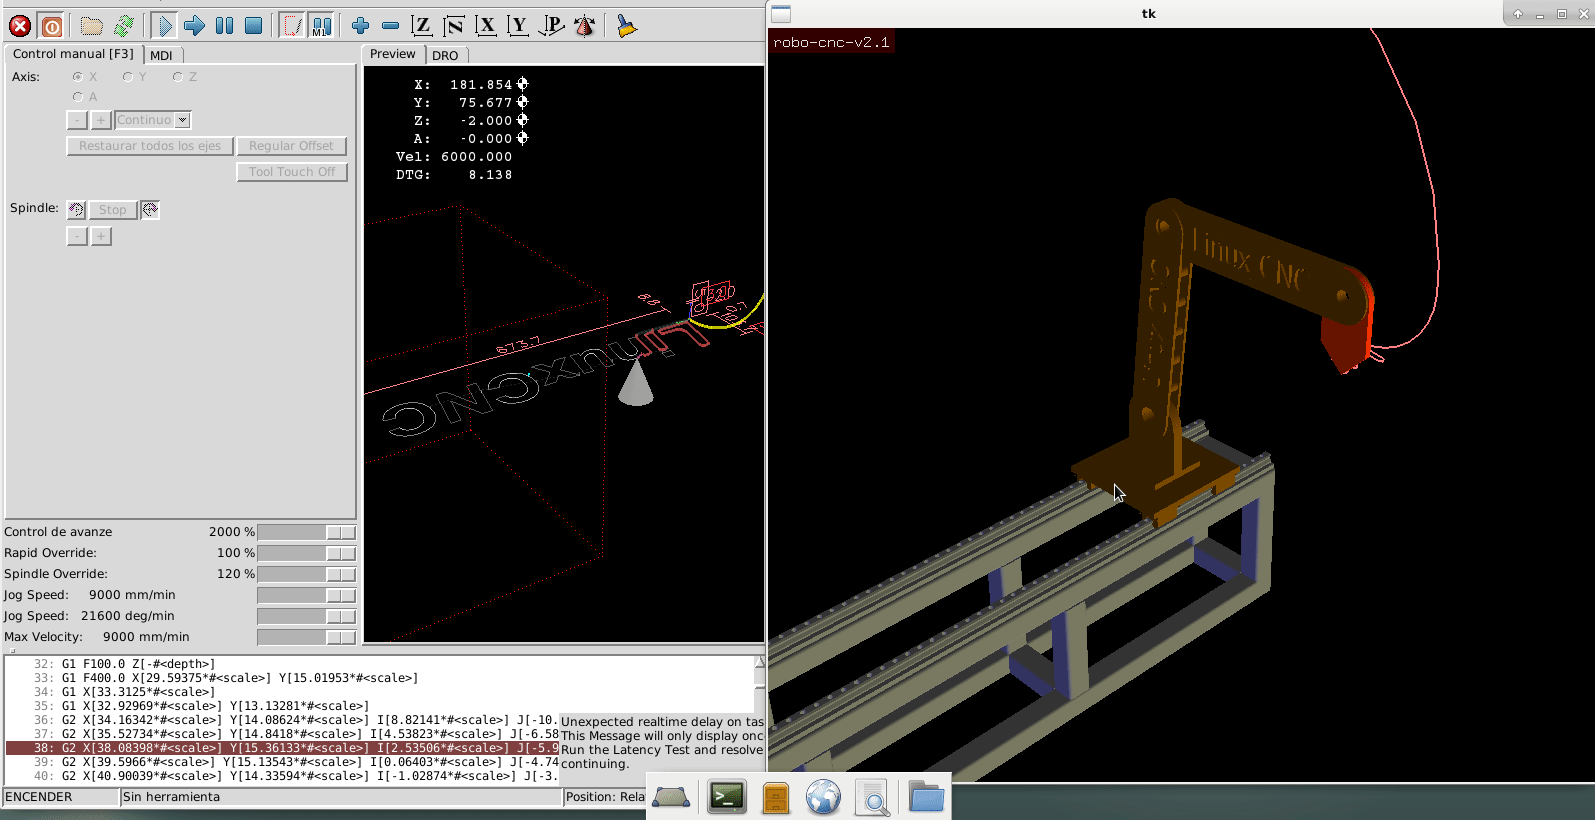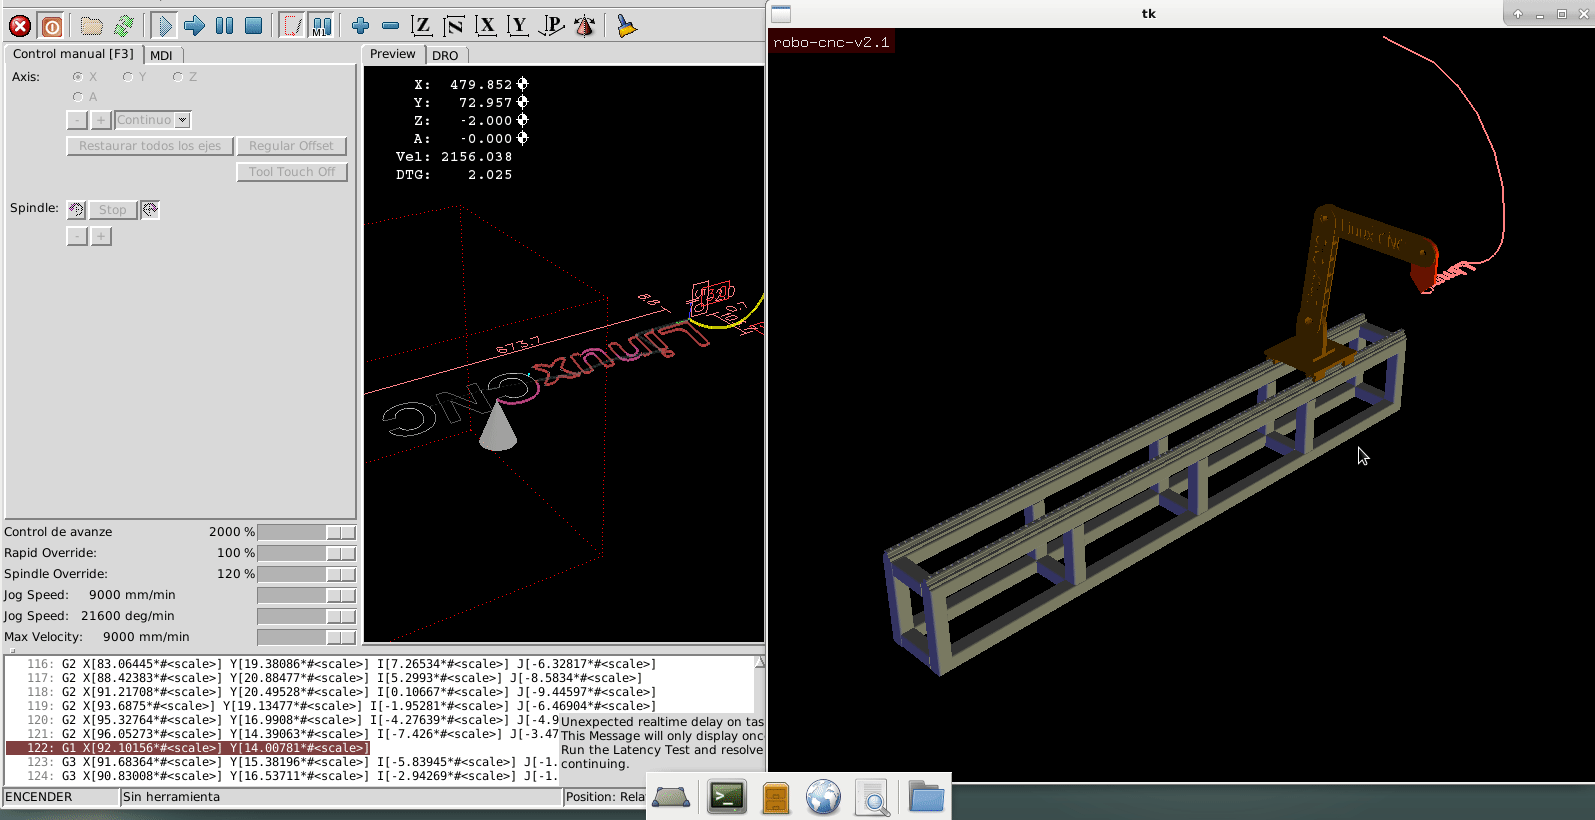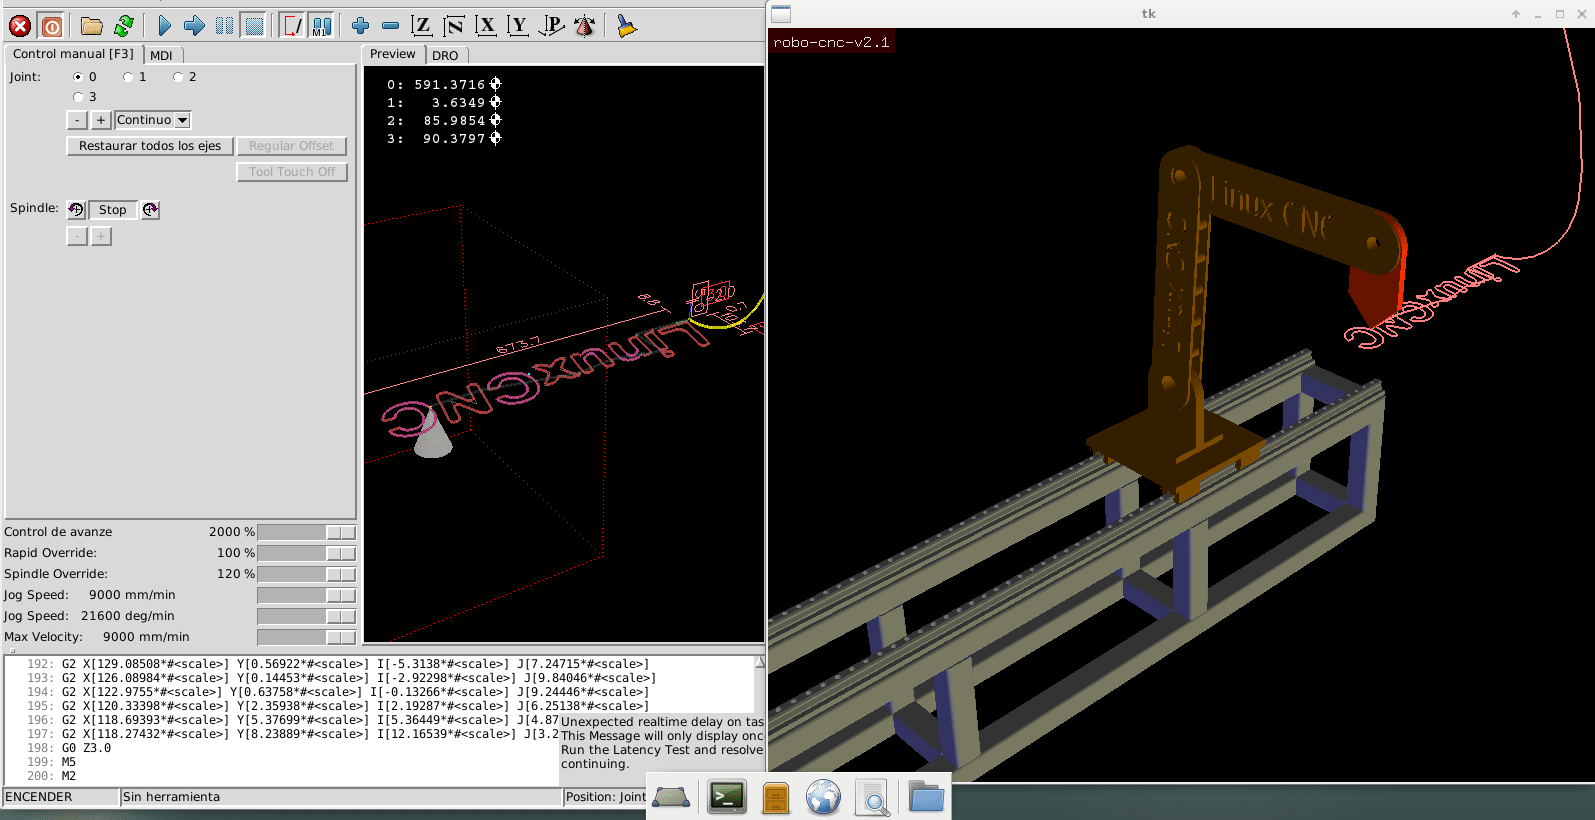
I attach a new model according to the rule of the right hand, there are still some problems that comes from the cinematic model, I will try if I can make some changes,
thanks Chimeno
Last edit: 7 years 9 months ago by chimeno.
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
7 years 9 months ago #123502
by chimeno
Replied by chimeno on topic Kinematics... again:/
If you set this, your robot can only use 1 config.
In your inverse kinematic, you used q1 = acos(cc), exactly there is one more solution that q1 = - acos(cc) ( most of time i use atan2 to caculate inverse kinematic). So we need to know which solution we should use, there is a method that is detect current config ( pumakins is using this).
So in your forward kinematic, we can find current robot config by something like:
cc = (rsq - D1*D1 - D2*D2) / (2*D1*D2);
p1 = acos(cc);
if ( abs(p1 - joint[1]) < 0.0000001)
*ifflag = 1;
In inverse kinematic :
if (!*iflags)
q1 = - q1;
Hi Thang,
I attach the modified file with your instructions, at the end it has the same elbow effect above, thanks
Chimeno
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
7 years 9 months ago #123503
by chimeno
Hello Andy,
the modified genserkins file that you posted here that contains linial boards, works, or is it simulated? Do you need important modifications to make it work?
Thank you
Chimeno
Replied by chimeno on topic Kinematics... again:/
andypugh wrote: Here is a discussion about the kinematics of the actual machine in your first post:
sourceforge.net/p/emc/mailman/emc-users/...ail.com/#msg26845536
Missing from that conversation are several off-list messages that Viesturs and I exchanged. He did get quite a long way down the line of making a version of genserkins that handles sliding joints, I have attached the modified genserkins.c and gensekins.h files that we came up with, but be aware that they don't necessarily work
In the end Viesturs used a modified version of scarakins, called robotkins.c for that welding robot, I have also attached that.

Hello Andy,
the modified genserkins file that you posted here that contains linial boards, works, or is it simulated? Do you need important modifications to make it work?
Thank you
Chimeno
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-

Less
More
- Posts: 19899
- Thank you received: 4655
7 years 9 months ago #123504
by andypugh
The kinematics file would be identical between a real and a simulated config, so I don't understand the question.
Replied by andypugh on topic Kinematics... again:/
chimeno wrote: the modified genserkins file that you posted here that contains linial boards, works, or is it simulated?
The kinematics file would be identical between a real and a simulated config, so I don't understand the question.
Please Log in or Create an account to join the conversation.
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
7 years 9 months ago - 7 years 9 months ago #123511
by chimeno
Hello Andy, I'm sorry if I did not explain myself well, I say if modified genserkin is tested and it works?
regards
Chimeno
Replied by chimeno on topic Kinematics... again:/
andypugh wrote:
chimeno wrote: the modified genserkins file that you posted here that contains linial boards, works, or is it simulated?
The kinematics file would be identical between a real and a simulated config, so I don't understand the question.
Hello Andy, I'm sorry if I did not explain myself well, I say if modified genserkin is tested and it works?
regards
Chimeno
Last edit: 7 years 9 months ago by chimeno.
Please Log in or Create an account to join the conversation.
Time to create page: 0.689 seconds