
- Posts: 2
- Thank you received: 0
Ethercat HAL driver
- Piotr
- Offline
- New Member
-

Less
More
8 years 10 months ago #102707
by Piotr
Replied by Piotr on topic Ethercat HAL driver
Hello.
Sorry my english is not perfect.
I have problem with start examples swm-fm45.
I have servo Stober MDS5040/L
I changed ethercat-conf.xml
When I run the program it gets an error
What am I doing wrong?
In the attachment there is the whole log
Thanks in advance
Sorry my english is not perfect.
I have problem with start examples swm-fm45.
I have servo Stober MDS5040/L
I changed ethercat-conf.xml
Code:
<masters>
<master idx="0" appTimePeriod="1000000" refClockCycles="1000">
<slave idx="1" type="StMDSk" name="SAT-EC-XML-EtherCAT_FastRefValue">
<dcConf assignActive="300" sync0Cycle="*1" sync0Shift="-2500"/>
</slave>
</master>
</masters>
Code:
Print file information:
RUN_IN_PLACE=no
LINUXCNC_DIR=
LINUXCNC_BIN_DIR=/usr/bin
LINUXCNC_TCL_DIR=/usr/lib/tcltk/linuxcnc
LINUXCNC_SCRIPT_DIR=
LINUXCNC_RTLIB_DIR=/usr/realtime-3.4-9-rtai-686-pae/modules/linuxcnc
LINUXCNC_CONFIG_DIR=
LINUXCNC_LANG_DIR=/usr/share/linuxcnc/tcl/msgs
INIVAR=inivar
HALCMD=halcmd
LINUXCNC_EMCSH=/usr/bin/wish8.5
LINUXCNC - 2.7.0
Machine configuration directory is '/home/cezary2528/linuxcnc/configs/swm-fm45a'
Machine configuration file is 'swm-fm45a.ini'
INIFILE=/home/cezary2528/linuxcnc/configs/swm-fm45a/swm-fm45a.ini
PARAMETER_FILE=linuxcnc.var
TASK=milltask
HALUI=
DISPLAY=axis
Starting LinuxCNC...
Starting LinuxCNC server program: linuxcncsvr
Loading Real Time OS, RTAPI, and HAL_LIB modules
Starting LinuxCNC IO program: io
Found file(REL): ./swm-fm45a.hal
Shutting down and cleaning up LinuxCNC...
Killing task linuxcncsvr, PID=5688
Removing HAL_LIB, RTAPI, and Real Time OS modules
Removing NML shared memory segments
Debug file information:
.
Error: could not insert module /usr/realtime-3.4-9-rtai-686-pae/modules/linuxcnc/lcec.ko: Invalid parameters
./swm-fm45a.hal:22: exit value: 1
./swm-fm45a.hal:22: insmod for lcec failed, returned -1
See the output of 'dmesg' for more information.
5688
PID TTY STAT TIME COMMAND
Stopping realtime threads
Unloading hal components
What am I doing wrong?
In the attachment there is the whole log
Thanks in advance
- sirop
- Offline
- Elite Member
-

Less
More
- Posts: 193
- Thank you received: 57
8 years 10 months ago - 8 years 10 months ago #102709
by sirop
Replied by sirop on topic Ethercat HAL driver
First of all check the correct type spelling:
github.com/sittner/linuxcnc-ethercat/blo...src/lcec_conf.c#L147
Then if
github.com/sittner/linuxcnc-ethercat/blo...src/lcec_conf.c#L147
Then if
from your kernel log is no false positive, try to investigate this.[ 987.272595] LCEC: slave 0.SAT-EC-XML-EtherCAT_FastRefValue: Failed to execute SDO request (0x2212:0x00)
Last edit: 8 years 10 months ago by sirop.
- Piotr
- Offline
- New Member
-
Less
More
- Posts: 2
- Thank you received: 0
8 years 10 months ago #102729
by Piotr
Replied by Piotr on topic Ethercat HAL driver
Typo appeared when rewriting the code on the forum.
Parameter 0X2212 should be equal to 0?
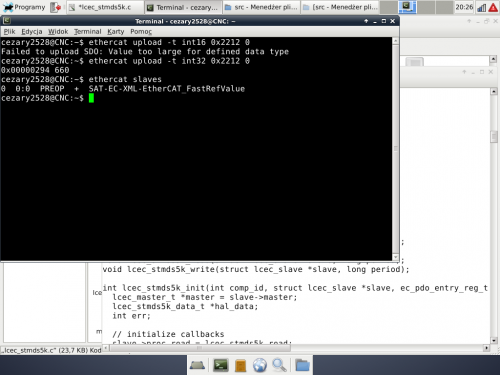
Currently, the servo motor is not connected to the inverter, can it be a problem?
Parameter 0X2212 should be equal to 0?
Currently, the servo motor is not connected to the inverter, can it be a problem?
- sirop
- Offline
- Elite Member
-
Less
More
- Posts: 193
- Thank you received: 57
8 years 10 months ago #102733
by sirop
Your error message originates from github.com/sittner/linuxcnc-ethercat/blo..._stmds5k.c#L120-L121 .
I do not have the manual of your slave , so can not say much about the SDO request.
If, however, it just takes too much time -- although being successful -- then it may be worth to increase LCEC_SDO_REQ_TIMEOUT
in github.com/sittner/linuxcnc-ethercat/blo...rc/lcec_main.c#L1140 .
Do not know if the servo motor not connected to the inverter can be a problem .
Replied by sirop on topic Ethercat HAL driver
Piotr wrote: Typo appeared when rewriting the code on the forum.
Parameter 0X2212 should be equal to 0?
Currently, the servo motor is not connected to the inverter, can it be a problem?
Your error message originates from github.com/sittner/linuxcnc-ethercat/blo..._stmds5k.c#L120-L121 .
I do not have the manual of your slave , so can not say much about the SDO request.
If, however, it just takes too much time -- although being successful -- then it may be worth to increase LCEC_SDO_REQ_TIMEOUT
in github.com/sittner/linuxcnc-ethercat/blo...rc/lcec_main.c#L1140 .
Do not know if the servo motor not connected to the inverter can be a problem .
- chimeno
- Offline
- Elite Member
-
Less
More
- Posts: 295
- Thank you received: 125
8 years 9 months ago - 8 years 9 months ago #104859
by chimeno
Replied by chimeno on topic Ethercat HAL driver
Hello everyone,
I'm trying to run el3773 with linuxcnc-ethercat and I can not get to OP in DC-mode, I think it's synchronization configuration problem but I do not see the one, can someone help me?
Thank you
Chimeno
I'm trying to run el3773 with linuxcnc-ethercat and I can not get to OP in DC-mode, I think it's synchronization configuration problem but I do not see the one, can someone help me?
Thank you
Chimeno
Last edit: 8 years 9 months ago by chimeno.
- sirop
- Offline
- Elite Member
-
Less
More
- Posts: 193
- Thank you received: 57
8 years 9 months ago #104863
by sirop
Replied by sirop on topic Ethercat HAL driver
Compare with
github.com/sittner/linuxcnc-ethercat/blo...thercat-conf.xml#L13
and then try
730 is actually a hex number but without preceding 0x, as I remember vaguely,
sync0Cycle="*1" means the EtherCat cycle is LinuxCNC cycle*1.
To determine what sync0Shift could be, you should read some EtherCAT docs.
and then try
Code:
<slave idx="1" type="EL3773" name="EL3773">
<dcConf assignActivate="730" sync0Cycle="*1" sync0Shift="25000" />
</slave>
sync0Cycle="*1" means the EtherCat cycle is LinuxCNC cycle*1.
To determine what sync0Shift could be, you should read some EtherCAT docs.
The following user(s) said Thank You: chimeno, Nico2017
Time to create page: 2.611 seconds