
- Posts: 295
- Thank you received: 125
Ethercat HAL driver
- chimeno
- Offline
- Elite Member
-

Less
More
6 years 4 months ago #170112
by chimeno
Replied by chimeno on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hi @theshade,
First I show you the DC tab where you have 2000us

now you have to go to the MOTION tab where we have the first TASK to 2000us

now we change it to 1000us
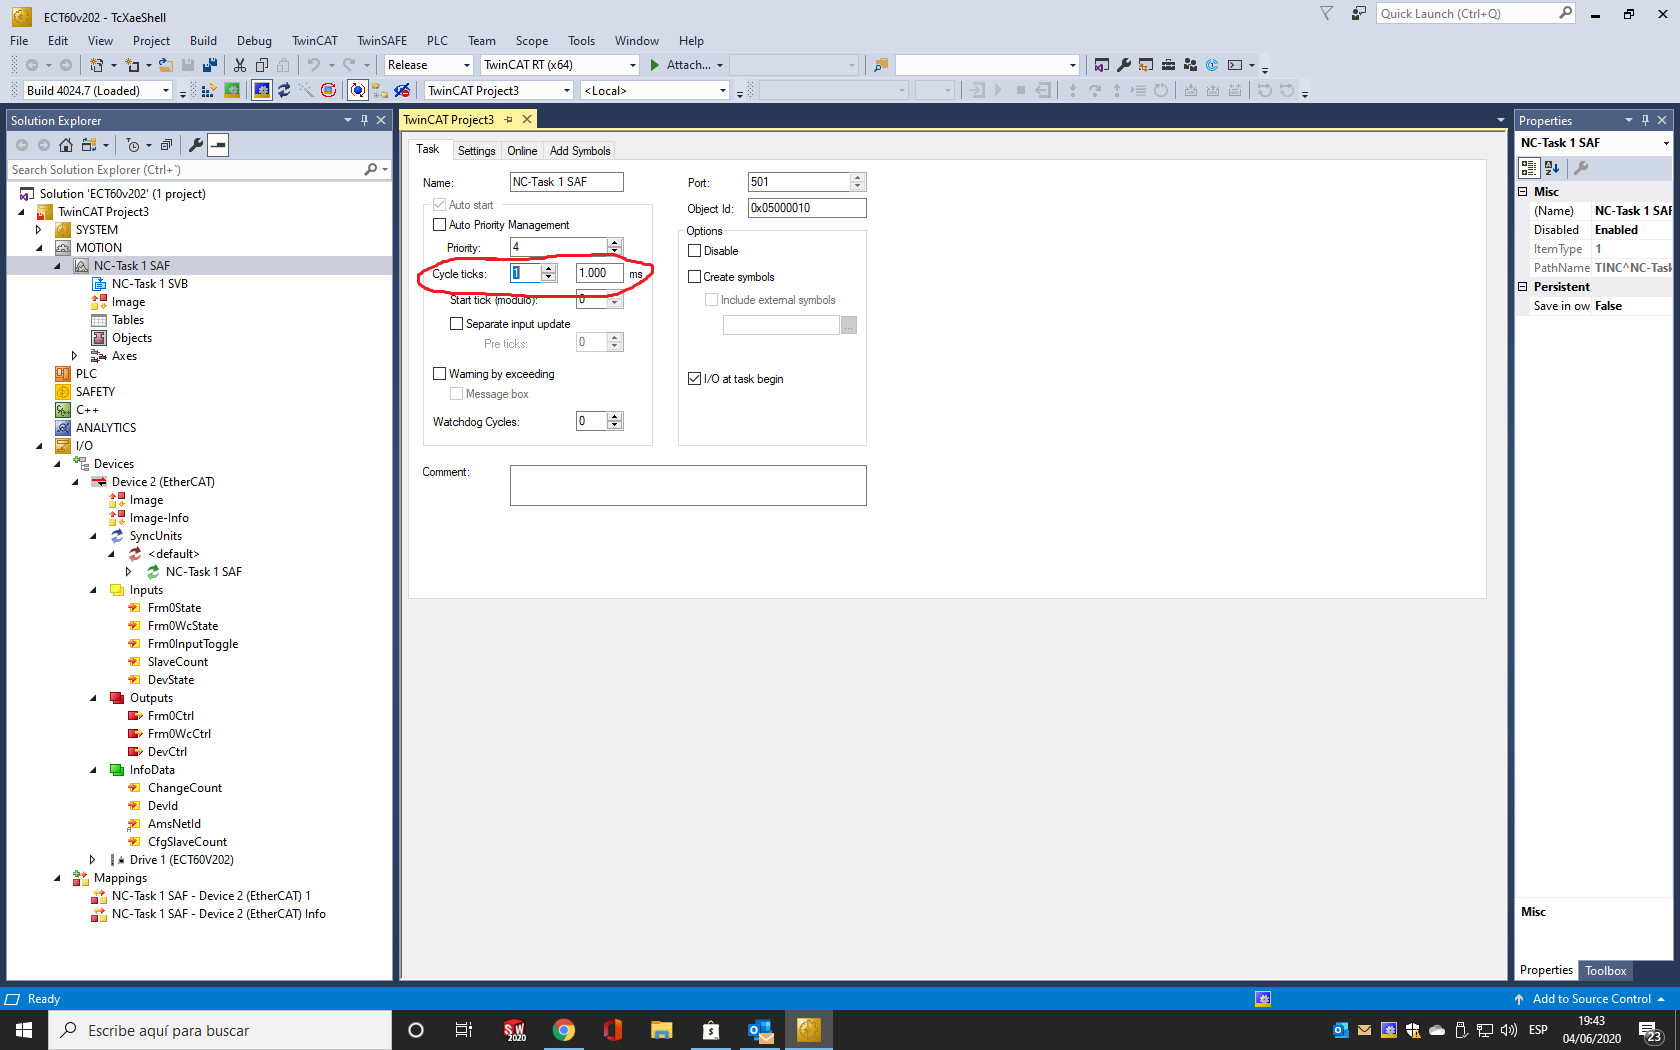
Now we go back to the DC tab of your device and automatically we have the value 1000us, now you just have to change the value of the SYNC0 in this case we multiply it x1 and reconfigure

You can also change the value and the different SYNC modes directly on the device, in the COE tab I cannot tell you where because I do not have the device and it does not allow me to see all the records although it is surely in 1C32 and 1C33, you also have to think that whenever the device is configured in linux, you usually have to do it before the device goes into OP mode and only send and receive data through PDOs.
I feel that I cannot be of more help,
Reguard
Chimeno
Here I explain how to change it through images that is much more intuitiveI tried the new dcConf you suggested but it doesn't seem to work
also when I try to edit the sync unit cycle to 2000us, but the field in the window would not let me change the value.
I suppose I would need to change it in the SDO somehow and save the value in the firmware of the driver?
First I show you the DC tab where you have 2000us
now you have to go to the MOTION tab where we have the first TASK to 2000us
now we change it to 1000us
Now we go back to the DC tab of your device and automatically we have the value 1000us, now you just have to change the value of the SYNC0 in this case we multiply it x1 and reconfigure
You can also change the value and the different SYNC modes directly on the device, in the COE tab I cannot tell you where because I do not have the device and it does not allow me to see all the records although it is surely in 1C32 and 1C33, you also have to think that whenever the device is configured in linux, you usually have to do it before the device goes into OP mode and only send and receive data through PDOs.
I feel that I cannot be of more help,
Reguard
Chimeno
- theshade
- Offline
- Junior Member
-

Less
More
- Posts: 29
- Thank you received: 5
6 years 4 months ago - 6 years 4 months ago #170123
by theshade
Replied by theshade on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Dear Chimeno,
Thank you so much...
I was able to change to 1ms and it works nice in twincat...
Also in twincat I have to enable controller+ feed FW + feed BW to make the motor move.
there is no such thing in linuxcnc?

I don't think there is more you can do indeed whithout a driver and hardware
And I don't really know how to thank you for all that... If you would ever come to Switzerland, I would be happy to offer you a good restaurant. Alternatively, if you need or would like something from here that I could ship, please let me know.
And of course, if I ever manage to make it work, I'll make sure to document the thing fully so newcomer (like me) with similar hardware can benefit of all this somehow.
Thank you so much...
I was able to change to 1ms and it works nice in twincat...
Also in twincat I have to enable controller+ feed FW + feed BW to make the motor move.
there is no such thing in linuxcnc?
I don't think there is more you can do indeed whithout a driver and hardware
And I don't really know how to thank you for all that... If you would ever come to Switzerland, I would be happy to offer you a good restaurant. Alternatively, if you need or would like something from here that I could ship, please let me know.
And of course, if I ever manage to make it work, I'll make sure to document the thing fully so newcomer (like me) with similar hardware can benefit of all this somehow.
Last edit: 6 years 4 months ago by theshade.
The following user(s) said Thank You: chimeno
- theshade
- Offline
- Junior Member
-
Less
More
- Posts: 29
- Thank you received: 5
6 years 4 months ago - 6 years 4 months ago #170228
by theshade
Replied by theshade on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hello, I think I just made some progress, :woohoo:
actualy my xml had this:
<syncManager idx="2" dir="out">
<pdo idx="1600">
<!--<pdoEntry idx="6040" subIdx="0" bitLen="16" halPin="control-word" halType="u32"/>-->
<pdoEntry idx="6040" subIdx="0" bitLen="16" halType="complex">
<complexEntry bitLen="1" halPin="X-cmd-SwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableVoltage" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-/QuickStop" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableOperation" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel1" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel2" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel3" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-FaultReset" halType="bit"/>
<complexEntry bitLen="1" halPin="XcTimeOut" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel4" halType="bit"/>
<complexEntry bitLen="6"/>
</pdoEntry>
<pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="opmode" halType="bit"/>
<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1"/>
</pdo>
</syncManager>
so I checked and indeed 0x6061 was always reading 0x08
because that is what is saved in the drive from before I enable and OP the drive.
but in OP 0x6060 is reading 0x00...
because I didn't do anything special in linuxcnc the halconfig related to 0x6060 stayed at 0x00
so what I did is add this to postgui.hal:
setp lcec.0.0.opmode-3 true
which actually writes the 3rd bit in 0x6060 and now when I read registers with
ethercat -p0 upload 0x6060 0
I get 0x08
and same for 0x6061
finally after looking for something logical and mucho tweaking: I changed the scales to 1000 and 0.0001:
<masters>
<master idx="0" appTimePeriod="1000000" refClockSyncCycles="1000">
<!-- ECT60 slave -->
<slave idx="0" type="generic" vid="00000A88" pid="0a880002" configPdos="true">
<!-- <initCmds filename="ECT60.xml"/> -->
<!--<dcConf assignActivate="300" sync0Cycle="10000000" sync0Shift="0"/>-->
<dcConf assignActivate="300" sync0Cycle="*1" sync0Shift="0"/>
<!-- <sdoConfig idx="6060" subIdx="0"><sdoDataRaw data="08"/></sdoConfig>-->
<syncManager idx="0" dir="out">
</syncManager>
<syncManager idx="1" dir="in">
</syncManager>
<syncManager idx="2" dir="out">
<pdo idx="1600">
<!--<pdoEntry idx="6040" subIdx="0" bitLen="16" halPin="control-word" halType="u32"/>-->
<pdoEntry idx="6040" subIdx="0" bitLen="16" halType="complex">
<complexEntry bitLen="1" halPin="X-cmd-SwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableVoltage" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-/QuickStop" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableOperation" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel1" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel2" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel3" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-FaultReset" halType="bit"/>
<complexEntry bitLen="1" halPin="XcTimeOut" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel4" halType="bit"/>
<complexEntry bitLen="6"/>
</pdoEntry>
<pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="opmode" halType="bit"/>
<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1000"/>
</pdo>
</syncManager>
<syncManager idx="3" dir="in">
<pdo idx="1a00">
<!--<pdoEntry idx="6041" subIdx="00" bitLen="16" halPin="status-word" halType="u32"/>-->
<pdoEntry idx="6041" subIdx="0" bitLen="16" halType="complex">
<complexEntry bitLen="1" halPin="X-stat-ReadyToSwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-SwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-OperationEnable" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Fault" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-VoltageEnabled" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-QuickStop" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-SwitchOnDisable" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Warning" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Keep" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Remote" halType="bit"/>
<complexEntry bitLen="5"/>
</pdoEntry>
<pdoEntry idx="6061" subIdx="00" bitLen="8" halPin="opmode_fb" halType="bit"/>
<pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="actpos" halType="float" scale=".001"/>
<pdoEntry idx="60FD" subIdx="00" bitLen="32" halPin="digital_inputs" halType="bit"/>
</pdo>
</syncManager>
</slave>
</master>
</masters>
AND NOW I CAN JOG!!!!! 1 axis... now I have a whole cnc to build but it seems so easy in comparison !!!
THANK YOU CHIMENO I owe you one...
actualy my xml had this:
<syncManager idx="2" dir="out">
<pdo idx="1600">
<!--<pdoEntry idx="6040" subIdx="0" bitLen="16" halPin="control-word" halType="u32"/>-->
<pdoEntry idx="6040" subIdx="0" bitLen="16" halType="complex">
<complexEntry bitLen="1" halPin="X-cmd-SwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableVoltage" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-/QuickStop" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableOperation" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel1" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel2" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel3" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-FaultReset" halType="bit"/>
<complexEntry bitLen="1" halPin="XcTimeOut" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel4" halType="bit"/>
<complexEntry bitLen="6"/>
</pdoEntry>
<pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="opmode" halType="bit"/>
<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1"/>
</pdo>
</syncManager>
so I checked and indeed 0x6061 was always reading 0x08
because that is what is saved in the drive from before I enable and OP the drive.
but in OP 0x6060 is reading 0x00...
because I didn't do anything special in linuxcnc the halconfig related to 0x6060 stayed at 0x00
so what I did is add this to postgui.hal:
setp lcec.0.0.opmode-3 true
which actually writes the 3rd bit in 0x6060 and now when I read registers with
ethercat -p0 upload 0x6060 0
I get 0x08
and same for 0x6061
finally after looking for something logical and mucho tweaking: I changed the scales to 1000 and 0.0001:
<masters>
<master idx="0" appTimePeriod="1000000" refClockSyncCycles="1000">
<!-- ECT60 slave -->
<slave idx="0" type="generic" vid="00000A88" pid="0a880002" configPdos="true">
<!-- <initCmds filename="ECT60.xml"/> -->
<!--<dcConf assignActivate="300" sync0Cycle="10000000" sync0Shift="0"/>-->
<dcConf assignActivate="300" sync0Cycle="*1" sync0Shift="0"/>
<!-- <sdoConfig idx="6060" subIdx="0"><sdoDataRaw data="08"/></sdoConfig>-->
<syncManager idx="0" dir="out">
</syncManager>
<syncManager idx="1" dir="in">
</syncManager>
<syncManager idx="2" dir="out">
<pdo idx="1600">
<!--<pdoEntry idx="6040" subIdx="0" bitLen="16" halPin="control-word" halType="u32"/>-->
<pdoEntry idx="6040" subIdx="0" bitLen="16" halType="complex">
<complexEntry bitLen="1" halPin="X-cmd-SwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableVoltage" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-/QuickStop" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-EnableOperation" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel1" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OPmodeRel2" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel3" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-FaultReset" halType="bit"/>
<complexEntry bitLen="1" halPin="XcTimeOut" halType="bit"/>
<complexEntry bitLen="1" halPin="X-cmd-OpmodeRel4" halType="bit"/>
<complexEntry bitLen="6"/>
</pdoEntry>
<pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="opmode" halType="bit"/>
<pdoEntry idx="607A" subIdx="00" bitLen="32" halPin="poscmd" halType="float" scale="1000"/>
</pdo>
</syncManager>
<syncManager idx="3" dir="in">
<pdo idx="1a00">
<!--<pdoEntry idx="6041" subIdx="00" bitLen="16" halPin="status-word" halType="u32"/>-->
<pdoEntry idx="6041" subIdx="0" bitLen="16" halType="complex">
<complexEntry bitLen="1" halPin="X-stat-ReadyToSwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-SwitchOn" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-OperationEnable" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Fault" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-VoltageEnabled" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-QuickStop" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-SwitchOnDisable" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Warning" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Keep" halType="bit"/>
<complexEntry bitLen="1" halPin="X-stat-Remote" halType="bit"/>
<complexEntry bitLen="5"/>
</pdoEntry>
<pdoEntry idx="6061" subIdx="00" bitLen="8" halPin="opmode_fb" halType="bit"/>
<pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="actpos" halType="float" scale=".001"/>
<pdoEntry idx="60FD" subIdx="00" bitLen="32" halPin="digital_inputs" halType="bit"/>
</pdo>
</syncManager>
</slave>
</master>
</masters>
AND NOW I CAN JOG!!!!! 1 axis... now I have a whole cnc to build but it seems so easy in comparison
!!!THANK YOU CHIMENO I owe you one...
Last edit: 6 years 4 months ago by theshade. Reason: little error
The following user(s) said Thank You: chimeno
- sqmathlete
- Offline
- Premium Member
-

Less
More
- Posts: 118
- Thank you received: 18
6 years 4 months ago #170282
by sqmathlete
Replied by sqmathlete on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
Hi all,
I know I've overlooked something simple but I cannot get my Delta ASDA-A2E amps to switch the default direction they travel i.e. I send a positive move and the carriage move's towards the negative direction. The machine is a slant bed lathe (back tool) and I have the limits as x min=0.0 x max=250.0mm, z min=0.0 and z max= 521.0mm. Home=+250,521.
I have tried setting P1-01 = 0x010C which should change the default rotation of the motor. I am running in CSP mode but I though this was the parameter for all modes. Any suggestions?
Thanks,
Dan
- Todd Zuercher
- Offline
- Platinum Member
-

Less
More
- Posts: 4793
- Thank you received: 1480
6 years 4 months ago #170483
by Todd Zuercher
Replied by Todd Zuercher on topic Ethercat HAL generic on raspberry 4 rt (working with beckhoff)
it might just be simpler to revers the direction within Linuxcnc by making the output scale negative.
- theshade
- Offline
- Junior Member
-
Less
More
- Posts: 29
- Thank you received: 5
6 years 4 months ago - 6 years 4 months ago #170541
by theshade
Replied by theshade on topic Ethercat HAL driver
Dear All,
Since Friday I am playing with a raspberry 4 with preempt RT controlling a close loop x axis stepper motor through an ECT60 ethercat drive.
I decided to spend some time configuring and adjusting the scale so that the mm scale on screen would match the screw in my gantry which seems like a good idea.
Also I was curious to see what speed I could achieve in displacement (no load or screw yet)
Well it so happens that I found the max speed to be about 3500 mm/minute. Higher than that and the motor would stop complaining about an error on the Joint . I understand that this is due to delta between the cmd position and the actual position returned by the motor.
I do believe this "max" speed to be adequate for my application and I am fairly happy with it, stil I would like to know what position lag this implies and if building the CNC based on this hardware is realistic or if I need to tweek it..
Also I believe it is linuxcnc that raises the alarm before the closed loop in the driver complains (is that desired behaviour at least it doesn't seem that I have to clear the driver error)?
Also what I a don't know yet is if the position lag or error is acceptable and since I believe my loop ethercat loop is 1ms I wanted to know if that was the cause of the whole lag.
So I fired the latency test histogram and plots as well as plotted actual position and cmd position in HAL scope (which I am not sure to fully master yet btw) to see how things fitted together.
the latency seems to be generally under the 1ms and I believe that although I use the "generic" driver it is not a bottle neck...???
But on the halscope,
I observed a 15 ms delay in time for the actual position to reach the cmd position at full speed of about 3000 mm/min = 50mm/s
on the graph the position lag is just under 1 halscope unit... which I suppose is mm
Doing some simple math 1 ms at that speed is a move of 50 um and 15 ms corresponds to 750 um which is about right.
So my question would be ... is that expected normal behavior for a closed loop stepper drive and motor?
Ethercat doesn't seem to be the bottle neck here (1 ms vs 15 ms) and I suppose the lag must thus be from the PID regulator in the driver.
And can linuxcnc successfully work with such a lag?
I suppose that I will never mill at that speed (probably only up to one third of that 1m/min) but that would already represent 250um lag... so is it acceptable?
Sorry if those general considerations are expected knowledge, but I don't know what is the correct strategy to reduce this error.
I believe this is usually solved using feedforward in a PID loop. So I found at least 2 registers in the driver which might be of interest:
Object dictionary Name Property Type Range The default value Note
0x2023:04 PosLoop_Kvff R/W/S UINT 0 to100 30 Speed compensation
and this one
Object dictionary Name Property Type Range The default value Note
0x2009 Filter Time R/W/S UINT 0~25600 6400 us
ECT60 has a built-in moving average filter. This object is used to set the time of moving average
filter. The greater the filtering time, the smoother the start and stop of the motor, but the greater
the response lag of the motor.
Lag time = filter time
There is also 0x2025 "speed filter" with some frequency parameters and also there is servo mode 2 parameter set (Kp,Ki,Kv1,Kv2,Kvf) to play with at 0x2026 to use for vector control algorithm
So what is a good strategy or guide to set up those parameters?
update: so I played a bit with parameter 0x2009 trying to half the time constant and indeed it does reduce the the lag between actpos and poscmd... but at the cost of the drive being "sometimes" unstable when I move the jog back and forth. It makes noises and strange steps .. I can feel it's not "happy"...
photos.app.goo.gl/PoLrSQ2Csg674BmY6


Last edit: 6 years 4 months ago by theshade. Reason: typo
Time to create page: 4.605 seconds