
- Posts: 14
- Thank you received: 3

I followed all the steps in this instruction.Clone these 2 repos (or download az zip)
github.com/marcoreps/linuxcnc_leadshine_EL8
github.com/LinuxCNC
Clopy from the second these files in to a known directory (/home/cnc/linuxcnc-dev/emc/motion/) for example.
homing.c
homing.h
motion.h
from the first repo, edit the el8_homecomp file, and change the path to homing.c file, to where you saved your files.
compile the cia402.comp:
sudo homecomp --install cia402.comp
compile the el8_homecomp.comp:
sudo homecomp --install el8_homecomp.comp
edit your axis.ini (or whatever is your gui)
after the EMCMOT, paste this line:
HOMEMOD=el8_homecomp
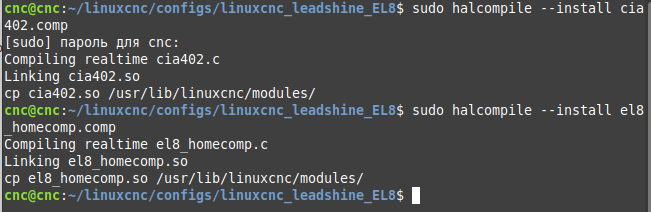
I had problems with this point.So thats it. The rest is setting up the servos, and the internal homing in the drives. Without it, you can not use this process, since the servos not responding to homing request.
Please Log in or Create an account to join the conversation.
We usually use Teamviewer but you must be using an Xorg desktop not WaylandCan anyone recommend a low-latency remote assistance software?
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
I too am having trouble with the ethercat install. Looks like the issue is very similar to Evgeny. I am able to see the ethercat slaves at this point but when I try to interact with lcec_conf it errors. I searched the computer and cannot find lcec_conf anywhere.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
