Search Results (Searched for: )

  • viewsat
31 Jul 2026 12:23 - 31 Jul 2026 16:00
My settings are as follows, JSON file attached.
 
 
  • hitchhiker
31 Jul 2026 11:42
Replied by hitchhiker on topic PUMA 200 Robotarm and some Hal/INI issues
Ok!

But what about the tcp in the simulation and my config?
Could you olease check if you have the phenomen with your sim config?

Ok a negative sign on pwm scale and encoder scale is not the issue?

Could you please explain me what are the correct direction of turn + - joint 1 2 3 4 5 6?

Possible that there is something wrong... i dont understand the MDH with flipping the coordinate system correct possible.. thats why alpha 0 to 5 has this values.

Possible my length and side shifts are not correct because the puma200 and puma560 are different on which side is shoulder to upper arm and upper arm to lower arm.

Thanks for your help... is it possible we can meet us in a teamview or zoom call or something? I am from germany.. timeshift... but if you can help me it would be so nice.

Thanks
  • rodw
31 Jul 2026 11:16
Thats pretty cool. I'll give it a go. If you have Home Assistant it was dead simple to publish this
 

In fact it was stupid simple once I enabled mqtt which I already had on my server (A pi4b Ive been running for years), it was done for me.

 
  • Todd Zuercher
31 Jul 2026 11:02
Replied by Todd Zuercher on topic RS485 + Absolute Encoder for Homing a 4th Axis?
If the drive and motors have absolute encoders and if you are not having encoder feedback to Linuxcnc, you may be able to program the drive to move to the "home" position when Linuxcnc sends it a home command. Then have send a homed signal to Linuxcnc which Linuxcnc could see as the home switch.

Linuxcnc also supports absolute encoders and if the absolute encoder position is being fed back to Linuxcnc, then homing is not necessary at all.
  • meister
31 Jul 2026 09:49 - 31 Jul 2026 09:57
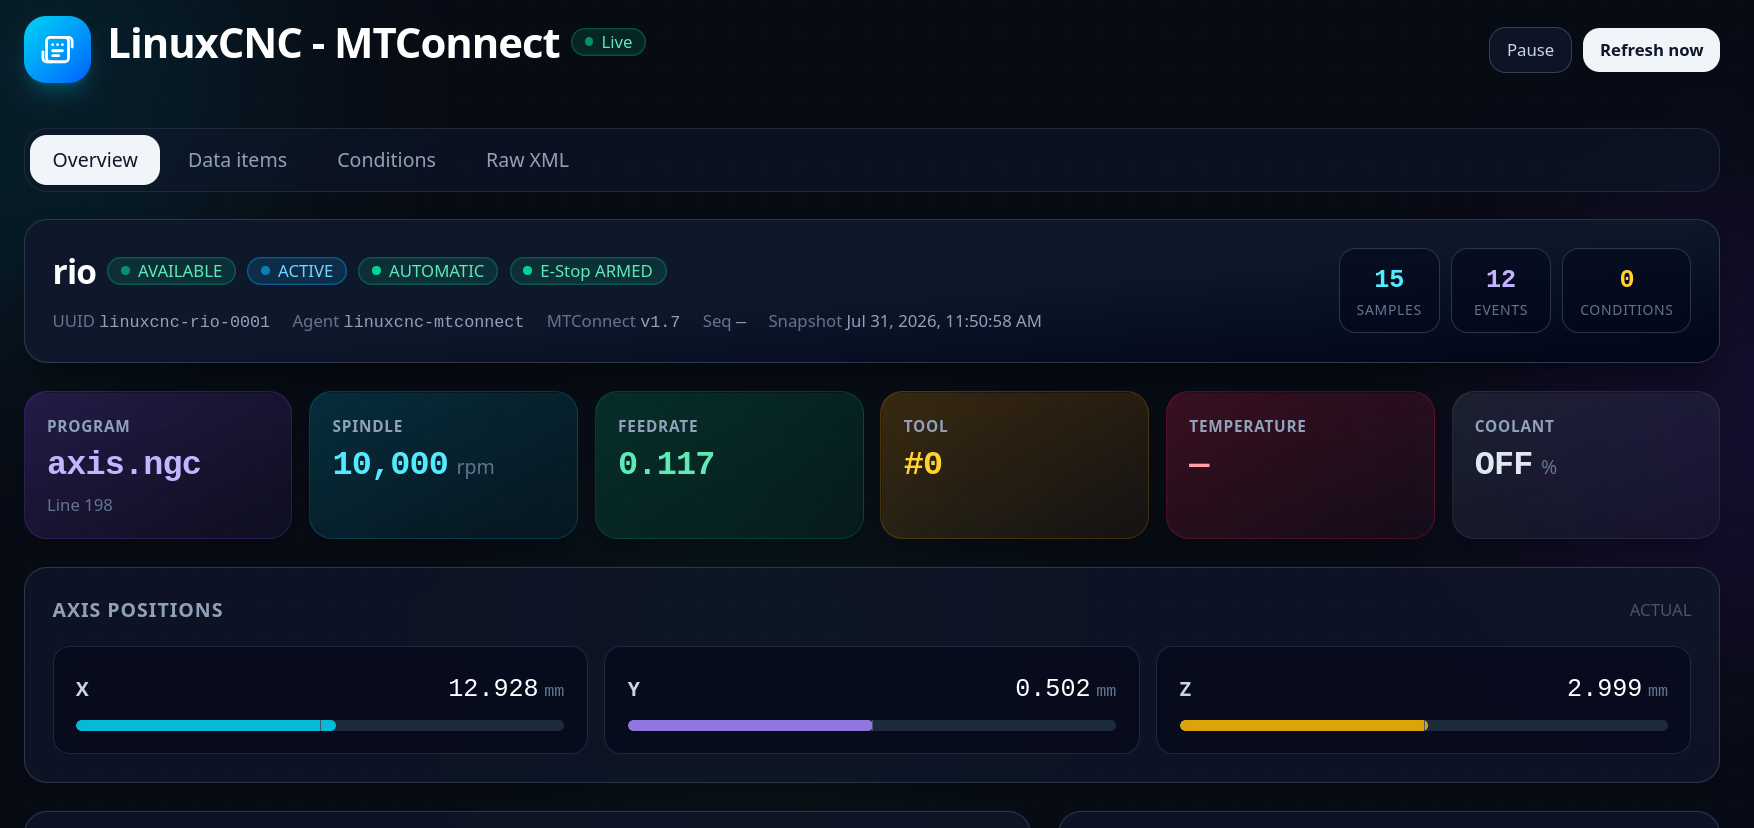
I've already found the repo, but it would be better if it were separate from the LinuxCNC source—that's what I meant by having its own repo.

It would also be cool if you could pass in additional HAL signals, like sensors or 'door-open' inputs.

EDIT:

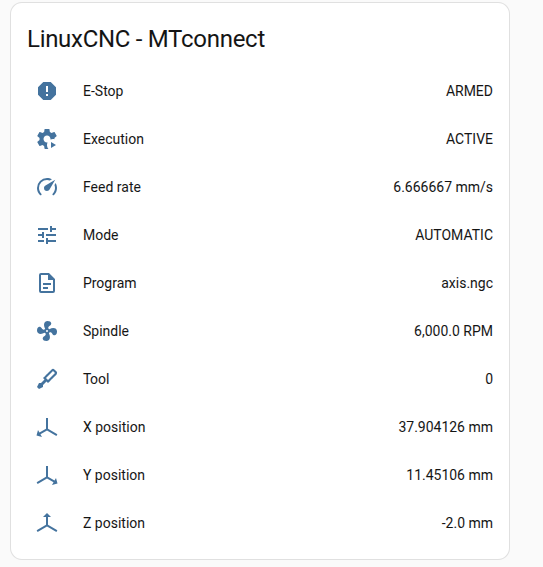
My first AI project (A simple status page for MTConnect): 
github.com/multigcs/riocore/blob/dev/rio...nect/files/stat.html

to test it, you can simply overwrite the twin.html file with it.

 
  • rodw
31 Jul 2026 09:46
Replied by rodw on topic StepperOnline A6 Servo

Thanks Guys, My main problem is that Always Homed is not working, and the issue with Homing my dual Y Setup Precisely. :|
Re homing, please read this link until you understand it. Probably at least 6 times image missing /media/kunena/emoticons/unsure.png

linuxcnc.org/docs/stable/html/config/ini-config.html
  • rodw
31 Jul 2026 09:40
Yes its pretty cool. His repo is here  github.com/sliptonic/linuxcnc/tree/feature/mtconnect-agent
I've added this link to the video description (and installed it on my machine including a Home Assistant panel)
I have asked in another thread if anybody has a 3 axis vismach model we could use in our PR to linuxCNC

The next step is to discuss with the devs how best to package this. My thought is to have a userspace driver that you added to your Hal file something like:
Code:
loadusr -W MTconnect mtconnect.ini
Because all parameters are contained in the ini file, I think this approach will require passing the ini file name to the driver.
 
  • rodw
31 Jul 2026 09:26
Replied by rodw on topic DIY CNC

@logthor: The stl you posted, will be a nightmare to machine :-).
Glad someone else looked!

With some spindles, its not possible to fit an encoder (I've had a couple) but thread milling solves the thread cutting dilema on all machines and is much easier on small machines.
  • Aciera
31 Jul 2026 07:46 - 31 Jul 2026 08:20
Replied by Aciera on topic PUMA 200 Robotarm and some Hal/INI issues

could it be a problem that i change the signs on m joint 1,3 and 4 (linuxcnc joints!).. there have minus sign... please look at the ini you will see what i mean.

If you mean the 'SCALE_PWM' then that is not necessarily wrong as long as the joints rotate in the correct directions when you are jogging.

but the in Wolrd Z moves are "ok" but in x and y it makes stuff wit the hand joints and get failure

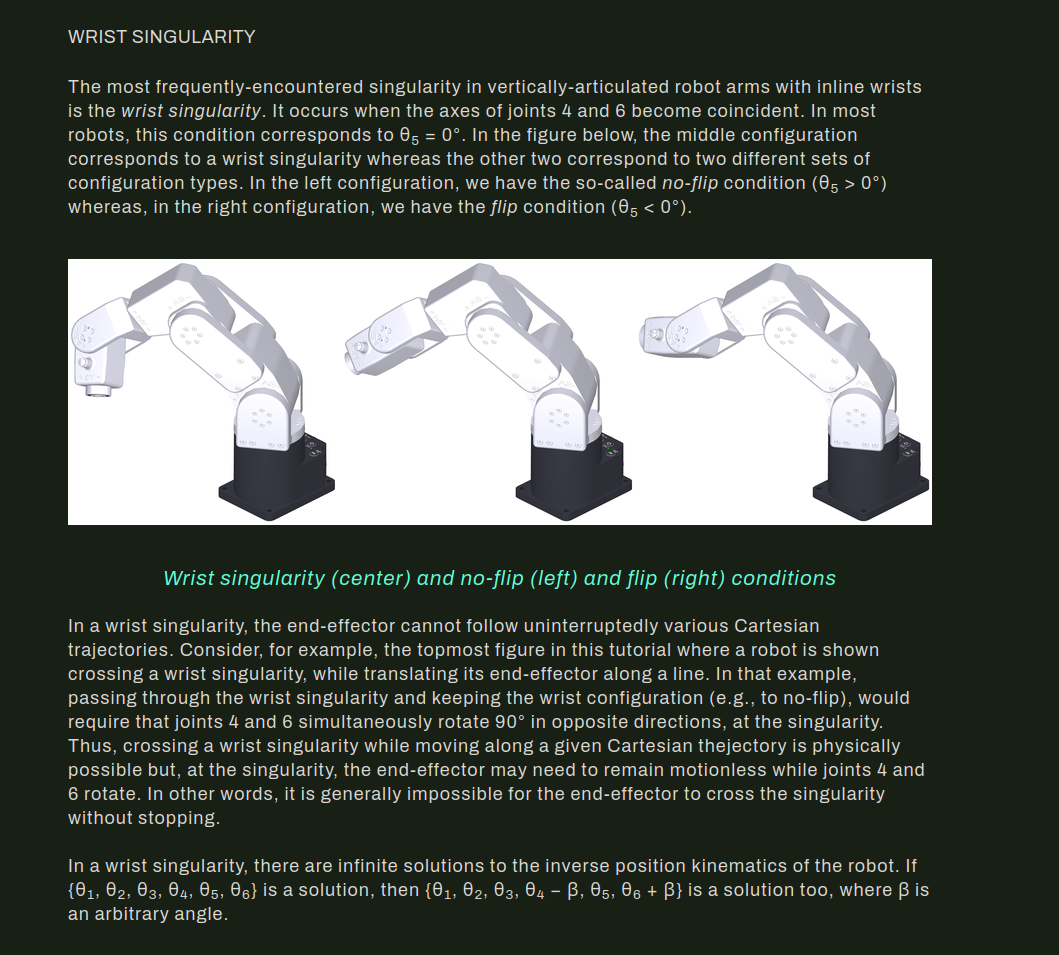
That sounds like you may be getting close to a singularity. Try setting the B joint to something that is not so close to having it point along the arm because if the wrist is collinear with the lower arm the C axis and the A axis are collinear which is a singular pose.
Sim configs CAN rapidly change the orientation of a wrist joint when approaching a singular pose, doing this with real hardware will trigger joint following errors and the kinematic will eventually fail.


for more on singularities in 6 axis manipulators:
mecademic.com/insights/academic-tutorial...es-6-axis-robot-arm/

Try it with a pose more like this:

  • meister
31 Jul 2026 07:34
He's done a really great job with his MTconnect;
it works perfectly, so I integrated it directly into my riocore system as a plugin.
It would be nice if there were a dedicated repository for it.
  • Jugo2
31 Jul 2026 07:22 - 31 Jul 2026 07:23
Replied by Jugo2 on topic StepperOnline A6 Servo
Thanks Guys, My main problem is that Always Homed is not working, and the issue with Homing my dual Y Setup Precisely. :|
  • Logthor
31 Jul 2026 07:19
Replied by Logthor on topic DIY CNC
For the simple stuff I'm doing with my bob, I don't think it'll be an issue. I'm well aware of what a nightmare it'll be to machine. The model needs a lot of love.
  • hitchhiker
31 Jul 2026 06:18
Replied by hitchhiker on topic PUMA 200 Robotarm and some Hal/INI issues
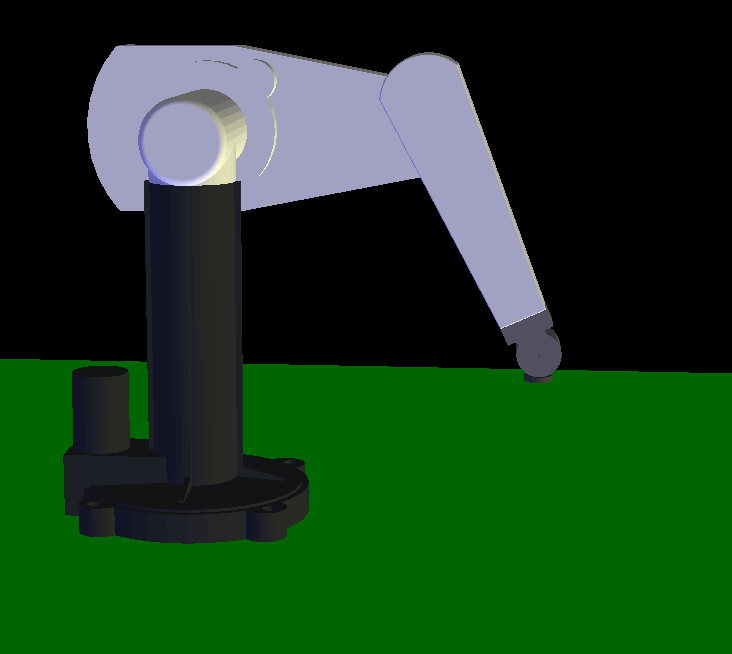
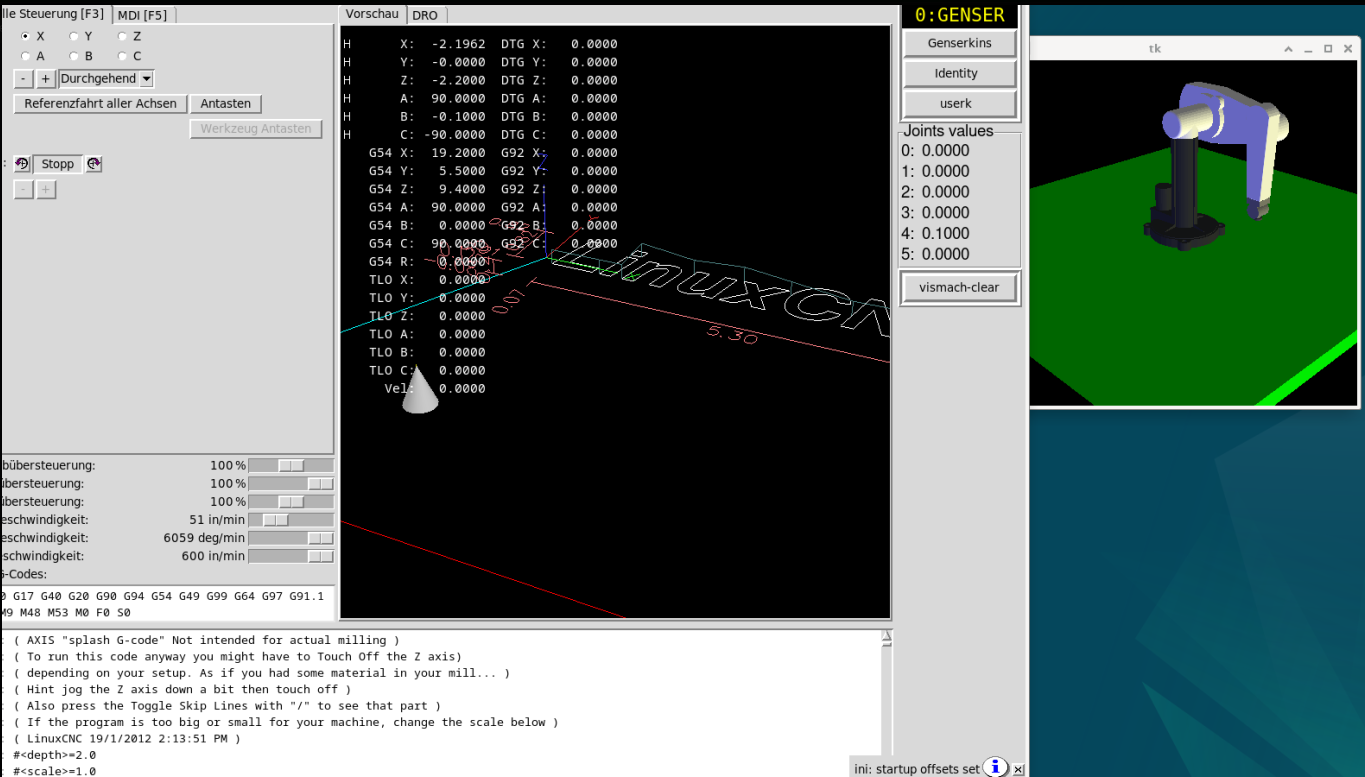
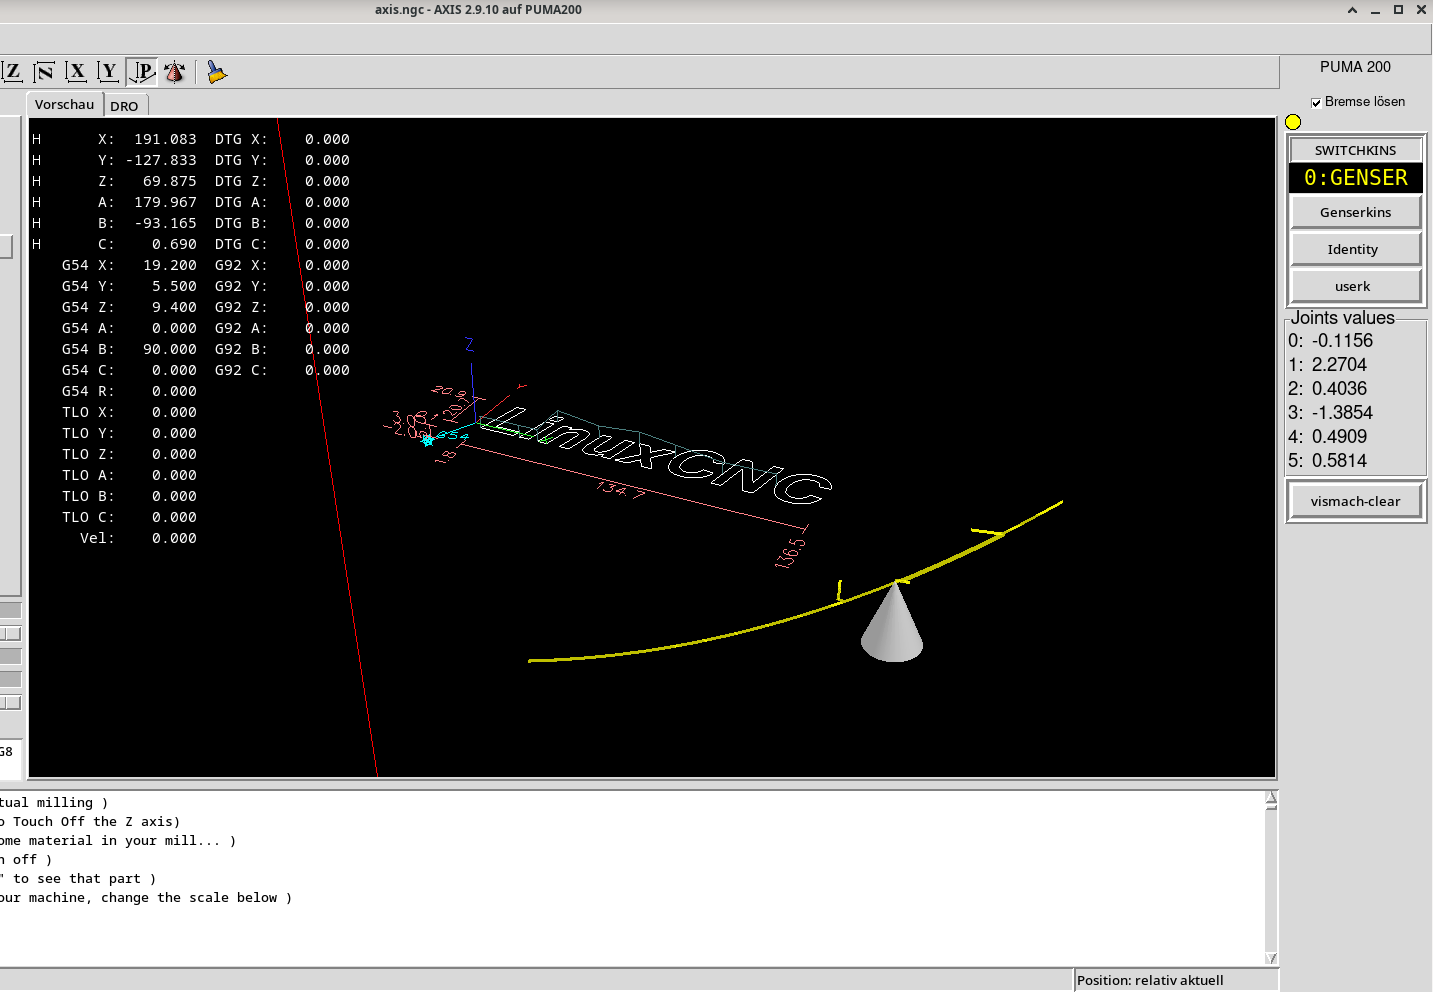
this is how it looks when i start the genserkins example 


could it be a problem that i change the signs on m joint  1,3 and 4 (linuxcnc joints!).. there have minus sign... please look at the ini you will see what i mean.

i attached 2 screenshots.. mygui is what i have after homing. i changed in the homing: homeoffset und home to 0. i move befor homeing in a extra osition.. form this position i hit home... then all 6 motors turn until the Z index of the encoder is reached.

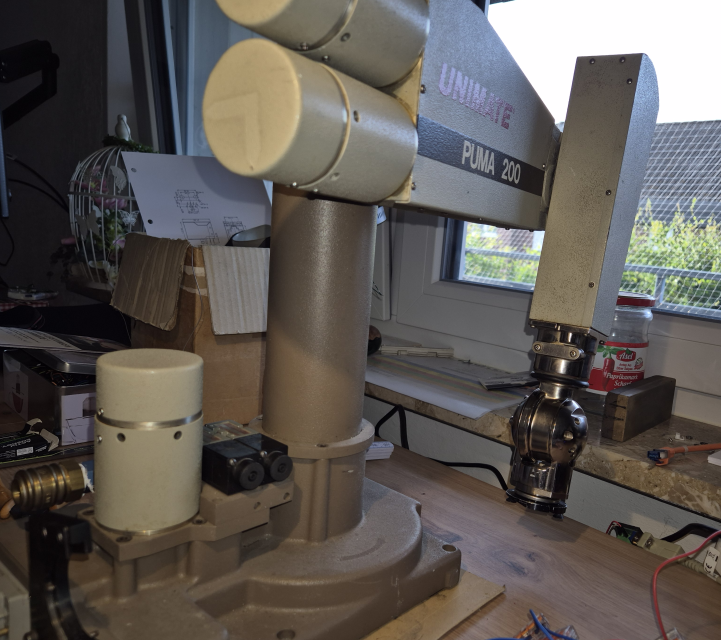
i attached form this a picture.. pumaafterhoming.... thats the "ready position" but the in Wolrd Z moves are "ok" but in x and y it makes stuff wit the hand joints and get failure.. i attached again the used ini with editi to home and home offset 0.. to talk about the NOW situation.

i thank you!


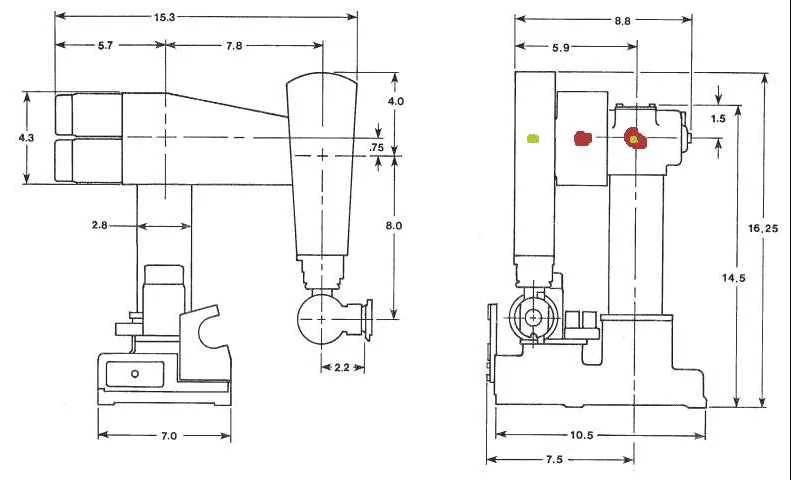
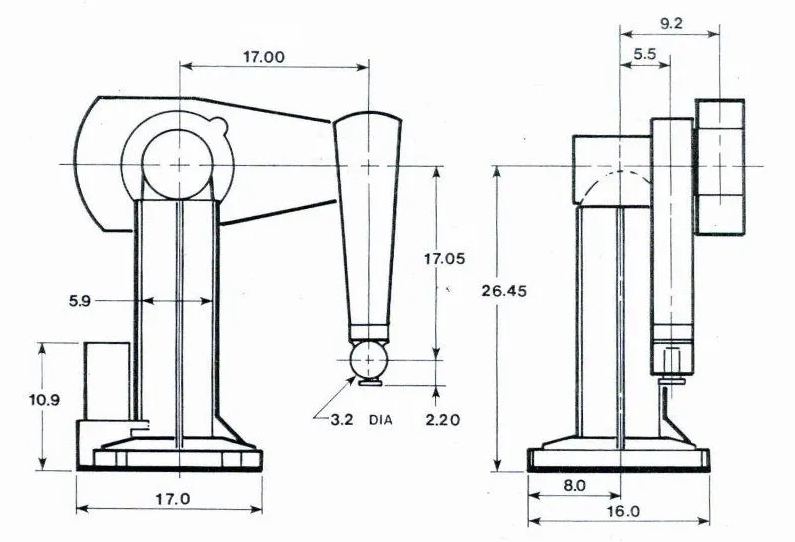
aah befor i forget... there is a difference between puma 560 and puma 200... the shoulder of the puma 200 is of the opposite then on the puma 560. thats why i have on D1 a positiv value.. this value i got from stäubli via email. i measured.. and yes this values are correct... its from red green to green in the drawing i attached. i add then the puma560geo.png to the attached files that you see what i mean what is the difference... 

pum200geo


puma560geo
 

puma200afterhoming
   
puma200gui after homing


exampleguipuma560
 
  • timo
31 Jul 2026 05:26
Replied by timo on topic DIY CNC
Anecdotal evidence: I had issues getting a 100ppr encoder to work reliable at 600 rpm. The cheap BOB seemed the issue, the system was loosing signals.

The Mesa Card fixed the problem and I have not the slightest interest in trying to figure out what went wrong, only point (I should have spent the money earlier)

20000 pulses (if I am correct and did not make a mistake) It would limit a 1/8th 200ppr stepper motor with my lead screw (4mm pitch) to approx. 3000mm/min. This is in my book good enough for a sherline, but some commercial machines run approx. 10x that speed.

@logthor: The stl you posted, will be a nightmare to machine :-).
  • Aciera
31 Jul 2026 05:08
Replied by Aciera on topic PUMA 200 Robotarm and some Hal/INI issues
Ah, I see what you mean, the A value being 180° because the tool coordinate frame is pointing away from the flange. You are rotating the tool frame in the kinematics. Ok that shouldn't be the problem then.
Can you post a screenshot of the situation when you start the example program?
Displaying 2146 - 2160 out of 11901 results.
Time to create page: 0.304 seconds
Powered by Kunena Forum