
- Posts: 144
- Thank you received: 9
TCP 5-axis kinematics
- jsskangas
- Offline
- Premium Member
-

Less
More
8 years 2 months ago #115738
by jsskangas
Replied by jsskangas on topic TCP 5-axis kinematics
Hello
Thanks for answer. I need to check kinematics one more time.
Thanks for answer. I need to check kinematics one more time.
Please Log in or Create an account to join the conversation.
- Spetrov
- Offline
- New Member
-

Less
More
- Posts: 1
- Thank you received: 0
8 years 2 months ago #116549
by Spetrov
Replied by Spetrov on topic TCP 5-axis kinematics
Hi, jsskangas, I tried your kinematics and got an error(on photo), could you help me please?
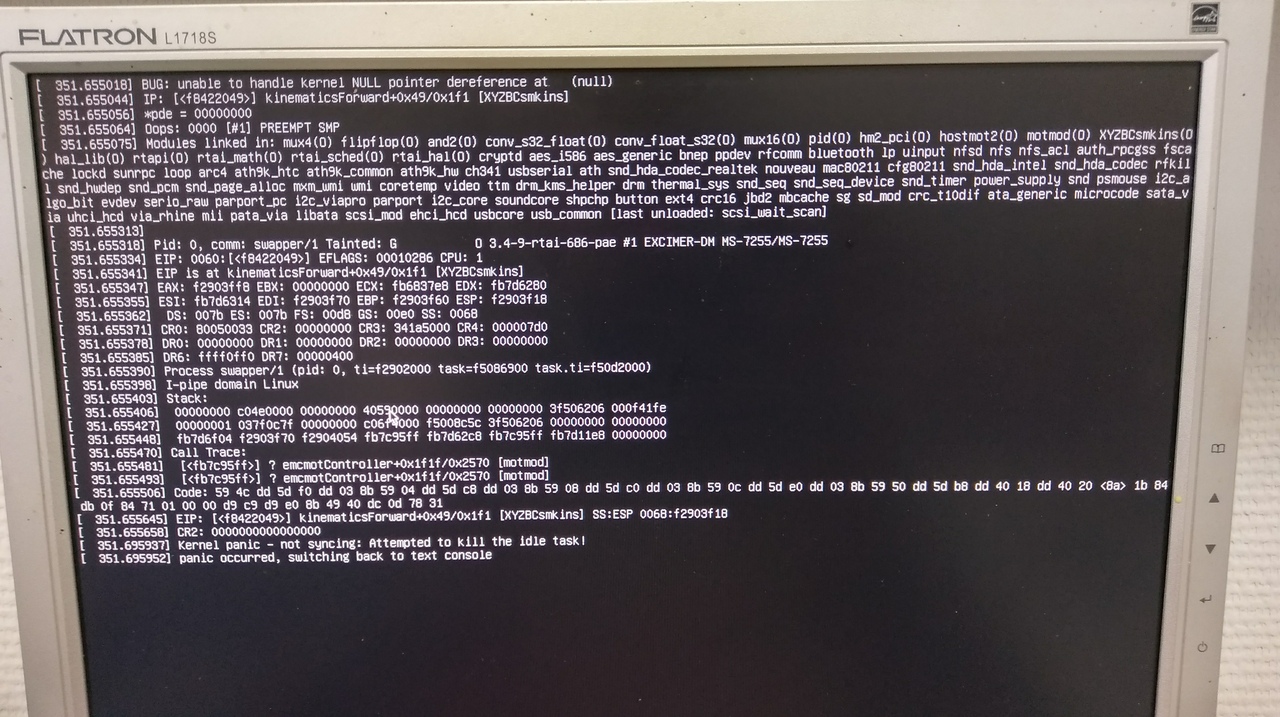
Even when I compiled your file, I had errors. I myself was able to correct them, but I could be wrong.
Even when I compiled your file, I had errors. I myself was able to correct them, but I could be wrong.
Warning: Spoiler!
make KBUILD_EXTRA_SYMBOLS=/usr/realtime-3.4-9-rtai-686-pae/modules/linuxcnc/Module.symvers -C /usr/src/linux-headers-3.4-9-rtai-686-pae SUBDIRS=`pwd` CC=gcc V=0 modules
make[1]: Entering directory `/usr/src/linux-headers-3.4-9-rtai-686-pae'
CC [M] /tmp/tmpbG6srv/XYZBCsmkins.o
/tmp/tmpbG6srv/XYZBCsmkins.c: In function ‘kinematicsForward’:
/tmp/tmpbG6srv/XYZBCsmkins.c:84:39: error: expected ‘)’ before ‘;’ token
/tmp/tmpbG6srv/XYZBCsmkins.c:124:5: error: expected ‘;’ before ‘}’ token
/tmp/tmpbG6srv/XYZBCsmkins.c:57:26: warning: unused variable ‘FK_Z’ [-Wunused-variable]
/tmp/tmpbG6srv/XYZBCsmkins.c:57:19: warning: unused variable ‘FK_Y’ [-Wunused-variable]
/tmp/tmpbG6srv/XYZBCsmkins.c: In function ‘kinematicsInverse’:
/tmp/tmpbG6srv/XYZBCsmkins.c:168:40: error: expected ‘)’ before ‘;’ token
/tmp/tmpbG6srv/XYZBCsmkins.c:197:5: error: expected ‘;’ before ‘}’ token
/tmp/tmpbG6srv/XYZBCsmkins.c:150:26: warning: unused variable ‘IK_Z’ [-Wunused-variable]
/tmp/tmpbG6srv/XYZBCsmkins.c:150:19: warning: unused variable ‘IK_Y’ [-Wunused-variable]
/tmp/tmpbG6srv/XYZBCsmkins.c: In function ‘init_module’:
/tmp/tmpbG6srv/XYZBCsmkins.c:245:116: error: unknown type name ‘Jussi’
/tmp/tmpbG6srv/XYZBCsmkins.c:245:128: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:172: error: expected ‘=’, ‘,’, ‘;’, ‘asm’ or ‘__attribute__’ before ‘J’
/tmp/tmpbG6srv/XYZBCsmkins.c:245:173: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:175: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:177: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:179: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:181: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:185: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:187: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:189: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:191: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:193: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:195: warning: null character(s) ignored [enabled by default]
/tmp/tmpbG6srv/XYZBCsmkins.c:245:116: warning: ISO C90 forbids mixed declarations and code [-Wdeclaration-after-statement]
/tmp/tmpbG6srv/XYZBCsmkins.c: At top level:
/tmp/tmpbG6srv/XYZBCsmkins.c:265:0: error: unterminated argument list invoking macro "rtapi_app_exit"
/tmp/tmpbG6srv/XYZBCsmkins.c:265:1: error: expected ‘=’, ‘,’, ‘;’, ‘asm’ or ‘__attribute__’ at end of input
make[4]: *** [/tmp/tmpbG6srv/XYZBCsmkins.o] Ошибка 1
make[3]: *** [_module_/tmp/tmpbG6srv] Ошибка 2
make[2]: *** [sub-make] Ошибка 2
make[1]: *** [all] Ошибка 2
make[1]: Leaving directory `/usr/src/linux-headers-3.4-9-rtai-686-pae'
make: *** [modules] Ошибка 2
Please Log in or Create an account to join the conversation.
- jsskangas
- Offline
- Premium Member
-
Less
More
- Posts: 144
- Thank you received: 9
8 years 2 months ago - 8 years 2 months ago #116570
by jsskangas
Replied by jsskangas on topic TCP 5-axis kinematics
Hello
Yes there seems to be error that has occurred during packing or uploading.
I will take new files.
There is still error at least in forward kinematics.
This is not usable yet.
I will correct kinematics, but at the moment it will take at least 3 weeks until I get fee time for this.
Yes there seems to be error that has occurred during packing or uploading.
I will take new files.
There is still error at least in forward kinematics.
This is not usable yet.
I will correct kinematics, but at the moment it will take at least 3 weeks until I get fee time for this.
Last edit: 8 years 2 months ago by jsskangas.
Please Log in or Create an account to join the conversation.
- jsskangas
- Offline
- Premium Member
-
Less
More
- Posts: 144
- Thank you received: 9
8 years 1 month ago - 8 years 1 month ago #117213
by jsskangas
Replied by jsskangas on topic TCP 5-axis kinematics
Hello andy
I did look into Kinematics, if you look in to exel and use "dxb" at 0.0 value, forward and inverse kinematics are ok.
I removed baxis offset support from kinematics, and still have same behavior
Error must come from somewhere else.
I did look into Kinematics, if you look in to exel and use "dxb" at 0.0 value, forward and inverse kinematics are ok.
I removed baxis offset support from kinematics, and still have same behavior
Error must come from somewhere else.
Last edit: 8 years 1 month ago by jsskangas.
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-

Less
More
- Posts: 19899
- Thank you received: 4655
8 years 1 month ago #117332
by andypugh
Replied by andypugh on topic TCP 5-axis kinematics
I wonder if you are not using the correct combinations of motor-pos-cmd, pos-cmd, motor-pos-fb and pos-fb pins in motion, so that a homing offset is being added more than once?
Please Log in or Create an account to join the conversation.
- jsskangas
- Offline
- Premium Member
-
Less
More
- Posts: 144
- Thank you received: 9
8 years 1 month ago - 8 years 1 month ago #117867
by jsskangas
Replied by jsskangas on topic TCP 5-axis kinematics
Hello
Homing works well, it is dead on every time when homed.
This error is not homing error, it is not misplaced zeropoint.
if I use only 3 axis kinematics zeropoint will stay on its point.
if I use 3+2 axis machining axis wont drift.
If I change between kinematics, axis will drift.
Somehow this lost of position is related to shifting between 3+2 and full 5-axis kinematics.
I will make video when I have next free time.
Last edit: 8 years 1 month ago by jsskangas.
Please Log in or Create an account to join the conversation.
Time to create page: 0.168 seconds