
- Posts: 33
- Thank you received: 10
LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
- viewsat
- Offline
- Junior Member
-

Less
More
2 months 2 weeks ago #348757
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
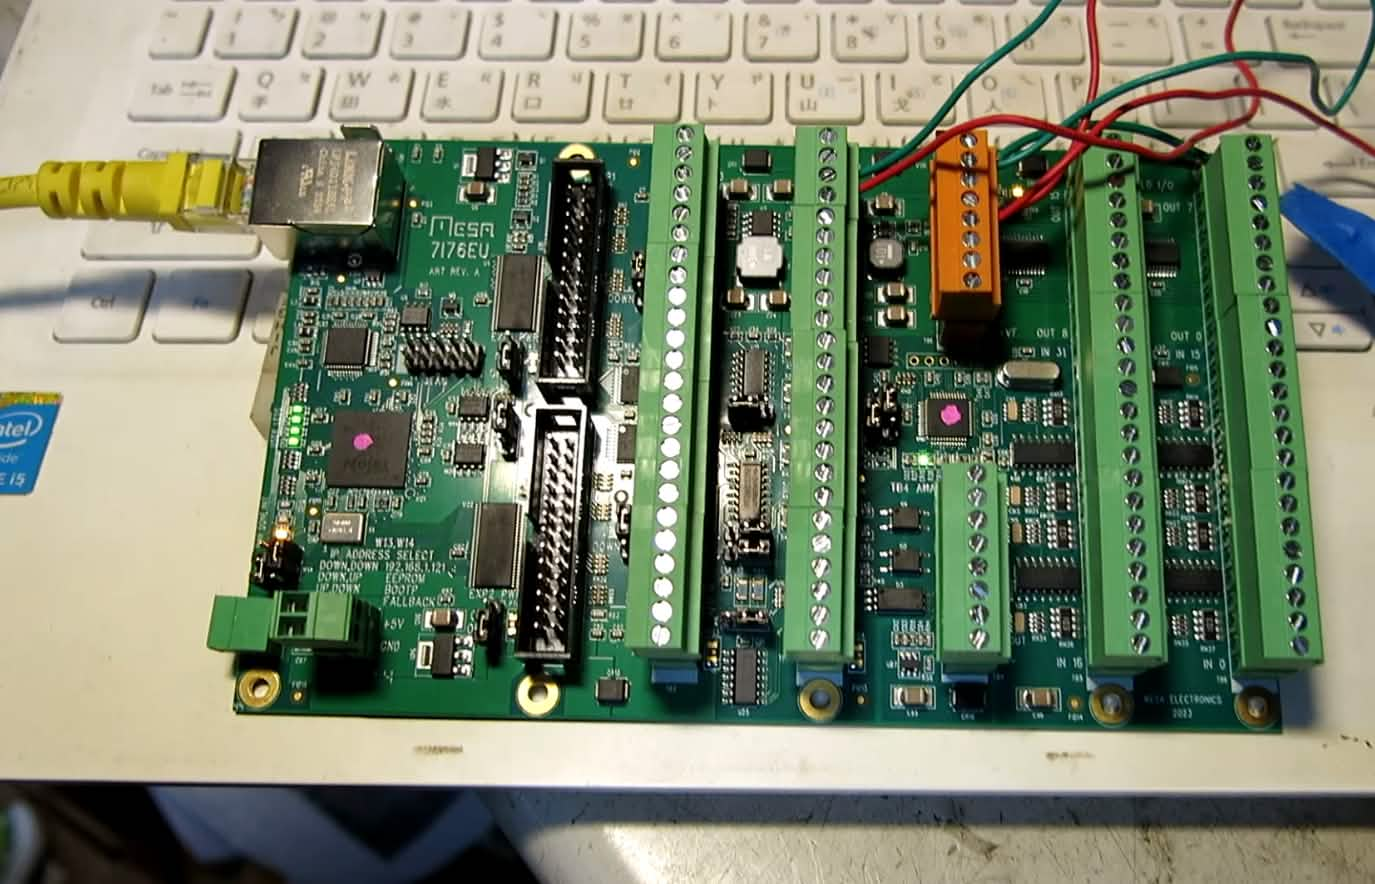
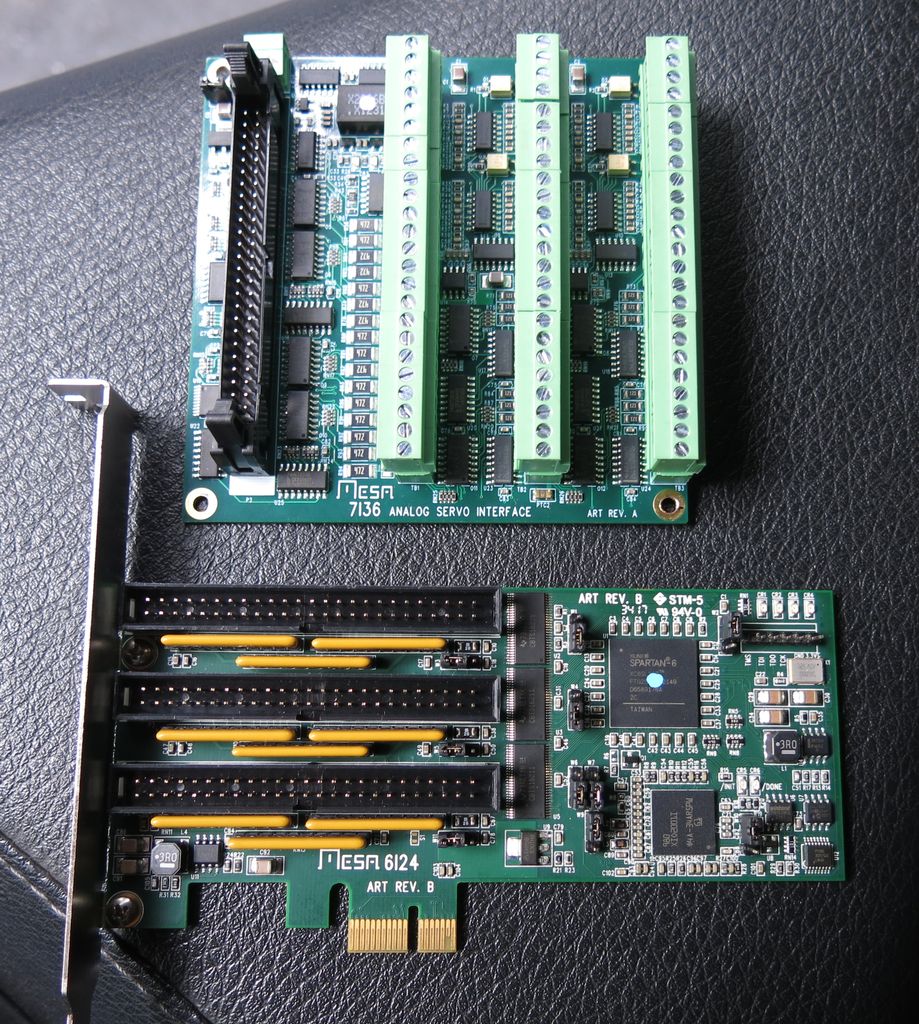
I have experience using some MESA control cards and connecting drivers, so I shouldn't have any technical difficulties connecting motor drivers.If this is a drive level issue, note that a 26C31 does not swing to 5Vand its output level is about 2 diode drops below 5V (3.6V) with a 5 mA load.I have experience using some MESA control cards and connecting drivers, so I shouldn't have any technical difficulties connecting motor drivers.
The following user(s) said Thank You: tommylight
Please Log in or Create an account to join the conversation.
- PCW
- Offline
- Moderator
-

Less
More
- Posts: 18115
- Thank you received: 5334
2 months 2 weeks ago #348772
by PCW
The issue with the 26C31 is that the high level drive does not swing to 5V
but the low level drive does swing close to 0V.
Replied by PCW on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
Yes, connected that way you would get close to 5V drive.
If this is a drive level issue, note that a 26C31 does not swing to 5V
and its output level is about 2 diode drops below 5V (3.6V) with a 5 mA load.
I connected the motor driver using +5V and A-.
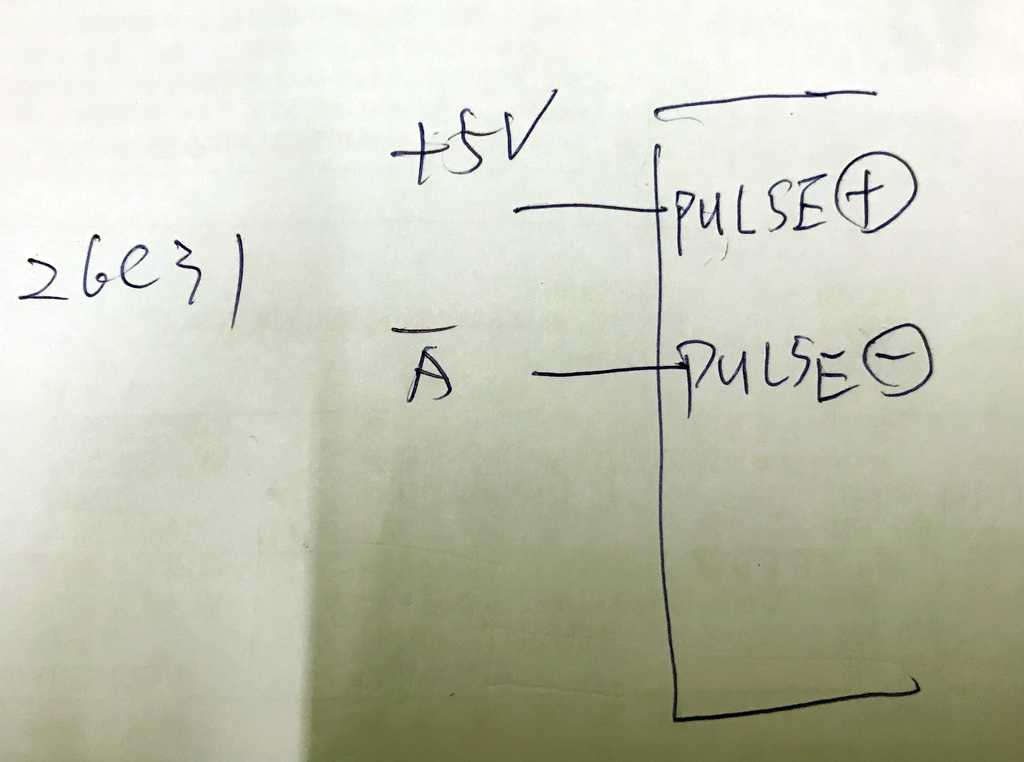
The issue with the 26C31 is that the high level drive does not swing to 5V
but the low level drive does swing close to 0V.
The following user(s) said Thank You: viewsat
Please Log in or Create an account to join the conversation.
- viewsat
- Offline
- Junior Member
-
Less
More
- Posts: 33
- Thank you received: 10
2 months 2 weeks ago - 2 months 2 weeks ago #348781
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
The Linux CNC FPGA control board I bought connects to the motor driver, and it works perfectly with the 74HC245.
There is no problem connecting the DM542 using the 74HC245.
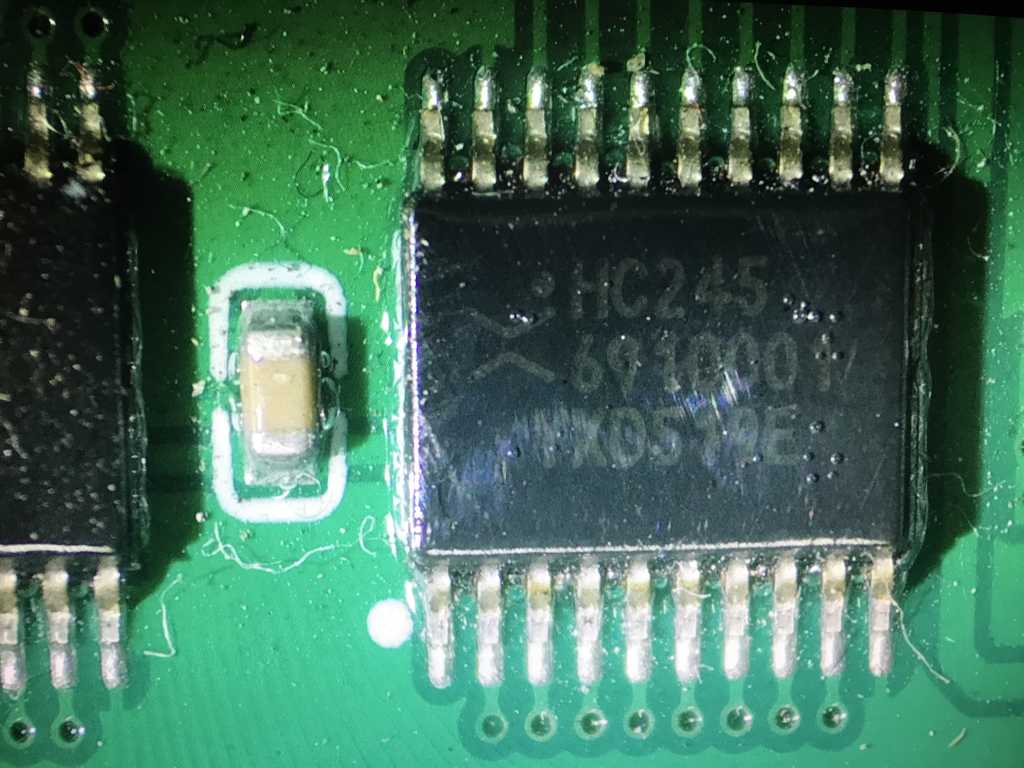
The FPGA (3.3V) is directly connected to the 74HC245 (5V).
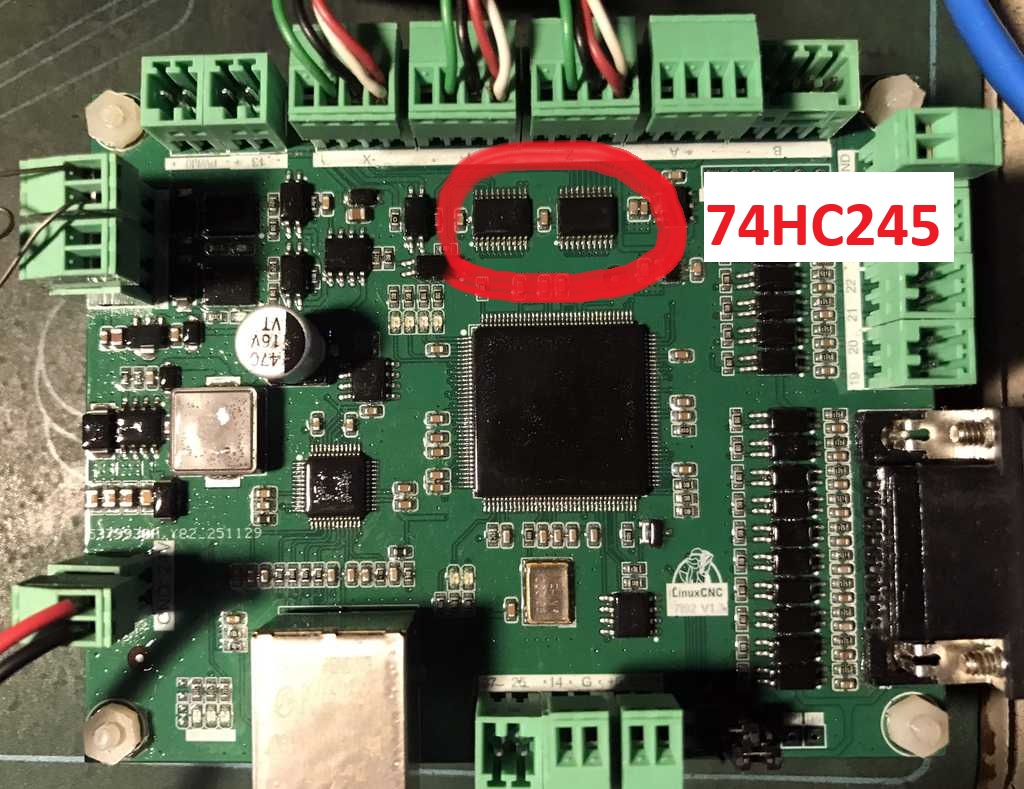
There is no problem connecting the DM542 using the 74HC245.
The FPGA (3.3V) is directly connected to the 74HC245 (5V).
Last edit: 2 months 2 weeks ago by viewsat.
Please Log in or Create an account to join the conversation.
- viewsat
- Offline
- Junior Member
-
Less
More
- Posts: 33
- Thank you received: 10
2 months 2 weeks ago - 2 months 1 week ago #348798
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
The problem has been resolved after adjusting the parameters of `joint` and `pid`.
I measured 0.2mm using a logic analyzer, which is not 64 steps.Tang Nano 9k riocore ,leadscwer=5mm,driver= 1600step/revScale_Out=320 ,1mm/320=0.003125mm/step0.2mm/0.003125=64step
I measured 0.2mm using a logic analyzer, which is not 64 steps.Tang Nano 9k riocore ,leadscwer=5mm,driver= 1600step/revScale_Out=320 ,1mm/320=0.003125mm/step0.2mm/0.003125=64step
Last edit: 2 months 1 week ago by viewsat.
The following user(s) said Thank You: meister
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-

Less
More
- Posts: 806
- Thank you received: 502
2 months 2 weeks ago #348804
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
Deviations may occur due to the PID controller and the deadband; these shouldn’t exceed ±1.
If you then also take measurements using pendulum movements without setting the G64 parameter, the difference may be even greater.
If you’ve got a logic analyser, why didn’t you use it earlier to measure the pulses?
And if you’ve got something like that, you must have a multimeter too, yet you still haven’t measured the voltages at the DIR pin.
This is a hobby project; I’m really happy to help, but there are limits – especially when you keep posting such fragmented information in the thread.
The only thing I can say is, yes, there are definitely 1,000 bugs in Riocore and a lot of things could be handled better.
I try to implement it as best I can; when bugs are reported to me, I try to fix them as soon as possible.
But if neither DIR nor Scale were working here, you certainly wouldn’t be the only one to report it.
I’ve no idea how many people use Riocore – I don’t think it’s that many –
If I keep coming across new boards from all over the world that have been built specifically for Riocore,
then I suppose there must be one or two people using them.
and the complaints seem to be kept within reasonable limits.
The following user(s) said Thank You: viewsat
Please Log in or Create an account to join the conversation.
- viewsat
- Offline
- Junior Member
-
Less
More
- Posts: 33
- Thank you received: 10
2 months 2 weeks ago - 2 months 1 week ago #348805
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
The problem has been resolved after adjusting the parameters of `joint` and `pid`.
I apologize for asking so many questions.Strangely enough, the MESA7i92 which also has PID and deadband, does not have output pulse count error. I'm a retired person in my sixties, and I only use CNC as a hobby now. I was so eager to ask because I discovered a problem with motor positioning. In my experience, I haven't encountered any open-loop pulse positioning errors with CNC controllers,so I only checked it with a logic analyzer yesterday,The number of pulses in an open-loop stepper motor must be absolutely accurate. Back in the early days of GRBL, I also found an operation that caused a crash, and I immediately notified the author. After confirming the error, he escalated it to a serious bug and fixed it( github.com/gnea/grbl/issues/238 )
I apologize for asking so many questions.Strangely enough, the MESA7i92 which also has PID and deadband, does not have output pulse count error. I'm a retired person in my sixties, and I only use CNC as a hobby now. I was so eager to ask because I discovered a problem with motor positioning. In my experience, I haven't encountered any open-loop pulse positioning errors with CNC controllers,so I only checked it with a logic analyzer yesterday,The number of pulses in an open-loop stepper motor must be absolutely accurate. Back in the early days of GRBL, I also found an operation that caused a crash, and I immediately notified the author. After confirming the error, he escalated it to a serious bug and fixed it( github.com/gnea/grbl/issues/238 )
Last edit: 2 months 1 week ago by viewsat.
Please Log in or Create an account to join the conversation.
Time to create page: 0.808 seconds