
- Posts: 33
- Thank you received: 10
LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
- viewsat
- Offline
- Junior Member
-

Less
More
2 months 3 weeks ago #348548
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
Because I'm busy with work, I'll do testing when I have time.
Please Log in or Create an account to join the conversation.
- viewsat
- Offline
- Junior Member
-
Less
More
- Posts: 33
- Thank you received: 10
2 months 3 weeks ago - 2 months 1 week ago #348598
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
DIR/PULSE issue resolved, thank you!! (2026-08-19)
I tested with the Branches dev from GitHub and the Tang Nano 9k, but the motor still couldn't return to the zero position after stopping. You must use the same DM542 stepper motor driver to reproduce this problem.
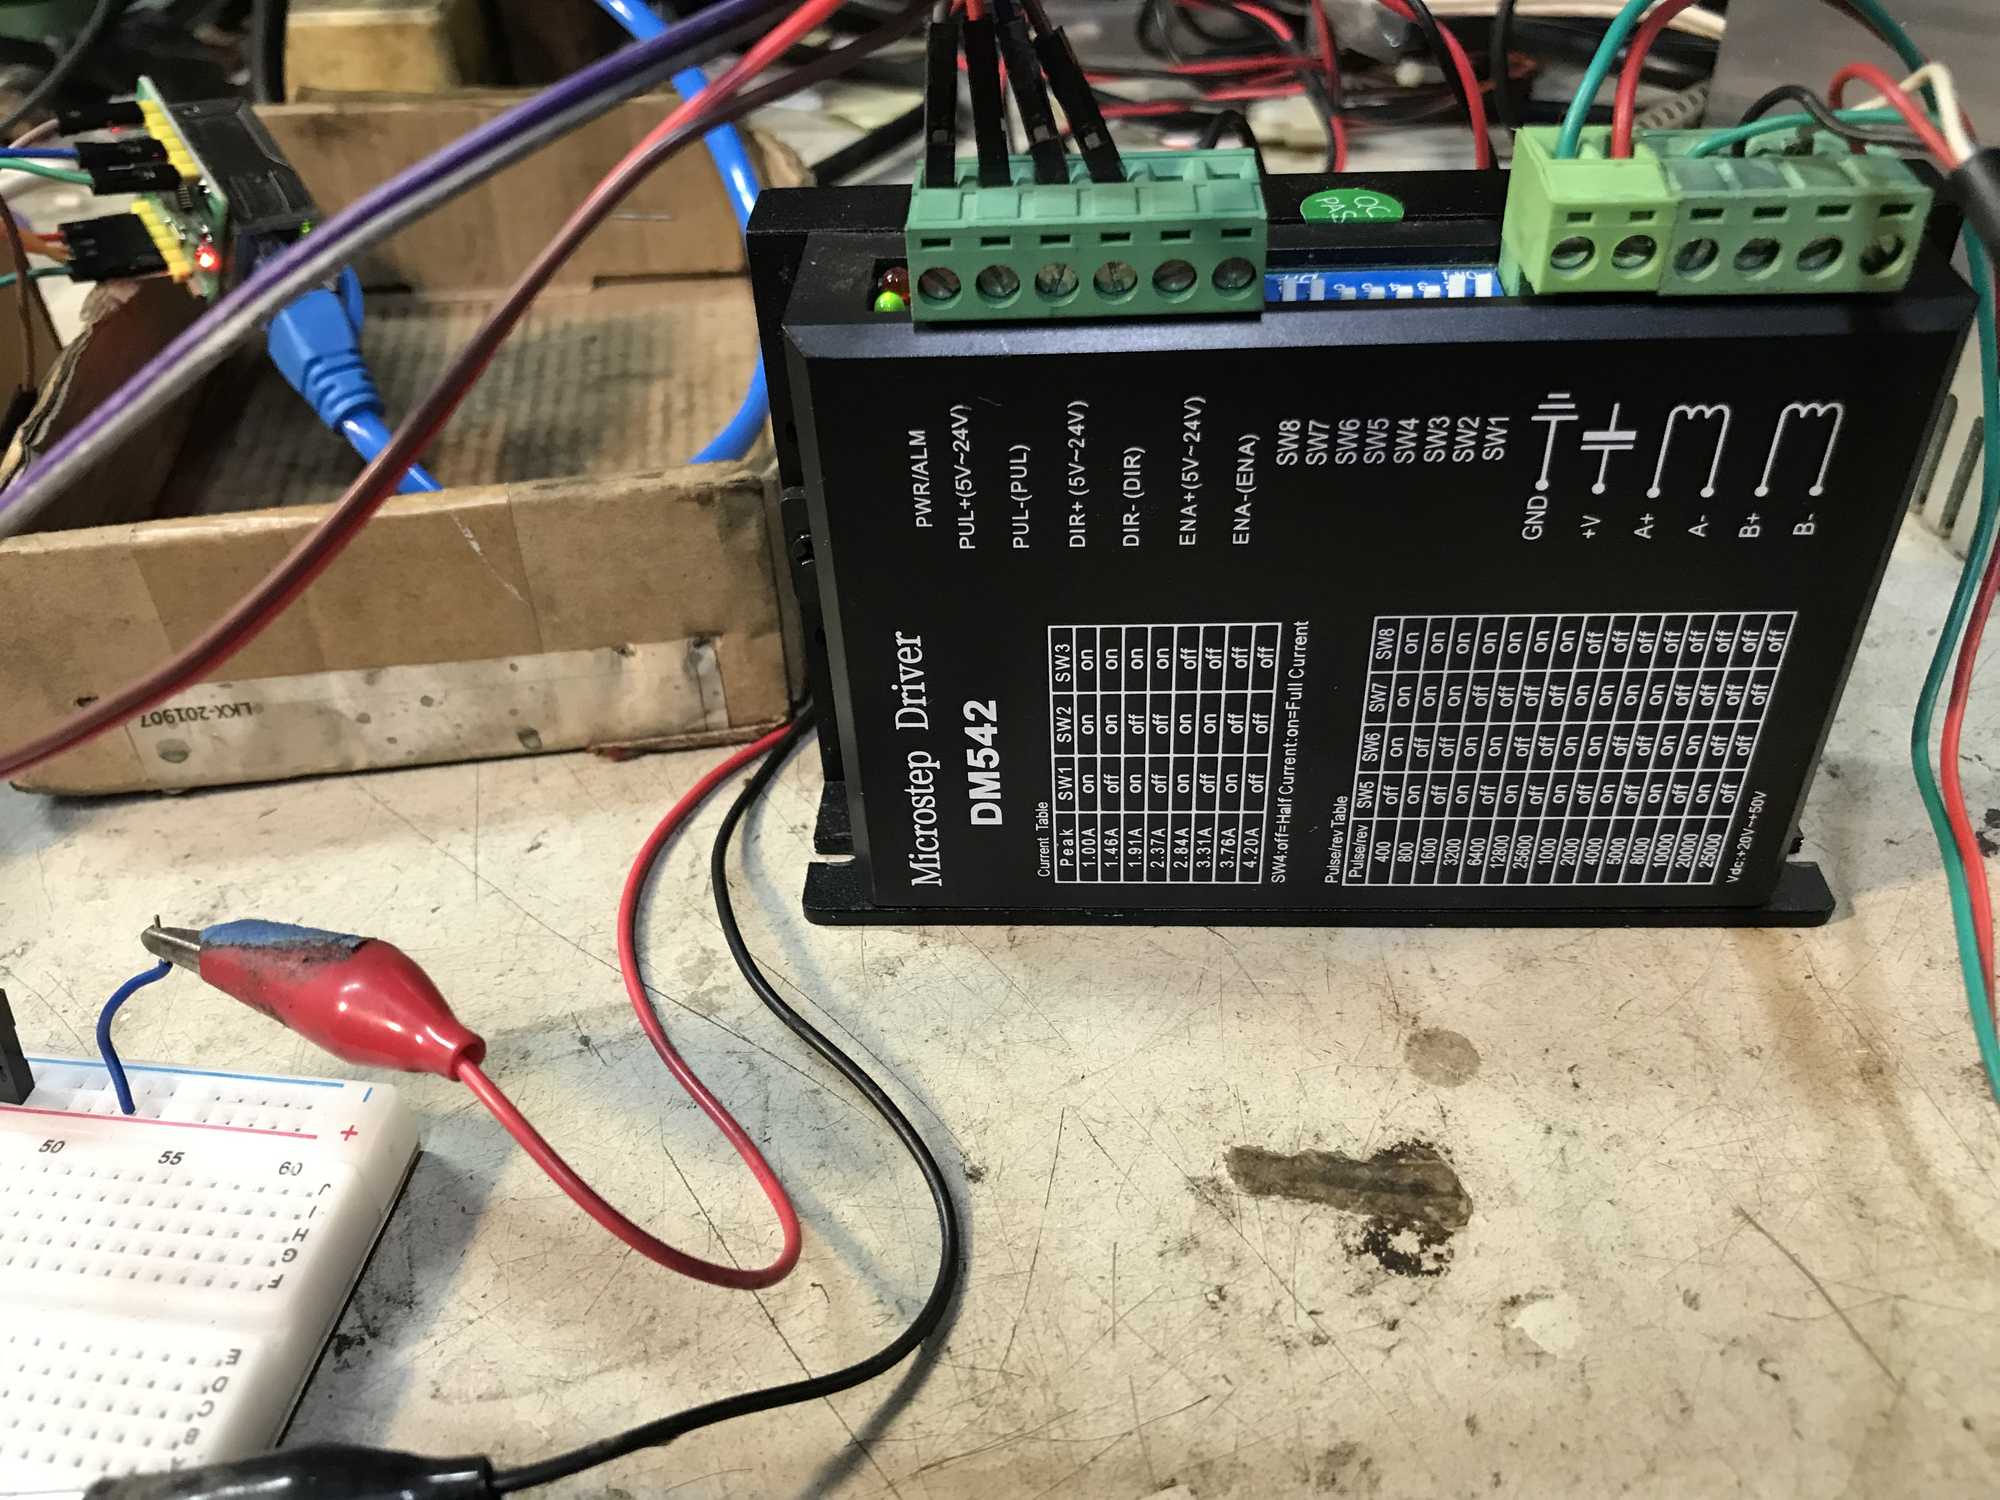
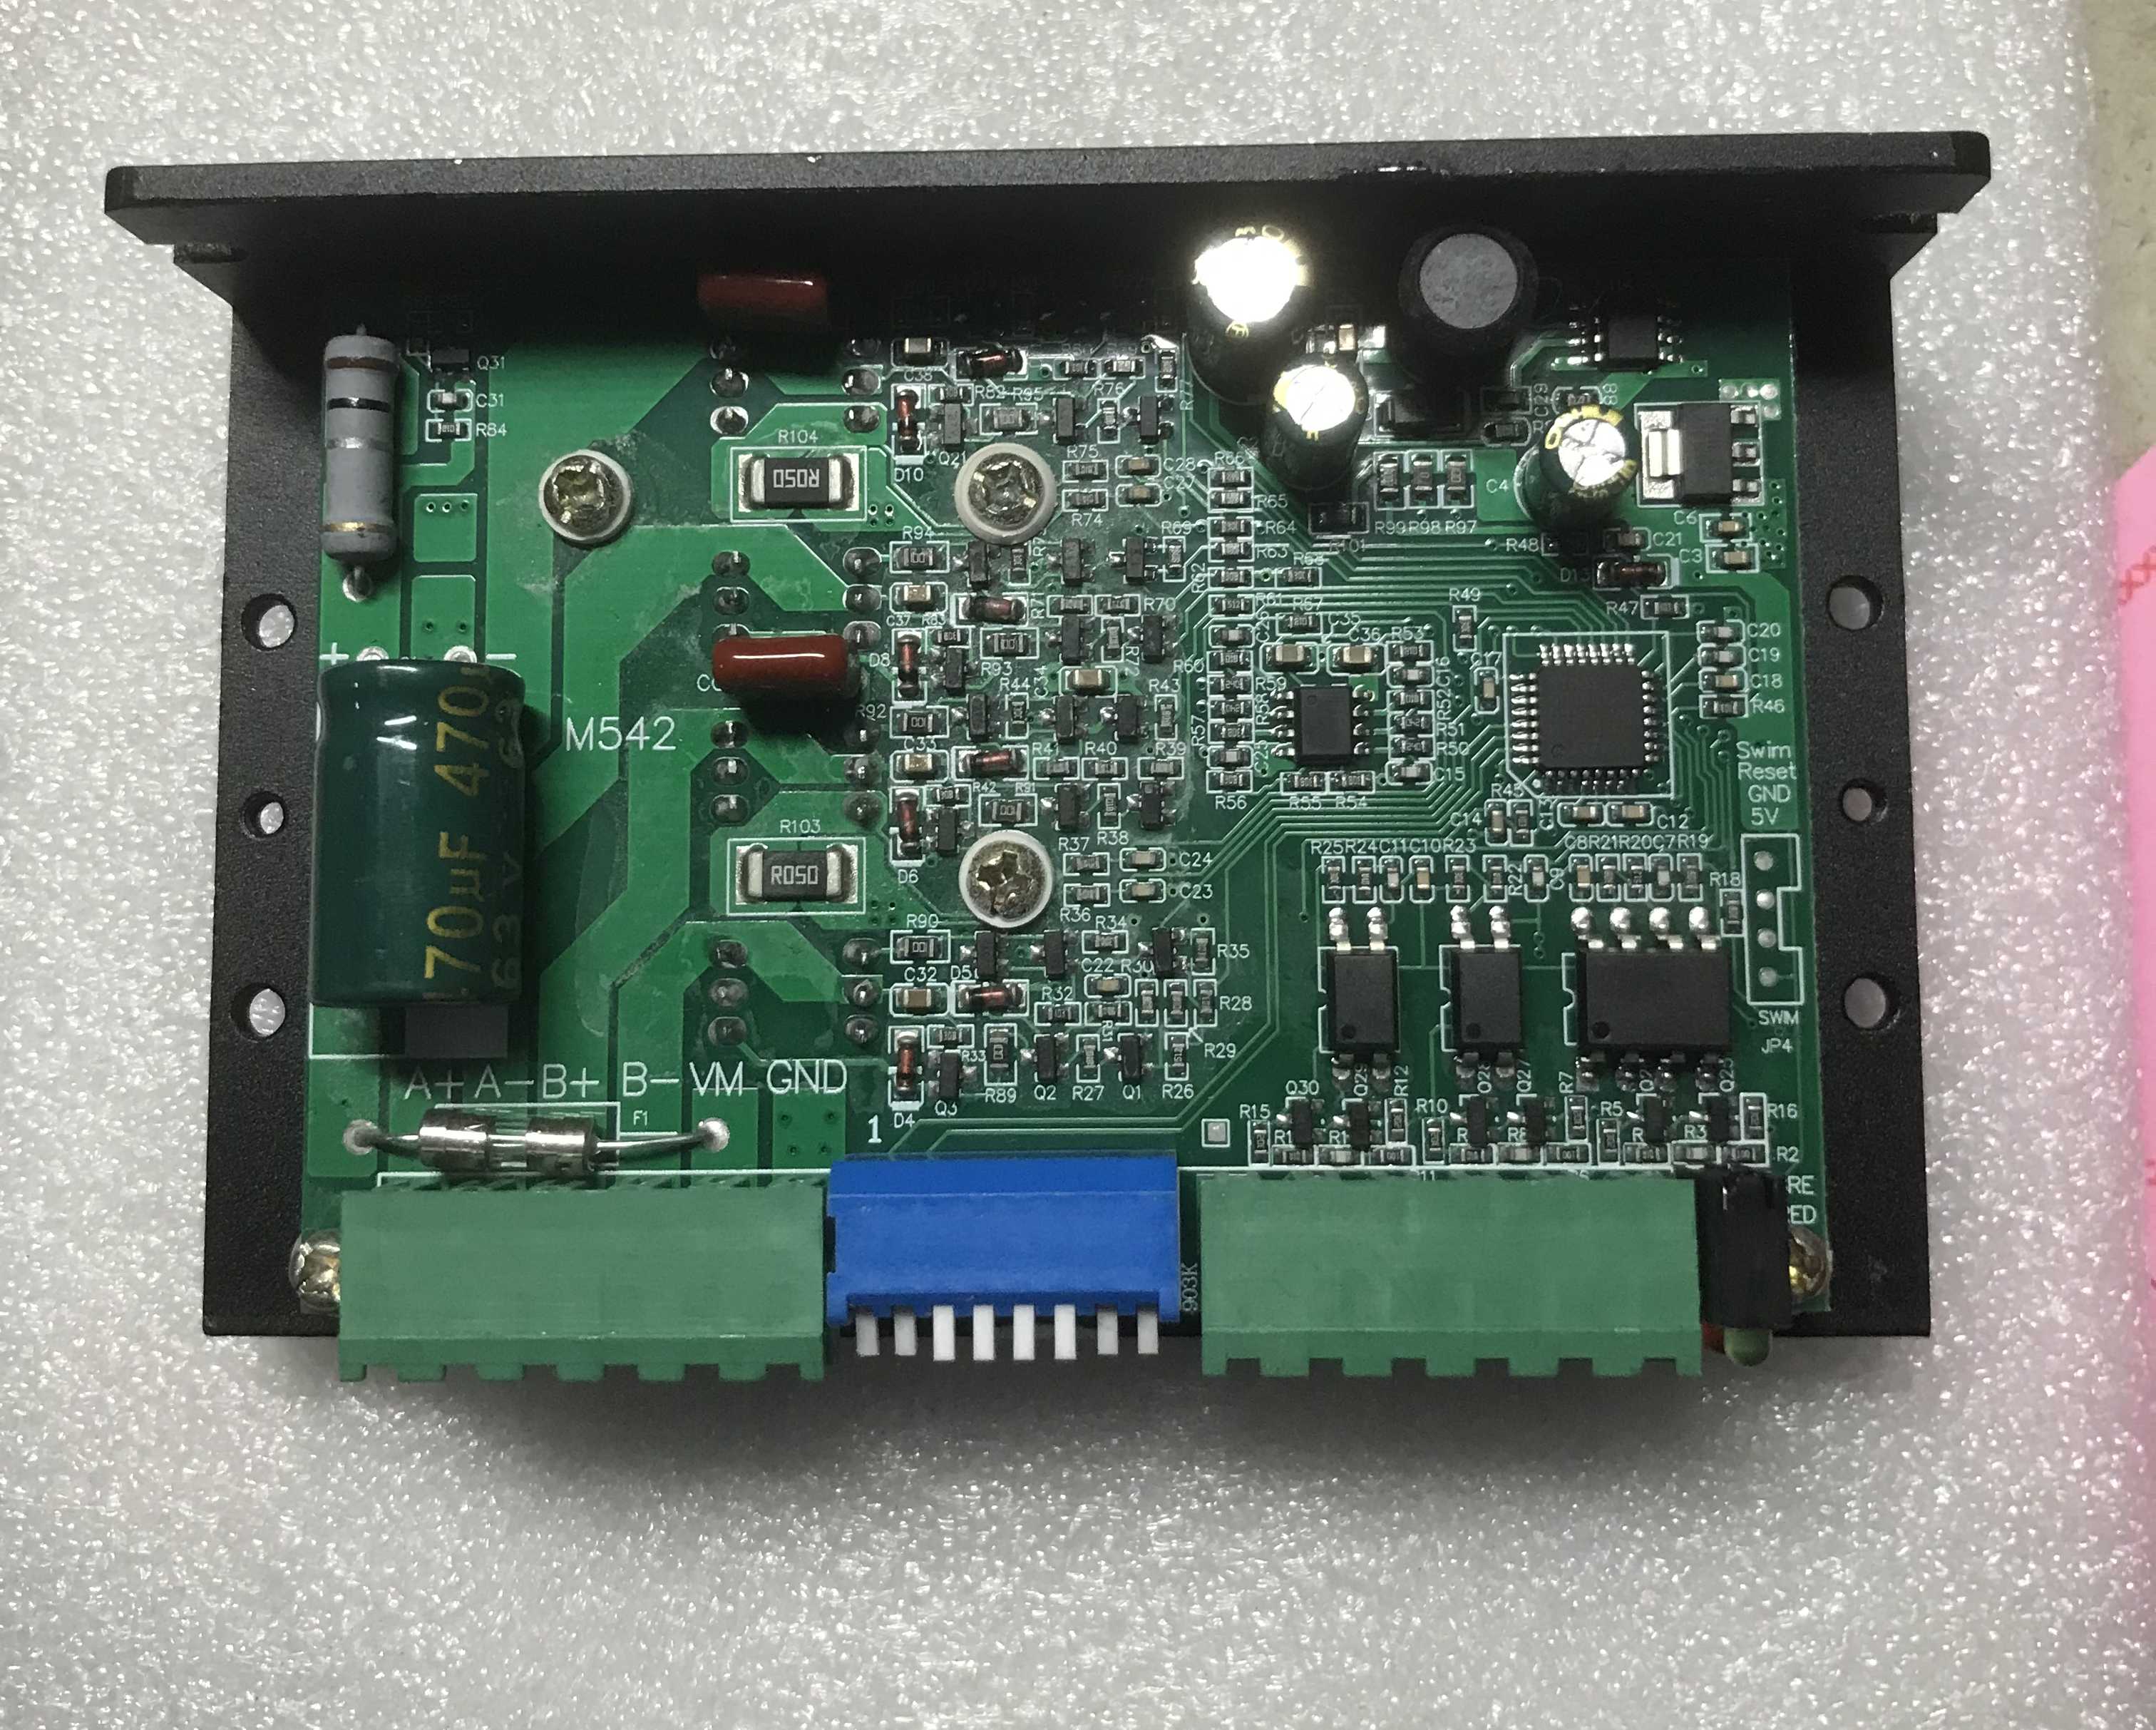
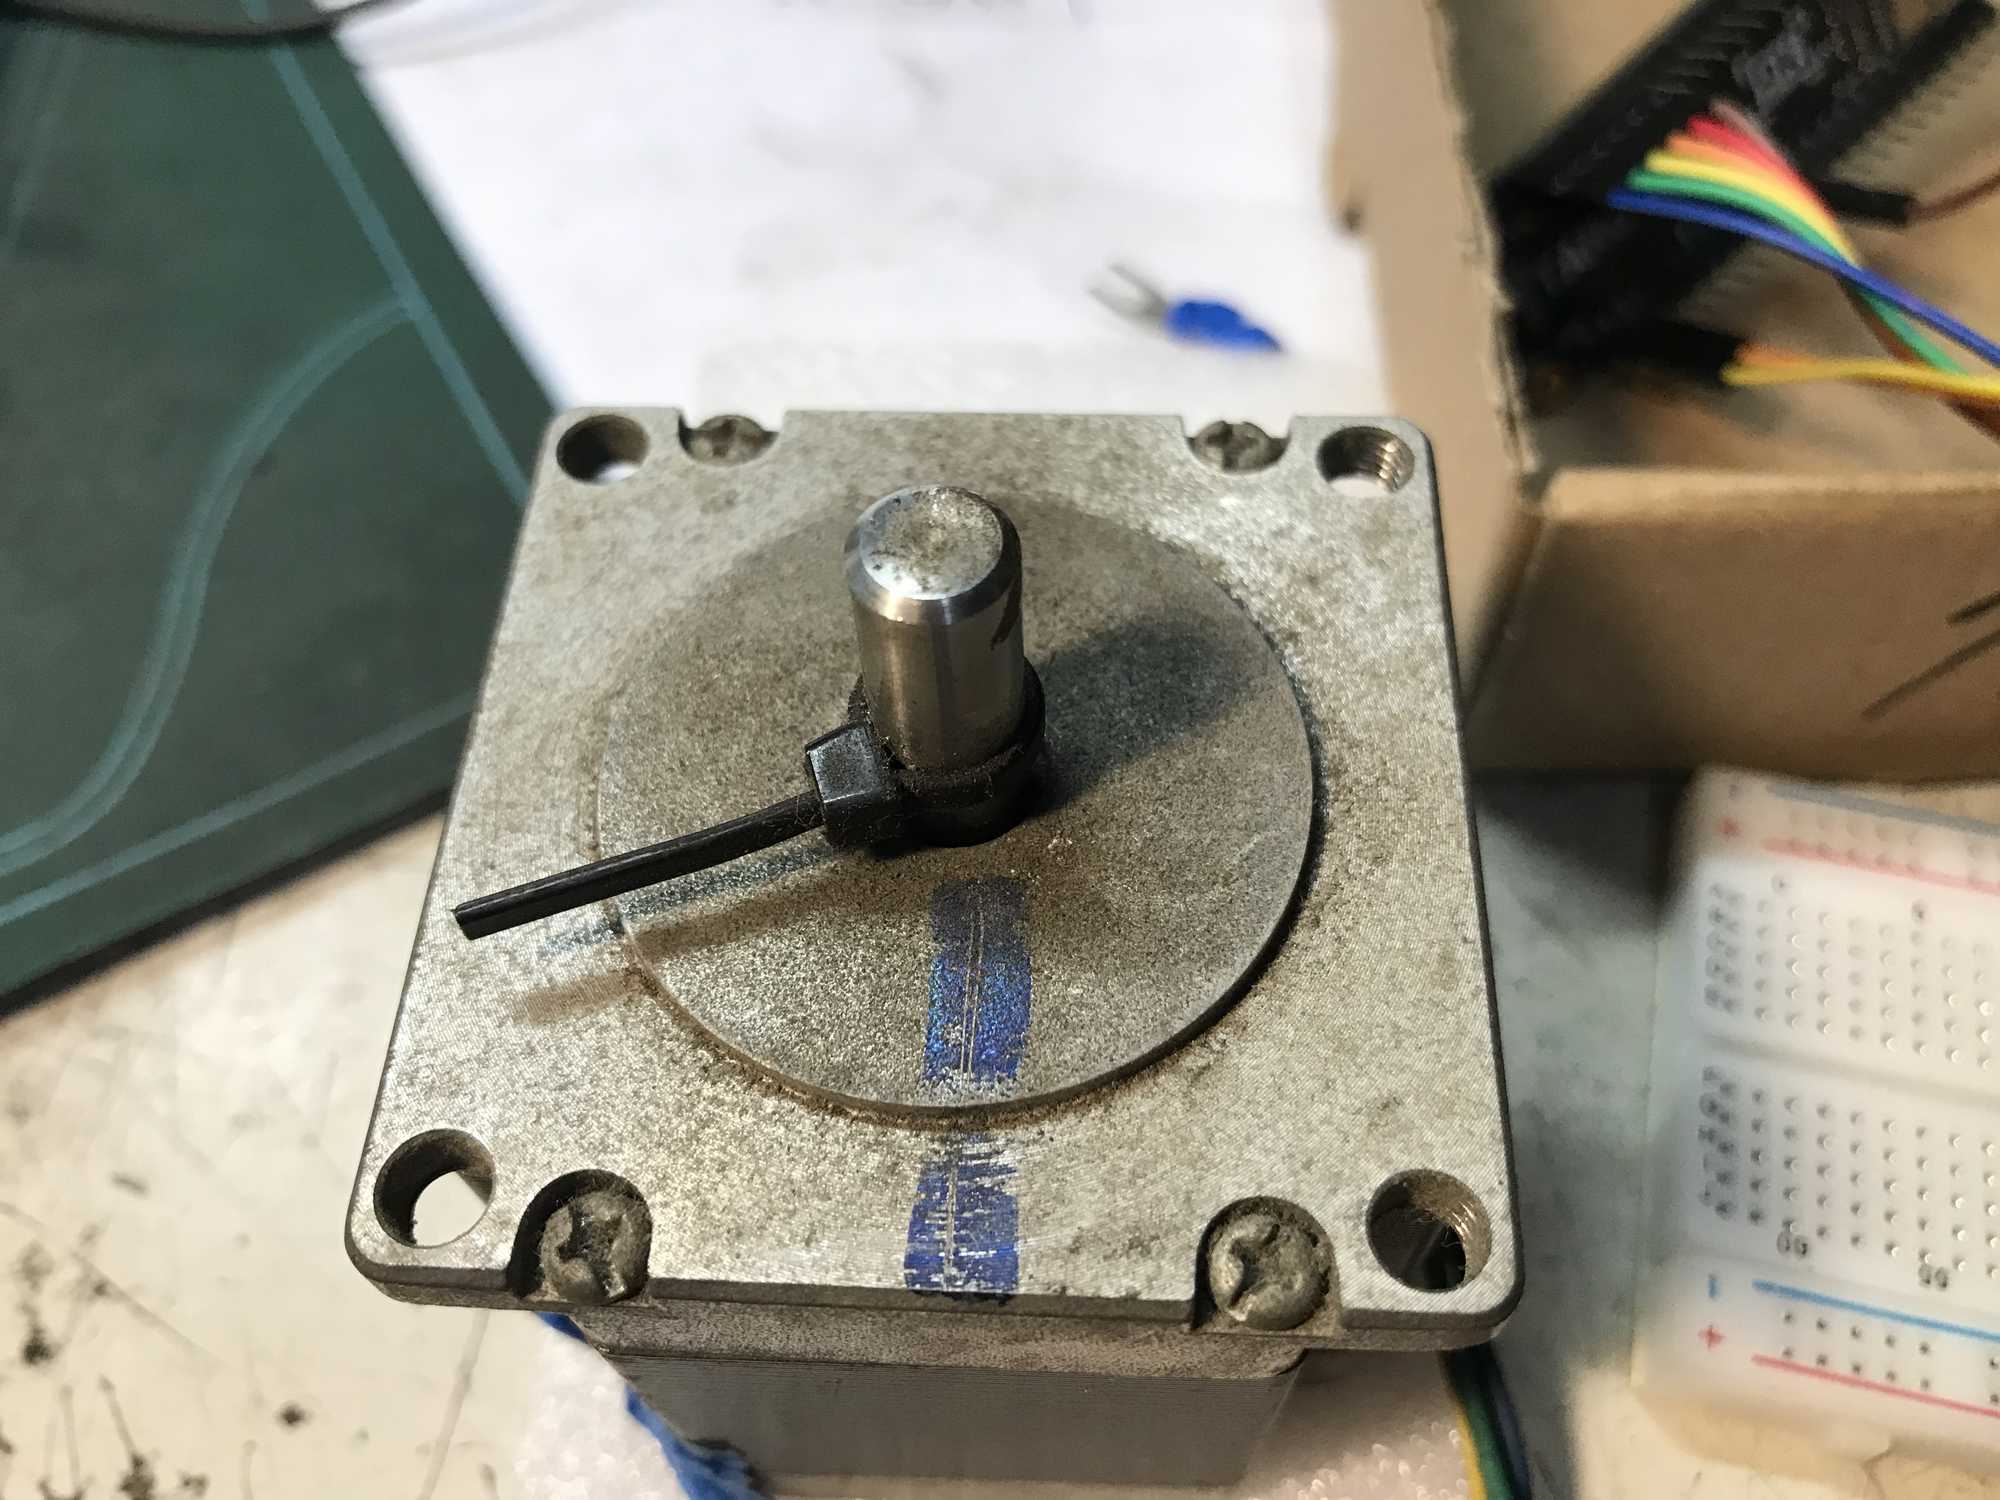
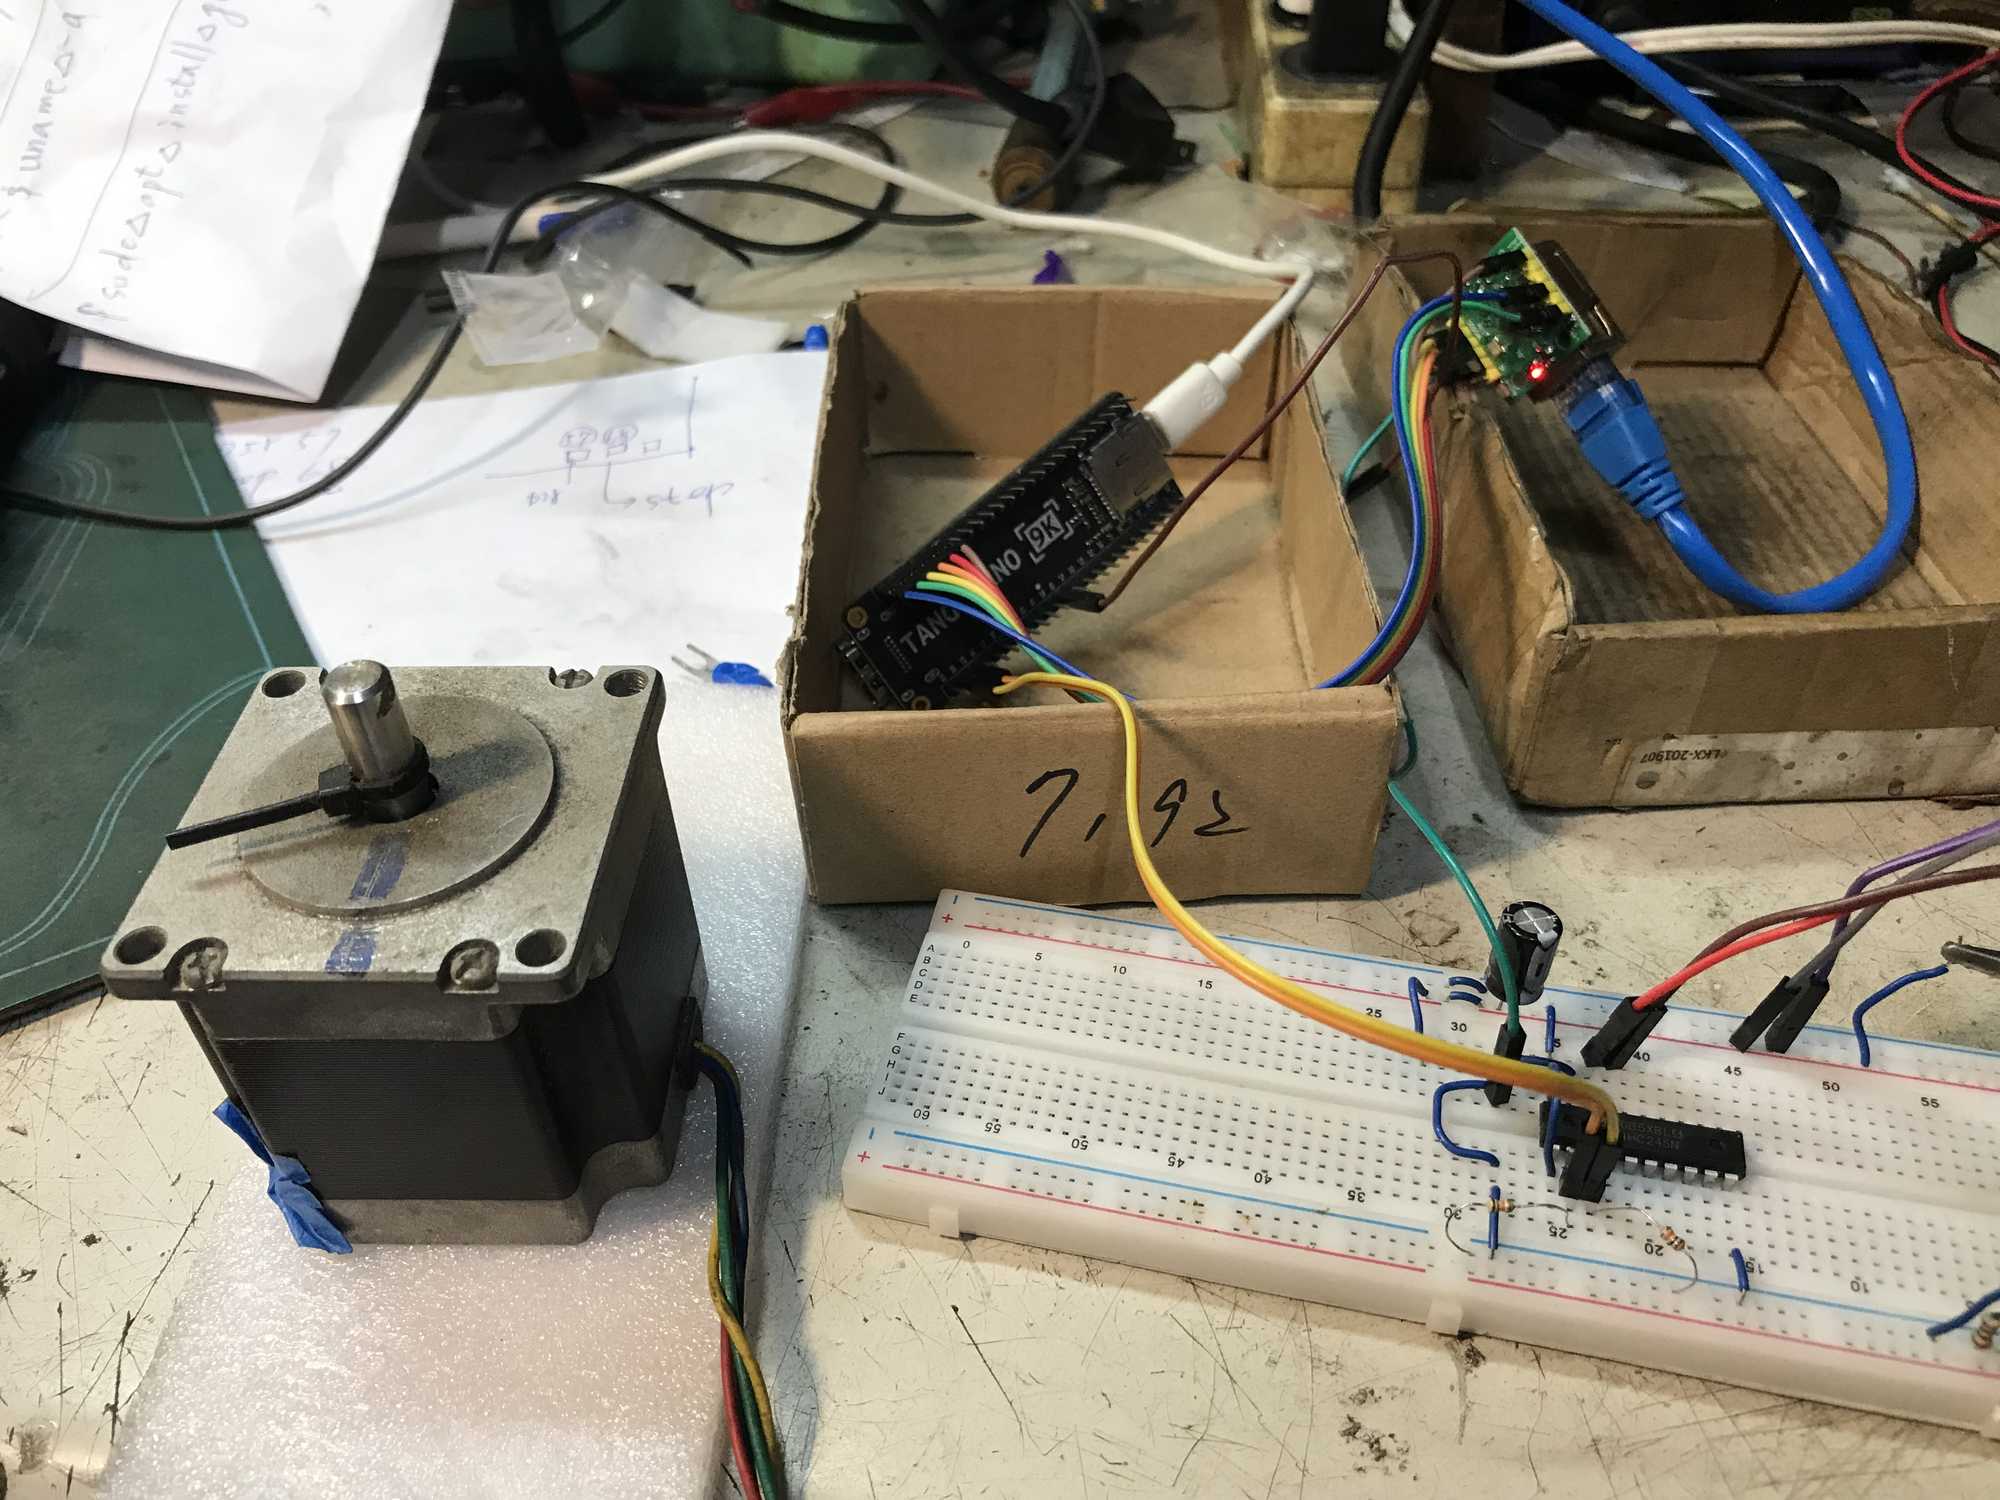
I tested with the Branches dev from GitHub and the Tang Nano 9k, but the motor still couldn't return to the zero position after stopping. You must use the same DM542 stepper motor driver to reproduce this problem.
Last edit: 2 months 1 week ago by viewsat.
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-

Less
More
- Posts: 806
- Thank you received: 502
2 months 3 weeks ago - 2 months 3 weeks ago #348602
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
1. try other pins, looks like you are on two of the HDMI pins (there are filters on the board)
2. set an inverter/modifier to the step pin: (Pins -> Step -> Modifier + -> invert)
3. check that Pulse_LEN and Dir_Delay set to default (4.0 / 0.7)
I have several machines running on this, and there are a few other users as well, all with different drivers and motors; so far, it’s always worked.
EDIT: what is on the breadboard ?
EDIT2: I’ve gone ahead and ordered one of those DM542s just to be on the safe side,
it’s due to arrive on Tuesday or Wednesday
Last edit: 2 months 3 weeks ago by meister.
Please Log in or Create an account to join the conversation.
- viewsat
- Offline
- Junior Member
-
Less
More
- Posts: 33
- Thank you received: 10
2 months 3 weeks ago - 2 months 1 week ago #348622
by viewsat
Replied by viewsat on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
DIR/PULSE issue resolved, thank you!! (2026-08-19)
1. I will try other pins.( tests on both the ICEBreakerV1.0e and Tana Nano9k yielded the same results)
2. I will set an inverter/modifier to the step pin
3. Pulse_LEN => 10us and Dir_Delay => 25us
4. There is a 74HC245 on the breadboard.
I have used many DM542 stepper motor drivers (see the photo above), and no problems when using GRBL and 7i92.
Last edit: 2 months 1 week ago by viewsat.
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
Less
More
- Posts: 806
- Thank you received: 502
2 months 3 weeks ago #348643
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
new driver plugin: TMC5160 via SPI:
www.youtube.com/shorts/DlIHY1Iy-ZQ
I don’t really like AI, but I do give it a go every now and then.
But this time I have to admit that gpt-5.6-sol-xhigh
did a pretty good job of it; it understood how a Rio plugin is structured and also generated the Verilog code quite neatly.
So this is the first plugin I’ve created with the help of AI.
I’d had the drivers for a while, but I was always too lazy
The tricky bit here was realising that, although the drivers use SPI (for configuration), they can’t be controlled via SPI.
To do that, you have to re-solder a tiny resistor on the back – not much fun.
So if you’re going to do this, get a board with the right jumpers for SD mode and SPI mode.
The following user(s) said Thank You: viewsat, jpn9900
Please Log in or Create an account to join the conversation.
- meister
- Offline
- Platinum Member
-
Less
More
- Posts: 806
- Thank you received: 502
2 months 2 weeks ago #348666
by meister
Replied by meister on topic LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)
@viewsat
Wow, OK, I can picture it – that’s intense
Even at low speed – wtf
Wow, OK, I can picture it – that’s intense
Even at low speed – wtf
Please Log in or Create an account to join the conversation.
Time to create page: 0.157 seconds