
- Posts: 226
- Thank you received: 14
5Axis Kinetic from 2.8 on 2.7x
- JackRay
- Offline
- Elite Member
-

Less
More
6 years 1 month ago #181674
by JackRay
Replied by JackRay on topic 5Axis Kinetic from 2.8 on 2.7x
Good evening
I have configured my .hal & .ini files. or I included the loading of the module "xyzac-trt-kins" + connections to the HAL (length compensation in "z"), and I do not understand the behavior of my machine.
with each movement of axes a message announces that I will exceed the limits in positive or negative ...
I used a G54 to make my zero machine.
frankly I don't understand much.
if you have any tips?
thank you
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
6 years 1 month ago - 6 years 1 month ago #181719
by Aciera
Replied by Aciera on topic 5Axis Kinetic from 2.8 on 2.7x
Limits are the values you entered in the ini file for each axis/joint. That is independent on where you zero the axis only on the home position and the length of travel possible for each joint/axis. Of course you will want to setup your workpiece so that there is enough space for the machine to move.
The contoller will try to move the tool in a position where the TCP follows the part being rotated. Depending on your pivot lenghts and tool lenght that may well exeed your limits.
Have you set up your pivot distances correctly?
[edit]
best approach might be to start with the rotary table and just leave the tilting table at 0. As you rotate the rotary you should see the tool folowing the table.
Maybe have a look here:
forum.linuxcnc.org/10-advanced-configura...nematics-x?start=270
forum.linuxcnc.org/media/kunena/attachme.../5-axis-machines.pdf
Last edit: 6 years 1 month ago by Aciera. Reason: Clarifications
Please Log in or Create an account to join the conversation.
- JackRay
- Offline
- Elite Member
-
Less
More
- Posts: 226
- Thank you received: 14
6 years 1 month ago #181724
by JackRay
Replied by JackRay on topic 5Axis Kinetic from 2.8 on 2.7x
ok thanks i will try. I can understand through your messages that the more the pivot offset and important as well as the length of the tools, it will take longer strokes on the 3 axes "xyz".
thank you
thank you
Please Log in or Create an account to join the conversation.
- JackRay
- Offline
- Elite Member
-
Less
More
- Posts: 226
- Thank you received: 14
6 years 1 month ago #181740
by JackRay
Replied by JackRay on topic 5Axis Kinetic from 2.8 on 2.7x
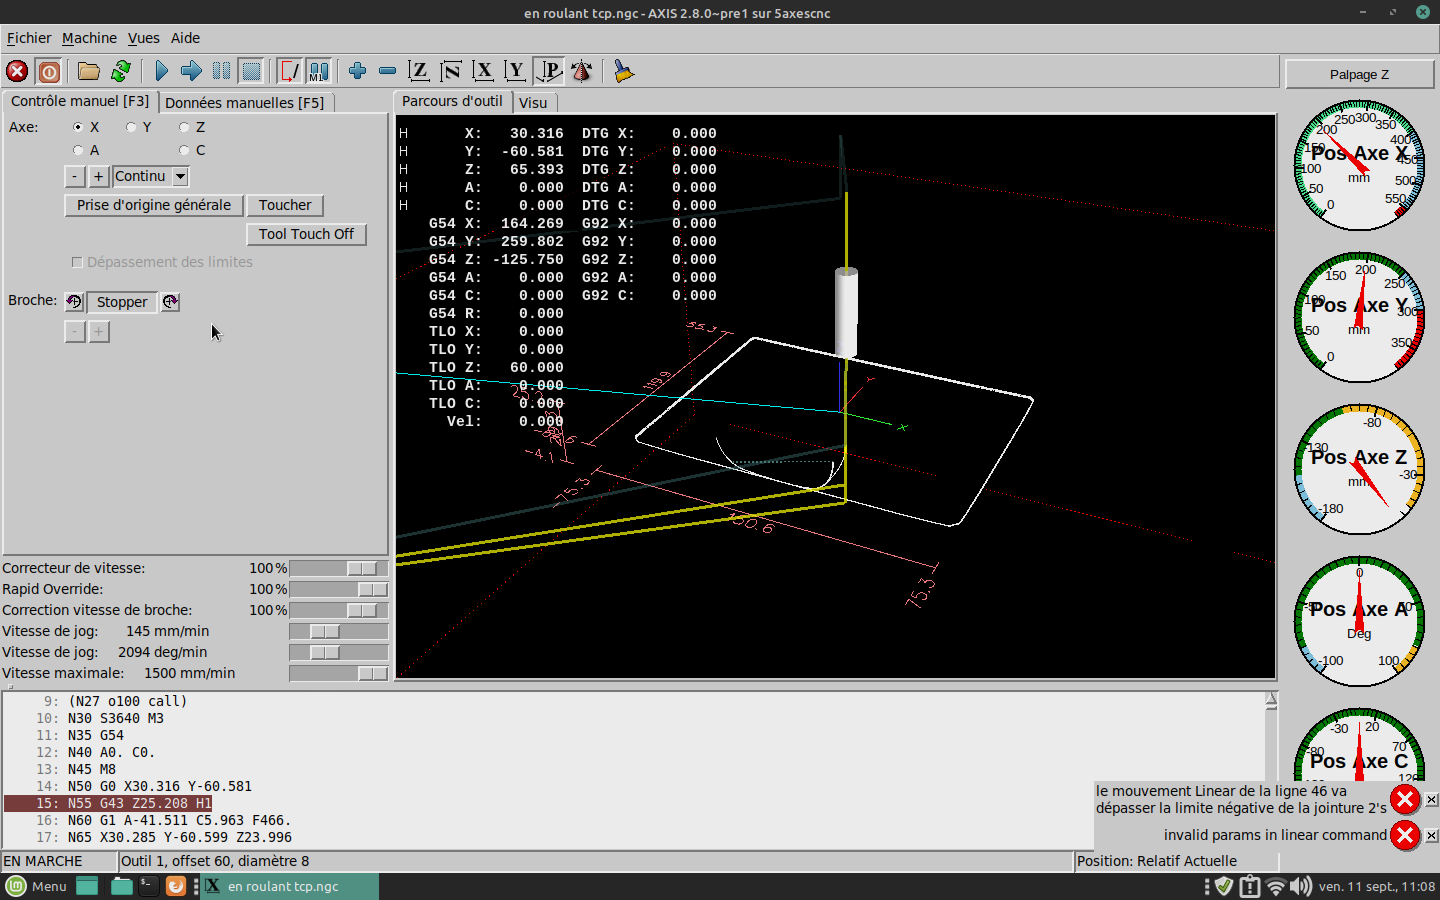
Despite the changes made to my .hal / .ini files I cannot get it to work. still a joint problem on the "z" axis despite changes in tool length or offset of the pivot point.
help please.
thank you
help please.
thank you
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
6 years 1 month ago - 6 years 1 month ago #181744
by Aciera
Replied by Aciera on topic 5Axis Kinetic from 2.8 on 2.7x
It says its got a limit violation on joint2 at line 46.
Can you post your GCode?
[edit]
Oh, one other imortant thing concerning limits:
LinuxCNC does only check axis values against limit values. It does not check joints. So this means that if your coordinate system is tilted or rotated by A or C when using non-trivial kinemtics, those limits are not aligned with your actual joints anymore and have not really any meaning.
So maybe you are not really exceeding your physical limits. This is really where we get to the limits of the current state of linuxCNC.
So if you have limit switches on both ends of the axis you could try to disable the limits in the INI.
Last edit: 6 years 1 month ago by Aciera.
Please Log in or Create an account to join the conversation.
- JackRay
- Offline
- Elite Member
-
Less
More
- Posts: 226
- Thank you received: 14
6 years 1 month ago #181768
by JackRay
Replied by JackRay on topic 5Axis Kinetic from 2.8 on 2.7x
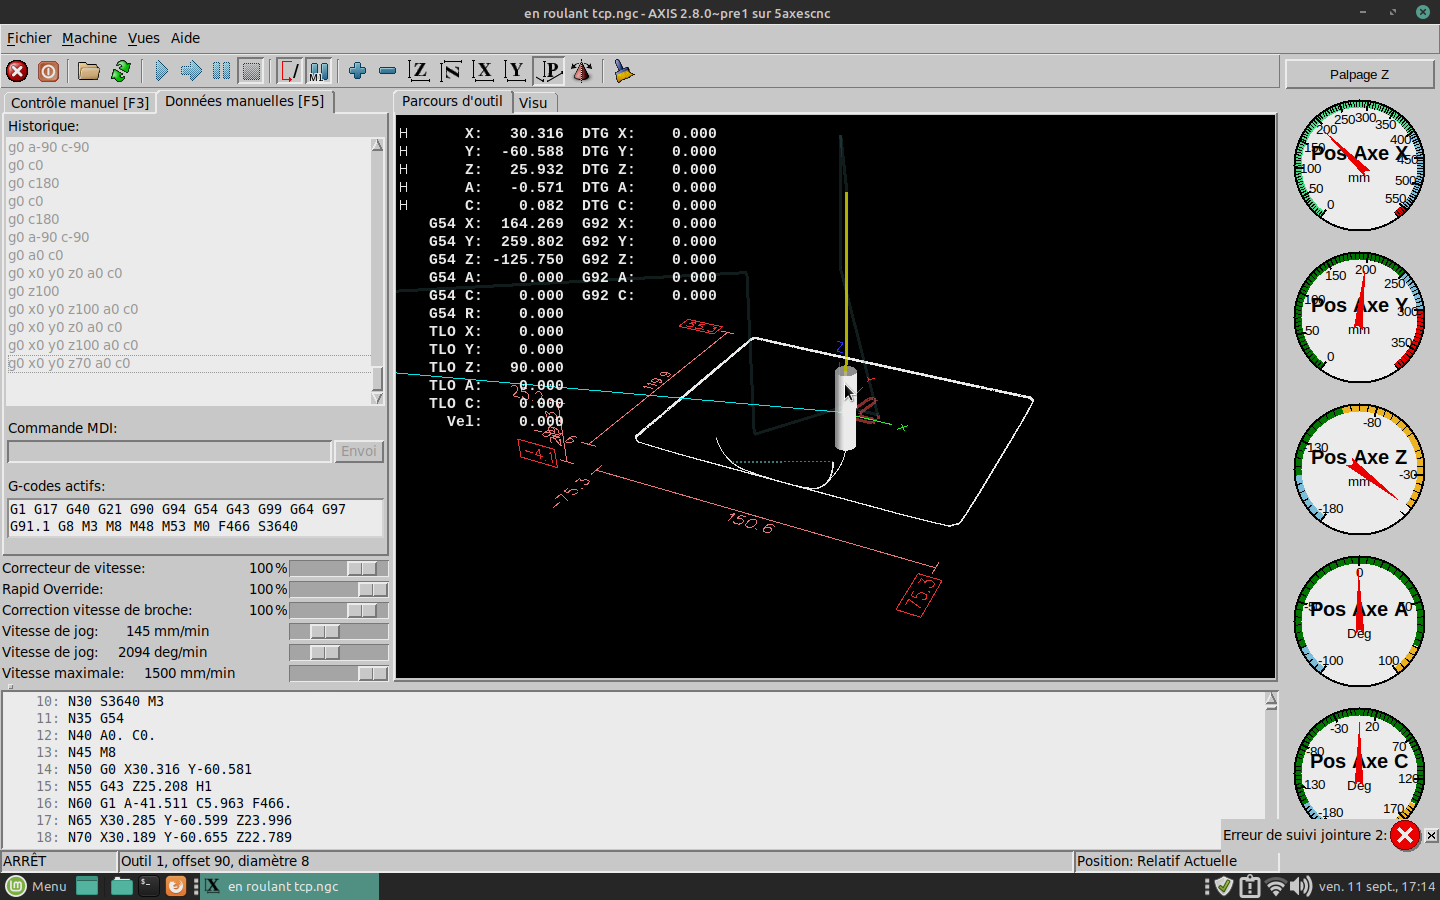
So I deactivated all the limes of each of the axes-I have an error on join 2.here is my G code file.Regards
Please Log in or Create an account to join the conversation.
Time to create page: 0.274 seconds