
- Posts: 723
- Thank you received: 139
Schaublin 125-CNC retrofit.
- smc.collins
- Offline
- Platinum Member
-

Less
More
3 years 10 months ago - 3 years 10 months ago #259667
by smc.collins
Replied by smc.collins on topic Schaublin 125-CNC retrofit.
yes, you got it. I wasn't sure if your servo was geared down or up from your lead screw. so yes, you need to tune your velocity for your lead screw pitch. Linux CNC calculates your velocity from pulse count versus travel distance.
Motor velocity & gear ratio = actual velocity with lead screw pitch etc accounted for.
Most of my tuning has been with brush dc motors, they have a lot more grunt on acceleration at low speed. If you have extra servo speed, maybe increasing giving the servo motor to lead screw more ratio would help if you can't get reasonable acceleration response. More TQ at the lead screw, More HP at the motor. did this lathe originally have DC servos ?
as to yor prior question.
Yes your drive velocity total travel needs to match in the drive and linux CNC.
For instance
If the drive has to run the motor at say 10,000rpm to go 10,000mm/sec, then your ini value is 10,000mm/sec
you need to account for ALL of the gearing and pulse counts. definitely looks like the acceleration rate is to high, by about 100%. try cutting it in half.
MAX_Accle is currently 750, make is 375, see if that helps
Last edit: 3 years 10 months ago by smc.collins.
The following user(s) said Thank You: RotarySMP
- RotarySMP
- Offline
- Platinum Member
-
Less
More
- Posts: 1635
- Thank you received: 595
3 years 10 months ago #259669
by RotarySMP
Replied by RotarySMP on topic Schaublin 125-CNC retrofit.
The X axis has very little mass. I dont need exceptionally dynamic performance from a lathe, so I wont be changing the gearing. I'll revist the accel, and see if I can get rid of that bump. The Z is already geared down more than X.
The original motors were DC servo's, but I did the MoI and Torque calcs on these AC Servos with the drive train and loads, and should be in the 1:1 - 1:2 inertial coupling range, with plenty of excess torque, so I should be able to find a sweet spot.
Sorry it took so long to get that gain setting understood. It is pretty obvious once I got it. Duh!
Would you tend to spend a lot of time trying to manually tune the drive, or just back off a bit from the edge of autotunes performance limit, and then do the rest in LCNC?
- smc.collins
- Offline
- Platinum Member
-
Less
More
- Posts: 723
- Thank you received: 139
3 years 10 months ago - 3 years 10 months ago #259673
by smc.collins
Replied by smc.collins on topic Schaublin 125-CNC retrofit.
I'd remove all the lcnc pid authority, tune the drive and ini values to get tight control, then watch lcnc while it works and maybe touch P and ff1 as needed for edge cases. basically get really good open loop control first. i do this with engines to.
find what makes the engine happiest, then bring the AF sensor feedback values to that. don't tune to make the AF happy, make the cylinder happy. same deal here.
i might be misreading the ff error, maybe accel needs to be 1500 instead of 750.
yeah those servos are 220v 3phase 2.8 amps ?? so 700watt ish, that's a lot.
but now you know how to get to say 6500mm/min with good control.
you got this now Mark,
Last edit: 3 years 10 months ago by smc.collins.
The following user(s) said Thank You: RotarySMP
- RotarySMP
- Offline
- Platinum Member
-
Less
More
- Posts: 1635
- Thank you received: 595
3 years 10 months ago - 3 years 10 months ago #259723
by RotarySMP
Replied by RotarySMP on topic Schaublin 125-CNC retrofit.
"I'd remove all the lcnc pid authority, tune the drive and ini values to get tight control,"
I halved the accel, and set LCNC to open loop (P0 FF1), and did a 0.25mm feedrate move at 50mm/min. This still creates a following error. Current INI settings are FERROR =1 and MIN_FERROR= 1 on this axis.
Why would I trip a following error, every time, with a slow 0.25mm move if MIN_FERROR = 1?
Once everything is tuned, What would be a normall FERROR allowance for a pretty slow, but hopfully quite precise machine like this? 0.01 Min and 0.025 at speed?
This is the plot.
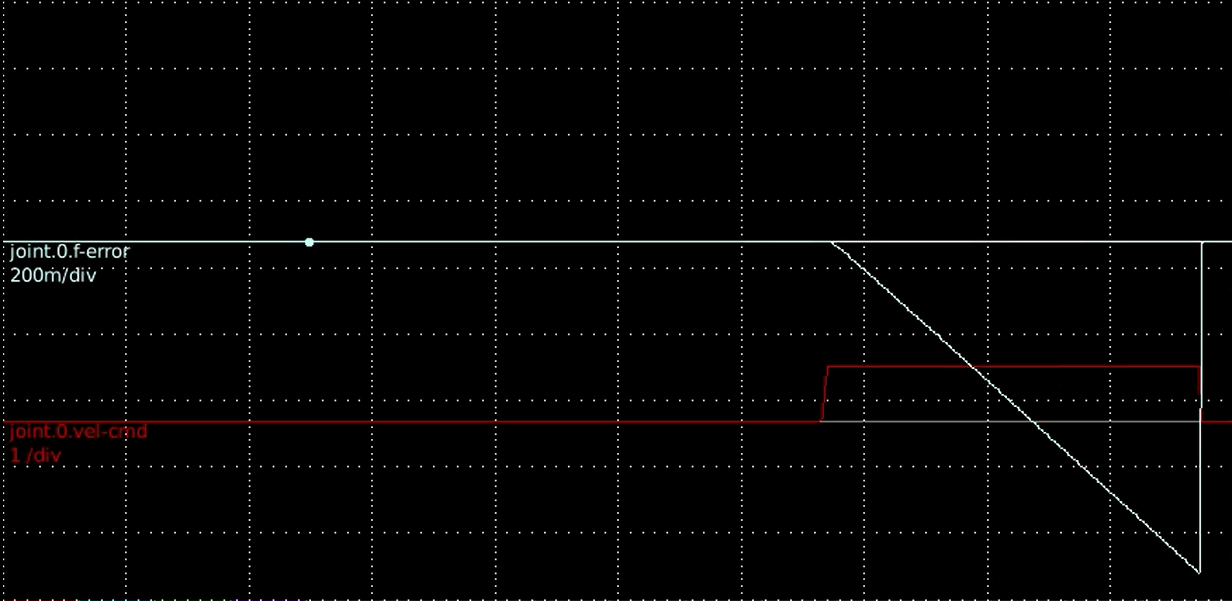
I halved the accel, and set LCNC to open loop (P0 FF1), and did a 0.25mm feedrate move at 50mm/min. This still creates a following error. Current INI settings are FERROR =1 and MIN_FERROR= 1 on this axis.
Why would I trip a following error, every time, with a slow 0.25mm move if MIN_FERROR = 1?
Once everything is tuned, What would be a normall FERROR allowance for a pretty slow, but hopfully quite precise machine like this? 0.01 Min and 0.025 at speed?
This is the plot.
Last edit: 3 years 10 months ago by RotarySMP.
- RotarySMP
- Offline
- Platinum Member
-
Less
More
- Posts: 1635
- Thank you received: 595
3 years 10 months ago #259730
by RotarySMP
Replied by RotarySMP on topic Schaublin 125-CNC retrofit.
I really cnt see any better way of tuning the drive than using it's "autotune" settings (which are just a look up table of discrete configurations). With LinuxCNC in openloop mode, and doing short jogs within the FERROR, I cant do better with the LinuxCNC Osci, than I can get by just increasing the auto tune to instablity and then backing off.
Having done that, I then used Tommy's tuning instructions once again.
At 200mm/min this is the best I can get tuned.
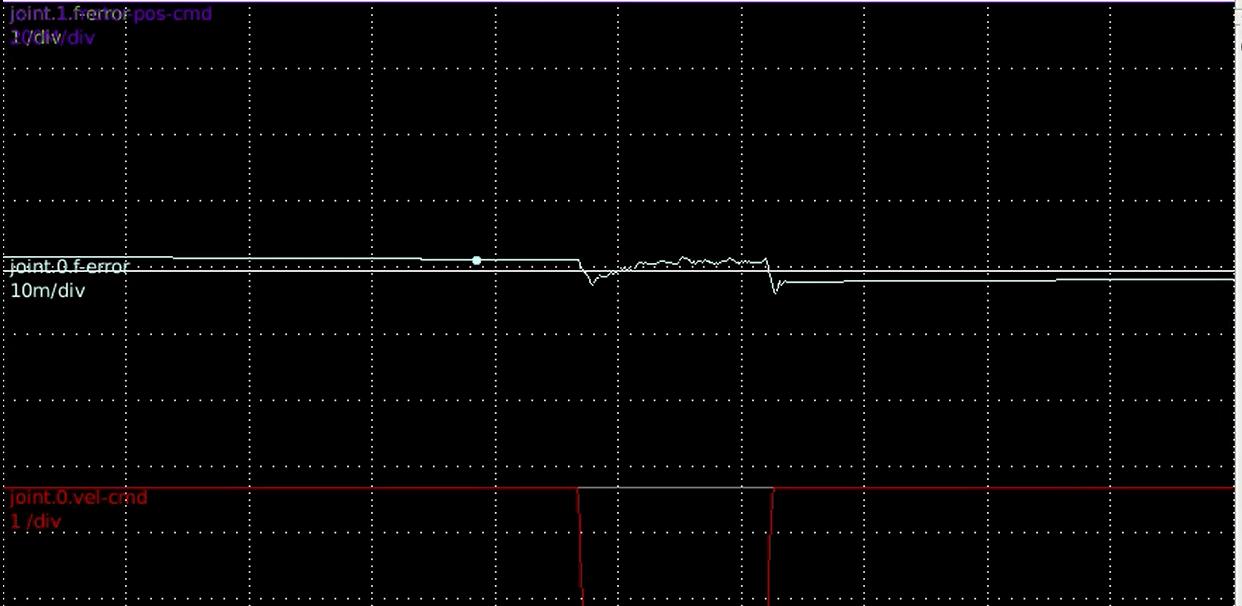
At 500mm/min :
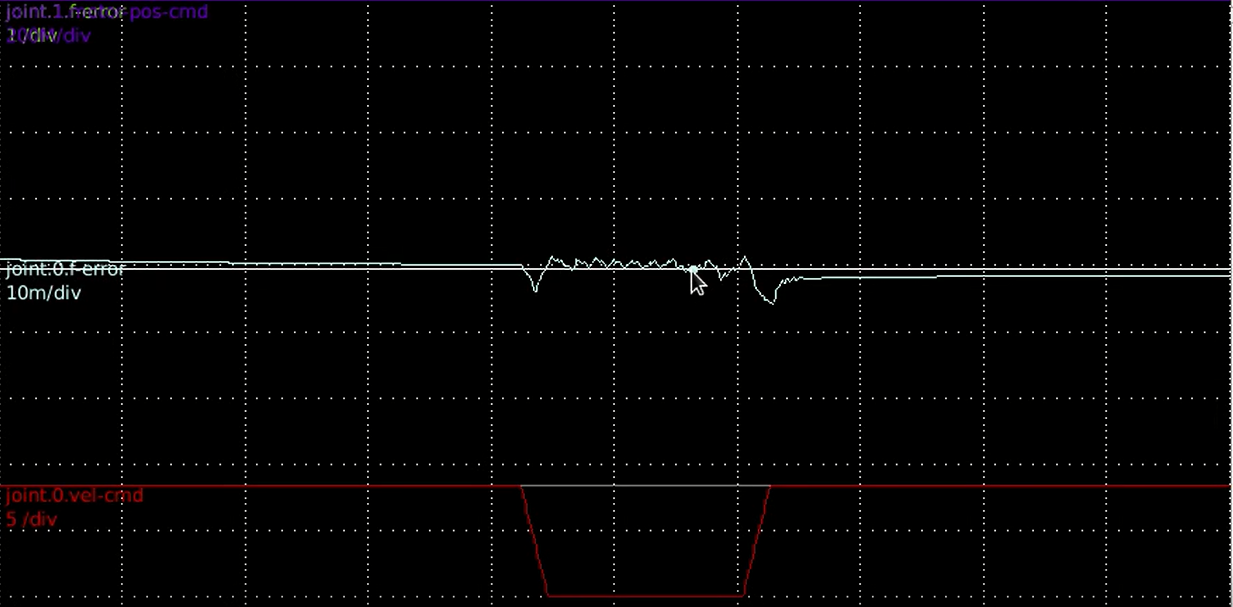
And these are the best settings I came up with and the plot at 1000mm/min
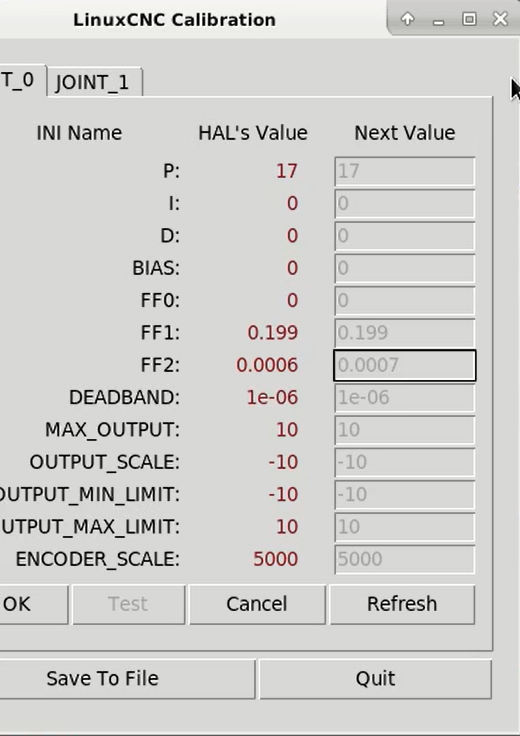
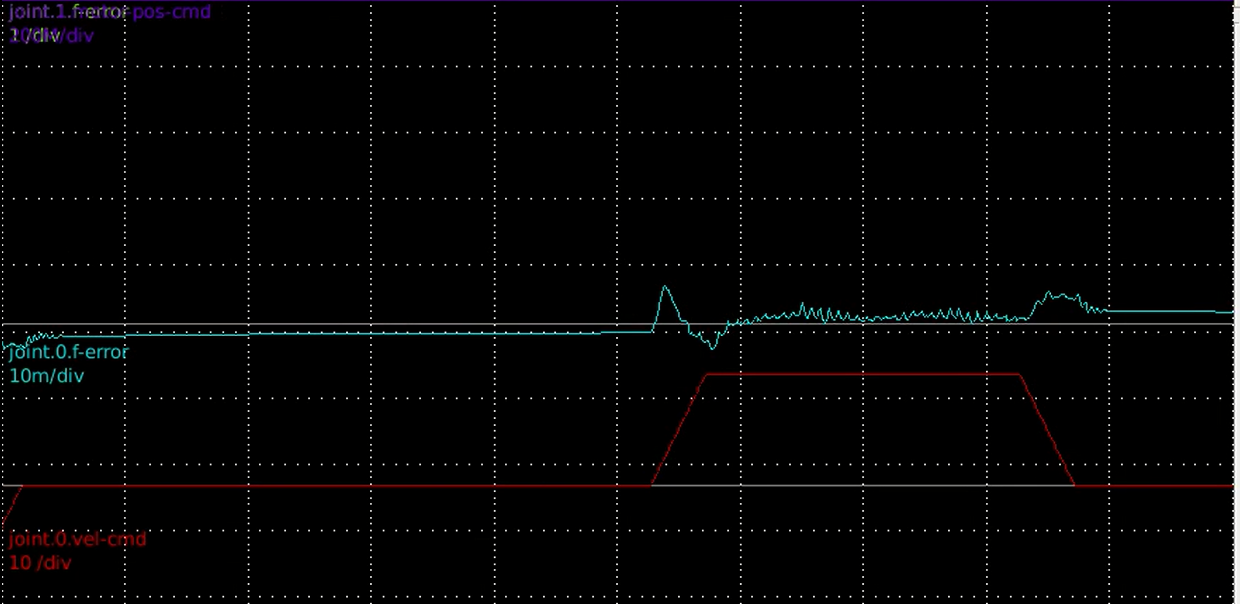
What are your thoughts on this? How anal do I need to go on this. You can keep zooming and zooming, and can always have it looking terrible.
I rewatched Peter (Talla83) excellent video, where he just used a vise as a crute linear way, and he seems to have only stayed at 1/Div, whereas I am used 10m/Div. At 1/div, my plot is a flat line.
Having done that, I then used Tommy's tuning instructions once again.
At 200mm/min this is the best I can get tuned.
At 500mm/min :
And these are the best settings I came up with and the plot at 1000mm/min
What are your thoughts on this? How anal do I need to go on this. You can keep zooming and zooming, and can always have it looking terrible.
I rewatched Peter (Talla83) excellent video, where he just used a vise as a crute linear way, and he seems to have only stayed at 1/Div, whereas I am used 10m/Div. At 1/div, my plot is a flat line.
- smc.collins
- Offline
- Platinum Member
-
Less
More
- Posts: 723
- Thank you received: 139
3 years 10 months ago #259737
by smc.collins
Replied by smc.collins on topic Schaublin 125-CNC retrofit.
well, i think you're just about there. my only suggestion is to start moving faster and see if the amplitude is small or not.
have you calculated out the variables fpr the servo control and drive ??
max motor rpm = x velocity mm/sec
made sure that is what your ini file reflects this
that your max input voltage to the drive is 10v in ini and drive
max velocity etc.
adjust the acceleration rate in the ini to reflect the physical ability of the
mechanical assembly
if all that is good and co-ordinated, then yes it's time to work with the lcnc pid.
if your total max velocity is 3m/min
I'd test at 1m/min 2m/min 3m/min
if everything looks good. yeah, that's when it's time to get after the pid adjustments. my suspicion is that your drive input gain settings might be to low, but, see what ya get.
The following user(s) said Thank You: RotarySMP
Moderators: piasdom
Time to create page: 0.280 seconds