
- Posts: 62
- Thank you received: 30
ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
- muvideo
- Offline
- Senior Member
-

Less
More
3 years 10 months ago - 3 years 10 months ago #258335
by muvideo
Replied by muvideo on topic ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
Hello, another inch forward for my implemetation:
Ciao!
Fabio
- Lcnc master
- the driver now can handle up to 4 boards, you'll need a gigabit ethernet switch. In theory many more boards could be handled, but honestly I'm not sure how useful is to increase this number, if someone wants to try just set
Code:#define MAX_CHAN 4 in Lcnc.c to the number you want
- the ip address and port now are parameters at hal invocation, so no need to rebuild the driver to change ip and port, added also a "debug" parameter. Example:
"debug=1" will add some verbose output and a series of pins that report the time in ns that each part of the code is taking, of these T1 and T6 correspond to two calls to eb_send function, and are the most time consuming.Code:loadrt Lcnc ipaddr="192.168.2.50","192.168.2.51" ipport="1234","1235" debug=1
- A raspberry pi 4 seem capable to handle two colorlight boards at 1ms Thread with sufficient stability.
- stepgen step and direction timings are now expressed in ns instead of us.
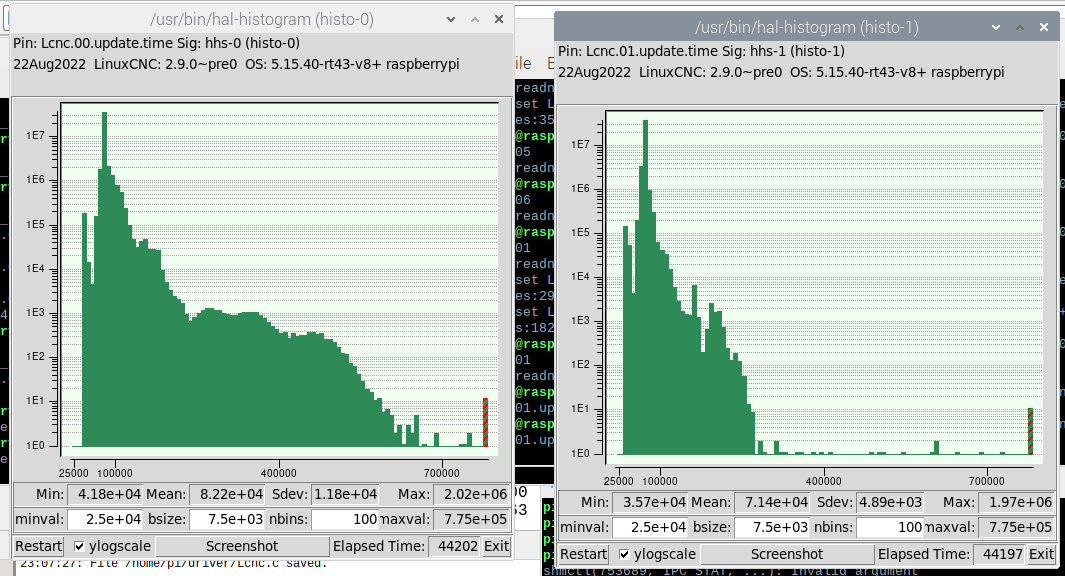
- In the attachment the timing I'm seeing with 2 colorlight 5a-75b boards, on the left the one with 14 outputs 11 inputs 6 stepgens 6 encoders 6 pwm, on the right the one with 26 outputs 23 inputs 6 pwm. Seem that also the fpga configuration is having an impact on timing. Some sporadic task overrun are still there.
Ciao!
Fabio
Last edit: 3 years 10 months ago by muvideo.
The following user(s) said Thank You: romanetz
- romanetz
- Offline
- Senior Member
-
Less
More
- Posts: 51
- Thank you received: 45
3 years 10 months ago - 3 years 10 months ago #258445
by romanetz
Replied by romanetz on topic ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
@TOLP2 How to use the driver with right-in-place installation, i. e. linuxcnc built from source?
Last edit: 3 years 10 months ago by romanetz.
- romanetz
- Offline
- Senior Member
-
Less
More
- Posts: 51
- Thank you received: 45
3 years 10 months ago - 3 years 10 months ago #258485
by romanetz
Replied by romanetz on topic ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
Hello, another inch forward for my implementation
Fabio, I tried your configuration. In purpose of reducing time for testing, I flashed pre-built firmware from Lcnc/prebuilt_firmwares/75e_v6_v8_30o29i9s9e8p/. The board responds to ping at desired ip 192.168.2.50
In order to run machine configuration with my r-i-p installation of Lcnc, I've built the driver without any issues. Then, an error in configuration has been found: loadrt Lcnc ipaddr="192.168.2.50" udpport (not ipport as mentioned in documentation)="1234". Well, after making some changes to match .ngc files location, i got a final error. When I jog the axis towards (say, X+ or Y+) results in decreasing of proper coordinate, therefore I get a joint following error. Looks like somewhere commanded speed is been inverted.
Upd. the reason was that acceleration limit was not set in the configuration. After adding of these llines "setp Lcnc.00.stepgen.02.acc_lim [JOINT_0]STEPGEN_MAXACCEL" for all of corresponding axes, the configuration has run successfully.
Last edit: 3 years 10 months ago by romanetz.
- wuyatom
- Offline
- Senior Member
-
Less
More
- Posts: 42
- Thank you received: 0
3 years 10 months ago - 3 years 10 months ago #258513
by wuyatom

My v7.1 board is not enabled
Replied by wuyatom on topic ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
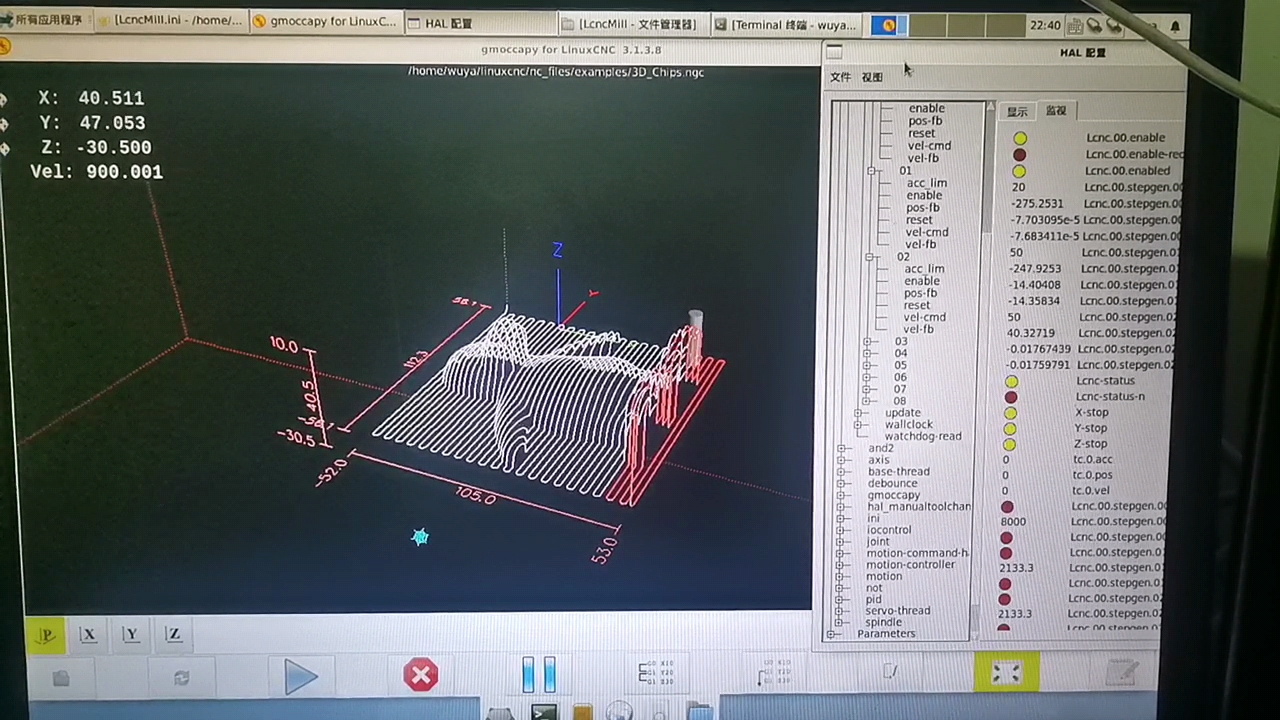
My v7.1 board is not enabled
Last edit: 3 years 10 months ago by wuyatom.
- romanetz
- Offline
- Senior Member
-
Less
More
- Posts: 51
- Thank you received: 45
3 years 10 months ago #258557
by romanetz
Replied by romanetz on topic ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
Here is my test config for Litex-CNC
- muvideo
- Offline
- Senior Member
-
Less
More
- Posts: 62
- Thank you received: 30
3 years 10 months ago #258600
by muvideo
here Fix_Commit now. Let me know of any strange behavior.
Replied by muvideo on topic ColorCNC Colorlight 5A-75E/5A-75B as FPGA controller board
Hi, I'm very happy you were successful in testing my last commit, thanks for spotting the errors, I hope they are fixed
Hello, another inch forward for my implementation
Fabio, I tried your configuration. In purpose of reducing time for testing, I flashed pre-built firmware from Lcnc/prebuilt_firmwares/75e_v6_v8_30o29i9s9e8p/. The board responds to ping at desired ip 192.168.2.50
In order to run machine configuration with my r-i-p installation of Lcnc, I've built the driver without any issues. Then, an error in configuration has been found: loadrt Lcnc ipaddr="192.168.2.50" udpport (not ipport as mentioned in documentation)="1234". Well, after making some changes to match .ngc files location, i got a final error. When I jog the axis towards (say, X+ or Y+) results in decreasing of proper coordinate, therefore I get a joint following error. Looks like somewhere commanded speed is been inverted.
Upd. the reason was that acceleration limit was not set in the configuration. After adding of these llines "setp Lcnc.00.stepgen.02.acc_lim [JOINT_0]STEPGEN_MAXACCEL" for all of corresponding axes, the configuration has run successfully.
here Fix_Commit now. Let me know of any strange behavior.
Moderators: PCW, jmelson
Time to create page: 0.220 seconds